SKU: DRFC-1987
📋 GST Invoice Available

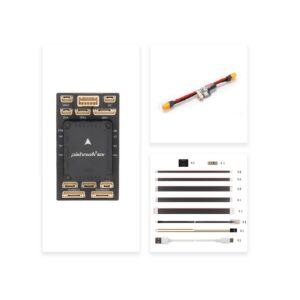
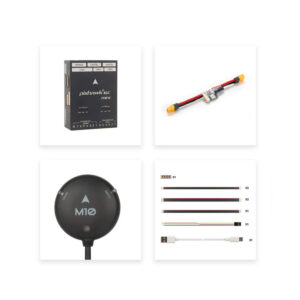
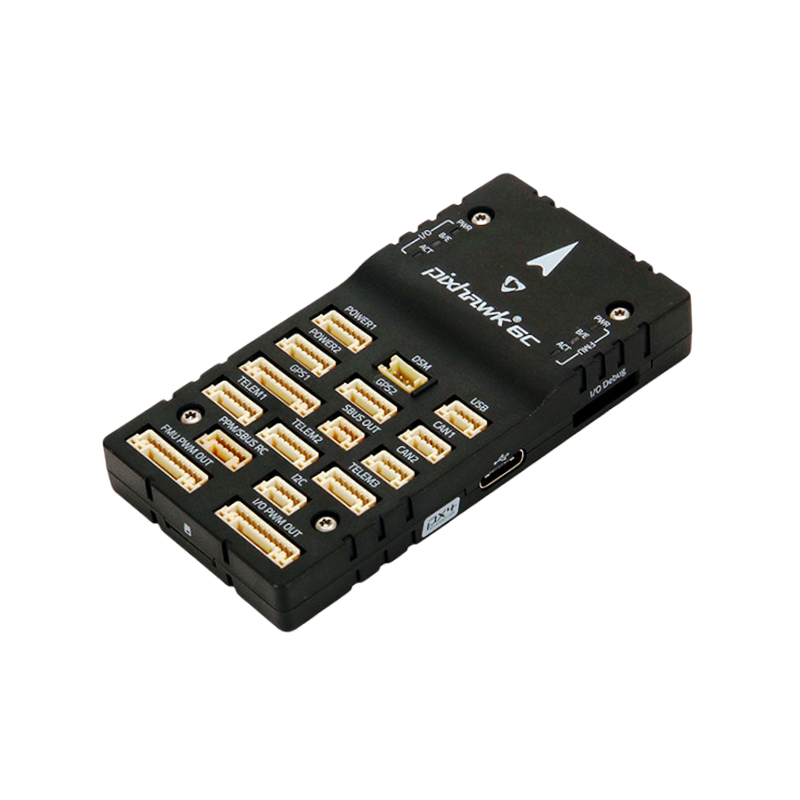
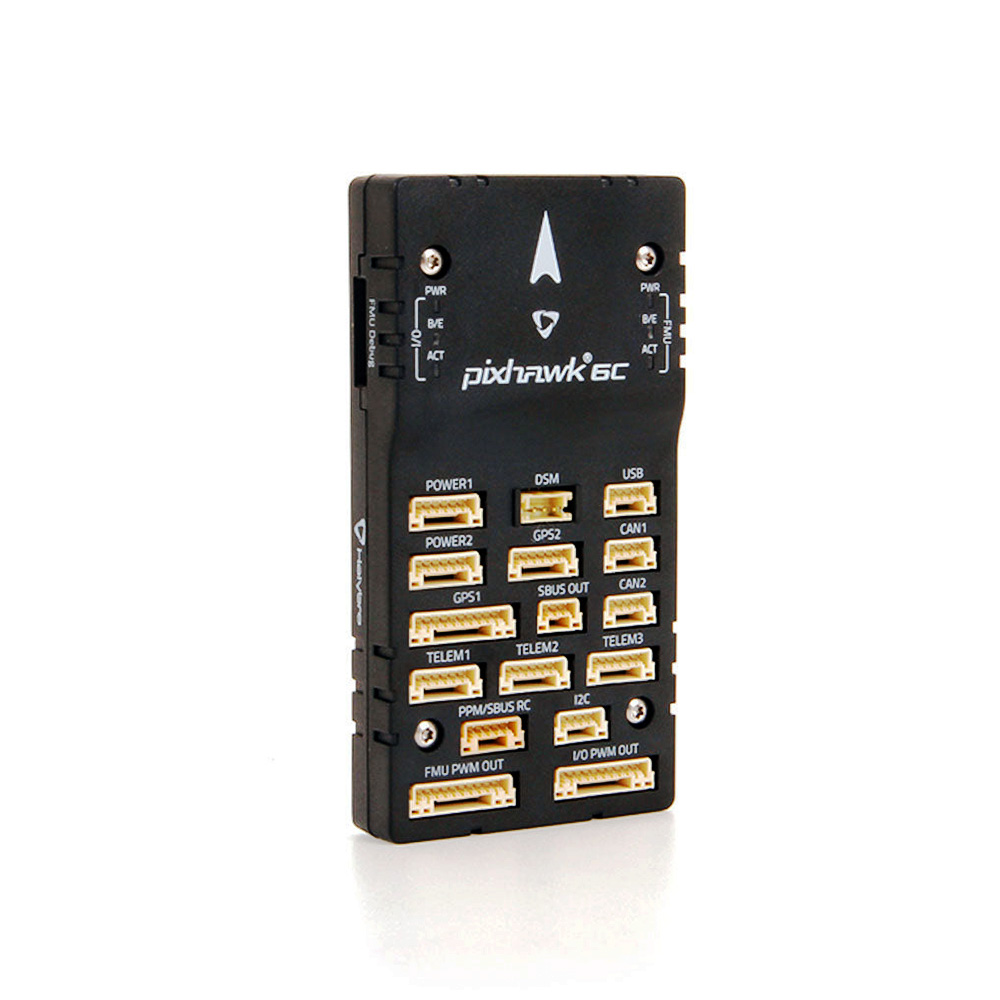
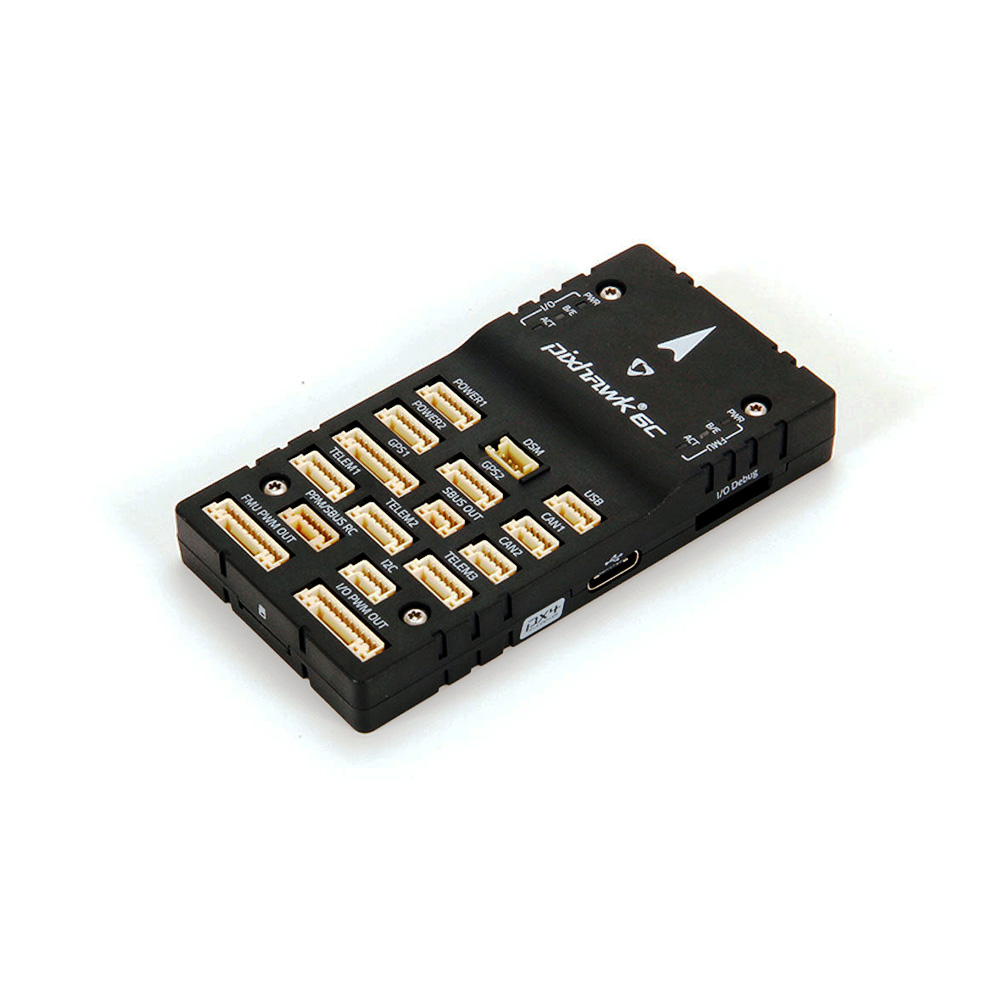
Holybro Pixhawk 6C Flight Controller (Plastic Case)

₹27,879.00 (Inclusive of all taxes)
Out of Stock

The Holybro Pixhawk 6C is an advanced flight controller based on the Pixhawk FMUv6C open standard, featuring a powerful STM32H743 processor and redundant IMUs for reliable autonomous vehicle control in academic, commercial, and research applications.

Features

  • STM32H743 Arm Cortex-M7 processor running at up to 480 MHz with 2MB Flash and 1MB RAM.
  • Redundant IMU system featuring Bosch BMI055 and InvenSense ICM-42688-P sensors for enhanced reliability.
  • Integrated vibration isolation system to filter high-frequency noise and ensure accurate sensor readings.
  • Pre-installed with PX4 Autopilot® firmware for versatile autonomous vehicle development.
  • Cost-effective design with a low-profile plastic case, suitable for a wide range of UAV applications.

Out of stock

Description

The Pixhawk 6C represents the latest evolution in the Pixhawk flight controller lineage, adhering to the FMUv6C open hardware and connector standard. Its core is built around the high-performance STM32H743 microcontroller, which provides the computational power necessary for complex autonomous navigation algorithms and real-time control tasks. This processing capability is paired with a carefully selected sensor suite designed for robustness and precision.

Engineered for reliability, the controller incorporates a redundant inertial measurement unit (IMU) configuration and an active vibration damping system. This combination ensures stable flight performance even in environments with significant mechanical noise. The design prioritizes a high-value build, delivering professional-grade features in a form factor accessible to developers, researchers, and commercial operators.

Key Features

  • High-performance STM32H743 32-bit Arm Cortex-M7 core operating at 480 MHz.
  • Dual redundant IMUs (BMI055 & ICM-42688-P) with temperature-controlled heating resistors for optimal performance.
  • Integrated vibration isolation platform to minimize sensor noise from motor and propeller harmonics.
  • Comprehensive sensor suite includes IST8310 magnetometer and MS5611 barometer for full attitude and altitude reference.
  • Based on the Pixhawk FMUv6C open standard, ensuring broad hardware and software compatibility.
  • Pre-loaded with the open-source PX4 Autopilot firmware for immediate deployment.
  • Low-profile plastic enclosure designed for easy integration into various airframe types.

Applications

  • Academic and university research platforms for autonomous systems development.
  • Commercial drone platforms for mapping, surveying, and inspection services.
  • Startup prototyping for custom UAV and robotic vehicle applications.
  • Advanced multirotor and fixed-wing autonomous flight projects.
  • Educational tool for professors and students in robotics and aerospace engineering.

Technical Specifications

ProcessorSTM32H743 (Arm Cortex-M7), 480 MHz
Flash Memory2 MB
RAM1 MB
Accelerometer/Gyroscope 1InvenSense ICM-42688-P
Accelerometer/Gyroscope 2Bosch BMI055
MagnetometerIST8310
BarometerMS5611
Input Voltage6V
FirmwarePX4 Autopilot®
Form FactorPixhawk FMUv6C Standard
CasePlastic

Frequently Asked Questions

What is the input voltage range for the Pixhawk 6C?

The Pixhawk 6C is designed for a 6V input. It is critical to provide clean, regulated 6V power, typically from a dedicated power module or a BEC, to ensure stable operation of the processor and sensors.

What are the benefits of the redundant IMU system?

The dual IMU system, using sensors from Bosch and InvenSense, provides hardware redundancy. If one IMU experiences a fault or provides noisy data, the flight controller can seamlessly switch to the other, significantly increasing the overall reliability and safety of the autonomous vehicle.

How does the integrated vibration isolation system work?

The controller features a mechanically damped mounting system within its plastic case. This system filters out high-frequency vibrations generated by motors and propellers before they reach the sensitive IMU sensors, leading to cleaner data, more accurate state estimation, and improved flight performance.

Is the Pixhawk 6C compatible with ArduPilot firmware?

While the Pixhawk 6C ships with PX4 Autopilot pre-installed, it is based on the open FMUv6C standard. This means it is also compatible with ArduPilot firmware, allowing developers to choose the open-source autopilot stack that best fits their project requirements.

Package Includes

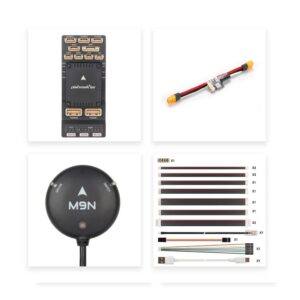
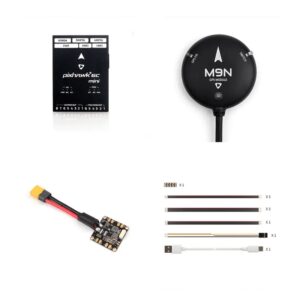
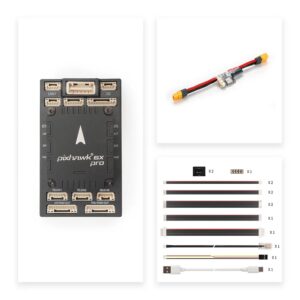
  • 1 x Holybro Pixhawk 6C Flight Controller (Plastic Case)

Additional Information

Weight 0.2 kg
Dimensions 16 × 13 × 5 cm