SKU: DRFC-1794
📋 GST Invoice Available

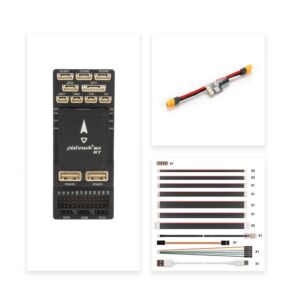
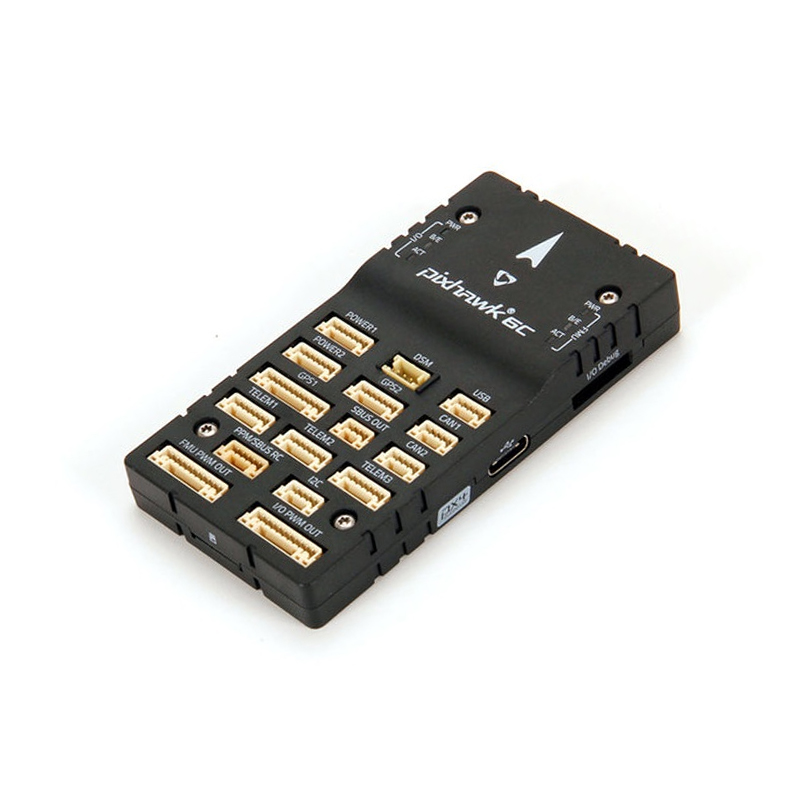
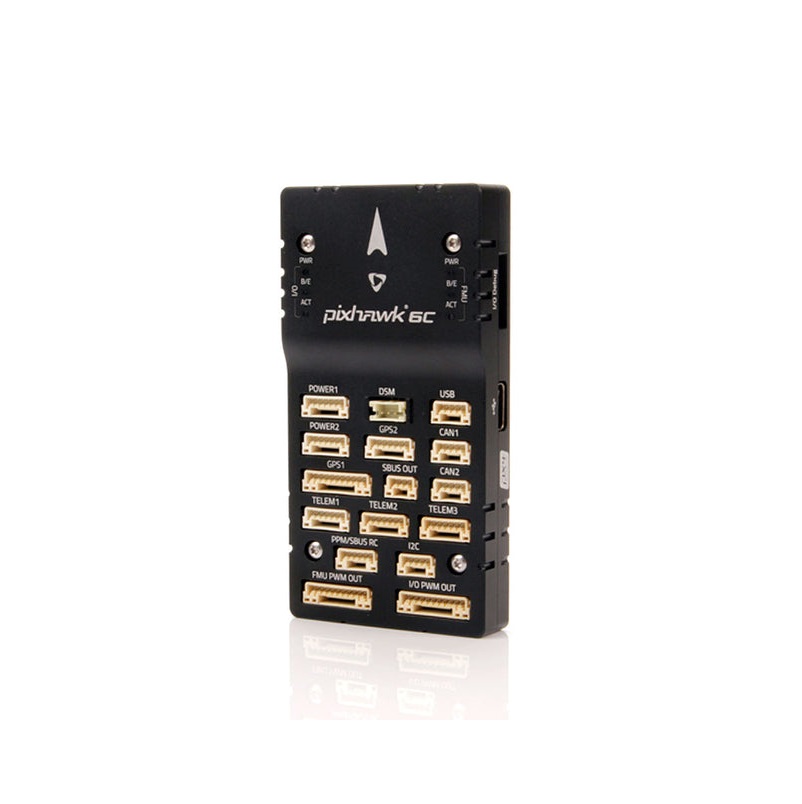
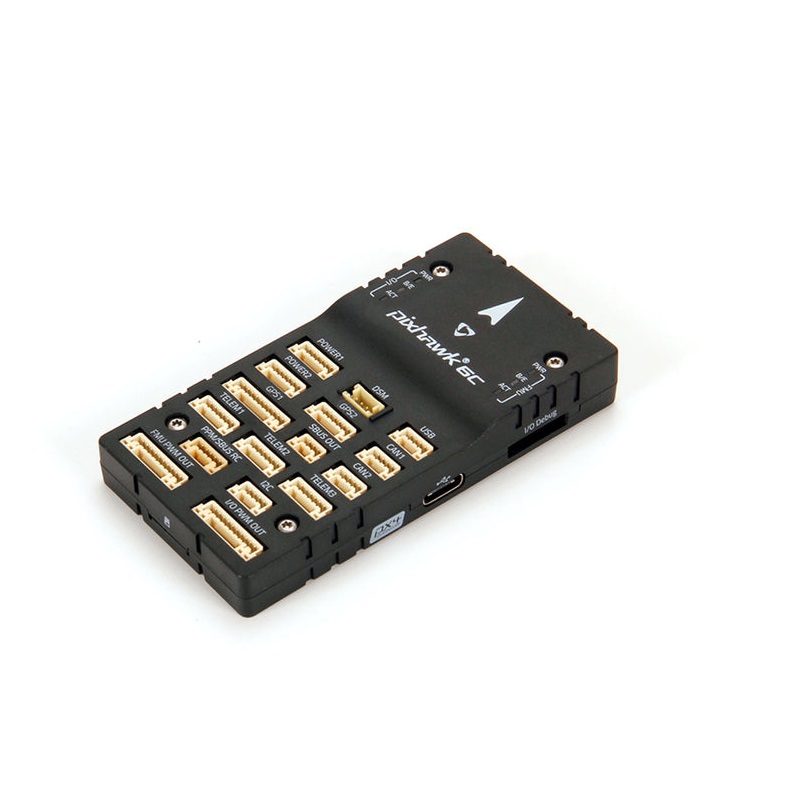
Holybro Pixhawk 6C Aluminium Body - NO GPS NO Power Module

₹35,699.00 (Inclusive of all taxes)
Out of Stock

The Holybro Pixhawk 6C is a high-performance flight controller based on the Pixhawk FMUv6C open standard, featuring an STM32H743 processor and redundant Bosch & InvenSense IMUs. It is pre-loaded with PX4 Autopilot firmware and is designed for advanced autonomous UAV applications in academic and commercial environments.

Features

  • STM32H743 Arm Cortex-M7 processor running at 480 MHz with 2MB flash and 1MB RAM.
  • Redundant inertial measurement units (IMUs) from Bosch and InvenSense for enhanced reliability.
  • Integrated vibration isolation system and temperature-controlled IMUs for accurate sensor readings.
  • Low-profile aluminum CNC case for durability and a professional form factor.
  • Pre-installed PX4 Autopilot firmware, compatible with a wide range of autonomous vehicles.

Out of stock

Description

The Pixhawk 6C represents the latest evolution in the Pixhawk flight controller lineage, built to the FMUv6C open hardware and connector standard. Its core computational power is delivered by the STMicroelectronics STM32H743 microcontroller, which enables the execution of complex flight algorithms and models essential for advanced autonomous operations. The board’s design emphasizes sensor integrity and system robustness.

Critical to its performance is the suite of high-performance, low-noise sensors, including accelerometers, gyroscopes, a magnetometer, and a barometer. The dual IMU configuration provides hardware redundancy, while the active temperature control and mechanical vibration damping ensure these sensors operate within optimal parameters, significantly reducing noise and improving overall flight stability and accuracy.

Key Features

  • High-Performance Compute: Features an STM32H743 (Cortex-M7) main processor and a dedicated STM32F103 (Cortex-M3) I/O processor for efficient task handling.
  • Redundant Sensor Suite: Equipped with dual ICM-42688-P and BMI055 IMUs, an IST8310 magnetometer, and an MS5611 barometer for reliable state estimation.
  • Advanced Vibration & Thermal Management: Integrated isolation system filters high-frequency vibrations, and onboard heating resistors maintain optimal IMU temperature.
  • Robust Power Design: Accepts a wide input voltage range on the servo rail (0-36V) and includes dedicated 5V USB power input for bench testing.
  • Professional Aluminum Enclosure: Machined aluminum case provides superior EMI shielding, heat dissipation, and physical protection compared to plastic variants.
  • PX4 Autopilot Ecosystem: Comes pre-installed with the open-source PX4 flight stack, offering full compatibility with ArduPilot and extensive community support.

Applications

  • Advanced academic and university research platforms for autonomous UAV development.
  • Commercial drone prototypes and production vehicles for surveying, mapping, and inspection.
  • Heavy-lift and industrial-grade multirotor platforms requiring robust autopilot capabilities.
  • Fixed-wing and VTOL (Vertical Take-Off and Landing) autonomous aircraft projects.
  • Integration into custom robotic and unmanned ground/sea vehicle control systems.

Technical Specifications

Main FMU ProcessorSTM32H743 32 Bit Arm Cortex-M7, 480MHz, 2MB Flash, 1MB SRAM
IO ProcessorSTM32F103 32 Bit Arm Cortex-M3, 72MHz, 64KB SRAM
Accelerometer/GyroscopeICM-42688-P & BMI055 (Redundant)
MagnetometerIST8310
BarometerMS5611
Input Voltage (VCC)6V
USB Power Input4.75 - 5.25V
Servo Rail Input0 - 36V
Dimensions (L x W x H)84.8 x 44 x 12.4 mm
Weight59.3 g

Frequently Asked Questions

What is included in this 'NO GPS NO Power Module' version of the Pixhawk 6C?

This listing includes only the Holybro Pixhawk 6C flight controller unit housed in the aluminum CNC case. It does not include a GPS module, a power module (for voltage/current sensing), or any cabling. You will need to source these components separately to complete a functional autopilot system.

What is the main advantage of the redundant IMU setup on the Pixhawk 6C?

The dual ICM-42688-P and BMI055 IMUs provide hardware redundancy, which increases system reliability. If one IMU fails or provides anomalous data due to a fault or extreme vibration, the flight controller can seamlessly switch to the other, maintaining stable flight and preventing a crash. This is critical for commercial and research applications.

What software does the Pixhawk 6C run, and how do I configure it?

The Pixhawk 6C comes pre-installed with the PX4 Autopilot firmware. You configure and tune it using the QGroundControl ground station software, which is compatible with Windows, macOS, and Linux. The board is also fully compatible with the ArduPilot firmware if you choose to flash it, offering flexibility for different project requirements.

What are the power input requirements and connections for this flight controller?

The board has multiple power inputs. The primary flight system power (6V) is supplied via the main connector. A separate servo rail accepts 0-36V for powering servos and peripherals. For bench testing without a flight battery, you can power the board via its micro-USB port, which accepts 4.75-5.25V. A dedicated power module is required for proper battery voltage and current monitoring.

Package Includes

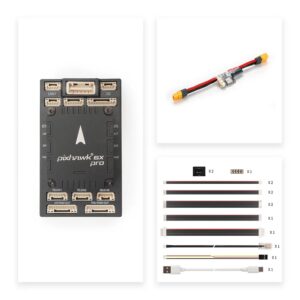
  • 1 x Holybro Pixhawk 6C Flight Controller (Aluminium Body)

Additional Information

Weight 0.0593 kg
Dimensions 8.48 × 4.4 × 1.24 cm