SKU: DRFC-1884
📋 GST Invoice Available

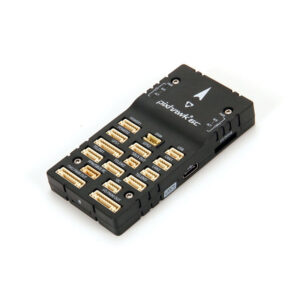
Holybro Pixhawk 5X Standard Set v2B+M9N GPS

₹46,999.00 (Inclusive of all taxes)
Out of Stock

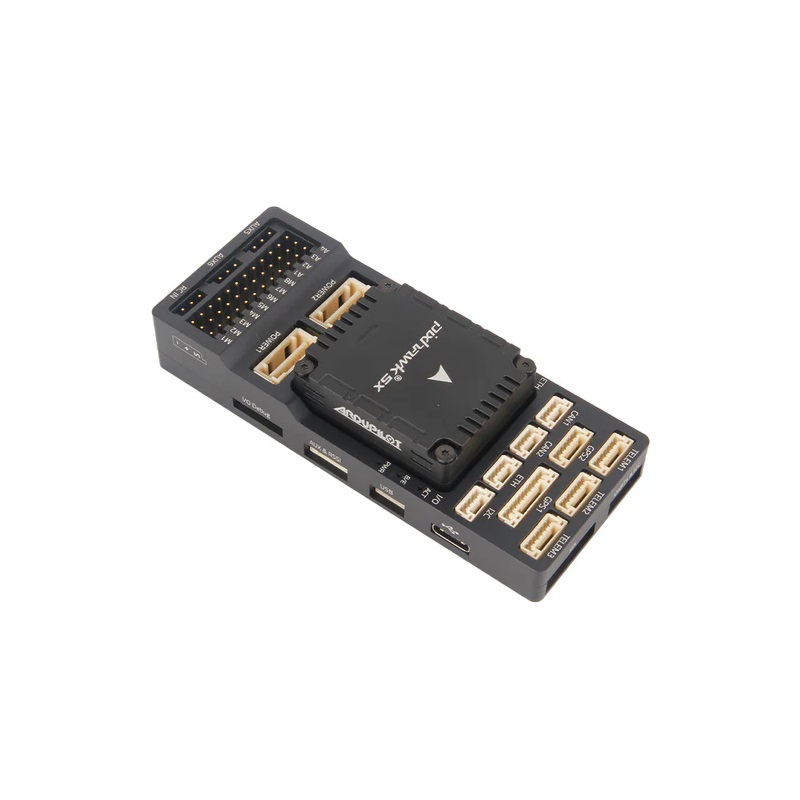
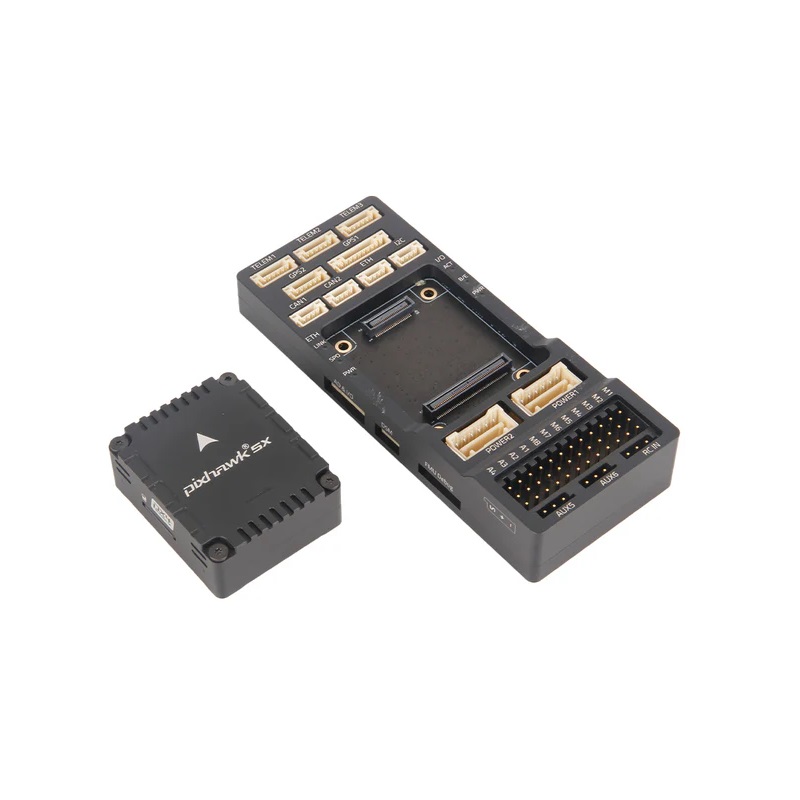
The Holybro Pixhawk 5X Standard Set is a high-performance, triple-redundant flight controller designed for demanding autonomous UAV and robotic applications. It features an STM32F7 processor, triple IMUs, dual barometers, and is pre-configured for PX4 and ArduPilot firmware.

Features

  • STM32F7 32-bit Arm Cortex-M7 processor with 2MB Flash and 512KB RAM for high-speed flight control.
  • Triple-redundant IMU and dual barometer sensors on isolated buses for maximum reliability.
  • Integrated vibration isolation and temperature-controlled IMU domains for precise sensor data.
  • Ethernet interface (LAN8742AI-CZ-TR) for high-speed mission computer and companion integration.
  • Compatible with PX4 (pre-installed) and ArduPilot open-source autopilot firmware.

Out of stock

Description

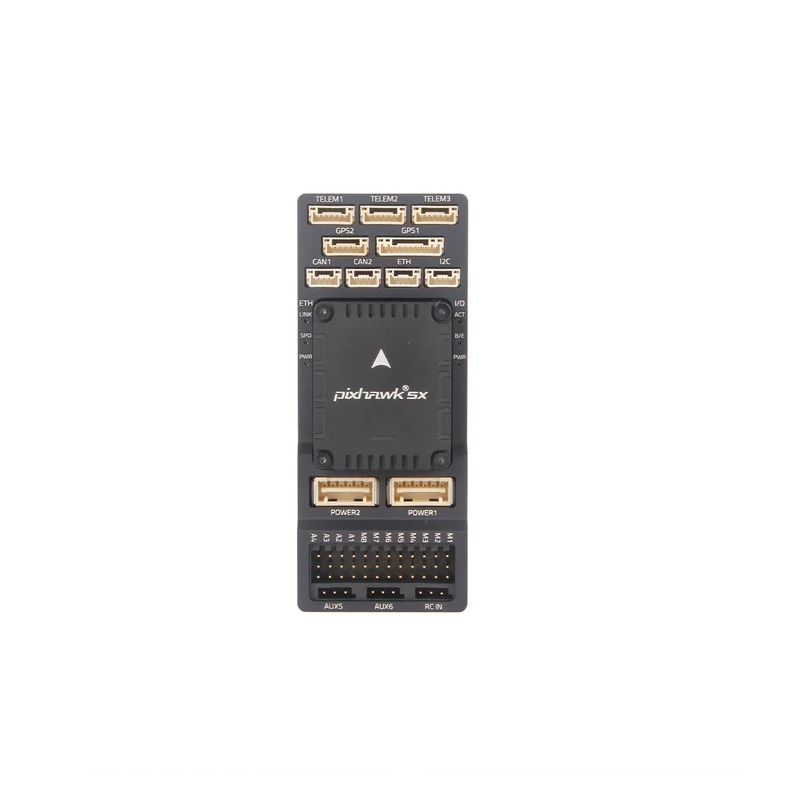
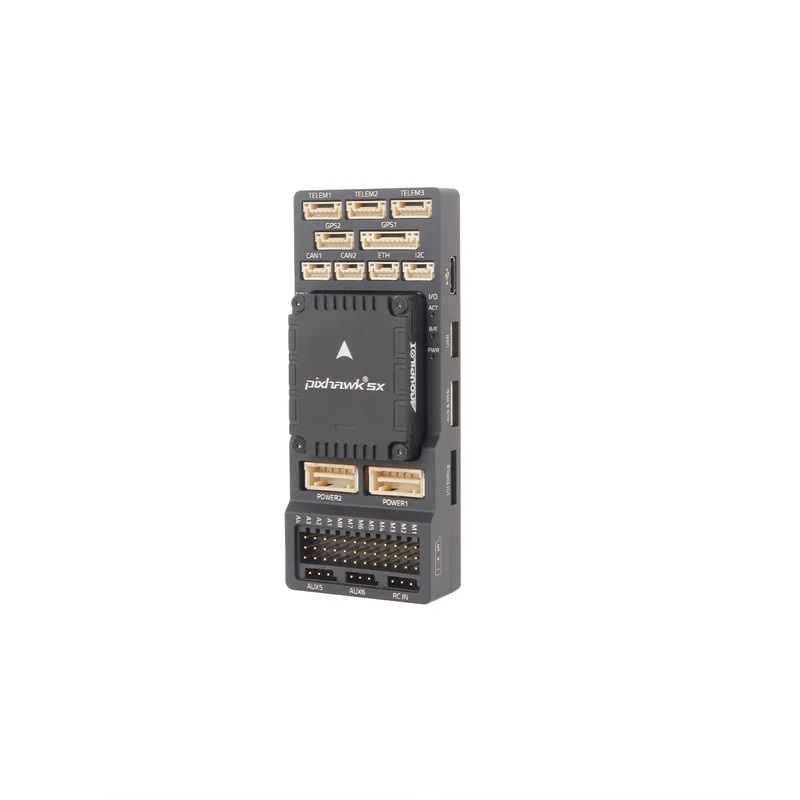
The Pixhawk 5X is engineered to the Pixhawk FMUv5X and Pixhawk Autopilot Bus standards, providing a modular and flexible foundation for advanced autonomous systems. Its separated FMU, IMU, and baseboard architecture allows for customizable configurations and easy integration of additional payloads and sensors.

Power management is handled by independent LDOs and dual SMBus battery monitoring, supporting a wide input range from the servo rail (0-36V) and a regulated 6V system input. The controller’s design prioritizes operational integrity in harsh environments, making it suitable for commercial, industrial, and academic research applications.

Key Features

  • Modular design with 100-pin and 50-pin Pixhawk Autopilot Bus connectors for system expansion.
  • Triple physically isolated sensor domains with separate power and data buses for true hardware redundancy.
  • Onboard heating resistors maintain optimal IMU operating temperature for consistent performance.
  • Advanced vibration damping system filters high-frequency noise to ensure accurate inertial measurement.
  • Automated sensor calibration compensates for signal variance and thermal drift.
  • Robust power system with independent voltage regulation and comprehensive battery monitoring.
  • High-speed SPI5 bus and Ethernet port enable seamless data transfer to companion computers.

Applications

  • High-reliancy autonomous drones for commercial inspection, mapping, and delivery services.
  • Research and development platforms for academic and corporate UAV/robotics projects.
  • Heavy-lift and industrial-grade multirotors requiring robust, redundant flight control.
  • Ground and maritime autonomous robotic systems built on the Pixhawk ecosystem.
  • Prototyping and educational platforms for advanced autopilot and robotics coursework.

Technical Specifications

ProcessorSTM32F7 (STM32H743), 32-bit Arm Cortex-M7, 480 MHz, 2MB Flash, 512KB RAM
I/O ProcessorSTM32F100
IMU 1 (Hard Mounted)ICM-20649 Accelerometer/Gyroscope
IMU 2 (Soft Mounted)ICM-42688P Accelerometer/Gyroscope
IMU 3 (Soft Mounted)ICM-20602 or BMI088 Accelerometer/Gyroscope
MagnetometerBMM150
Barometer2x BMP388
Voltage Input6V
USB Power Input4.75–5.25V
Servo Rail Input0–36V
Firmware CompatibilityPX4 (pre-installed), ArduPilot
Key InterfaceEthernet (LAN8742AI-CZ-TR), SPI5 Bus

Frequently Asked Questions

What is the input voltage range for the Pixhawk 5X servo rail?

The servo rail on the Pixhawk 5X accepts a wide input range of 0 to 36 volts. This is typically supplied via the included PM02D HV Power Module from your main flight battery (LiPo). The internal flight controller module itself is powered by a regulated 6V supply from the baseboard.

Does the Pixhawk 5X support both PX4 and ArduPilot firmware?

Yes, the Holybro Pixhawk 5X is fully compatible with both the PX4 and ArduPilot open-source autopilot stacks. The unit ships from the factory with PX4 firmware pre-installed, but you can flash ArduPilot using standard ground station software. Its design adheres to the Pixhawk FMUv5X standard, ensuring broad firmware support.

What is the purpose of the triple-redundant IMU design?

The triple-redundant IMU system provides critical fault tolerance. The three inertial measurement units (ICM-20649, ICM-42688P, and ICM-20602/BMI088) operate on physically isolated power and data buses. If one sensor fails or provides erroneous data, the flight controller's voting algorithms can seamlessly continue operation using the remaining healthy sensors, drastically increasing system reliability for commercial and industrial applications.

How do I connect a companion computer to the Pixhawk 5X?

The Pixhawk 5X features a dedicated Ethernet port (LAN8742AI-CZ-TR) for high-speed, low-latency communication with a companion computer (e.g., Raspberry Pi). This is the recommended primary link. Additionally, you can utilize the available serial ports (UARTs) over the Pixhawk Autopilot Bus connectors for traditional serial communication protocols like MAVLink.

Package Includes

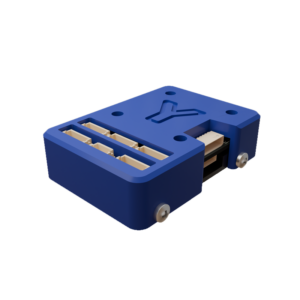
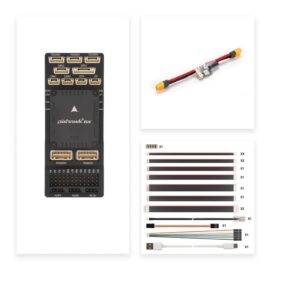
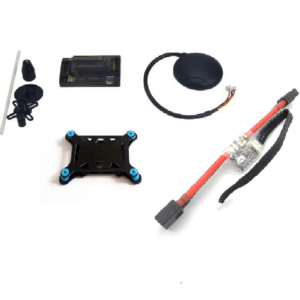
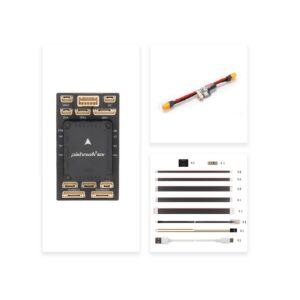
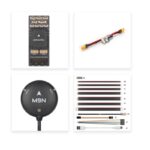
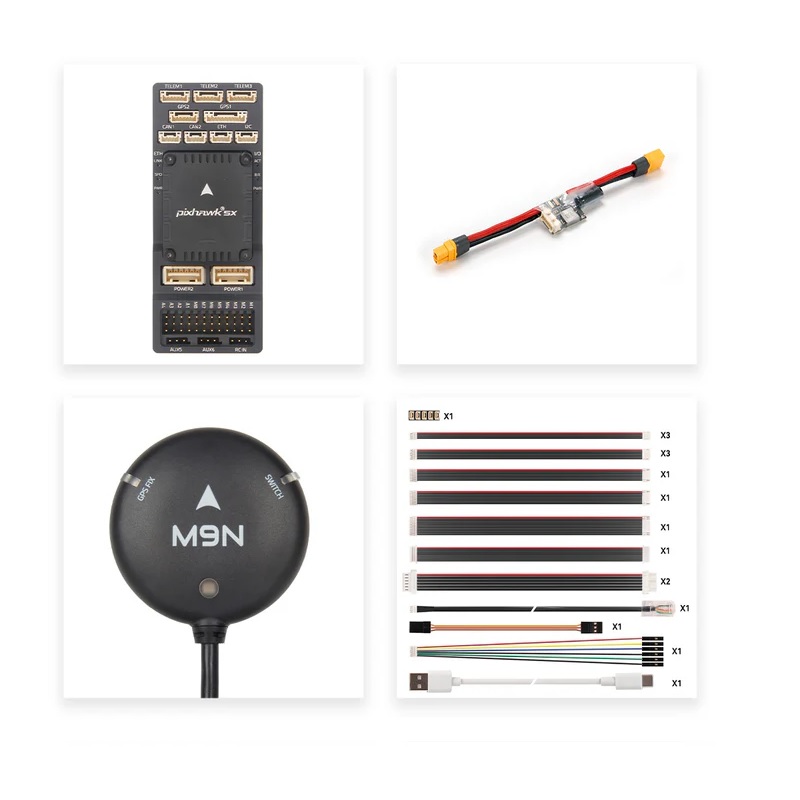
  • 1x Pixhawk 5X Flight Controller Module
  • 1x v2B or Mini Baseboard
  • 1x PM02D HV Power Module
  • 1x Cable Set
  • 1x M9N GPS Module

Additional Information

Weight 0.319 kg
Dimensions 10 × 15 × 7 cm