SKU: DRFC-1869
📋 GST Invoice Available

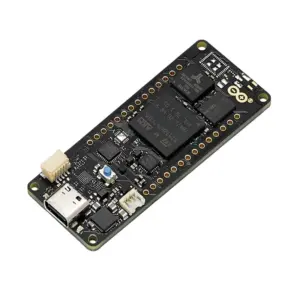
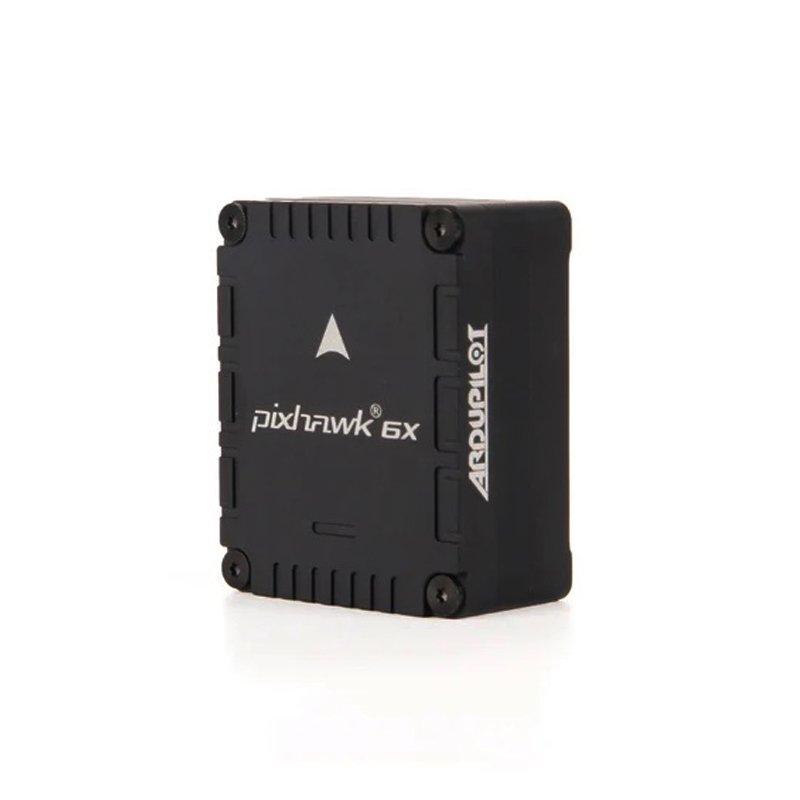
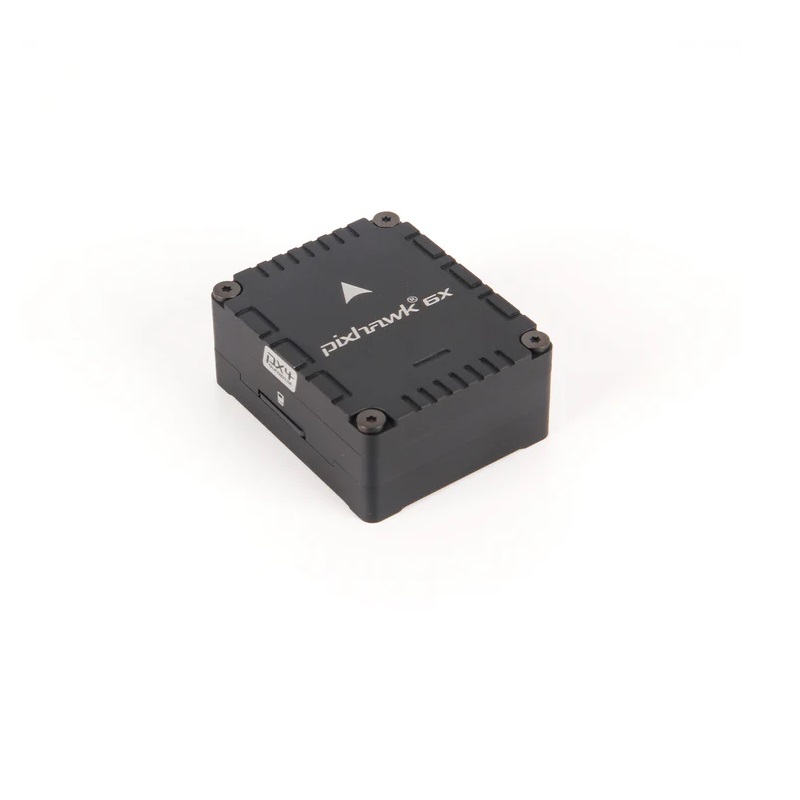
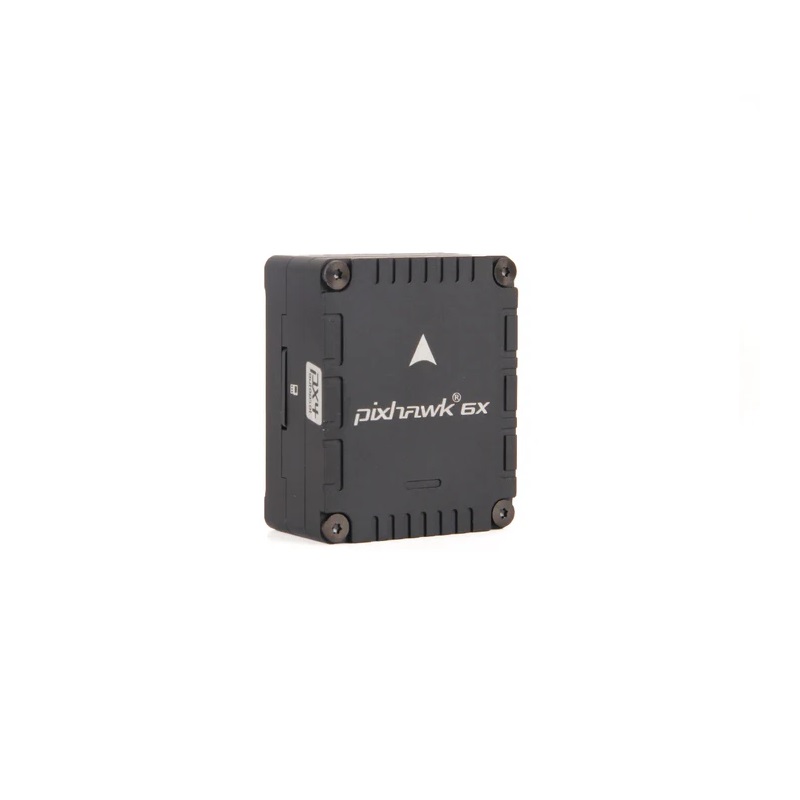
Holybro Pixhawk 6X (Rev8) - FC Module Only

₹14,843.00 (Inclusive of all taxes)
Out of Stock

The Holybro Pixhawk 6X (Rev8) is a high-reliability flight controller module featuring triple-redundant ICM-45686 IMUs with BalancedGyroâ„¢ technology and advanced vibration isolation. Powered by a 480 MHz STM32H753 processor, it supports Ethernet mission computer integration and is designed for demanding industrial, commercial, and autonomous UAV applications.

Features

  • Triple-redundant sensor suite with three ICM-45686 IMUs (±32g) and two barometers (ICP20100 & BMP388).
  • High-performance 480 MHz STM32H753 processor paired with an STM32F103 I/O co-processor.
  • Advanced vibration isolation system with durable materials for precise sensor readings.
  • Integrated Ethernet port for high-speed communication with mission computers.
  • Modular design with separate IMU, FMU, and Base systems using Pixhawk® Autopilot Bus connectors.

Out of stock

Description

The Pixhawk 6X (Rev8) flight controller module is engineered for maximum reliability in critical UAV operations. Its core architecture employs triple isolated redundancy domains, where three independent ICM-45686 inertial measurement units and dual barometric pressure sensors operate on separate power and data buses. This design ensures continuous operation even in the event of a single sensor or power domain failure.

Structural integrity is prioritized through a sophisticated vibration damping system that utilizes materials with a higher resonance frequency spectrum, effectively isolating the sensitive IMUs from frame and motor harmonics. The temperature-controlled IMU housing maintains optimal sensor operating conditions, while the integrated Ethernet interface enables low-latency data exchange with companion computers for complex autonomous missions.

Key Features

  • Triple Redundant IMUs: Three ICM-45686 sensors with BalancedGyroâ„¢ provide fault-tolerant attitude and acceleration data.
  • Dual Barometer & Compass: Features ICP20100 and BMP388 barometers alongside a BMM150 magnetometer for robust altitude and heading reference.
  • High-Speed Processing: STM32H753 main processor (480 MHz) handles complex flight algorithms, supported by an STM32F103 for I/O management.
  • Advanced Vibration Damping: Engineered isolation system minimizes high-frequency noise for accurate sensor feedback.
  • Mission Computer Ethernet: Transformerless 100BASE-TX Ethernet with 50 Ohm termination enables direct, high-bandwidth integration.
  • Flexible Power Architecture: Accepts 6V main input, 4.75–5.25V USB, and servo rail inputs from 0V to 36V.
  • Modular Connector System: Utilizes standard 100-pin and 50-pin Pixhawk® Autopilot Bus connectors for expandability.
  • Temperature-Regulated IMU Bay: Actively maintains IMUs at a consistent operational temperature for stable performance.

Applications

  • High-endurance mapping and surveying drones for precision geomatics.
  • Autonomous cargo and logistics UAVs requiring failsafe reliability.
  • Advanced agricultural drones for targeted spraying and crop monitoring.
  • Search and rescue (SAR) and surveillance platforms operating in challenging environments.
  • Custom robotic and autonomous vehicle systems for research and development.

Technical Specifications

Item TypeFlight Controller
ProcessorSTM32H753
I/O ProcessorSTM32F103
Accel/Gyro Sensors3x ICM-45686
Barometer SensorsICP20100 & BMP388
MagnetometerBMM150
Main Voltage Input6V
USB Power Input4.75–5.25V
Servo Rail Input0–36V
Shipping Weight0.1 kg
Shipping Dimensions10 x 8 x 5 cm

Frequently Asked Questions

What is the main power input voltage for the Pixhawk 6X?

The primary power input for the Pixhawk 6X flight controller module is 6V. It also accepts USB power within 4.75–5.25V and can handle servo rail inputs from 0V up to 36V, providing flexible integration with various power systems and peripherals.

How does the triple redundancy improve reliability?

Triple redundancy is implemented through three physically isolated sensor domains, each containing an ICM-45686 IMU. The flight stack continuously compares data from all three sensors, allowing it to identify and isolate a faulty unit in real-time. This architecture, combined with dual barometers, ensures continuous operation critical for commercial and industrial drone missions.

Can I connect a mission computer directly to the Pixhawk 6X?

Yes, the integrated 100BASE-TX Ethernet port enables direct, high-speed communication with a mission computer or companion processor. It uses transformerless operation with 50 Ohm termination resistors, facilitating low-latency data transfer for complex autonomous navigation, payload control, and real-time telemetry.

What firmware is compatible with the Pixhawk 6X?

The Pixhawk 6X is designed to be fully compatible with the PX4 Pro and ArduPilot open-source autopilot firmware ecosystems. Its standard Pixhawk® Autopilot Bus connectors and modular design ensure seamless integration with the extensive suite of drivers, estimators, and controllers available in these platforms.

Package Includes

  • 1 x Pixhawk 6X Flight Controller Module (Rev8)

Additional Information

Weight 0.1 kg
Dimensions 10 × 8 × 5 cm