SKU: SENS-2785
📋 GST Invoice Available

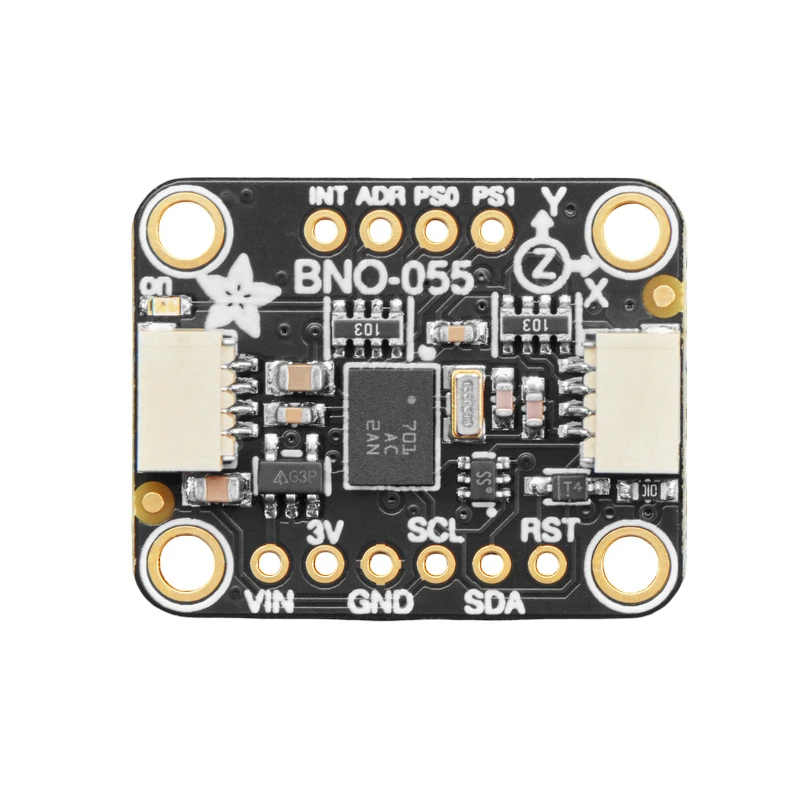
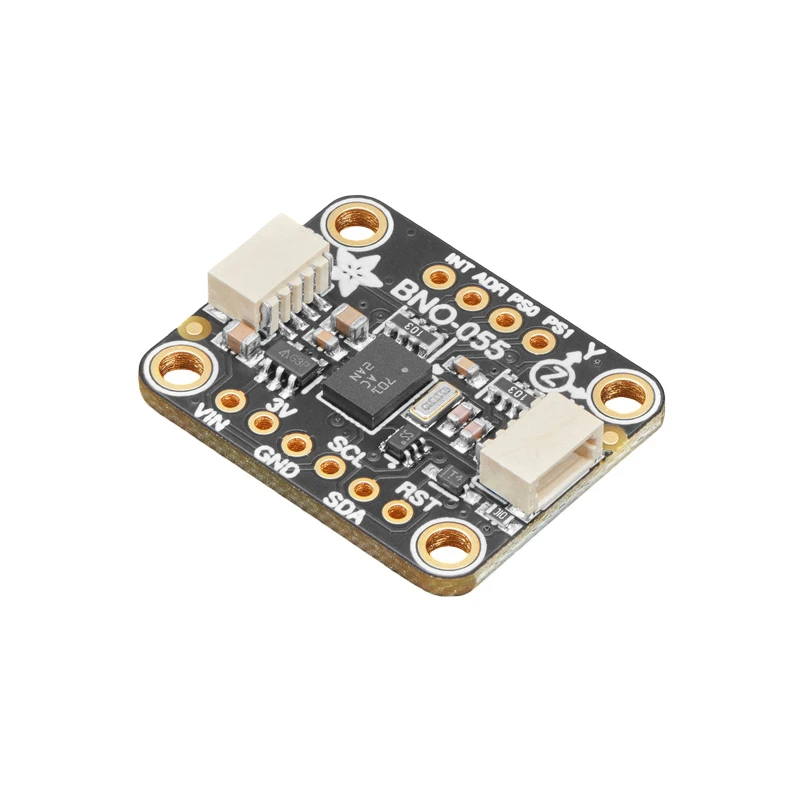
Adafruit BNO055 9-DOF Absolute Orientation IMU Fusion Breakout - STEMMA QT / Qwiic

₹4,619.00 (Inclusive of all taxes)
Out of Stock

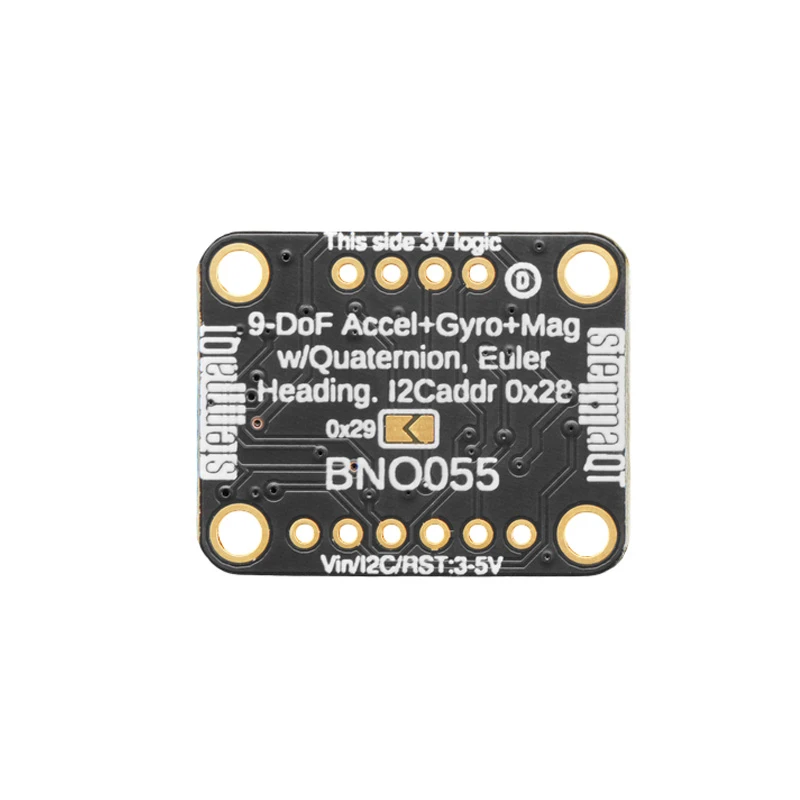
The Adafruit BNO055 breakout is a 9-DOF IMU integrating an accelerometer, gyroscope, and magnetometer with an onboard ARM Cortex-M0 processor for real-time sensor fusion. It provides Euler angles, quaternions, and raw data via I2C and is compatible with 3.3V/5V systems, Arduino, and CircuitPython.

Features

  • Integrated 9-DOF sensor fusion with onboard ARM Cortex-M0 processor.
  • Outputs Euler angles, quaternions, linear acceleration, and gravity Vector Technics at up to 100Hz.
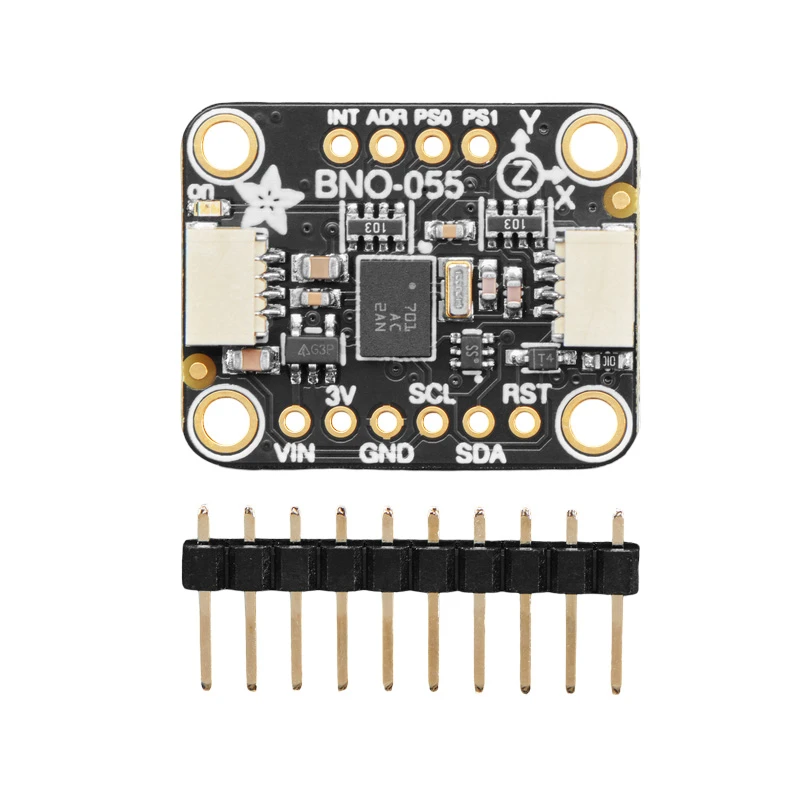
  • Plug-and-play connectivity via STEMMA QT / Qwiic connectors for solder-free I2C interfacing.
  • Wide 3.3V to 5V power supply compatibility for seamless integration with Arduino, Raspberry Pi, and other microcontrollers.
  • Comprehensive Arduino and CircuitPython library support for rapid prototyping and development.

Out of stock

Description

The Adafruit BNO055 Absolute Orientation IMU Fusion Breakout combines a triaxial accelerometer, gyroscope, and magnetometer with a dedicated ARM Cortex-M0 microcontroller. This integrated processor executes sophisticated sensor fusion algorithms, fusing data from all three sensors to compute stable and drift-corrected orientation outputs such as Euler angles (roll, pitch, yaw) and quaternions. This eliminates the need for developers to implement complex filtering and calibration routines, providing accurate spatial awareness directly from the module.

Communication is handled via a standard I2C interface, with the included STEMMA QT / Qwiic connectors enabling a solderless, plug-and-play connection to compatible development boards. The module operates from a wide 3.3V to 5V DC supply, making it directly compatible with most microcontroller platforms. Its compact PCB design includes mounting holes for secure installation in robotics, drones, or wearable motion-tracking systems.

Key Features

  • Onboard Sensor Fusion: ARM Cortex-M0 processor runs real-time fusion algorithms, delivering calibrated Euler angles and quaternion data without host MCU overhead.
  • Multi-Data Output: Provides absolute orientation, 3-axis angular velocity, linear acceleration, magnetic field strength, and gravity Vector Technics at configurable data rates.
  • Plug-and-Play Interface: STEMMA QT / Qwiic 4-pin JST connectors allow for tool-free, daisy-chainable I2C connections, speeding up prototyping.
  • Broad Voltage Compatibility: Supports 3.3V and 5V logic levels, ensuring seamless operation with Arduino, Raspberry Pi, ESP32, and other popular development boards.
  • Comprehensive Software Support: Officially supported by Adafruit's well-documented Arduino and CircuitPython libraries for easy integration and example code.
  • Compact & Mountable Design: Small 25mm x 20mm footprint with four corner mounting holes for secure mechanical fixation in final applications.

Applications

  • Robotics navigation and balancing systems for accurate platform orientation and tilt compensation.
  • Drone and UAV flight controllers requiring stable attitude and heading reference systems (AHRS).
  • Virtual Reality (VR) and Augmented Reality (AR) headset tracking for precise motion capture.
  • Wearable motion analysis devices for sports science, physiotherapy, and gesture recognition.
  • Industrial equipment monitoring for vibration analysis and machinery alignment.

Technical Specifications

ModelBNO055
Sensor Type9-DOF (Accelerometer, Gyroscope, Magnetometer)
ProcessorARM Cortex-M0
Communication InterfaceI2C
Power Supply3.3V - 5V DC
Connector TypeSTEMMA QT / Qwiic (4-pin JST)
Absolute Orientation Output (Euler)Up to 100Hz
Absolute Orientation Output (Quaternion)Up to 100Hz
Angular Velocity (Gyroscope)3-axis, up to 100Hz
Acceleration Vector Technics3-axis, up to 100Hz
Magnetic Field Strength3-axis, up to 20Hz
Linear Acceleration3-axis, up to 100Hz
Gravity Vector Technics3-axis, up to 100Hz
Temperature Output1 Hz
Dimensions (Board)25mm x 20mm x 5mm
Weight2g

Frequently Asked Questions

What is the primary advantage of the BNO055's onboard ARM Cortex-M0 processor?

The integrated ARM Cortex-M0 processor handles all complex sensor fusion algorithms in real-time. This means it fuses data from the accelerometer, gyroscope, and magnetometer internally, outputting stable, drift-corrected orientation data like Euler angles and quaternions directly. This offloads significant computational burden from your main microcontroller, simplifying code and improving system performance.

How do I connect this breakout to my microcontroller without soldering?

The board features a 4-pin STEMMA QT / Qwiic JST connector, which is a plug-and-play standard for I2C. Simply use a compatible STEMMA QT cable to connect the board's connector to a matching port on a host board like an Adafruit QT Py or SparkFun Qwiic shield. This provides power, ground, SDA, and SCL connections instantly, with no soldering required.

What is the difference between the Euler angle and quaternion outputs?

Euler angles (roll, pitch, yaw) describe orientation using three sequential rotations around specific axes, which is intuitive but can suffer from a singularity known as gimbal lock. Quaternions use a four-dimensional representation that avoids gimbal lock and provides smoother interpolation, making them preferable for advanced 3D graphics, robotics control, and motion filtering. The BNO055 provides both formats simultaneously.

Can I use this sensor with both 3.3V and 5V Arduino boards?

Yes. The BNO055 breakout is designed with logic level shifting, allowing it to operate from a power supply between 3.3V and 5V DC. The I2C communication lines are also tolerant of both voltage levels. You can power it directly from the 5V or 3.3V pin of an Arduino Uno, Mega, Leonardo, or a 3.3V board like an ESP32 or Raspberry Pi without risk of damage.

Package Includes

  • 1x Adafruit BNO055 9-DOF IMU Fusion Breakout Board
  • 1x Header Pin Strip (for optional soldered connection)

Additional Information

Weight 0.002 kg
Dimensions 2 × 2.5 × 0.5 cm