SKU: IOWC-0213
📋 GST Invoice Available

Intel Intel RealSense D435if Depth Camera w/ IMU & IR Filter

₹49,269.00 (Inclusive of all taxes)
Out of Stock

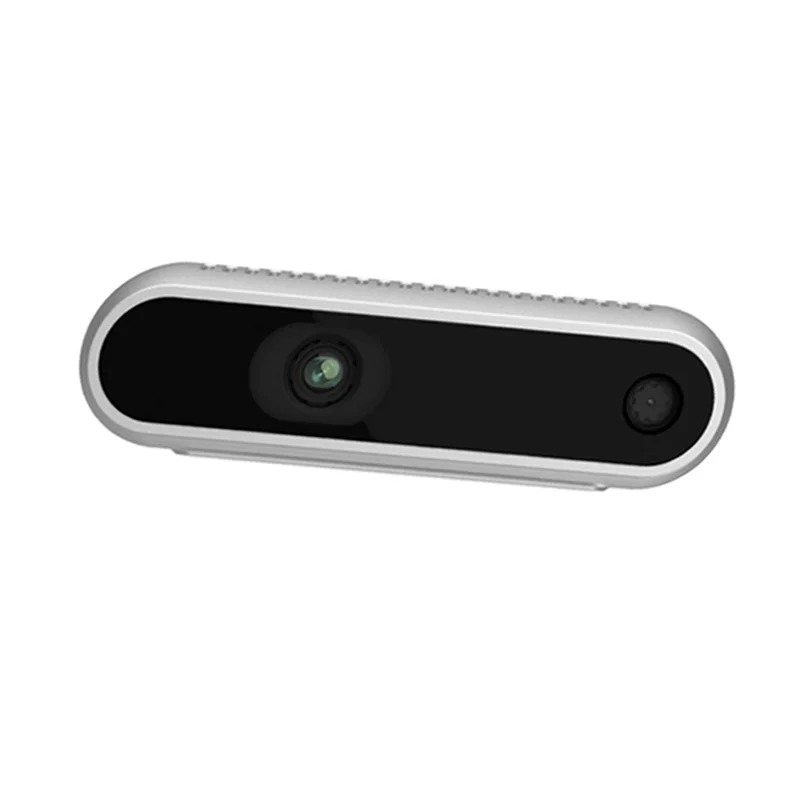
The Intel Intel RealSense D435if is a USB-powered stereo depth camera featuring an integrated IMU, a 750nm IR pass filter, and a global shutter, designed for high-speed depth perception in robotics, AR/VR, and 3D scanning applications.

Features

  • Stereo depth sensing with integrated IMU for motion-aware depth data fusion in dynamic environments.
  • Features a 750nm IR pass filter factory-installed to eliminate false object detection from light reflections.
  • Wide 87° x 58° depth FOV with global shutter supports up to 90 fps for high-speed applications.
  • Powered by the Intel Intel RealSense Vision Processor D4 for real-time depth computation via USB-C 3.1.
  • Includes active IR projector for robust depth data in low-light or textureless scenes.

Out of stock

Description

The Intel Intel RealSense D435if depth camera builds upon the D400 series by integrating a 6-DoF Inertial Measurement Unit (IMU) directly with the stereo vision system. This fusion allows applications to refine depth perception dynamically, compensating for camera motion—a critical feature for autonomous robots, drones, and augmented reality systems. The camera employs a pair of depth sensors with a global shutter and a dedicated RGB sensor, all processed by the 28nm Intel RealSense D4 vision processor.

Its key differentiator is the factory-applied 750nm near-infrared filter over the lenses, which resolves issues with repetitive patterns and specular reflections, providing reliable out-of-the-box performance. The active IR projector illuminates scenes to ensure consistent depth data quality, even in environments with poor ambient lighting or low texture. Data from the IMU is hardware-synchronized and time-stamped with depth frames, enabling precise sensor fusion for robotic navigation and SLAM algorithms.

Key Features

  • Motion-Enhanced Depth: Integrated IMU provides 6-axis motion data time-synced to depth frames for dynamic scene understanding.
  • Reflection-Resistant Imaging: Factory-fitted 750nm IR pass filter eliminates false depth readings from ambient light reflections and repetitive patterns.
  • High-Speed Global Shutter: Enables capture of fast-moving objects without rolling shutter distortion at frame rates up to 90 fps.
  • Real-Time Depth Processing: Onboard Intel Intel RealSense D4 vision processor handles disparity calculation, offloading host CPU.
  • Active IR Illumination: Built-in IR projector ensures reliable depth data in low-light or featureless environments.
  • Cross-Platform SDK: Fully supported by the open-source Intel Intel RealSense SDK 2.0 for Windows, Linux, and macOS.
  • Wide Field of View: 87° x 58° depth FOV provides expansive scene coverage for navigation and mapping.
  • USB-C Power & Data: Single USB-C 3.1 Gen 1 cable provides both power and high-bandwidth data transfer.

Applications

  • Autonomous Mobile Robots (AMRs) and drones for navigation, obstacle avoidance, and SLAM.
  • Augmented and Virtual Reality (AR/VR) systems for environment mapping and gesture recognition.
  • 3D scanning and digitization for manufacturing, logistics, and cultural heritage.
  • Industrial automation and robotic vision for bin picking, inspection, and measurement.
  • Research and development in computer vision, robotics, and human-machine interaction.

Technical Specifications

Depth TechnologyStereo Vision with Active IR Projector
IMUIntegrated 6-DoF Inertial Measurement Unit
Depth Field of View87° × 58° (±3°)
Depth Range0.3 m to 3 m
Depth Accuracy<2% at 2 m
Max Depth Frame RateUp to 90 fps
RGB Sensor2 MP (1920 × 1080)
Vision ProcessorIntel Intel RealSense D4 with IMU
InterfaceUSB-C 3.1 Gen 1
Operating PowerUSB Powered
Dimensions (LxWxH)90 mm × 25.8 mm × 25 mm
Filter750 nm Near-Infrared Pass Filter

Frequently Asked Questions

What software is needed to use the Intel RealSense D435if camera?

The camera is supported by the Intel Intel RealSense SDK 2.0 (librealsense), an open-source, cross-platform library available for Windows, Linux, and macOS. You'll need to install the SDK and its dependencies to access depth streams, RGB video, and synchronized IMU data through provided APIs or viewer tools. For robotics, frameworks like ROS have dedicated Intel RealSense wrappers for easy integration into navigation and perception stacks.

How does the integrated IMU improve depth sensing performance?

The onboard 6-DoF IMU provides accelerometer and gyroscope data that is hardware-synchronized and time-stamped with each depth frame. This allows algorithms to fuse motion data with visual depth, correcting for rapid camera movements or vibrations. This is crucial for applications like drone navigation or handheld scanning, where pure visual odometry might fail during fast motion or featureless scenes, resulting in more robust and accurate pose estimation.

What is the purpose of the 750nm IR pass filter on the D435if?

The factory-installed 750nm infrared pass filter blocks ambient visible light while allowing the camera's own active IR projector light to pass. This eliminates false depth readings caused by reflections from shiny surfaces or repetitive patterns like checkerboards in the environment. It ensures reliable, out-of-the-box depth data in a wider range of lighting conditions without requiring external calibration or software workarounds.

What are the power and connectivity requirements for the D435if?

The D435if is powered and transmits data through a single USB-C 3.1 Gen 1 (USB 3.0) cable. It requires a USB port capable of delivering sufficient power, typically from a host PC or a powered USB hub. For reliable operation at full frame rate and resolution, a high-bandwidth USB 3.0 connection is mandatory; USB 2.0 ports will limit performance and may not provide adequate power for all functions including the IR projector.

Package Includes

  • 1 x Intel Intel RealSense D435if Depth Camera

Additional Information

Weight 0.42 kg
Dimensions 9 × 2.58 × 2.5 cm