SKU: DRFC-1873
📋 GST Invoice Available

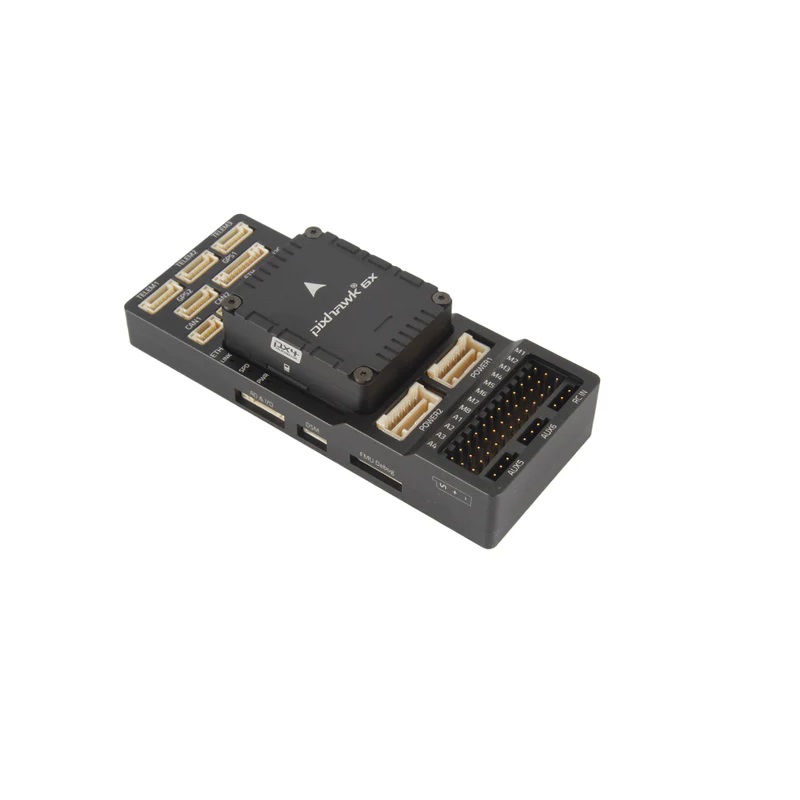
Holybro Pixhawk 6X Standard Set v2B + M10 GPS

₹47,189.00 (Inclusive of all taxes)
Out of Stock

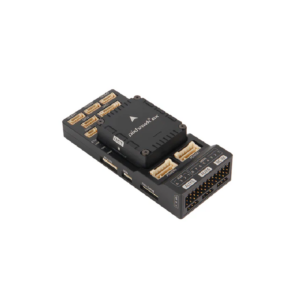
The Holybro Pixhawk 6X Standard Set v2B is a high-performance flight controller featuring triple-redundant ICM-45686 IMUs and BalancedGyroâ„¢ technology, powered by an STM32H753 processor for demanding UAV, robotics, and autonomous vehicle applications.

Features

  • STM32H753 FMU processor (480 MHz) with STM32F103 IO co-processor for high-speed, multitasking flight control.
  • Triple-redundant ICM-45686 IMU sensors with BalancedGyroâ„¢ technology for exceptional stability and vibration resistance.
  • Dual barometer sensors (ICP20100 & BMP388) for robust and precise altitude measurement.
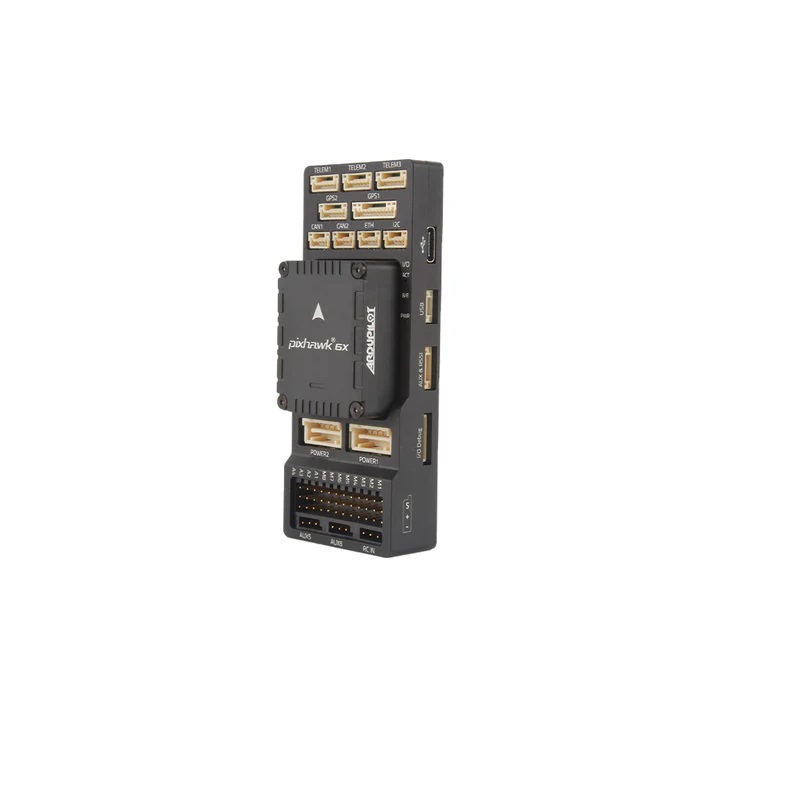
  • Modular design with separate FMU, IO, and Baseboard v2B, connected via Pixhawk® Autopilot Bus for flexible system integration.
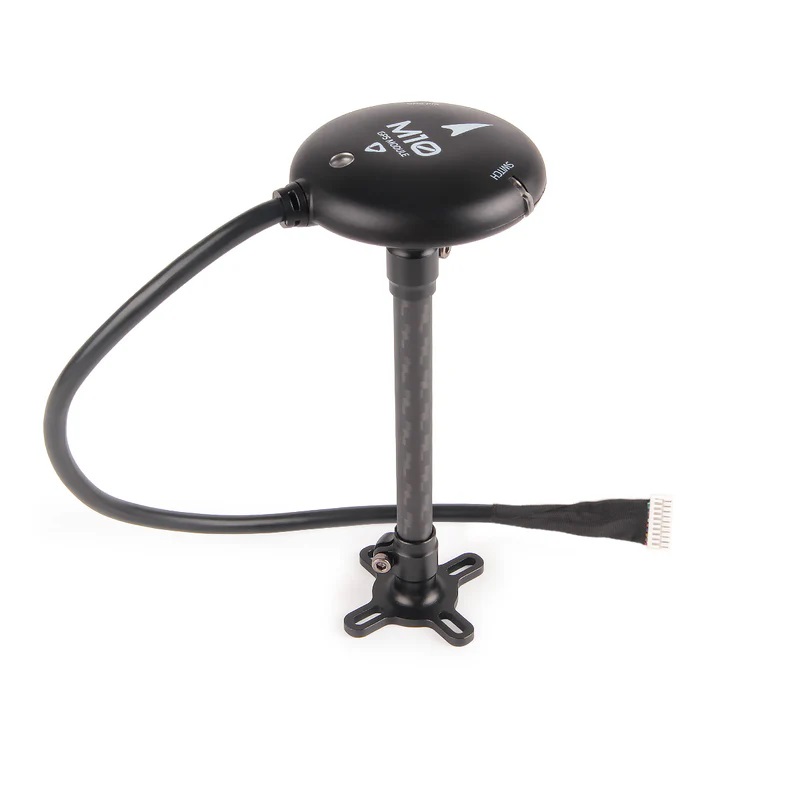
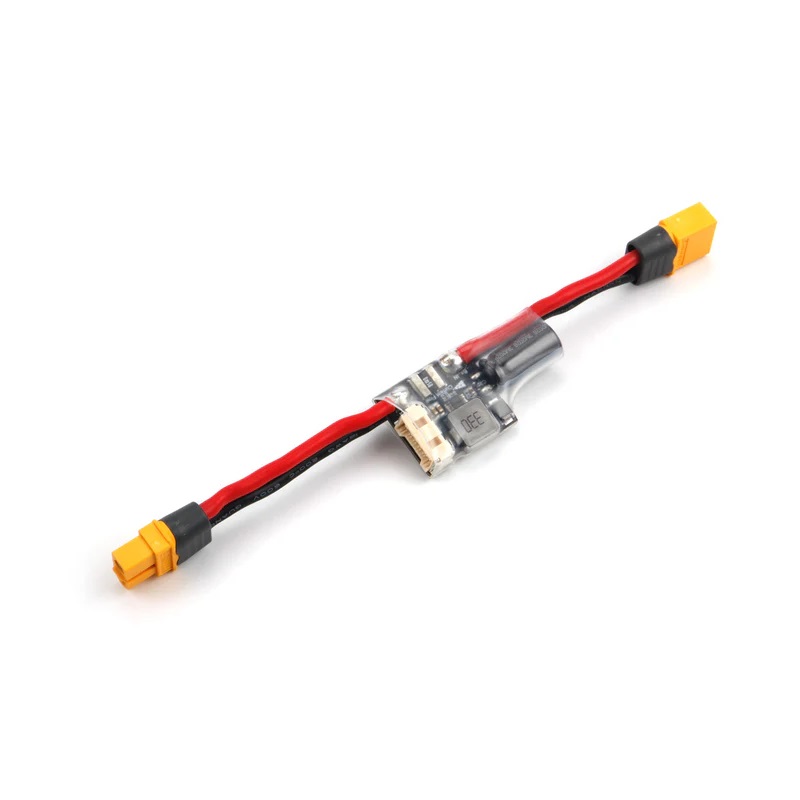
  • Includes M10 GPS module and PM02D HV Power Module for a complete, ready-to-deploy autopilot solution.

Out of stock

Description

The Pixhawk 6X Standard Set v2B is engineered for professional-grade reliability and precision. Its core architecture leverages a powerful STM32H753 microcontroller running at 480 MHz, paired with a dedicated STM32F103 IO processor to handle sensor data and peripheral management efficiently. This separation of concerns ensures robust performance for complex autonomous missions.

The system’s resilience is built on sensor redundancy. Three independent ICM-45686 IMUs, employing BalancedGyroâ„¢ technology, provide fault-tolerant attitude estimation, while dual barometers (ICP20100 and BMP388) safeguard altitude data. The modular design, centered on the Pixhawk® Autopilot Bus, allows the FMU and IO boards to be paired with different baseboards (like the included v2B) to suit specific vehicle types and power requirements.

Key Features

  • High-Performance Compute: STM32H753 (480 MHz) main processor with dedicated STM32F103 co-processor for optimized task handling.
  • Advanced Sensor Fusion: Triple-redundant ICM-45686 IMUs with BalancedGyroâ„¢ for vibration-damped, precise gyroscope and accelerometer data.
  • Redundant Barometric Altitude: Dual barometers (ICP20100 & BMP388) provide fail-safe altitude sensing.
  • Secure Hardware Element: Integrated NXP Semiconductors EdgeLock SE050 secure element for encrypted data handling and secure boot.
  • Modular & Scalable Architecture: FMU and IO module system works with multiple baseboards (v2B included) for application-specific configurations.
  • Wide Input Voltage Range: Supports 6V regulated input, 4.75–5.25V USB, and a servo rail input capable of 0–36V for flexible power sourcing.
  • Vibration-Isolated Design: Mechanical and electrical design minimizes vibration transfer to critical sensors for accurate readings in dynamic flight.
  • Professional-Grade Connectivity: Comprehensive I/O including multiple UART, CAN, I2C, and PWM outputs for peripherals like GPS, telemetry, and servos.

Applications

  • Industrial UAVs for precision aerial surveying, mapping, and infrastructure inspection.
  • Autonomous cargo and delivery drones requiring reliable, redundant navigation systems.
  • Advanced research and development platforms for robotics and autonomous vehicle testing.
  • Heavy-lift cinematography and agricultural spraying drones where flight stability is critical.
  • Marine and ground robotic systems utilizing the modular baseboard architecture.

Technical Specifications

Item TypeFlight Controller
FMU ProcessorSTM32H753 (480 MHz)
IO ProcessorSTM32F103
IMU Sensors3x ICM-45686 (Accelerometer/Gyroscope)
Barometer SensorsICP20100 & BMP388
MagnetometerIntegrated
Secure ElementNXP Semiconductors EdgeLock SE050
Voltage Input (Main)6V
USB Power Input4.75–5.25V
Servo Rail Input0–36V
ConnectivityPixhawk® Autopilot Bus, UART, CAN, I2C, PWM
FirmwarePX4, ArduPilot

Frequently Asked Questions

What firmware is compatible with the Pixhawk 6X?

The Pixhawk 6X is fully compatible with both the PX4 and ArduPilot open-source autopilot firmware ecosystems. You can flash the latest stable or beta releases directly via USB or a ground station software like QGroundControl or Mission Planner.

What is the purpose of the triple-redundant IMUs?

The three independent ICM-45686 Inertial Measurement Units (IMUs) provide sensor redundancy. If one IMU fails or provides anomalous data due to vibration or damage, the flight controller's EKF2 (Extended Kalman Filter) can vote or fuse data from the remaining healthy sensors, maintaining stable flight and preventing a crash.

What power sources can I use with the Standard Baseboard v2B?

The system accepts multiple inputs: a regulated 6V supply via the main power port (typically from the included PM02D power module), standard USB power (4.75-5.25V), and a high-voltage servo rail input capable of handling 0-36V for direct connection to LiPo batteries or other high-voltage peripherals.

Does the set include everything needed for a basic drone build?

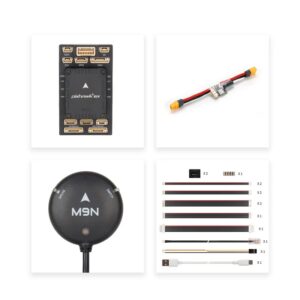
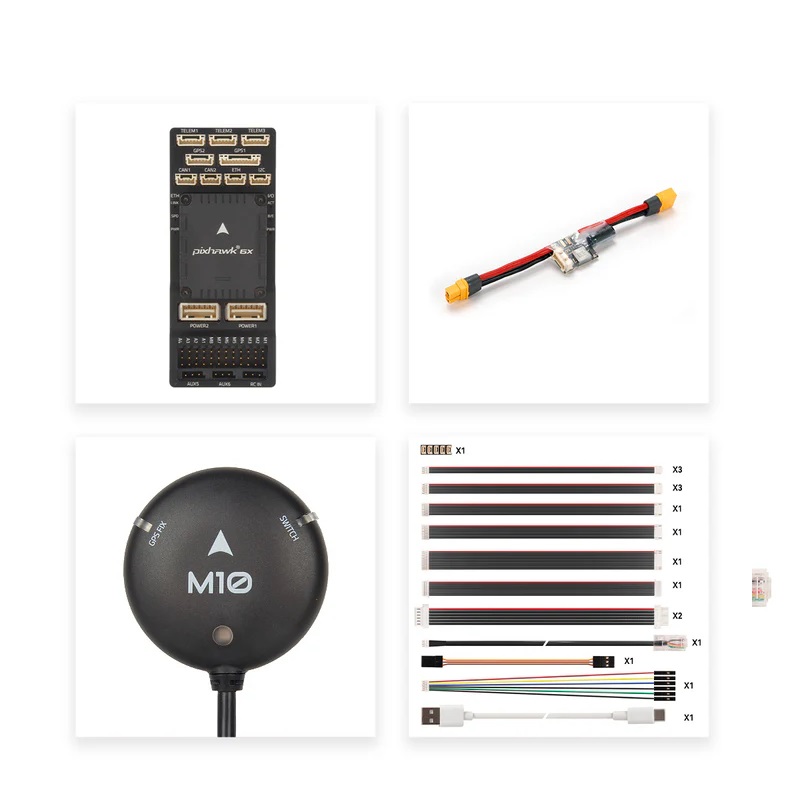
Yes, the Standard Set v2B provides the core autopilot components: the Pixhawk 6X flight controller module, the v2B baseboard, a PM02D high-voltage power module, an M10 GPS/compass module, and the necessary cables. You will need to add your own radio receiver (e.g., ELRS, FrSky), motors, ESCs, frame, and propellers to complete the build.

Package Includes

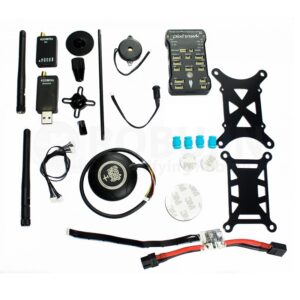
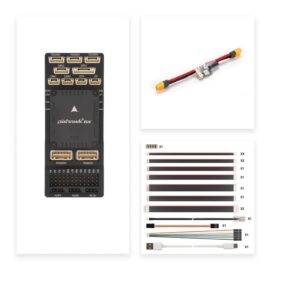
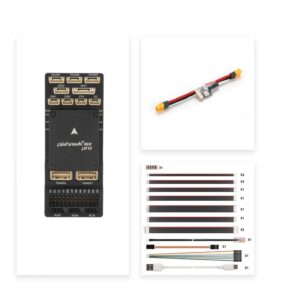
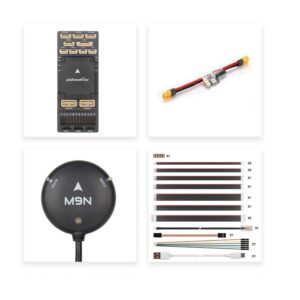
  • 1 x Pixhawk 6X Flight Controller Module (FMU & IO)
  • 1 x Standard Baseboard v2B
  • 1 x PM02D HV Power Module
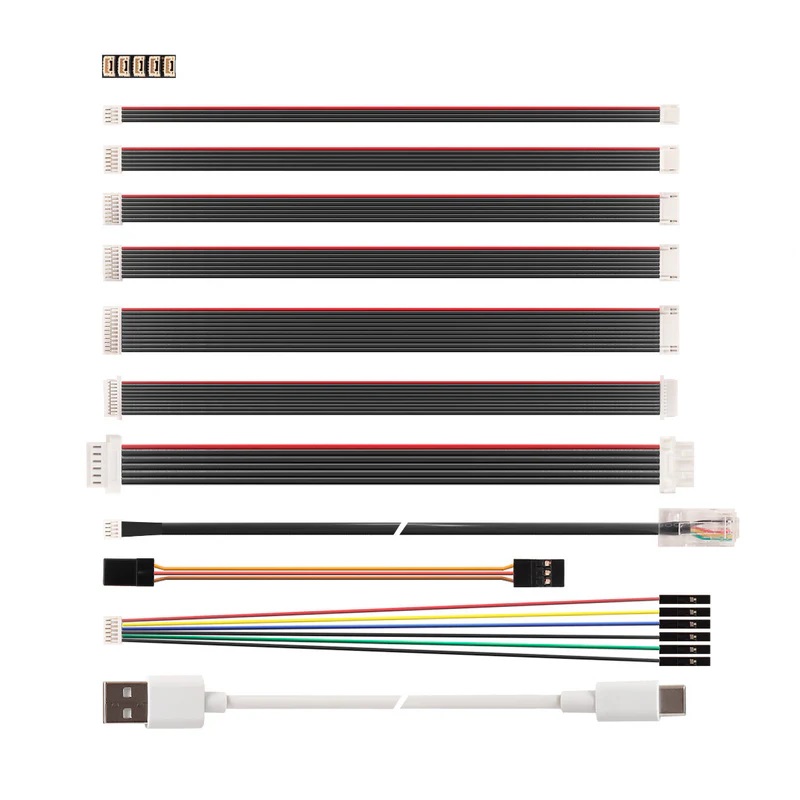
  • 1 x Cable Set
  • 1 x M10 GPS Module

Additional Information

Weight 0.325 kg
Dimensions 10 × 14 × 7 cm