SKU: DRFC-1815
📋 GST Invoice Available

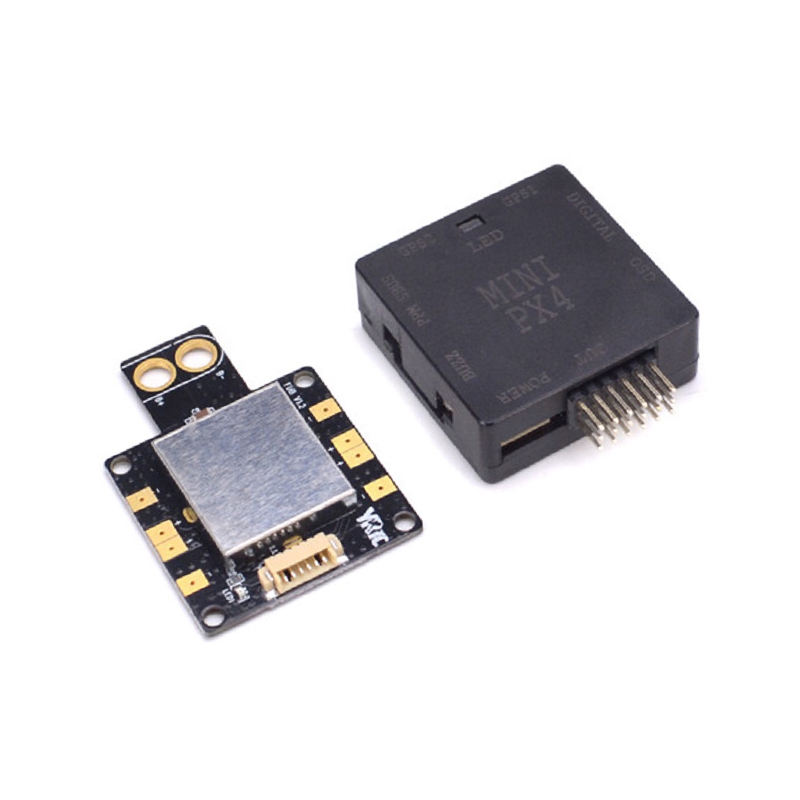
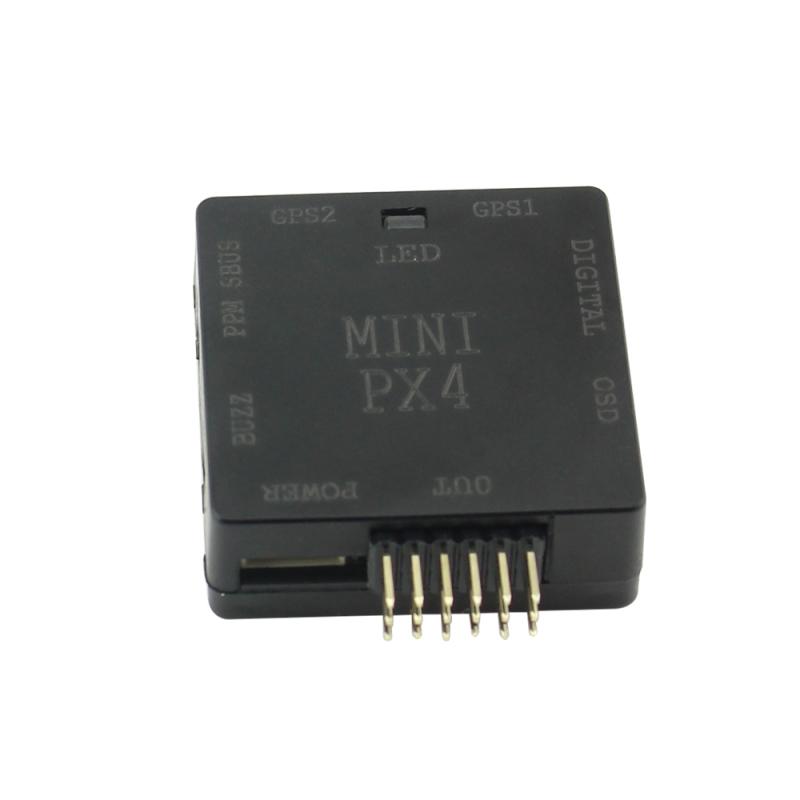
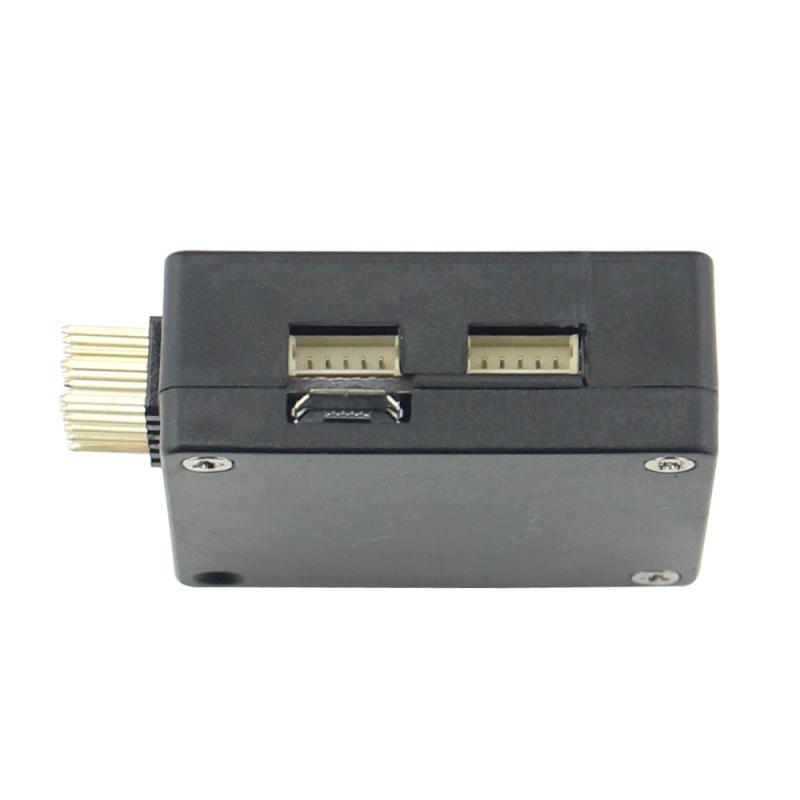
ReadyToSky Mini Pixhawk 2.4.8 and Power Module

₹3,189.00 (Inclusive of all taxes)
Out of Stock

The ReadyToSky Mini Pixhawk 2.4.8 is a compact 32-bit PX4 autopilot flight controller built around an STM32F407 Cortex-M7 processor, designed for advanced UAV applications requiring robust navigation and failsafe capabilities.

Features

  • STM32F407 32-bit Arm Cortex-M7 processor running at 168 MHz for high-performance flight control.
  • Integrated sensor suite includes ICM-20689 gyro/accelerometer, MS5607 barometer, and IST8310 compass.
  • Features redundant power input with automatic failover and an integrated backup controller for enhanced safety.
  • Supports up to 14 PWM/servo outputs and multiple serial interfaces (UART, I2C, SPI, CAN).
  • Compatible with the PX4 flight stack and NuttX RTOS for professional-grade autonomous operation.

Out of stock

Description

The Mini Pixhawk 2.4.8 is engineered as a professional-grade autopilot system, providing the computational power and sensor redundancy required for complex drone missions. Its STM32F407 Cortex-M7 core ensures rapid processing of navigation algorithms and real-time control loops, while the suite of high-precision sensors delivers accurate attitude and altitude data.

Designed with system integrity in mind, it incorporates a dedicated backup power supply and a secondary controller that automatically engages in the event of a primary system failure. This architecture, combined with support for the PX4 open-source ecosystem, makes it suitable for development, research, and commercial UAV platforms demanding reliability and advanced automation features.

Key Features

  • High-Performance Processing: 32-bit STM32F407 Arm Cortex-M7 CPU at 168 MHz handles complex flight control and navigation tasks efficiently.
  • Comprehensive Sensor Array: Equipped with an ICM-20689 6-axis IMU, MS5607 barometer, and IST8310 magnetometer for precise attitude, altitude, and heading data.
  • Redundant Safety Architecture: Integrated backup power input and a secondary controller provide automatic failover, enhancing operational safety.
  • Extensive Connectivity: Offers 14 PWM/servo outputs, 4 serial ports, and support for UART, I2C, SPI, and CAN bus interfaces for peripheral expansion.
  • Professional Software Stack: Runs the PX4 flight stack on the NuttX real-time operating system (RTOS), enabling advanced autonomous modes and mission scripting.
  • Flexible Power Input: Accepts a servo rail voltage of 5-16V, with a dedicated 5V input for the power module and flight controller logic.

Applications

  • Advanced autonomous research and development UAV platforms.
  • Compact mapping, surveying, and inspection drones requiring PX4 autopilot functionality.
  • Educational and prototyping projects for university-level robotics and aeronautics programs.
  • Heavy-lift or cargo multicopters where redundant control and power systems are critical.
  • Custom VTOL (Vertical Take-Off and Landing) or hybrid aircraft builds utilizing the PX4 flight stack.

Technical Specifications

Item TypeFlight Controller
Model NameMINI PIX Pixhawk 2.4.8
ProcessorSTM32F407 32-bit Arm Cortex-M7 @ 168 MHz
GyroscopeICM-20689
AccelerometerICM-20689
BarometerMS5607
Compass (Magnetometer)IST8310
Interface TypeCH1.25
USB Voltage5V
PM Module Input Voltage5V
Servo Input Voltage5-16V
FC Logic Voltage5V
Output Channels14 PWM / Servo
Serial Interfaces4 Ports (UART, I2C, SPI, CAN)
Firmware/OSPX4 / NuttX RTOS

Frequently Asked Questions

What is the primary processor and operating system used by the Mini Pixhawk 2.4.8?

The flight controller is built around an STM32F407 32-bit Arm Cortex-M7 processor running at 168 MHz. It operates on the NuttX real-time operating system (RTOS) and is programmed with the open-source PX4 flight stack, providing a robust and flexible environment for autonomous drone control and mission scripting.

What sensors are integrated into this flight controller for navigation?

The unit features a comprehensive sensor suite: an ICM-20689 for 6-axis gyroscope and accelerometer data, an MS5607 barometer for altitude measurement, and an IST8310 magnetometer (compass) for heading determination. This combination provides the essential data for stable flight and precise navigation.

How does the redundant power and failover system work?

The controller includes a dedicated backup power input. If the primary power rail or the main processor fails, the system automatically switches to the backup power supply and engages a secondary controller. This design ensures continued operation or a safe controlled landing, which is critical for professional and commercial UAV applications.

What voltage range can the servo/output rail accept, and how is the board itself powered?

The servo and output rail can accept an input voltage between 5V and 16V, suitable for a wide range of peripherals and ESCs. The flight controller's logic and the included power module are designed to operate at a stable 5V. A separate 5V USB port is also provided for configuration and data transfer.

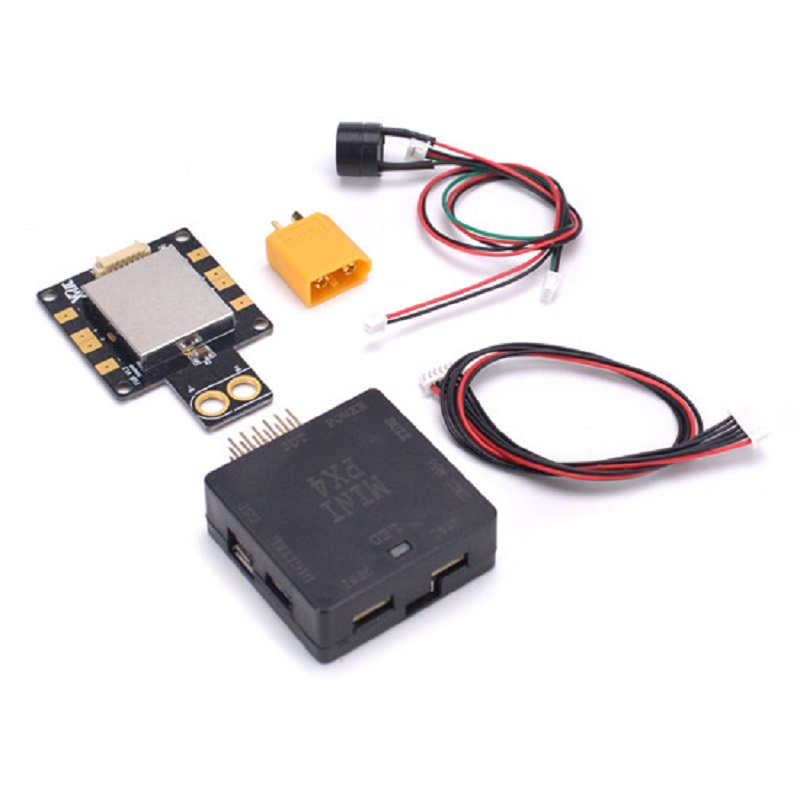
Package Includes

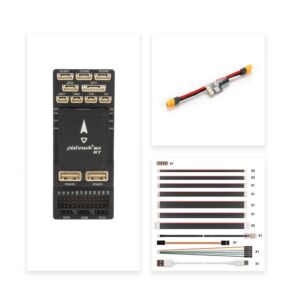
  • 1 x Mini Pixhawk 2.4.8 Flight Controller
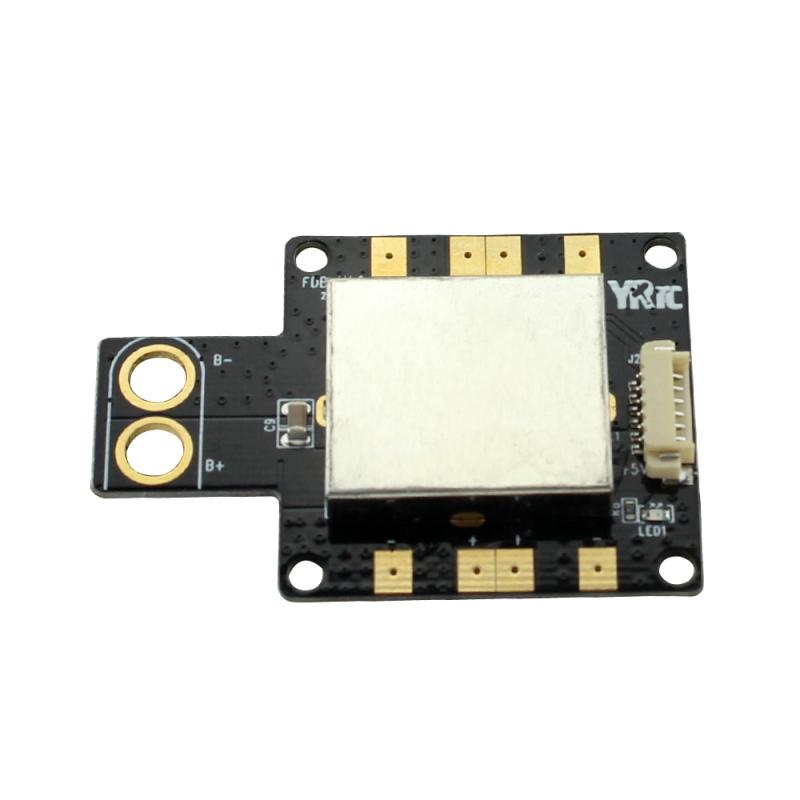
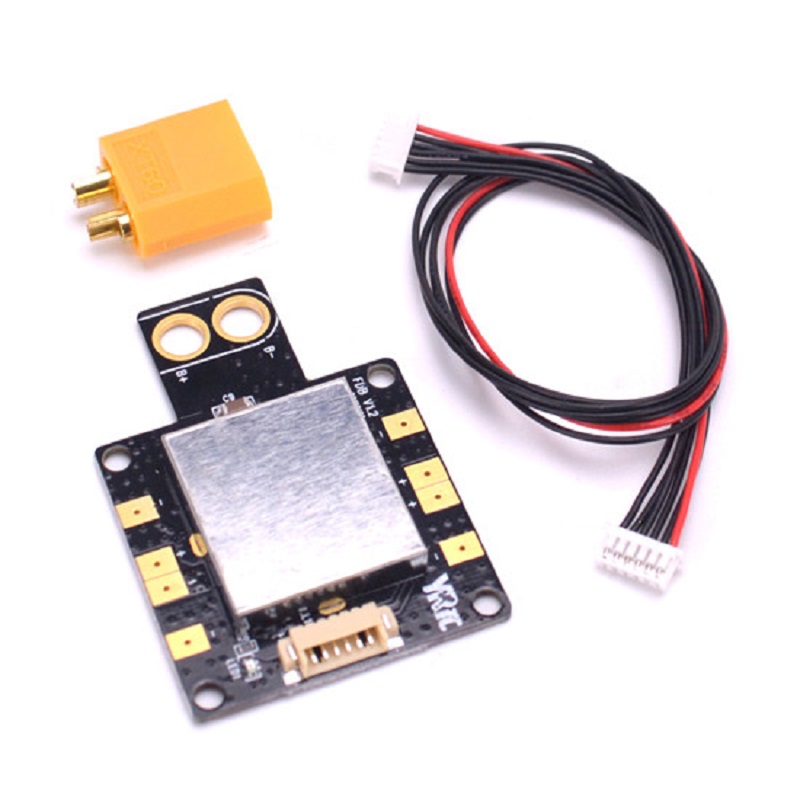
  • 1 x Power Module
  • 1 x Buzzer
  • 1 x Set of Cables

Additional Information

Weight 0.15 kg
Dimensions 5 × 8 × 5 cm