SKU: DRFC-0895
📋 GST Invoice Available

Pixhawk 2.4.7 Flight Controller w/ NEO-M8N GPS Combo Kit

₹23,626.35 (Inclusive of all taxes)
Out of Stock

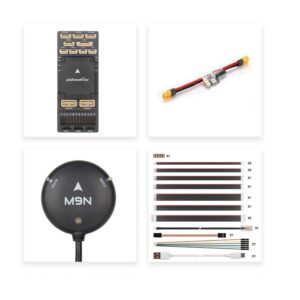
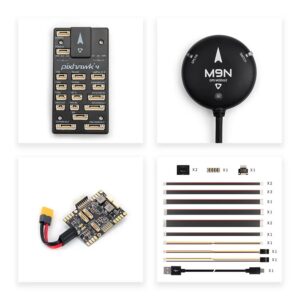
This comprehensive kit provides the essential control components for multirotors, fixed-wing, and robotic platforms, centered around the high-performance Pixhawk PX4 2.4.7 flight controller. It includes a u-blox NEO-M8N GPS for precision navigation, a Pixhawk Power Module for reliable power, and a PPM Encoder, ensuring robust and affordable flight control.

Features

  • High-performance Pixhawk PX4 2.4.7 Flight Controller for diverse UAV applications.
  • Integrated u-blox NEO-M8N GPS module with enhanced 0.9m position accuracy.
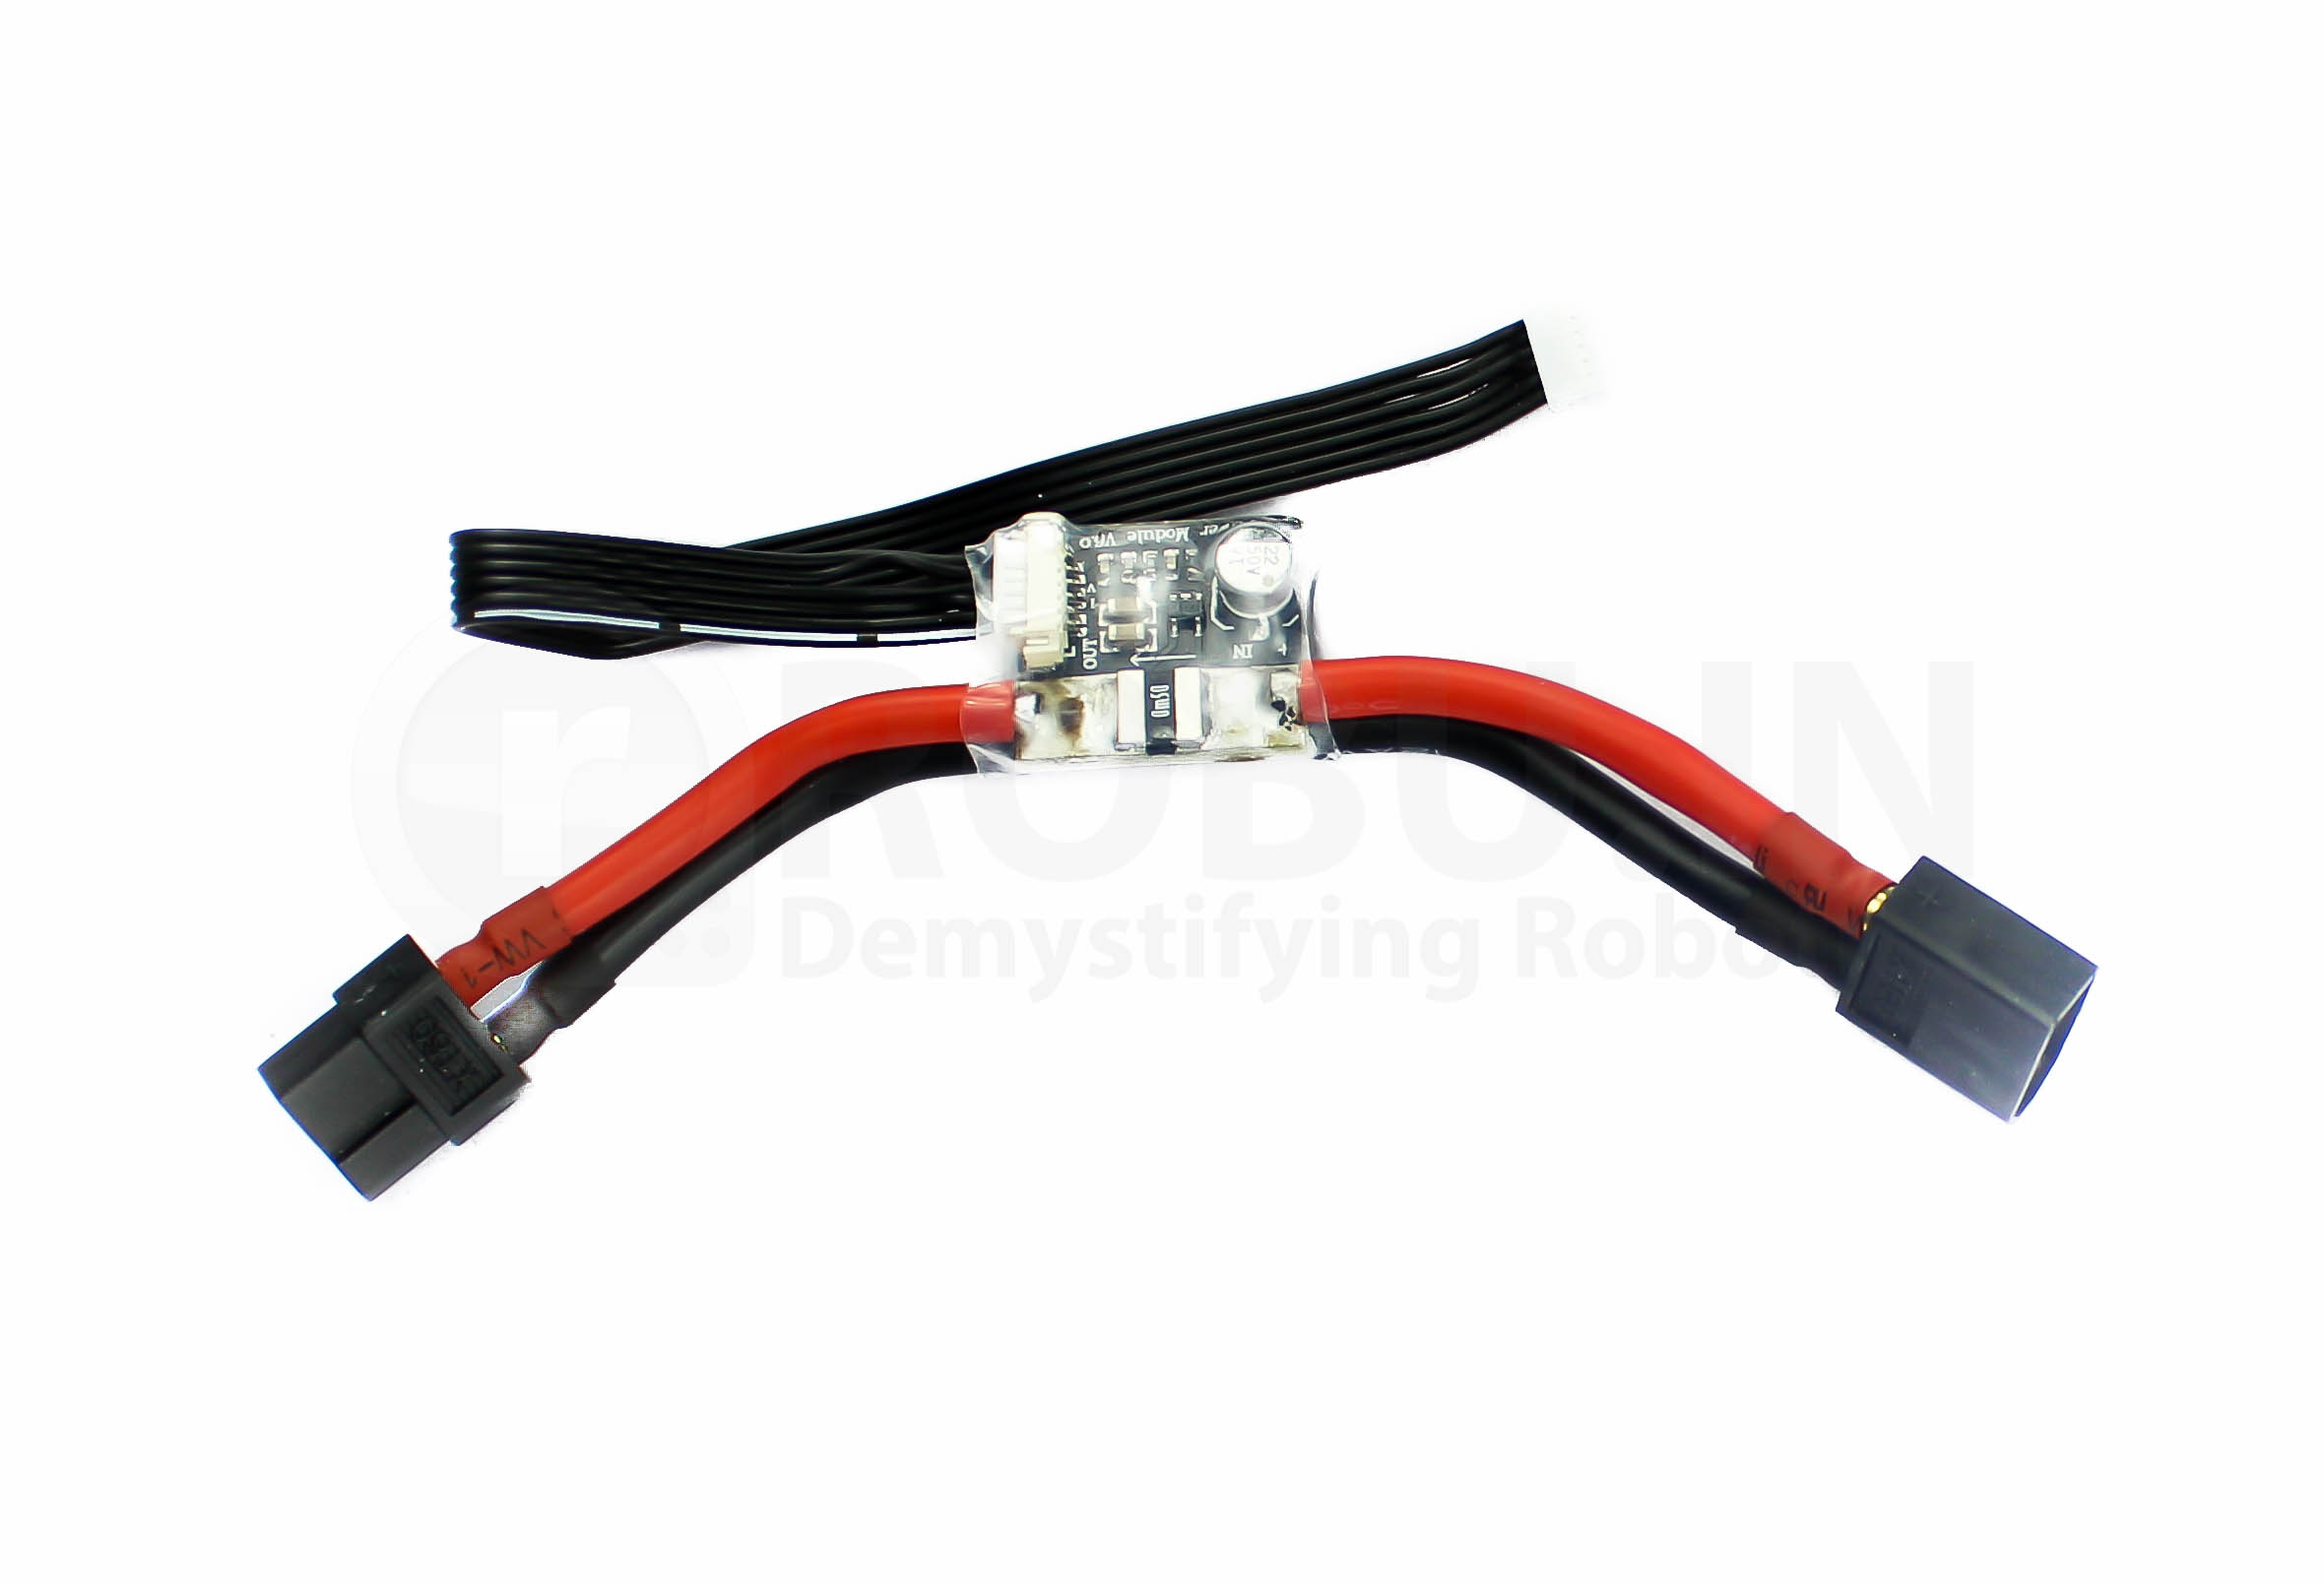
  • Reliable Pixhawk Power Module (28V/90A) for clean power and telemetry.
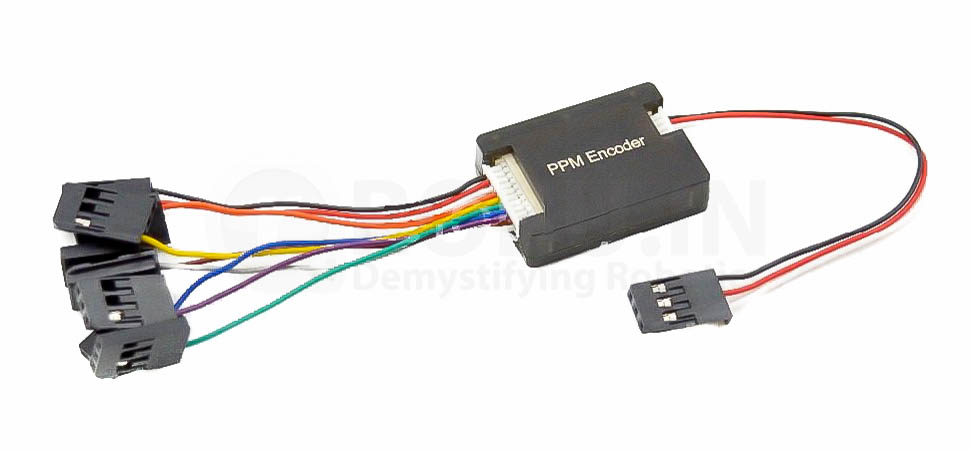
  • Includes PPM Encoder for simplified receiver signal integration.
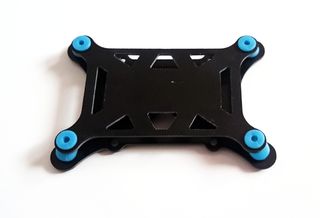
  • Universal anti-vibration mount for stable FC and sensor operation.

Out of stock

Description

The Pixhawk PX4 2.4.7 Flight Controller kit combines high-performance autopilot capabilities with essential peripherals, making it suitable for a wide range of robotic platforms including fixed-wing aircraft, multirotors, and ground vehicles. At its core is the 32-bit STM32F427 Cortex M4 microcontroller, offering substantial processing power (168 MHz / 252 MIPS) and extensive connectivity options through multiple UART, I2C, and CAN interfaces. This advanced architecture ensures precise flight control and robust data logging for complex missions.

This combo kit addresses critical aspects of UAV operation by including a new generation u-blox NEO-M8N GPS module, known for its low power consumption and improved positional accuracy (approximately 0.9 meters), supporting concurrent GNSS protocols. A dedicated Pixhawk Power Module provides a clean 5.3V @ 3A output from LiPo batteries (up to 6S, 28V/90A max current sensing), along with integrated voltage and current telemetry. Furthermore, the universal anti-vibration mount effectively isolates the flight controller from motor and propeller vibrations, safeguarding sensor integrity, while the PPM Encoder simplifies receiver wiring for streamlined setup.

Key Features

  • Advanced Autopilot Core: 32-bit STM32F427 Cortex M4F processor (168 MHz) with 2MB Flash and 256KB RAM for complex flight algorithms.
  • Redundant Systems: Features a 32-bit STM32F103 failsafe co-processor and redundant power inputs with automatic failover for enhanced reliability.
  • High-Precision GNSS: u-blox NEO-M8N GPS receiver offers 0.9-meter positional accuracy, supporting GPS/QZSS, GLONASS, and BeiDou.
  • Comprehensive Sensor Suite: Incorporates ST Micro L3GD20H gyroscope, 3CLDW 303H accelerometer/magnetometer, Invensense MPU 6000, and MEAS MS5611 barometer.
  • Extensive Connectivity: Provides 5x UARTs, 2x CAN, Spektrum DSM/S.BUS input, PPM sum input, I2C, SPI, and ADC for peripheral expansion.
  • Integrated Power Management: APM/Pixhawk Power Module V6.0 delivers clean 5.3V @ 3A, supports up to 6S LiPo, and measures 90A max current.
  • Vibration Isolation: Universal anti-vibration shock absorber set (glass fiber) compatible with Pixhawk, APM, KK, and MWC.
  • Simplified RC Input: Pixhawk PPM Encoder Module converts up to 8 PWM receiver channels into a single PPM sum signal.

Applications

  • Autonomous multirotor and fixed-wing UAVs.
  • FPV camera platforms requiring stable flight and accurate navigation.
  • Agricultural and inspection drones needing precise GPS positioning.
  • Robotic vehicle control and research platforms.
  • Long-range mission planning and execution.

Technical Specifications

Flight Controller (Pixhawk V2.4.7)
ProcessorSTM32F427 Cortex M4F (168 MHz, 2MB Flash, 256KB RAM)
Failsafe Co-processorSTM32F103
GyroscopeST Micro L3GD20H (16 bit), Invensense MPU 6000 (3-axis)
Accelerometer/MagnetometerST Micro 3CLDW 303H (14 bit)
BarometerMEAS MS5611
PWM/Servo Outputs14 (8 with failsafe, 6 auxiliaries)
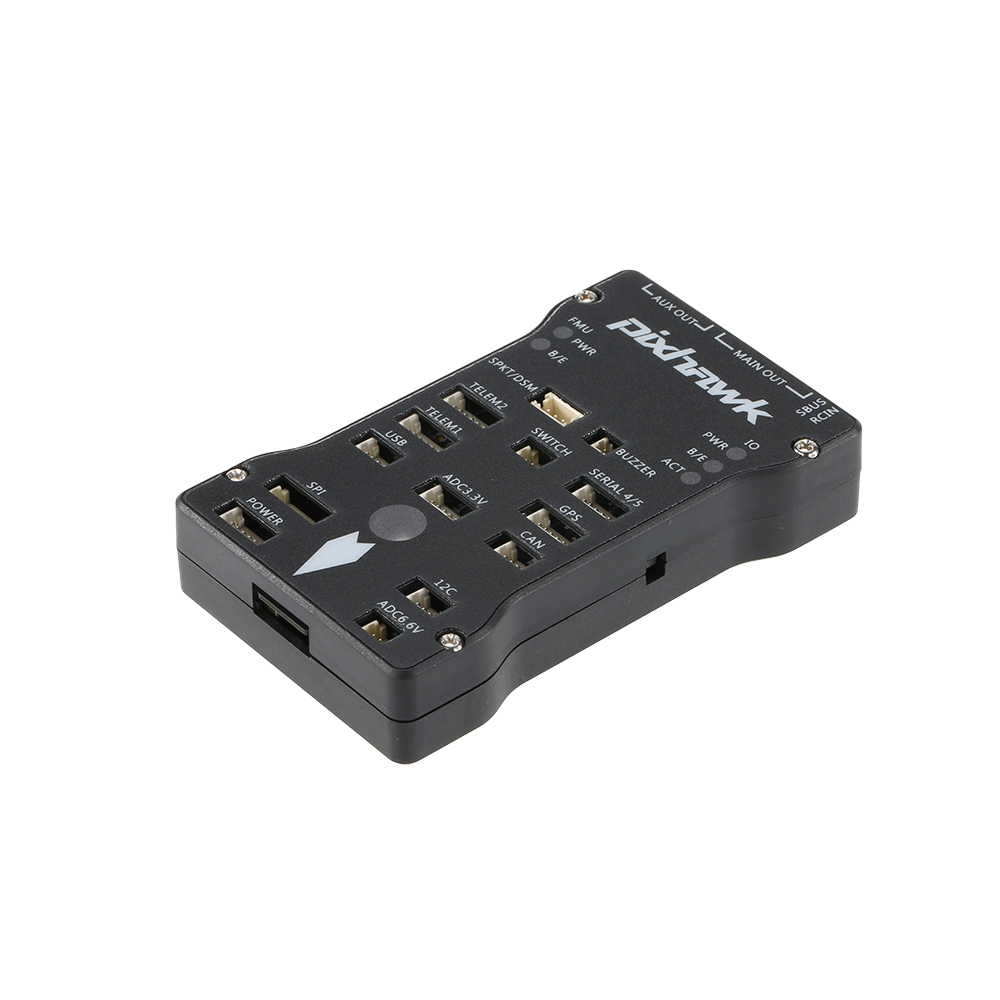
Interfaces5x UART, 2x CAN, Spektrum DSM/S.BUS, PPM sum, I2C, SPI, ADC
GPS Module (u-blox NEO-M8N)
Receiver Type72-channel u-blox M8 engine
Supported GNSSGPS/QZSS L1 C/A, GLONASS L10F, BeiDou B1, SBAS
Position Accuracy2.0 m CEP (actual ~0.9 m)
Nav. Update RateSingle GNSS: up to 18 Hz; Concurrent GNSS: up to 10 Hz
Sensitivity (Tracking)–167 dBm
Power Module (APM/Pixhawk V6.0)
Max Input Voltage28V
Max Current Sensing90A
Output BEC5.3V @ 3A max
Battery SupportUp to 6S LiPo
PPM Encoder Module
Input Channels8
OutputPPM SUM × 1 / MUX × 1
Dimensions28 x 19 x 5 mm
Weight12 gm (with wires)
Anti-Vibration Mount
MaterialGlass fiber
Upper Frame Size90 x 60 x 2 mm
Lower Frame Size100 x 70 x 2 mm
Shock Absorber Height10 x 12 mm

Frequently Asked Questions

What flight stack firmware is compatible with the Pixhawk 2.4.7 flight controller?

The Pixhawk 2.4.7 is primarily designed for ArduPilot and PX4 open-source flight stack firmware. Users can flash and configure it using ground control software like Mission Planner for ArduPilot or QGroundControl for PX4. This allows for extensive customization and support for various UAV types.

What are the power requirements and monitoring capabilities of the included Power Module?

The Pixhawk Power Module V6.0 supports input voltages up to 28V, making it compatible with up to 6S LiPo batteries. It provides a clean 5.3V output at 3A for the flight controller and peripherals. Crucially, it senses up to 90A current and battery voltage, feeding this data to the Pixhawk for critical telemetry and flight logging.

How does the u-blox NEO-M8N GPS module improve navigation accuracy?

The u-blox NEO-M8N module significantly enhances navigation by supporting concurrent reception of GPS/QZSS, GLONASS, and BeiDou satellite systems. This multi-constellation capability, combined with its 72-channel engine, reduces signal dropouts and improves positional accuracy to approximately 0.9 meters, crucial for precision flight tasks and autonomous operations.

What is the purpose of the PPM Encoder Module in this kit?

The PPM Encoder Module simplifies wiring between your RC receiver and the Pixhawk flight controller. Instead of connecting individual PWM channels, it converts up to eight standard PWM signals from your receiver into a single PPM sum signal. This reduces cable clutter and simplifies the setup, making integration more efficient for various RC systems.

Package Includes

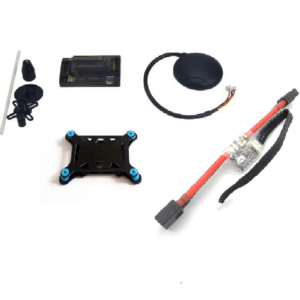
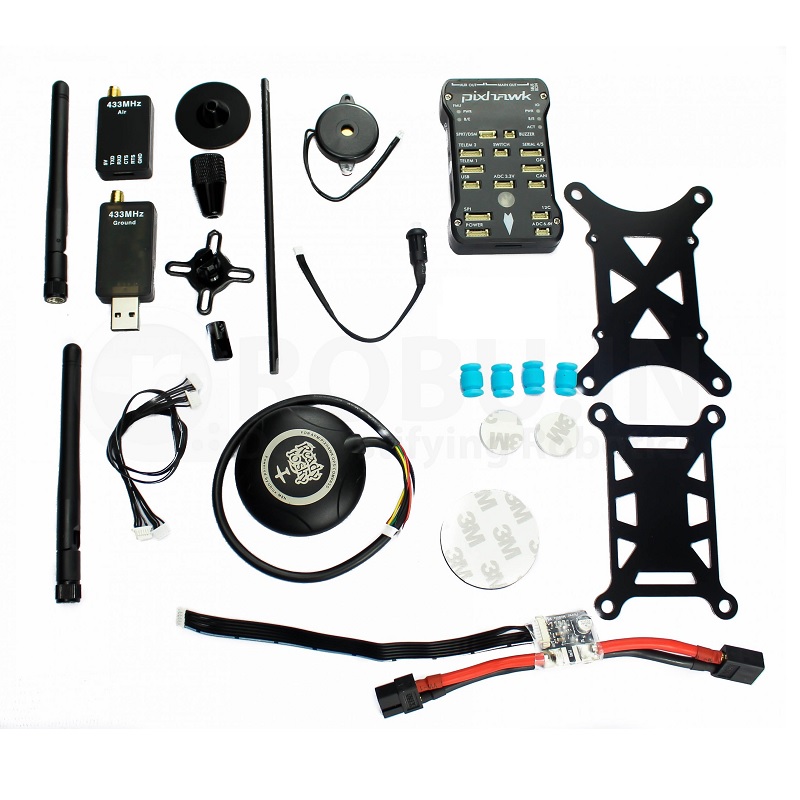
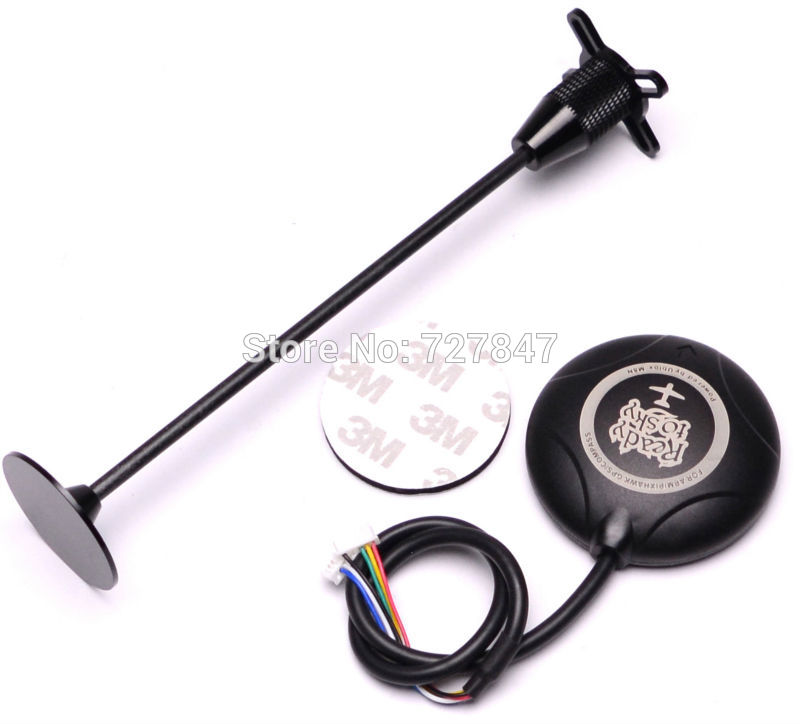
  • 1 x u-blox NEO-M8N GPS Module with Compass (APM/Pixhawk connector)
  • 1 x Pixhawk PX4 2.4.7 32Bits Flight Controller
  • 1 x Anti-Vibration Shock Absorber Set
  • 1 x Pixhawk PPM Encoder Module
  • 1 x APM/Pixhawk Power Module V6.0 (Output BEC 3A, XT60 Plug, 28V 90A)
  • 1 x GPS Folding Antenna Base mount (CNC Aluminum alloy, carbon fiber rod)

Additional Information

Dimensions 15 × 10 × 6 cm