SKU: DRFC-1886
📋 GST Invoice Available

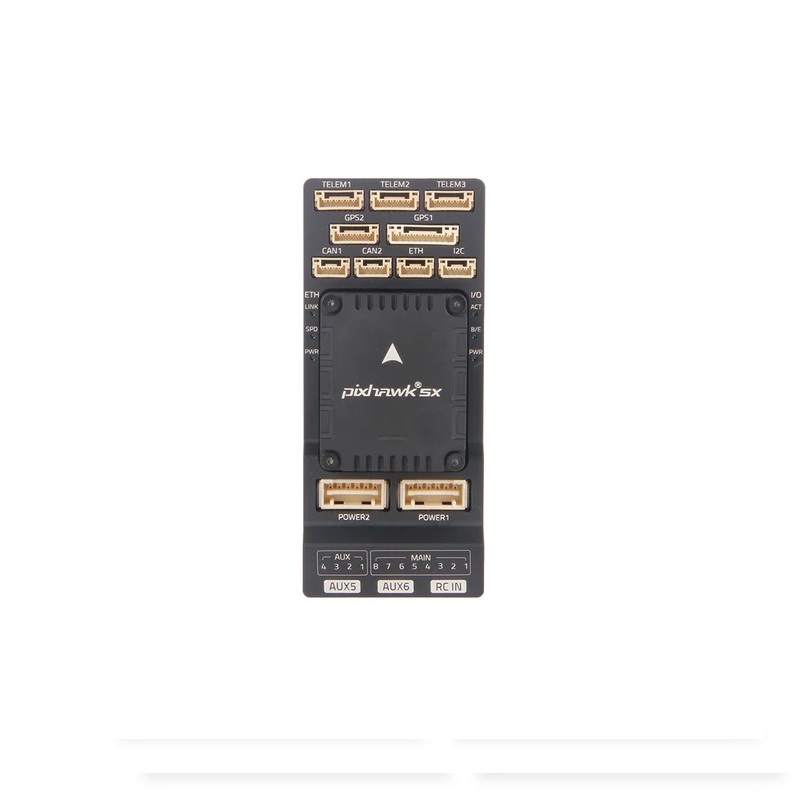
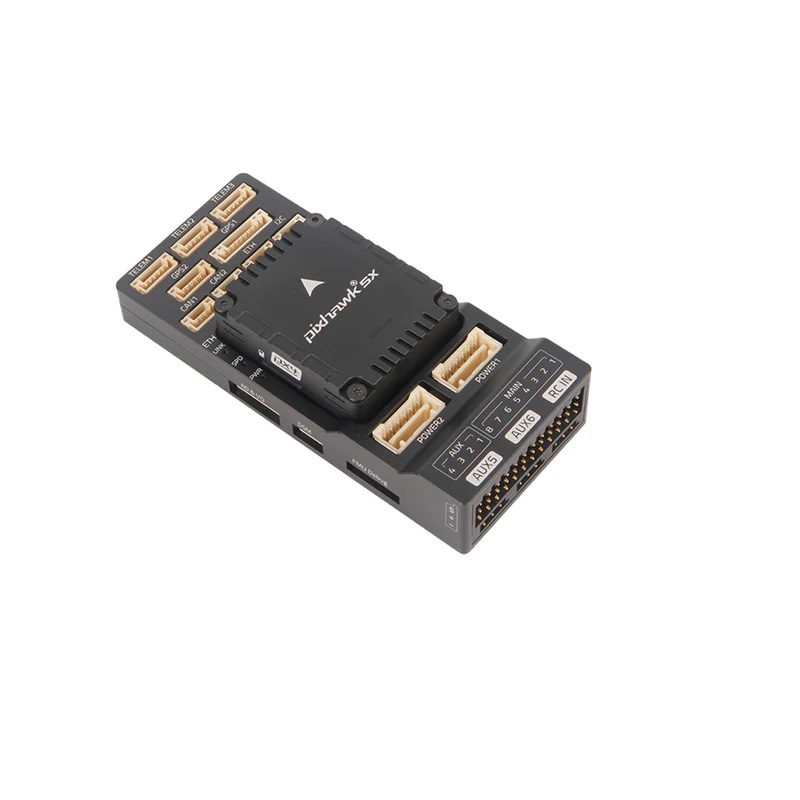
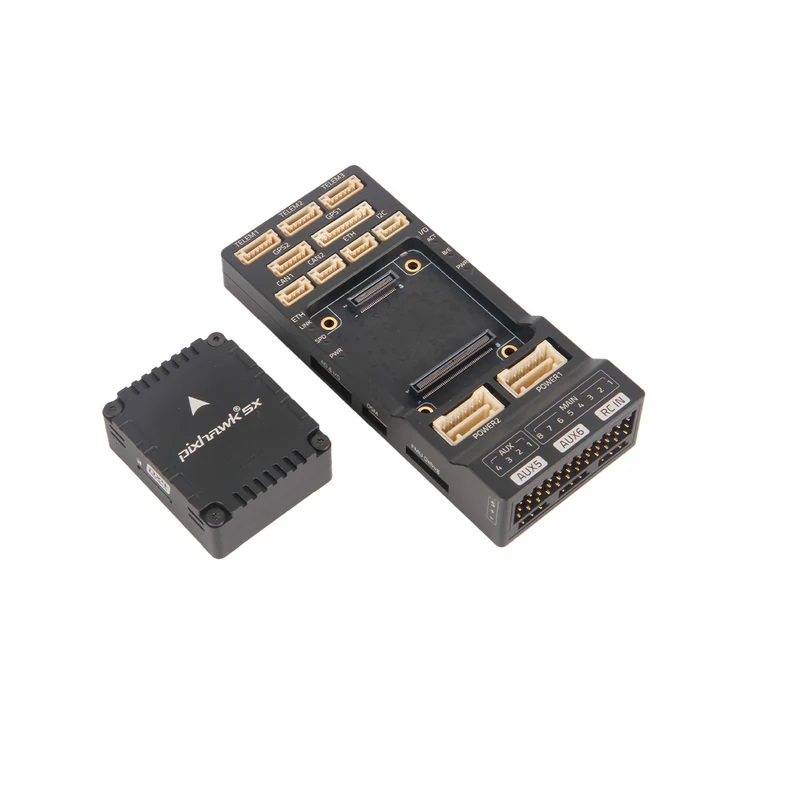
Holybro Pixhawk 5X Standard Set v2A+M9N GPS

₹46,999.00 (Inclusive of all taxes)
Out of Stock

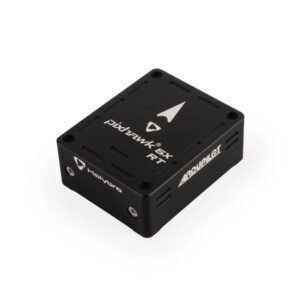
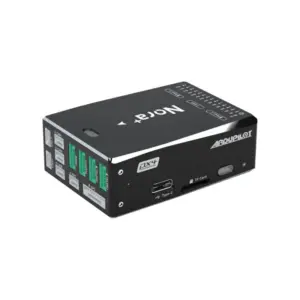
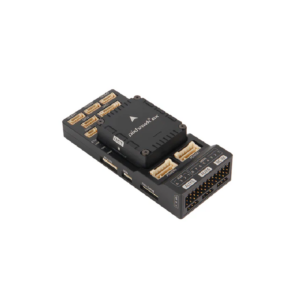
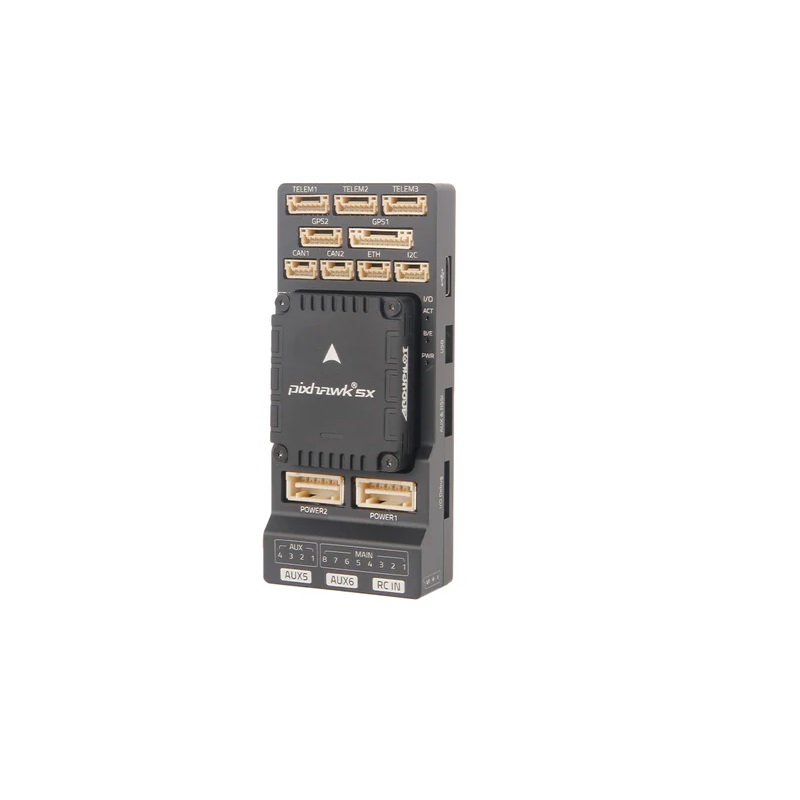
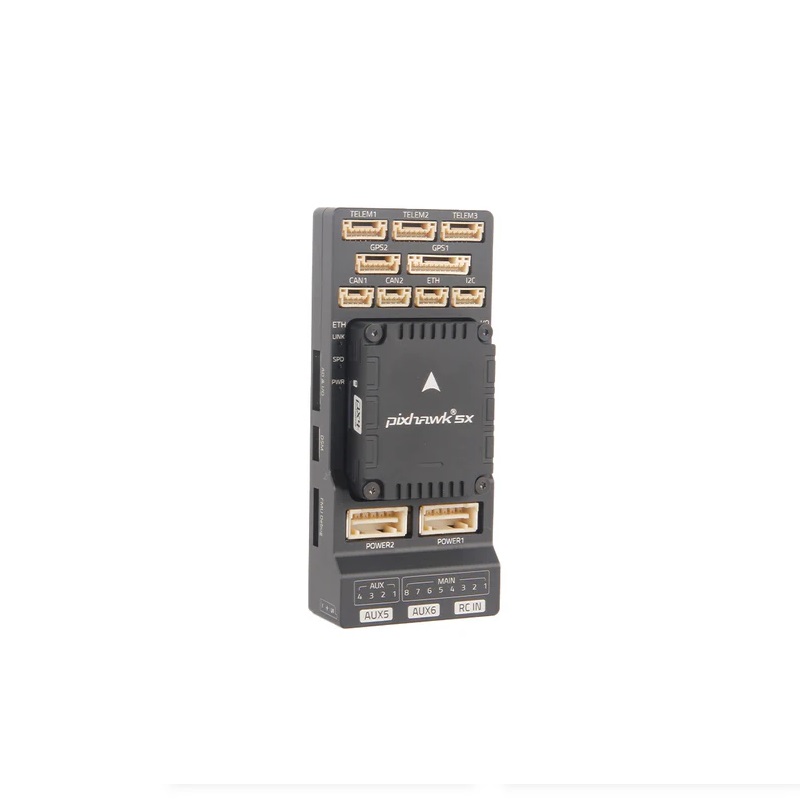
The Holybro Pixhawk 5X Standard Set is a professional-grade autopilot flight controller based on the Pixhawk FMUv5X standard, featuring triple-redundant IMUs, dual barometers, and an STM32F7 processor. It is fully compatible with PX4 and ArduPilot firmware, designed for advanced autonomous UAV applications requiring high reliability and sensor integration.

Features

  • Triple-redundant, low-noise IMUs (ICM-20649, ICM-42688P, ICM-20602/BMI088) with advanced vibration isolation.
  • Dual BMP388 barometers and independent power control for enhanced sensor reliability and failover.
  • STM32F765 FMU processor with 2MB flash and 512KB RAM for complex autonomous algorithms.
  • Integrated SPI5 external sensor bus with dual chip select and Ethernet PHY for mission computer communication.
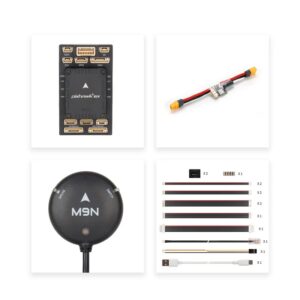
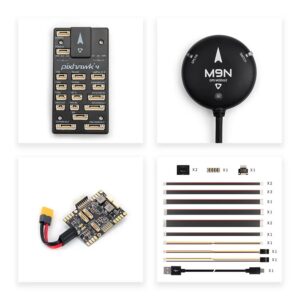
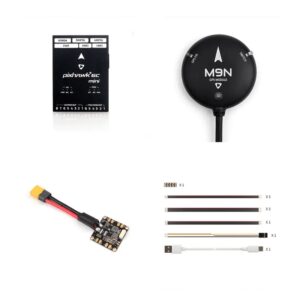
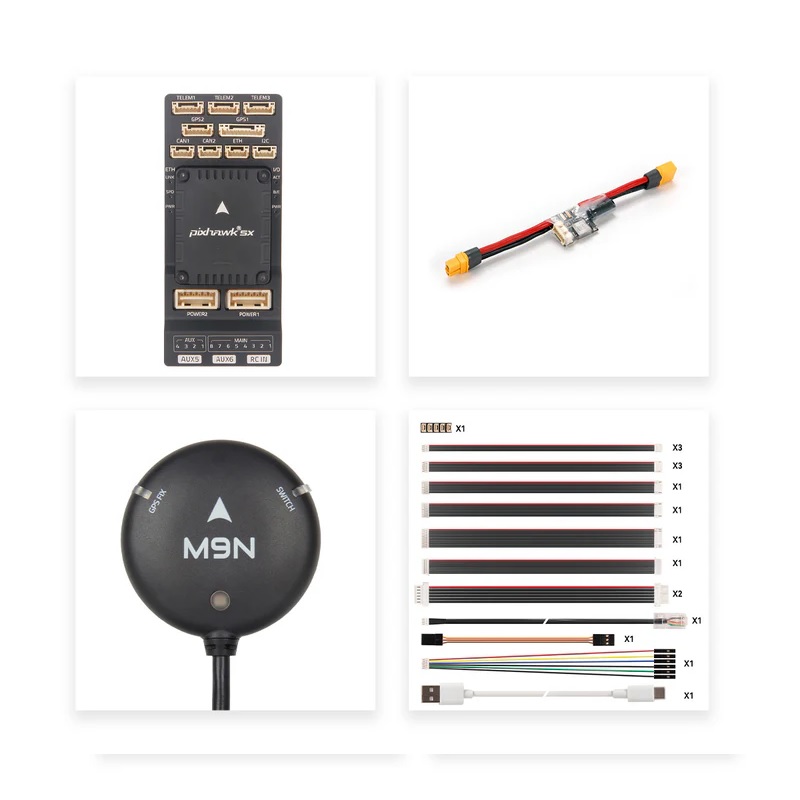
  • Includes PM02D HV Power Module, M9N GPS module, and full cable set for immediate deployment.

Out of stock

Description

The Pixhawk 5X represents the latest evolution in the Pixhawk open-standard flight controller family, engineered for demanding commercial and academic UAV projects. Its architecture centers on an STM32F7 microcontroller paired with a dedicated STM32F100 I/O processor, delivering the computational power required for sophisticated autonomy and navigation tasks. The system’s design emphasizes sensor integrity, with triple inertial measurement units and dual barometers operating on isolated, temperature-controlled power domains to minimize noise and ensure data accuracy.

This Standard Set configuration provides a complete solution for vehicle integration. The inclusion of the PM02D high-voltage power module supports a wide input range, while the M9N GPS module delivers precise global positioning. The controller’s feature set, including dual SMBus smart battery ports, an external SPI5 bus, and onboard Ethernet, facilitates seamless integration with additional sensors, companion computers, and power systems, making it suitable for complex multirotor, fixed-wing, and VTOL platforms.

Key Features

  • Triple-redundant IMU sensor suite for unparalleled flight stabilization and failover safety.
  • Advanced vibration damping and isolated power rails ensure clean data from accelerometers and gyroscopes.
  • High-speed STM32F765 processor enables execution of advanced PX4 and ArduPilot firmware features.
  • Dedicated SPI5 bus with dual chip select lines for easy expansion with external sensors like lidar or optical flow.
  • Integrated Microchip Technology LAN8742AI Ethernet PHY supports high-bandwidth communication with onboard mission computers.
  • Dual smart battery ports with INA226 support for detailed battery telemetry and monitoring.
  • Robust power design with 6V regulated output and wide-input servo rail (0-36V) for component compatibility.
  • Pre-configured with PX4 Autopilot software, ready for vehicle parameter tuning and mission planning.

Applications

  • Advanced autonomous research and commercial multirotor drones for mapping, inspection, and surveillance.
  • Heavy-lift UAV platforms requiring robust, redundant flight control for payload delivery or agricultural spraying.
  • Fixed-wing and VTOL (Vertical Take-Off and Landing) unmanned aircraft for long-endurance missions.
  • Academic and development platforms for prototyping complex autonomous behaviors and sensor fusion algorithms.
  • Integration with companion computers (via Ethernet) for AI-driven computer vision and real-time decision making.

Technical Specifications

FMU ProcessorSTM32F765
IO ProcessorSTM32F100
IMU SensorsICM-20649, ICM-42688P, ICM-20602 or BMI088
MagnetometerBMM150
Barometers2x BMP388
Input Voltage6V (regulated)
USB Power Input4.75–5.25V
Servo Rail Input0–36V
External BusSPI5 with dual chip select
CommunicationIntegrated Ethernet PHY (LAN8742AI)
Battery Ports2x SMBus with INA226 support
FirmwarePX4, ArduPilot

Frequently Asked Questions

What firmware is compatible with the Holybro Pixhawk 5X?

The Pixhawk 5X is fully compatible with both PX4 and ArduPilot open-source autopilot firmware. It ships pre-installed with PX4, allowing for immediate configuration and flight tuning. The STM32F7 processor's increased RAM and flash memory support the advanced features and algorithms in the latest versions of both firmware ecosystems.

What is the purpose of the triple-redundant IMUs?

The triple-redundant IMUs (ICM-20649, ICM-42688P, and ICM-20602/BMI088) provide critical sensor failover for safety and reliability. If one IMU experiences a fault or provides noisy data due to vibration, the flight controller's estimation filter can seamlessly switch to a backup sensor. This redundancy is essential for commercial and industrial drones where system failure is not an option.

How do I power the Pixhawk 5X and connect peripherals?

Primary power is supplied via the included PM02D HV Power Module, which connects to your main LiPo battery. The controller itself has a regulated 6V output for sensors. Peripherals like servos connect to the servo rail, which accepts 0-36V input. The dual SMBus ports allow for smart battery telemetry, and the dedicated SPI5 bus with chip select lines is designed for connecting external sensors like optical flow or lidar.

Can I connect a companion computer to the Pixhawk 5X?

Yes, the Pixhawk 5X features an integrated Ethernet PHY (LAN8742AI) specifically for high-speed communication with a companion mission computer, such as a Raspberry Pi or NVIDIA Jetson. This provides a fast, reliable data link for offloading complex processing, computer vision tasks, or running high-level mission planning software alongside the core flight controller.

Package Includes

  • 1x Pixhawk 5X Flight Controller Module
  • 1x Standard Set v2A
  • 1x PM02D HV Power Module
  • 1x Cable Set
  • 1x M9N GPS Module

Additional Information

Weight 0.299 kg
Dimensions 15 × 9 × 8 cm