SKU: SENS-2933
📋 GST Invoice Available

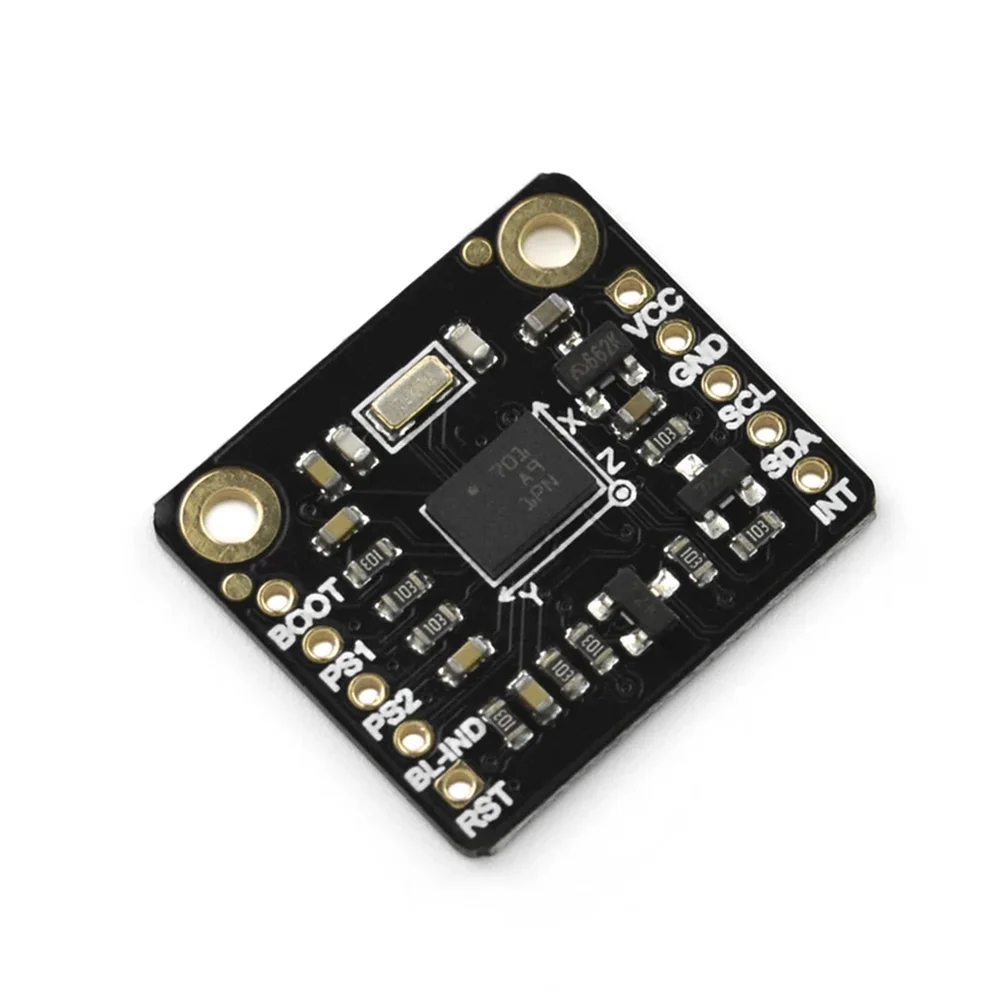
DFRobot Fermion BNO055 Intelligent 9-Axis Sensor Breakout - I2C IMU

₹1,989.00 (Inclusive of all taxes)
Out of Stock

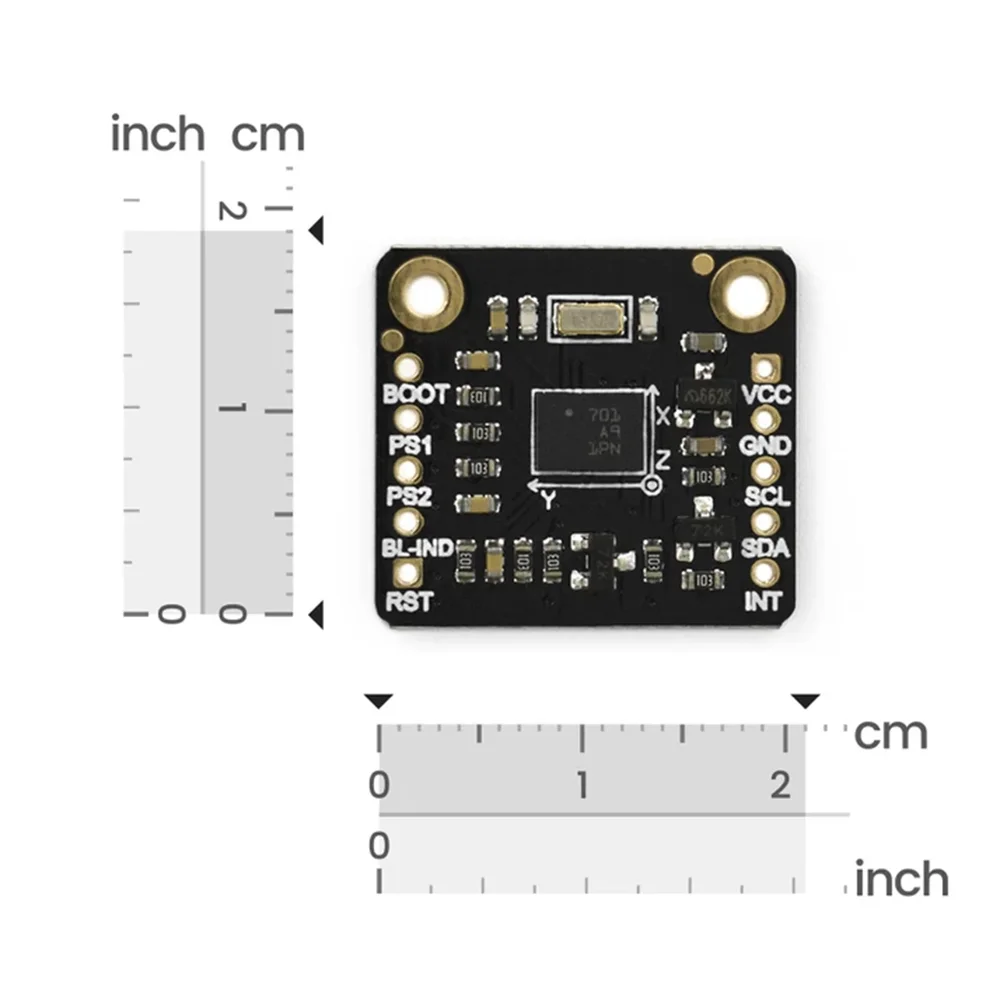
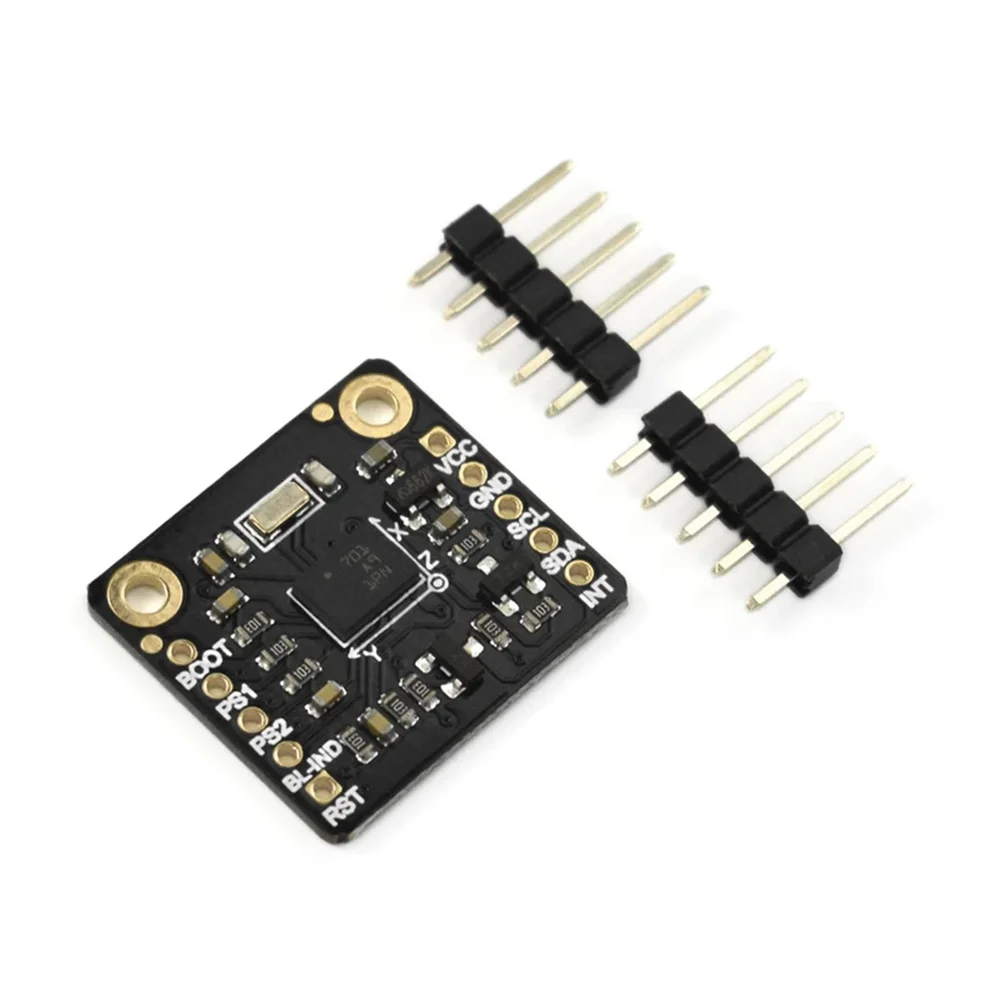
The DFRobot Fermion BNO055 is an intelligent 9-axis absolute orientation sensor breakout module, integrating a triaxial accelerometer, gyroscope, and geomagnetic sensor with a 32-bit fusion processor. It provides direct quaternion, Euler angle, and Vector Technics outputs via I2C, making it ideal for robotics, drones, and wearable devices compatible with 3.3V/5V systems like Arduino, Raspberry Pi, and ESP32.

Features

  • All-in-one 9-axis sensor fusion (accelerometer, gyroscope, magnetometer)
  • Integrated 32-bit microcontroller provides direct quaternion, Euler angle, and Vector Technics outputs
  • Wide operating voltage range from 3.3V to 5.5V with I2C communication
  • Configurable accelerometer (±2g to ±16g) and gyroscope (±125°/s to ±2000°/s) ranges
  • Compact breakout board format for easy prototyping and integration

Out of stock

Description

The BNO055 is a System-in-Package (SiP) sensor hub that combines a triaxial 14-bit accelerometer, a triaxial 16-bit gyroscope, and a triaxial geomagnetic sensor with a dedicated 32-bit microcontroller for sensor fusion. This integration offloads complex motion processing algorithms from the host controller, providing stable and accurate absolute orientation data directly.

Designed for high-precision motion tracking, the module outputs fused data such as quaternions and Euler angles, eliminating the need for developers to implement Kalman filters or other sensor fusion algorithms. Its low-power operation and small form factor make it suitable for battery-powered applications including smartphones, wearable devices, drones, and robotic navigation systems.

Key Features

  • Intelligent 9-axis absolute orientation sensor with integrated fusion processor
  • Provides direct output of quaternions, Euler angles (roll, pitch, yaw), and linear acceleration vectors
  • Selectable full-scale ranges for accelerometer (±2g, ±4g, ±8g, ±16g) and gyroscope (±125°/s, ±250°/s, ±500°/s, ±1000°/s, ±2000°/s)
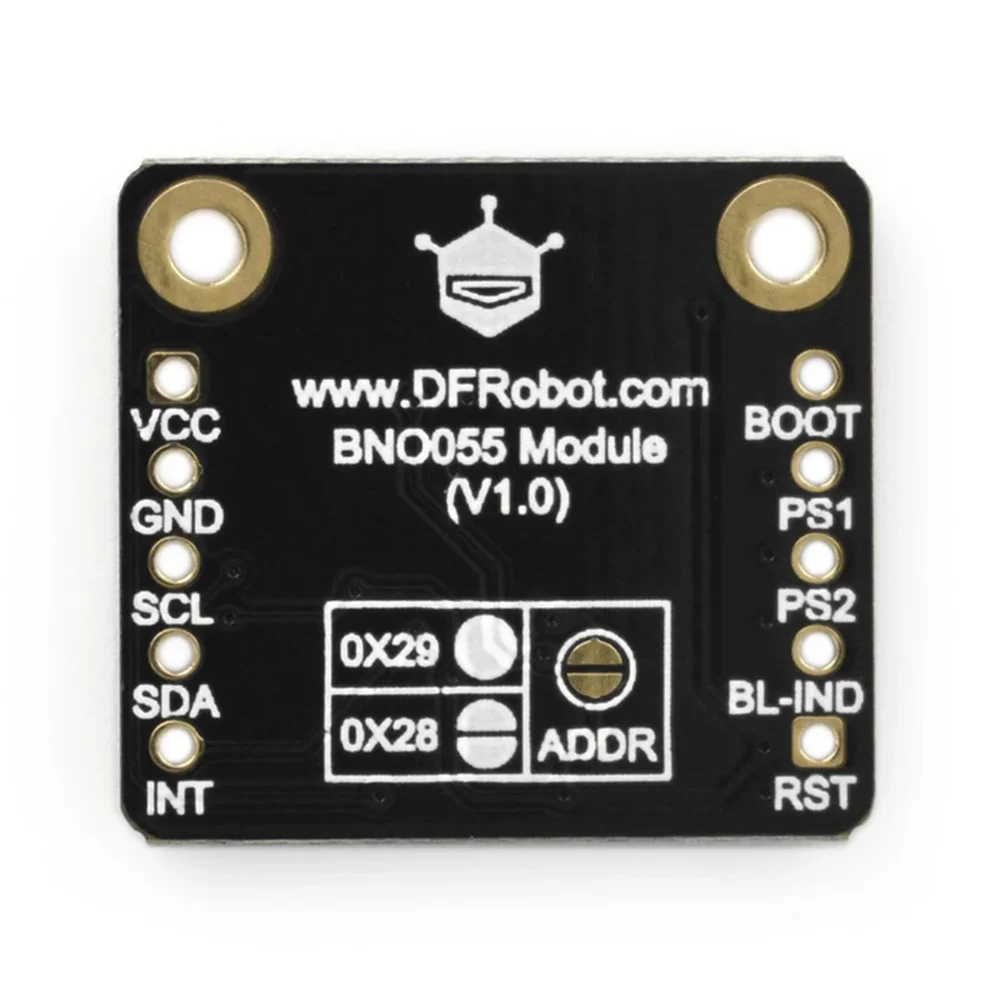
  • I2C digital interface with a default address of 0x28, compatible with 3.3V and 5V logic levels
  • Compact sensor IC (5.2 x 3.8 x 1.1 mm) mounted on a user-friendly Fermion breakout board
  • Low-power architecture suitable for portable and battery-operated devices
  • Simplifies complex inertial measurement unit (IMU) integration for robotics and navigation projects

Applications

  • Robotic platform stabilization and inertial navigation
  • Drone and UAV flight controller attitude and heading reference systems (AHRS)
  • Virtual reality (VR) and augmented reality (AR) headset motion tracking
  • Wearable device gesture recognition and activity monitoring
  • Camera gimbal stabilization and pan-tilt control systems

Technical Specifications

Operating Voltage3.3V - 5.5V
Communication InterfaceI2C
I2C AddressDefault 0x28
Accelerometer TypeTriaxial, 14-bit
Accelerometer Range±2g, ±4g, ±8g, ±16g (selectable)
Gyroscope TypeTriaxial, 16-bit
Gyroscope Range±125°/s, ±250°/s, ±500°/s, ±1000°/s, ±2000°/s (selectable)
MagnetometerTriaxial geomagnetic sensor
Output DataQuaternions, Euler Angles, Vectors, Raw Sensor Data
ProcessorIntegrated 32-bit microcontroller
PackageBreakout Board

Frequently Asked Questions

What is the default I2C address of the BNO055 breakout, and can it be changed?

The default I2C address is 0x28. The BNO055 IC itself supports a secondary address, but the DFRobot Fermion breakout typically hardwires it to the default address. For systems requiring multiple identical sensors, an I2C multiplexer is recommended.

Does this module require calibration, and how is it performed?

Yes, for optimal accuracy, the accelerometer, gyroscope, and magnetometer require calibration. The built-in fusion processor manages this. Calibration involves placing the sensor in specific orientations (for accelerometer/gyroscope) and performing a 'figure-eight' motion (for magnetometer) to compensate for hard and soft iron distortions. Status is available via the I2C register map.

Can I use this sensor with both 3.3V and 5V microcontrollers like Arduino?

Yes. The module's operating voltage range is 3.3V to 5.5V, and its I2C lines are compatible with both 3.3V and 5V logic levels. You can power it from either a 3.3V or 5V source on your development board and connect the I2C pins directly, making it suitable for Arduino Uno (5V), Raspberry Pi (3.3V), ESP32, and others.

What is the difference between raw sensor data and the fused orientation outputs?

The module provides both raw, uncorrected data from each individual sensor and fused, processed data. The raw data requires external processing for orientation. The fused outputs (quaternions, Euler angles) are computed internally by the 32-bit MCU using a sensor fusion algorithm, providing stable, drift-corrected absolute orientation directly, simplifying application development.

Package Includes

  • 1 x DFRobot Fermion BNO055 Intelligent 9-axis Sensor Breakout

Additional Information

Weight 0.02 kg
Dimensions 6 × 7 × 3 cm