SKU: IOWC-0206
📋 GST Invoice Available

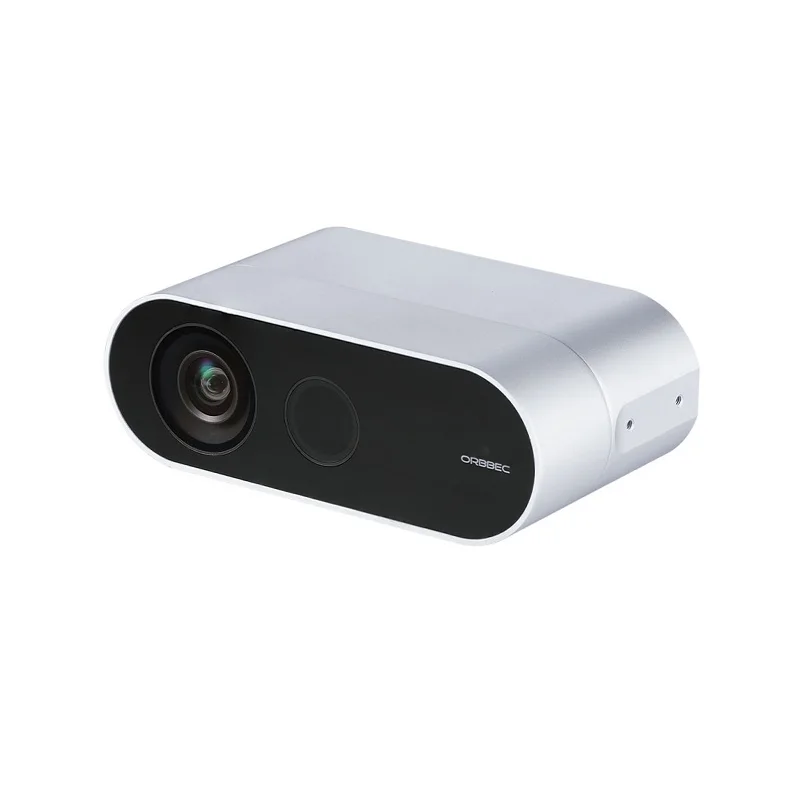
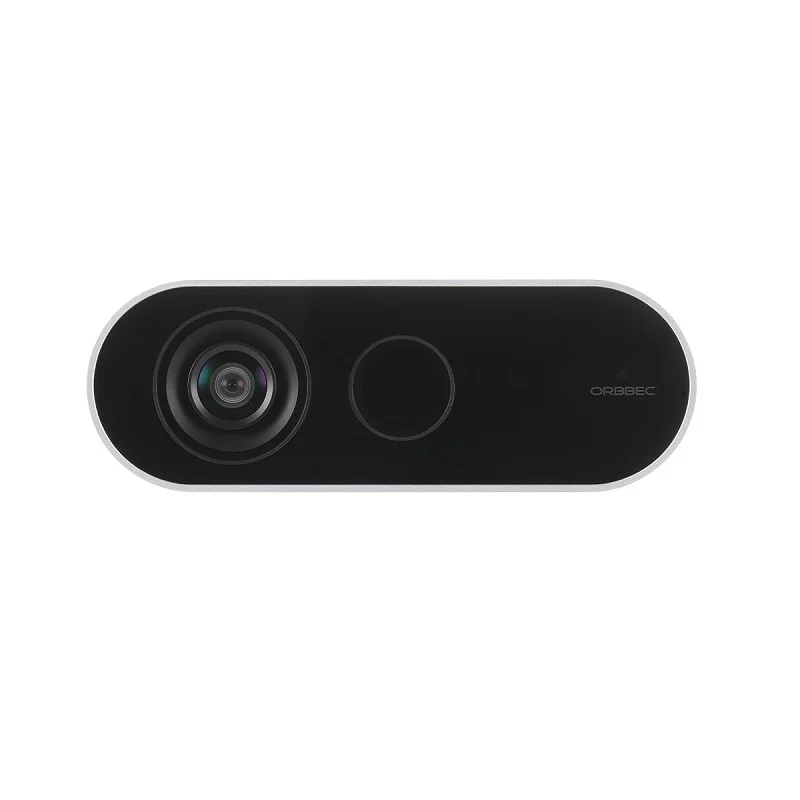
Orbbec Femto Bolt iToF 3D Camera w/ 1MP Depth & 4K RGB

₹63,209.00 (Inclusive of all taxes)
Out of Stock

The Orbbec Femto Bolt is a compact iToF 3D camera featuring a 1-megapixel depth sensor and 4K RGB with HDR, powered via USB-C 3.2. It provides synchronized depth and color streams for Windows/Linux SDKs, ideal for robotics and 3D vision applications.

Features

  • High-precision iToF depth sensor delivers 1024×1024 resolution at up to 15 fps with a 120° field of view.
  • Integrated 4K RGB camera with HDR enables detailed color overlay and scene context for 3D reconstruction.
  • Onboard 6-DoF IMU provides motion tracking data at 50-2000Hz for sensor fusion and pose estimation.
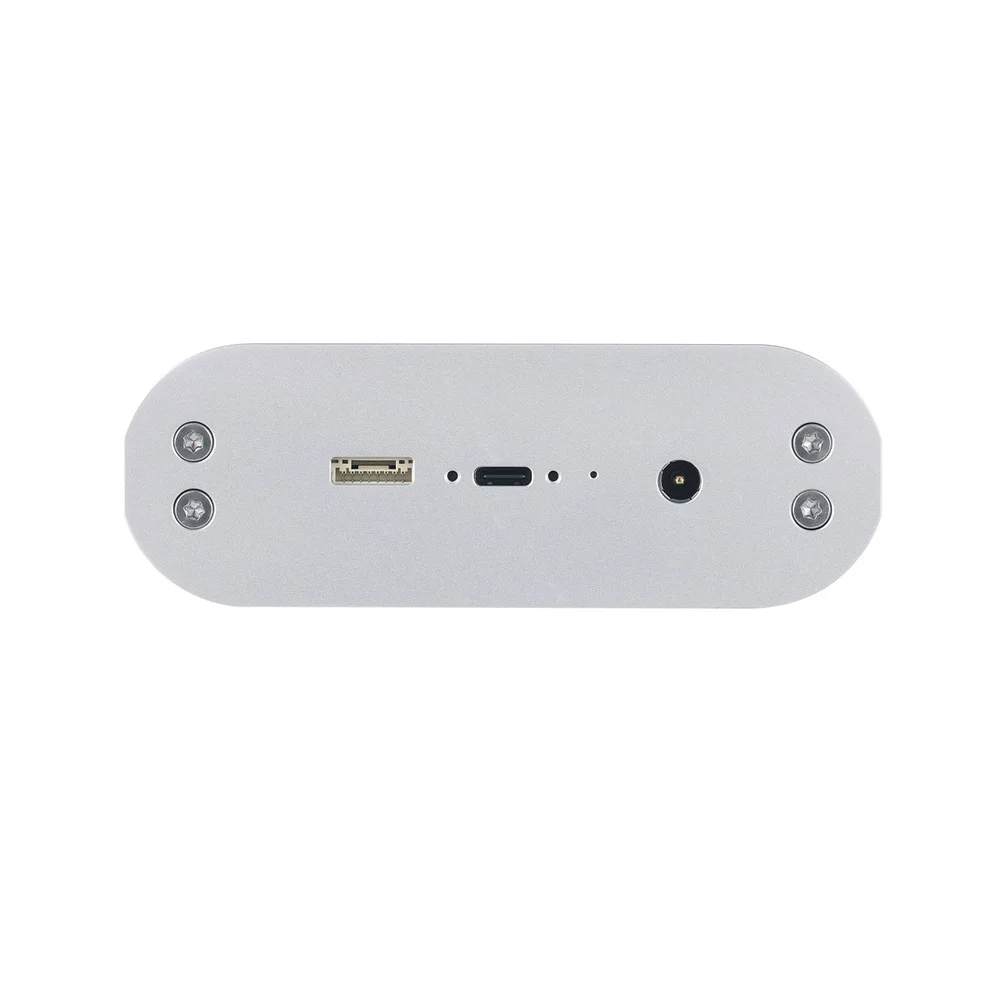
  • USB Type-C 3.2 Gen 1 interface consolidates power, data, and sophisticated trigger/sync control for multi-sensor setups.
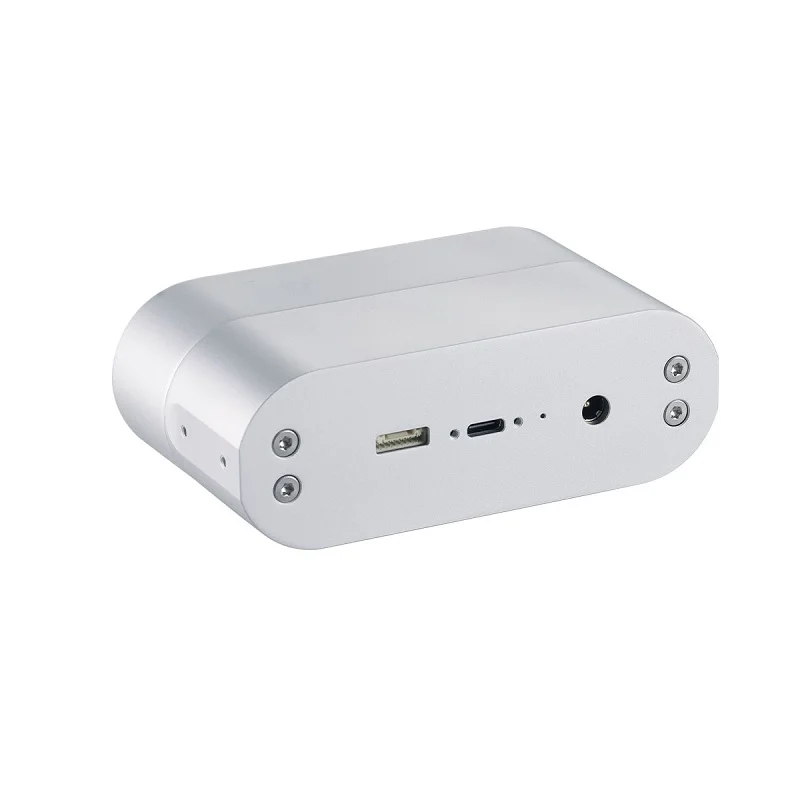
  • Compact form factor (115x65x40mm) and low 4.35W average power consumption suit embedded and mobile robotic platforms.

Out of stock

Description

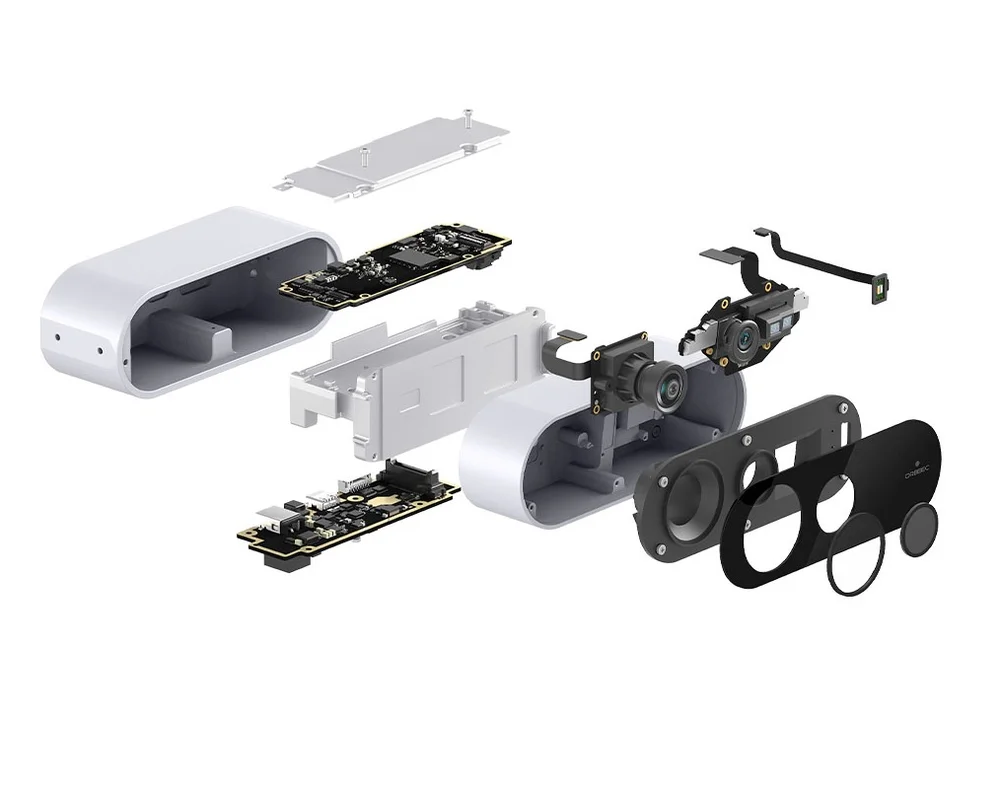
The Orbbec Femto Bolt iToF 3D Camera leverages Microsoft’s proven indirect Time-of-Flight technology, offering performance parity with industrial-grade sensors like the Azure Kinect. Its multi-mode imaging system combines a global shutter IR sensor for depth mapping with a rolling shutter RGB sensor for high-fidelity color capture, synchronized via hardware trigger control.

Designed for AI developers and system integrators, the camera operates on a standard USB-C connection delivering both power and high-bandwidth data streams. This simplifies integration into robotic arms, autonomous mobile robots (AMRs), and human-computer interaction systems requiring real-time 3D perception.

Key Features

  • Indirect Time-of-Flight (iToF) depth sensing with 1-megapixel resolution and 120° wide field of view.
  • Synchronized 4K RGB video stream with High Dynamic Range for accurate color representation in varying lighting.
  • Integrated 6-axis inertial measurement unit (IMU) for real-time orientation and acceleration tracking.
  • USB 3.2 Gen 1 Type-C interface provides single-cable solution for power, data transfer, and external synchronization.
  • Hardware trigger and sync control pins enable precise multi-camera array or sensor fusion setups.
  • Compact, ruggedized enclosure designed for integration on collaborative robots and mobile platforms.
  • Comprehensive SDK support for Windows and Linux, including depth processing, point cloud generation, and camera calibration tools.
  • Low average power consumption (4.35W) enables operation from standard USB power delivery or an external 12V/2A adapter.

Applications

  • Collaborative robot (cobot) pick-and-place operations with 3D bin picking and obstacle avoidance.
  • Human body scanning and 3D reconstruction for virtual fitting, animation, and biometrics.
  • Indoor Autonomous Mobile Robot (AMR) navigation, SLAM, and environment mapping.
  • Industrial volume measurement, quality inspection, and logistics parcel dimensioning.
  • Interactive installations, gesture recognition, and augmented reality experiences.

Technical Specifications

Model / TechnologyFemto Bolt / iToF (Indirect Time-of-Flight)
Depth Sensor1 MP ToF, Global Shutter, 1024x1024 @ 15 fps max
RGB Camera4K with HDR, Rolling Shutter
Field of View (Depth)120°
IMU6-DoF, 50-2000Hz Frequency, Float Data Format
Data InterfaceUSB Type-C 3.2 Gen 1
Power InputDC 12V 2A or USB-C 5V 3A
Avg. Power Consumption4.35 Watts
Operating Temperature10°C to 25°C
Dimensions (LxWxH)115 mm x 65 mm x 40 mm
Weight335 grams

Frequently Asked Questions

What operating systems are supported by the Orbbec Femto Bolt SDK?

The Orbbec Femto Bolt is supported by official SDKs for both Windows (10/11) and Linux (Ubuntu 18.04/20.04) operating systems. The SDK provides libraries for depth stream acquisition, point cloud generation, camera calibration, and IMU data fusion. Developers can access sample code for applications like 3D reconstruction, body tracking, and multi-camera synchronization directly from Orbbec's developer portal.

How do I power the camera and what are the power requirements?

The camera can be powered either via the included 12V 2A DC power adapter connected to the USB-C port or directly from a USB-C port supporting 5V 3A power delivery. The average power consumption is 4.35 watts. For reliable operation with both depth and RGB streams active, using the provided 12V adapter is recommended, especially in multi-camera setups or when using external synchronization triggers.

Can multiple Femto Bolt cameras be synchronized for 3D scanning?

Yes, multiple Femto Bolt cameras can be hardware-synchronized using the external trigger and sync control pins. This allows for precise timestamp alignment of depth and RGB frames across all units, essential for volumetric capture and large-scale 3D reconstruction. The SDK includes examples for configuring one camera as a master to generate a trigger signal, with others set as slaves, ensuring sub-millisecond frame alignment.

What is the effective range and accuracy of the depth sensor?

While exact minimum/maximum range specs are model-dependent, the iToF technology in the Femto Bolt provides high precision at short to medium ranges typical for indoor applications. Accuracy is optimized for scenarios like robotic arm manipulation (0.3-1.5m) and human-scale interaction. Performance is comparable to the Microsoft Azure Kinect, with depth noise and accuracy detailed in the technical datasheet available from Orbbec.

Package Includes

  • 1 x Orbbec Femto Bolt iToF 3D Camera
  • 1 x USB Type-C to USB Type-C Power & Data Cable
  • 1 x AC to DC Power Supply/Adapter (12V 2A)

Additional Information

Weight 0.335 kg
Dimensions 11.5 × 6.5 × 4 cm