SKU: DRFC-2069
📋 GST Invoice Available

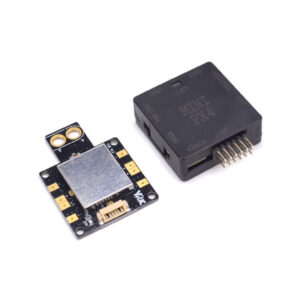
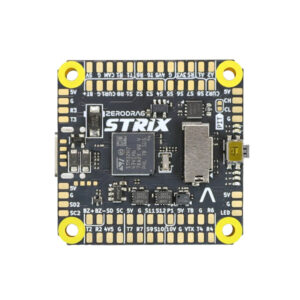
Pixhawk PX4 2.4.7 32-Bit Flight Controller for Quadcopter Multicopter

₹12,999.00 (Inclusive of all taxes)
Out of Stock

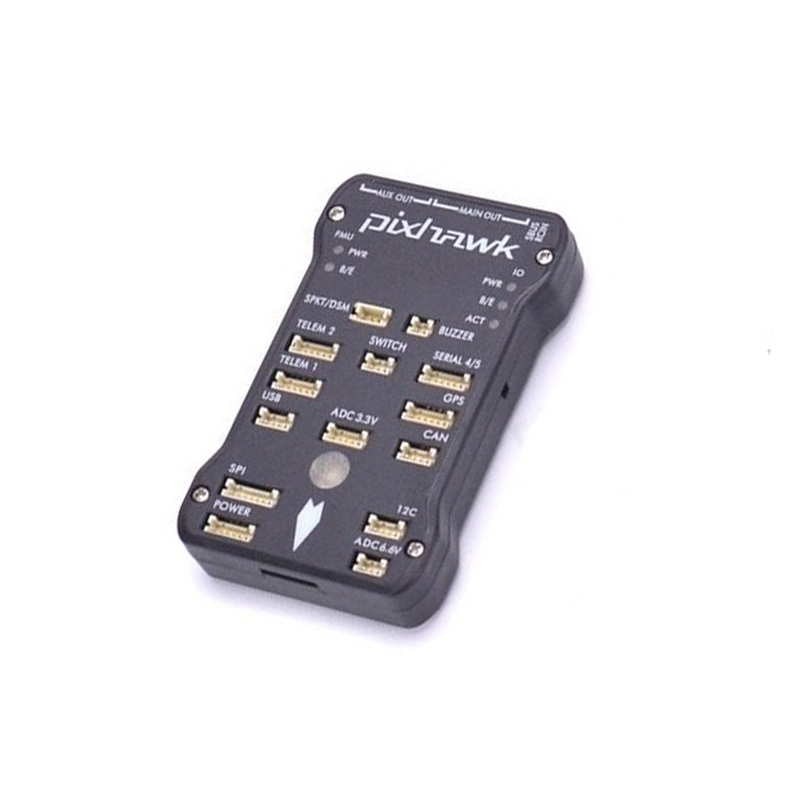
The Pixhawk PX4 2.4.7 is a 32-bit STM32F427 Cortex-M4 flight controller designed for advanced multirotor and fixed-wing UAVs, featuring a dedicated failsafe co-processor, extensive sensor suite, and compatibility with the PX4/ArduPilot ecosystem for autonomous flight operations.

Features

  • Dual-processor architecture with a 168 MHz STM32F427 Cortex-M4 main processor and an STM32F103 failsafe co-processor for robust in-flight recovery.
  • Comprehensive sensor suite includes an L3GD20H 16-bit gyroscope, LSM303D 14-bit accelerometer/magnetometer, MPU6000 IMU, and an MS5611 barometer for precise navigation.
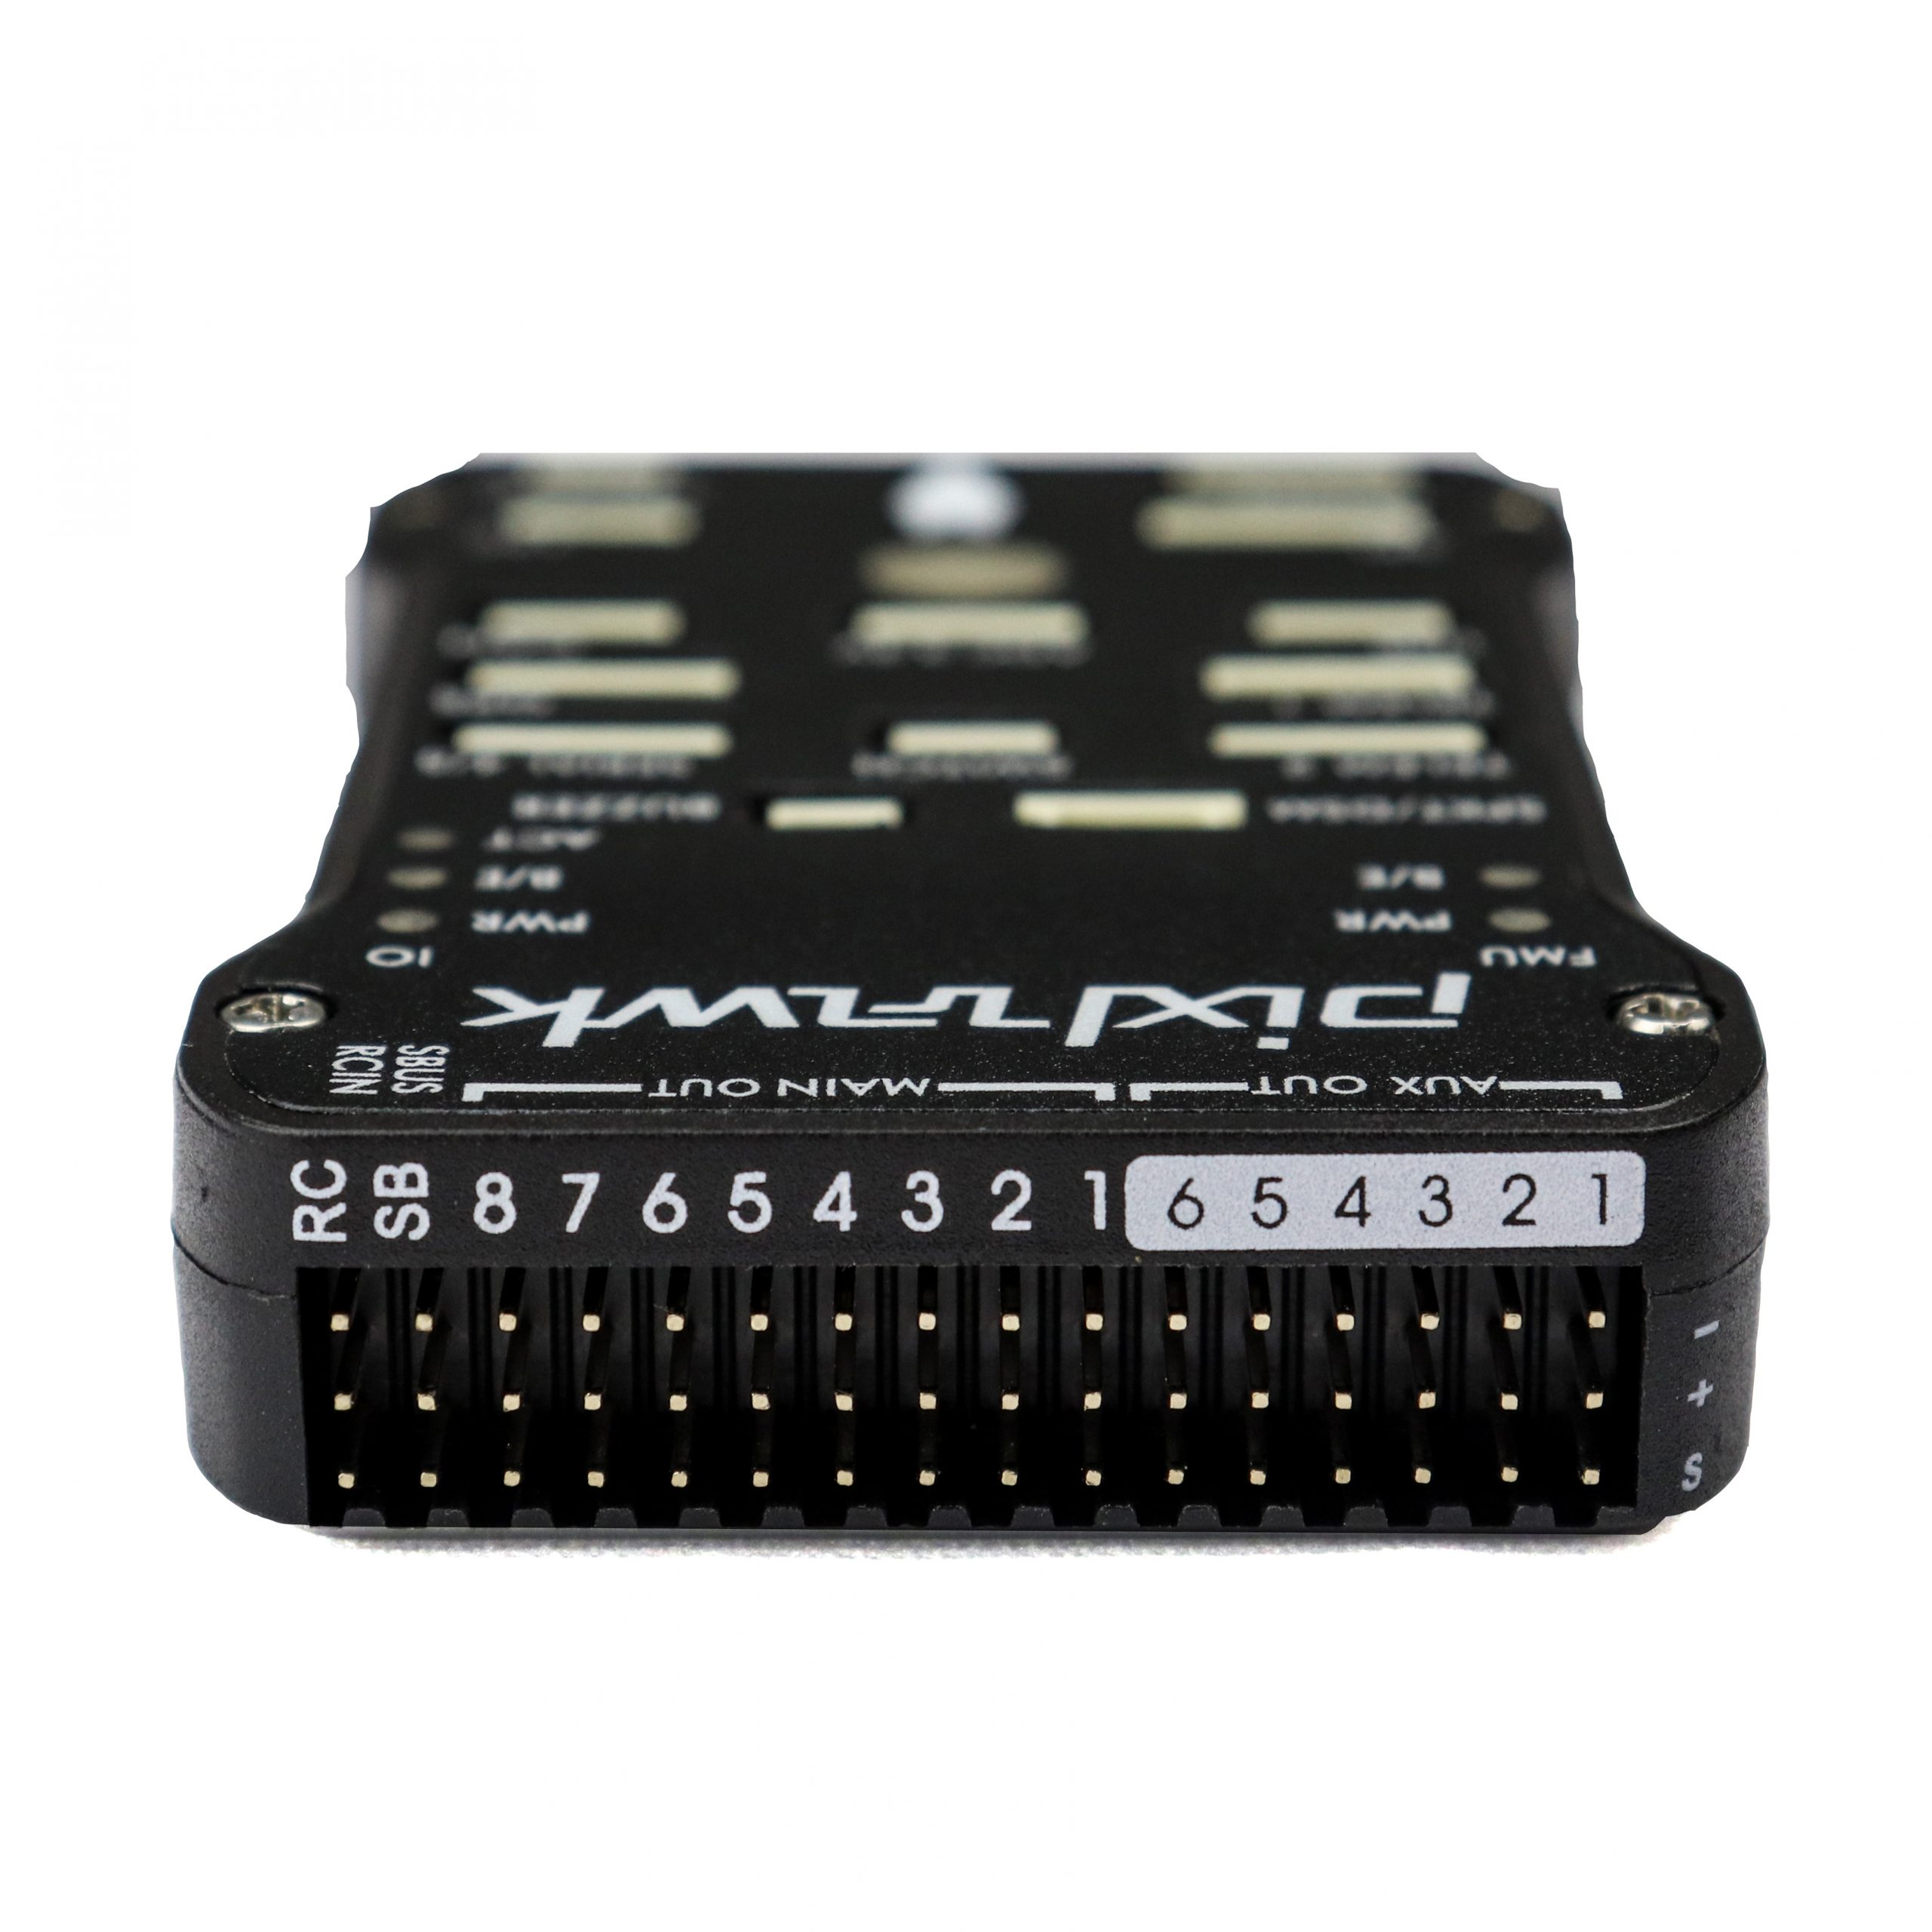
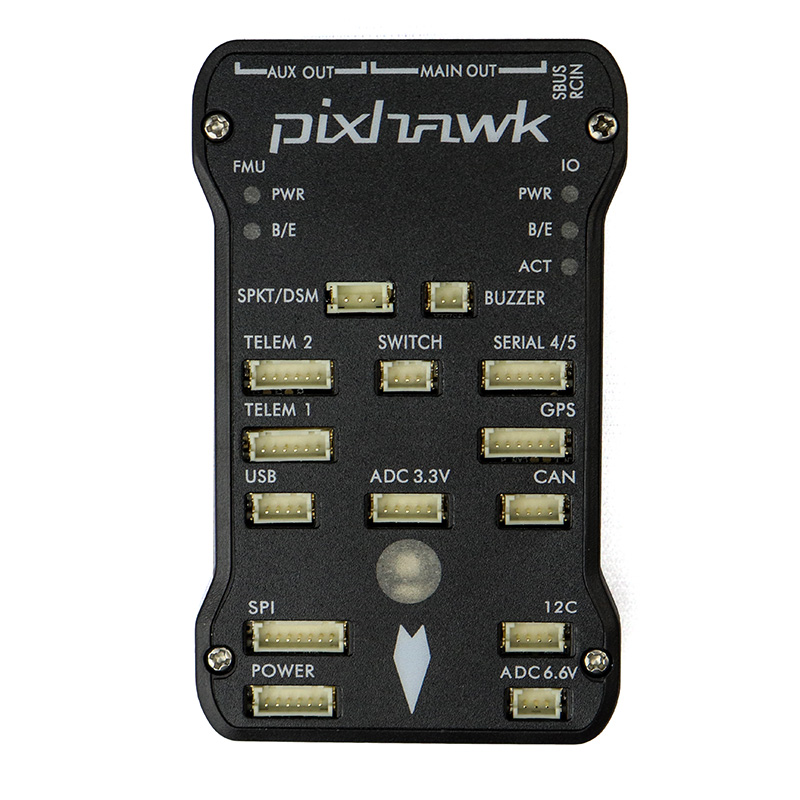
  • Extensive connectivity with 5x UART serial ports, 2x CAN bus interfaces, S.BUS, DSM, PPM, I2C, and SPI for peripheral expansion.
  • Redundant power input with automatic failover and servo rail support up to 10V/10A, with all outputs over-current protected.
  • Integrated microSD slot for high-rate flight data logging and compatibility with Mission Planner and QGroundControl ground station software.

Out of stock

Description

The Pixhawk PX4 2.4.7 flight controller represents a mature and highly capable open-source autopilot platform. Its core is built around a high-performance STM32F427 Cortex-M4 processor running the NuttX real-time operating system, providing the computational power needed for complex autonomous missions, precise stabilization, and sensor fusion algorithms. The dedicated STM32F103 co-processor acts as an independent failsafe system, enabling manual override and mixing for fixed-wing applications, ensuring vehicle recovery in the event of a main processor fault.

Engineered for system reliability, the board features a redundant power supply architecture with ideal diode controllers for automatic input switching. Its extensive I/O portfolio, including multiple UARTs with hardware flow control and CAN bus interfaces, allows for seamless integration of peripherals such as telemetry radios, GPS modules, optical flow sensors, and gimbals. The robust sensor array provides accurate attitude estimation and navigation data, forming the foundation for stable flight in both manual and fully autonomous modes under the PX4 or ArduPilot firmware frameworks.

Key Features

  • Advanced 32-bit STM32F427 Cortex-M4 core with FPU operating at 168 MHz for high-speed flight control processing.
  • Dedicated STM32F103 failsafe co-processor provides independent manual override and backup control for enhanced flight safety.
  • Professional-grade sensor fusion from ST Micro L3GD20H gyro, LSM303D accelerometer/magnetometer, Invensense MPU6000 IMU, and MEAS MS5611 barometer.
  • Robust connectivity suite with 5x UARTs (two with HW flow control), 2x CAN bus ports, Spektrum DSM/DSM2/DSM-X, Futaba S.BUS, PPM, and I2C/SPI.
  • Redundant 6-10V power inputs with automatic failover and a high-current servo rail capable of delivering over 10A.
  • Integrated microSD card slot for extensive, high-frequency flight data logging over extended mission durations.
  • All peripheral outputs are over-current protected, and all inputs feature ESD protection for increased hardware durability.
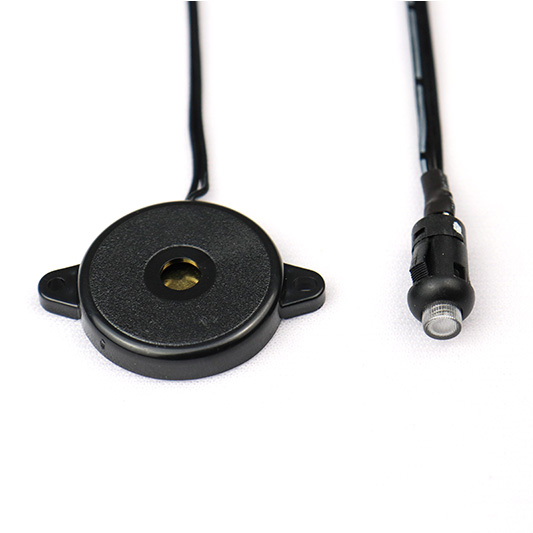
  • External safety switch and multi-tone buzzer interface for enhanced operational security and status indication.

Applications

  • Primary flight controller for custom-built 450-1000mm class quadcopters and hexacopters for aerial photography and mapping.
  • Autonomous fixed-wing UAV platform for long-range surveillance, agricultural surveying, and cargo delivery missions.
  • Advanced research and development platform for testing new sensor fusion algorithms, computer vision, and swarm robotics.
  • Heavy-lift multirotor builds requiring robust failsafe mechanisms and extensive peripheral connectivity for payload control.
  • Educational platform for university-level UAV engineering, robotics, and autonomous systems courses.

Technical Specifications

Model / NamePX4 2.4.7
Main Processor32-bit STM32F427 Cortex M4 with FPU @ 168 MHz
Failsafe Co-Processor32-bit STM32F103
RAM256 KB
Flash Memory2 MB
Input Voltage6 to 10 V DC
SensorsST Micro L3GD20H 16-bit Gyroscope, ST Micro LSM303D 14-bit Accelerometer/Magnetometer, Invensense MPU6000 3-axis Accelerometer/Gyroscope, MEAS MS5611 Barometer
Interfaces5x UART (serial ports), 2x CAN, Spektrum DSM/DSM2/DSM-X Satellite, Futaba S.BUS Input/Output, PPM, RSSI, I2C, SPI, 3.3V & 6.6V ADC
PWM/Servo Outputs14 total (8 with failsafe/manual override, 6 auxiliary)
MicroSD SlotYes
Operating SystemNuttX RTOS
FirmwarePX4, ArduPilot (via Mission Planner, QGroundControl)
Dimensions (L x W x H)82 x 50 x 16 mm
Weight39 g

Frequently Asked Questions

What is the input voltage range for the Pixhawk PX4 2.4.7 flight controller?

The Pixhawk PX4 2.4.7 accepts a nominal input voltage range of 6V to 10V DC. This is typically supplied via its primary and secondary power input ports from a LiPo battery through a power module or a regulated BEC. The board features redundant power inputs with automatic failover for increased reliability.

What firmware and ground control software is this flight controller compatible with?

This controller is designed for the open-source PX4 and ArduPilot firmware ecosystems. It is fully compatible with ground station software such as Mission Planner (for ArduPilot) and QGroundControl (for PX4). These programs allow for firmware flashing, parameter configuration, mission planning, and real-time telemetry monitoring.

What are the key differences provided by the dedicated failsafe co-processor?

The integrated STM32F103 co-processor provides a hardware-level failsafe and manual override system. It operates independently from the main processor, allowing for pilot control recovery if the main CPU fails. It also handles mixing for fixed-wing aircraft, ensuring smooth transition between autonomous and manual flight modes.

What peripherals and sensors can I connect to this flight controller?

The extensive I/O allows connection of u-blox GPS/compass modules, 915MHz or 2.4GHz telemetry radios, optical flow sensors, rangefinders, and CAN bus peripherals like ESCs or motor controllers. Its 5 UARTs, 2 CAN ports, I2C, and SPI buses support a wide ecosystem of expansion hardware for advanced autonomous functionality.

Package Includes

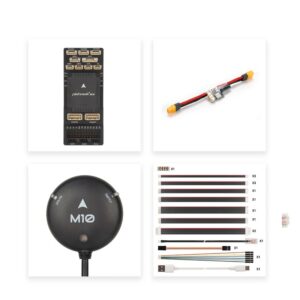
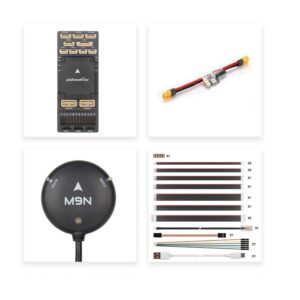
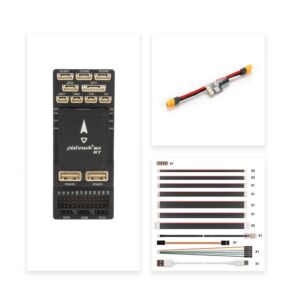
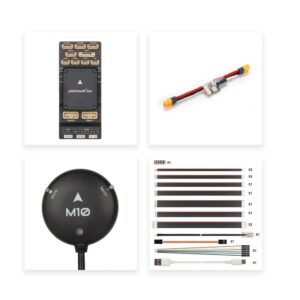
  • 1 x Pixhawk V2.4.7 Flight Controller Board with Original Shell
  • 1 x Teflon Safety Switch
  • 1 x Buzzer

Additional Information

Weight 0.039 kg
Dimensions 8.2 × 5 × 1.6 cm