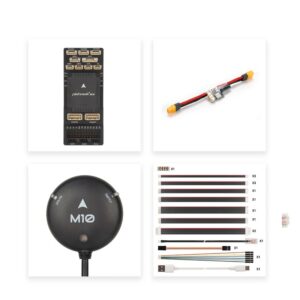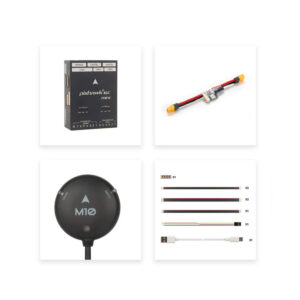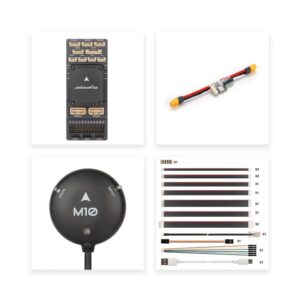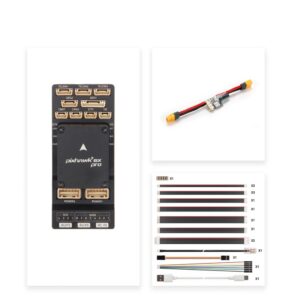
Pixhawk PX4 2.4.7 32-Bit Flight Controller for Quadcopter Multicopter
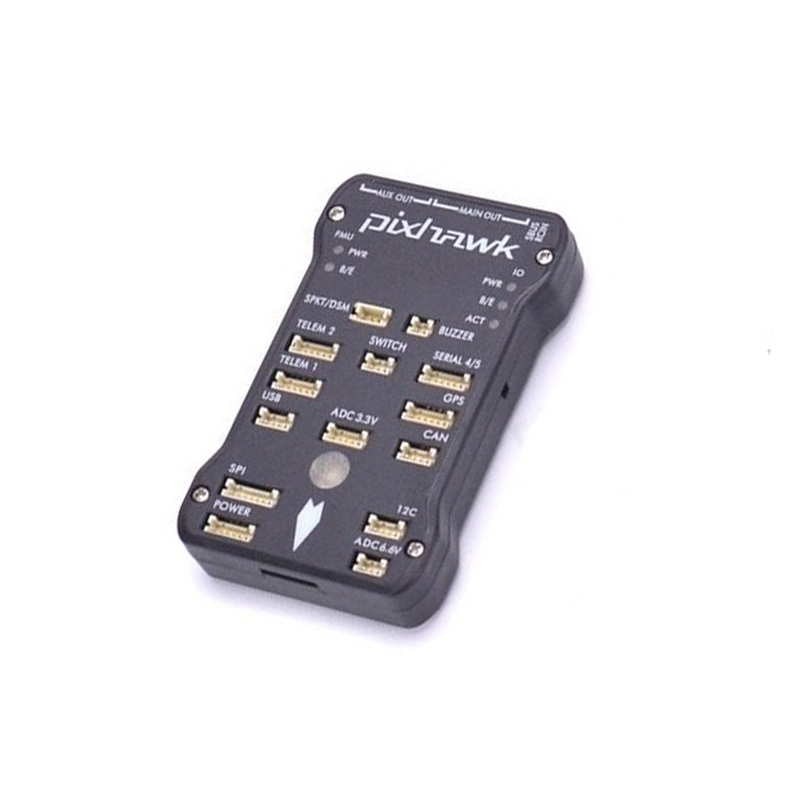
The Pixhawk PX4 2.4.7 is a 32-bit STM32F427 Cortex-M4 flight controller designed for advanced multirotor and fixed-wing UAVs, featuring a dedicated failsafe co-processor, extensive sensor suite, and compatibility with the PX4/ArduPilot ecosystem for autonomous flight operations.
Features
- Dual-processor architecture with a 168 MHz STM32F427 Cortex-M4 main processor and an STM32F103 failsafe co-processor for robust in-flight recovery.
- Comprehensive sensor suite includes an L3GD20H 16-bit gyroscope, LSM303D 14-bit accelerometer/magnetometer, MPU6000 IMU, and an MS5611 barometer for precise navigation.
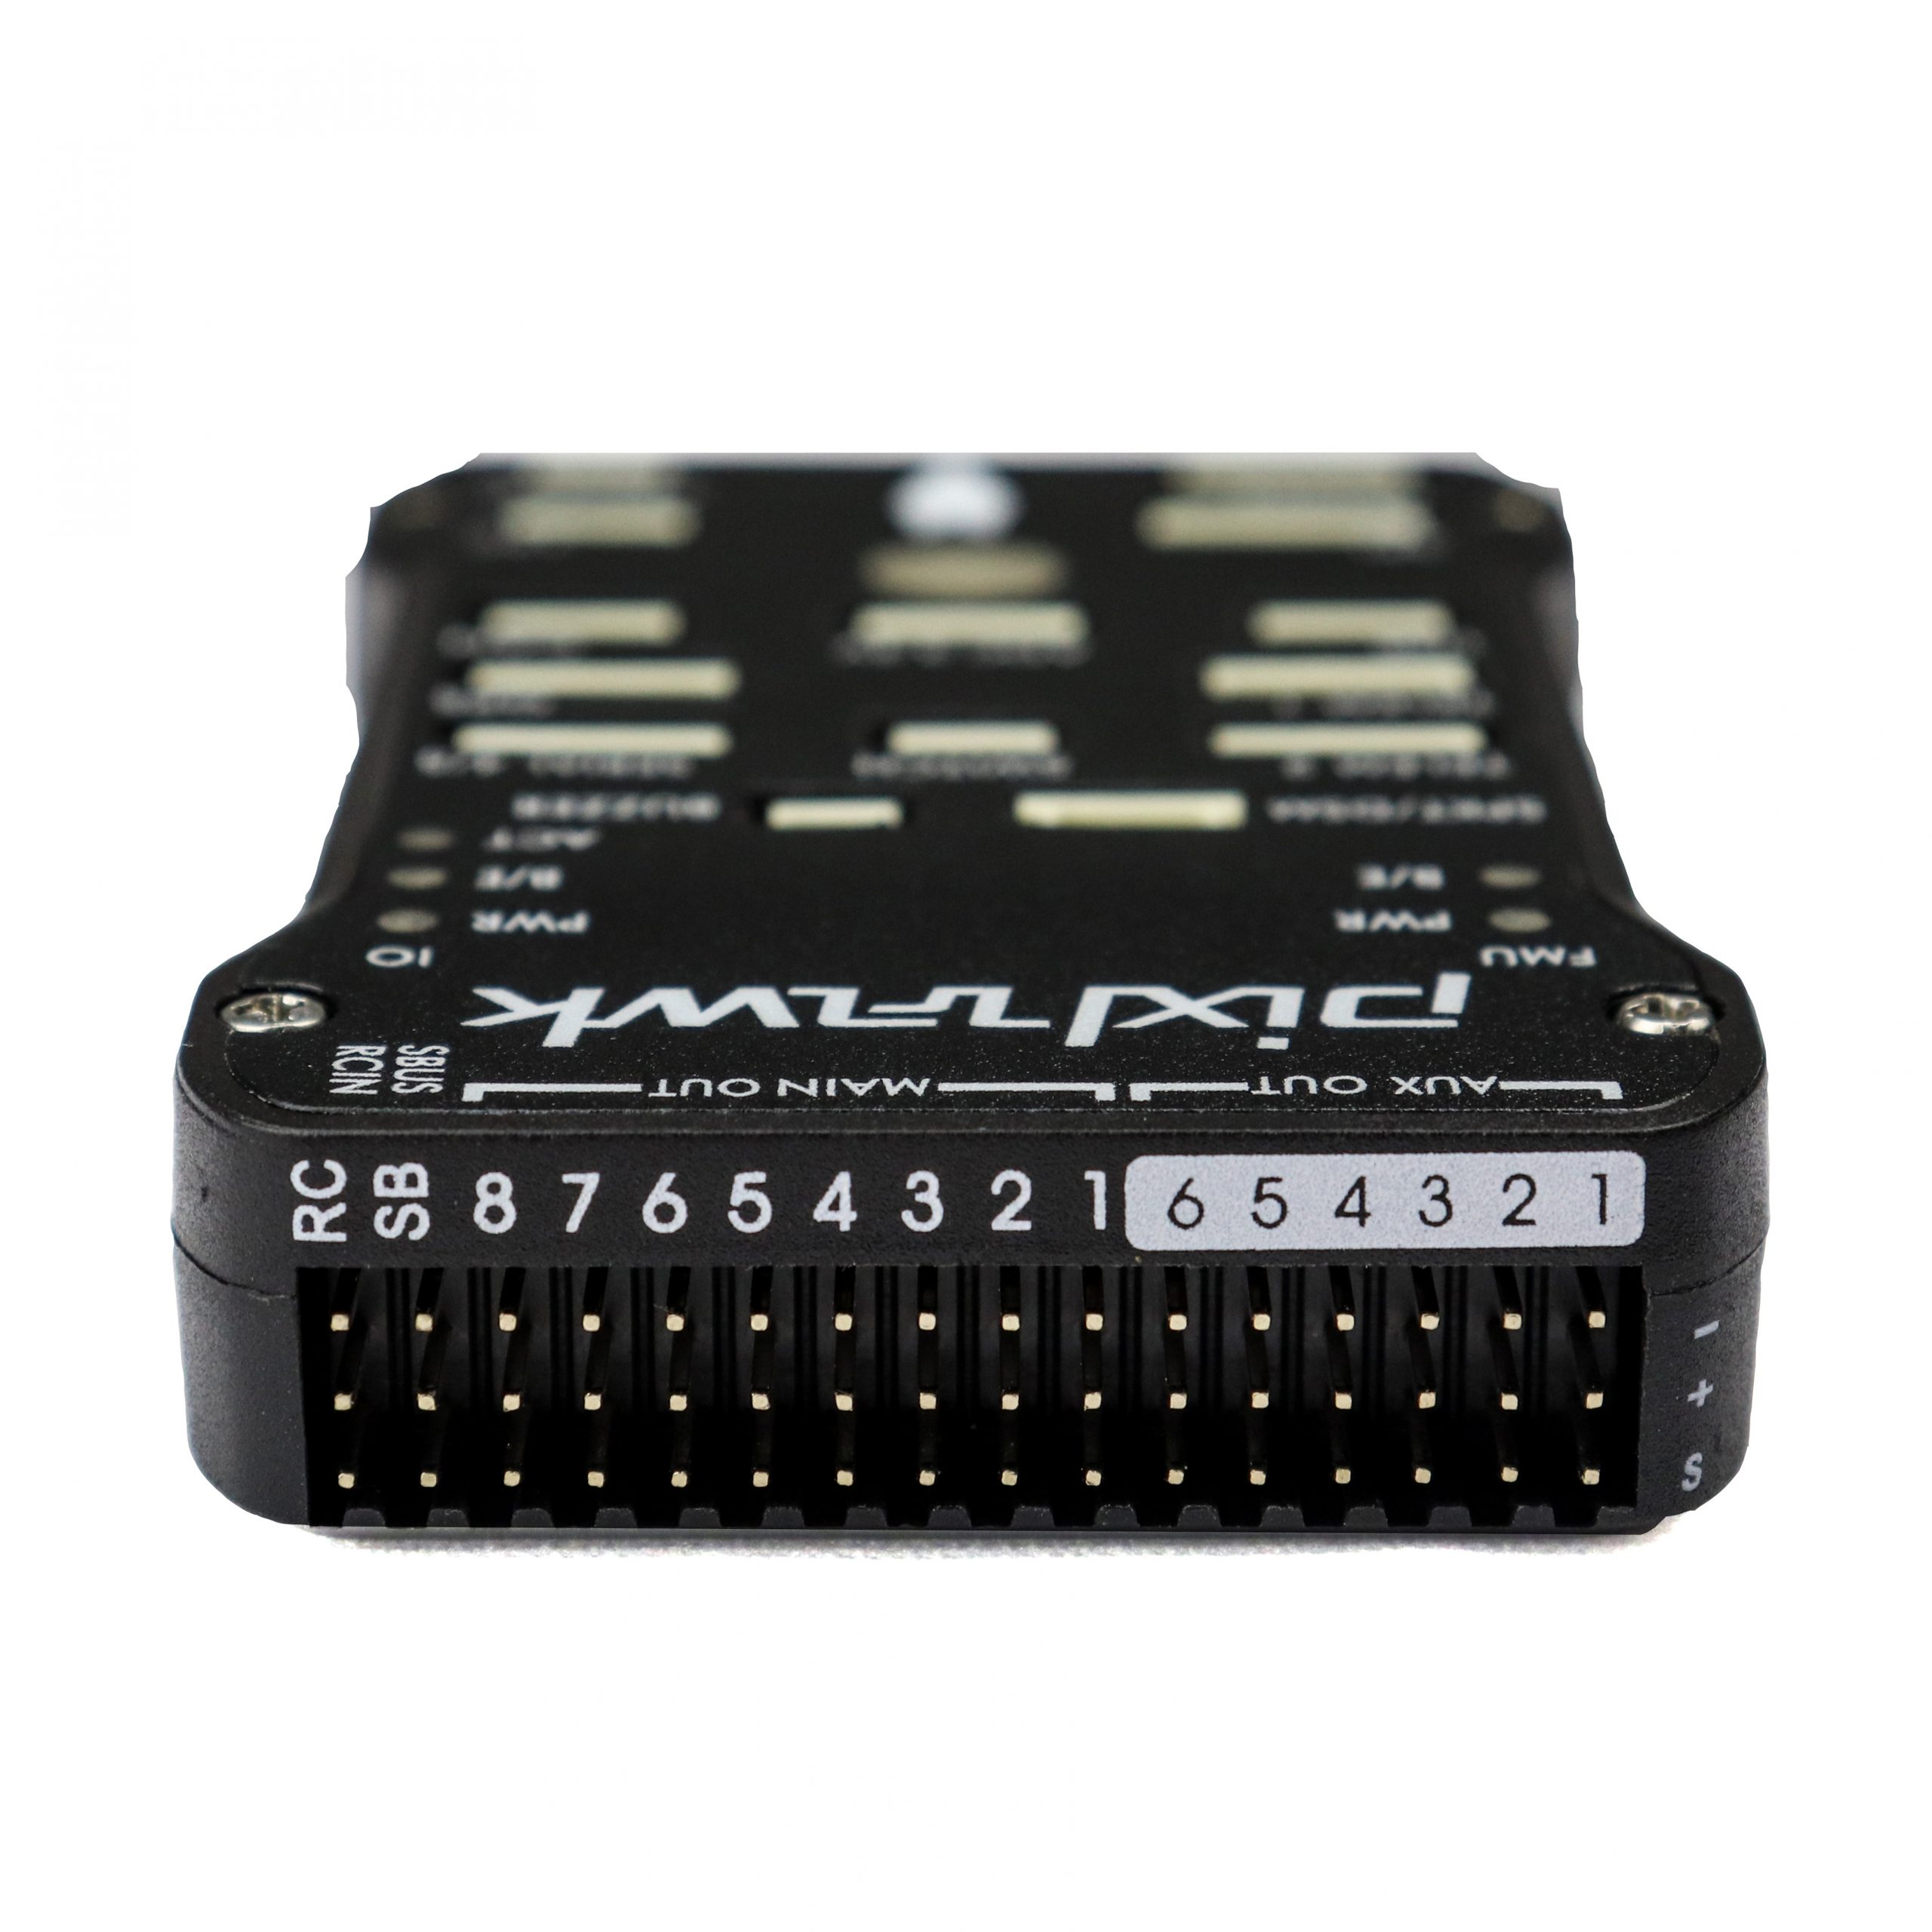
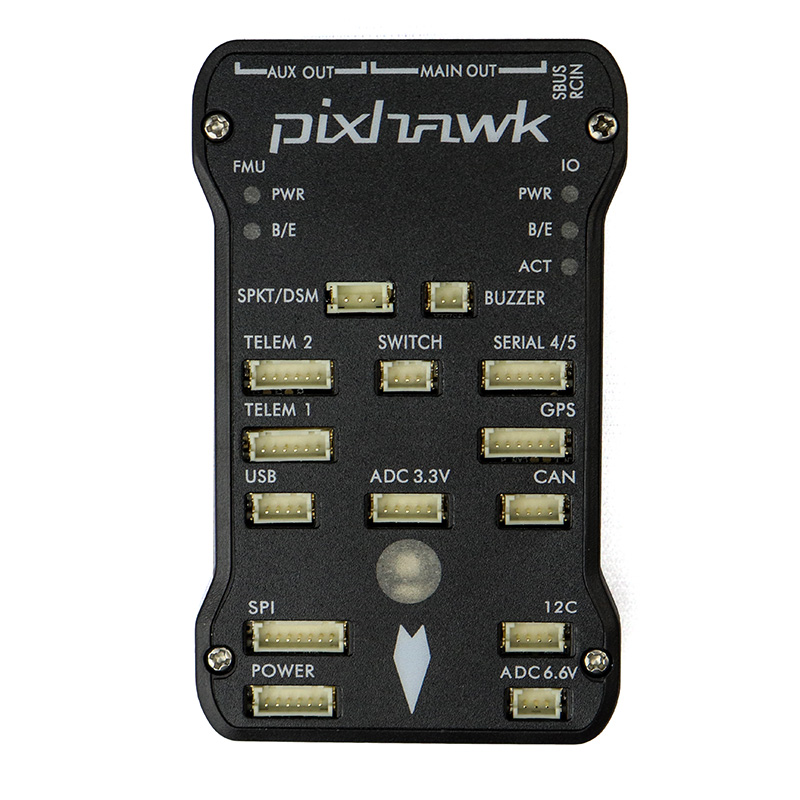
- Extensive connectivity with 5x UART serial ports, 2x CAN bus interfaces, S.BUS, DSM, PPM, I2C, and SPI for peripheral expansion.
- Redundant power input with automatic failover and servo rail support up to 10V/10A, with all outputs over-current protected.
- Integrated microSD slot for high-rate flight data logging and compatibility with Mission Planner and QGroundControl ground station software.
Out of stock
The Pixhawk PX4 2.4.7 flight controller represents a mature and highly capable open-source autopilot platform. Its core is built around a high-performance STM32F427 Cortex-M4 processor running the NuttX real-time operating system, providing the computational power needed for complex autonomous missions, precise stabilization, and sensor fusion algorithms. The dedicated STM32F103 co-processor acts as an independent failsafe system, enabling manual override and mixing for fixed-wing applications, ensuring vehicle recovery in the event of a main processor fault.
Engineered for system reliability, the board features a redundant power supply architecture with ideal diode controllers for automatic input switching. Its extensive I/O portfolio, including multiple UARTs with hardware flow control and CAN bus interfaces, allows for seamless integration of peripherals such as telemetry radios, GPS modules, optical flow sensors, and gimbals. The robust sensor array provides accurate attitude estimation and navigation data, forming the foundation for stable flight in both manual and fully autonomous modes under the PX4 or ArduPilot firmware frameworks.
Additional Information
| Weight | 0.039 kg |
|---|---|
| Dimensions | 8.2 × 5 × 1.6 cm |