SKU: DRFC-2034
📋 GST Invoice Available

RadioLink Pixhawk Flight Controller Board

₹15,389.00 (Inclusive of all taxes)
Out of Stock

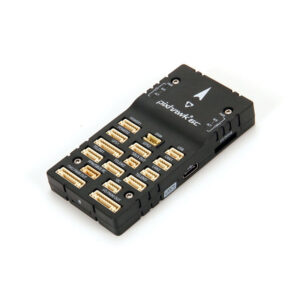
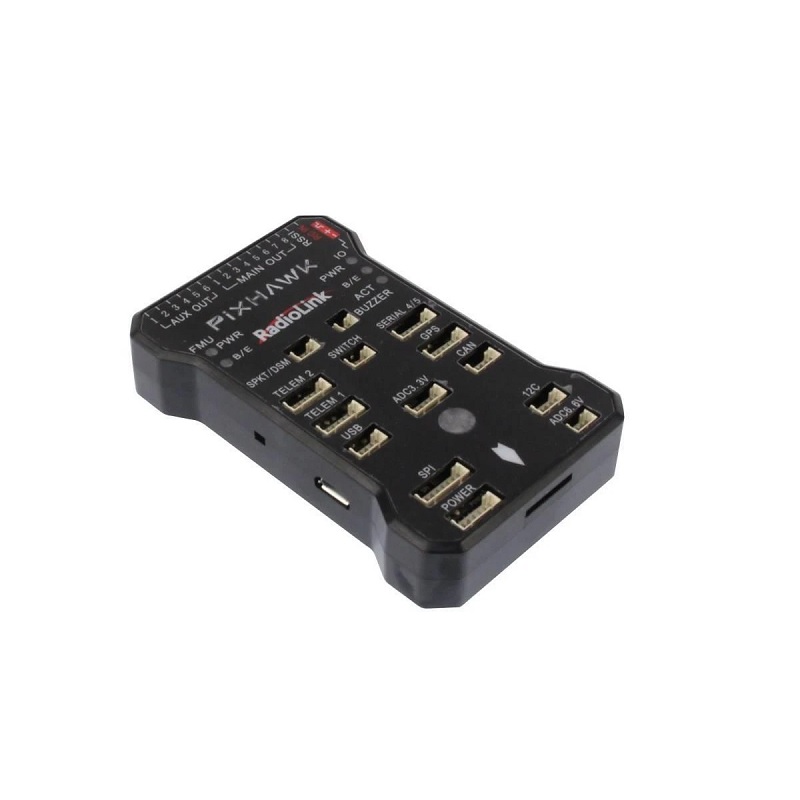
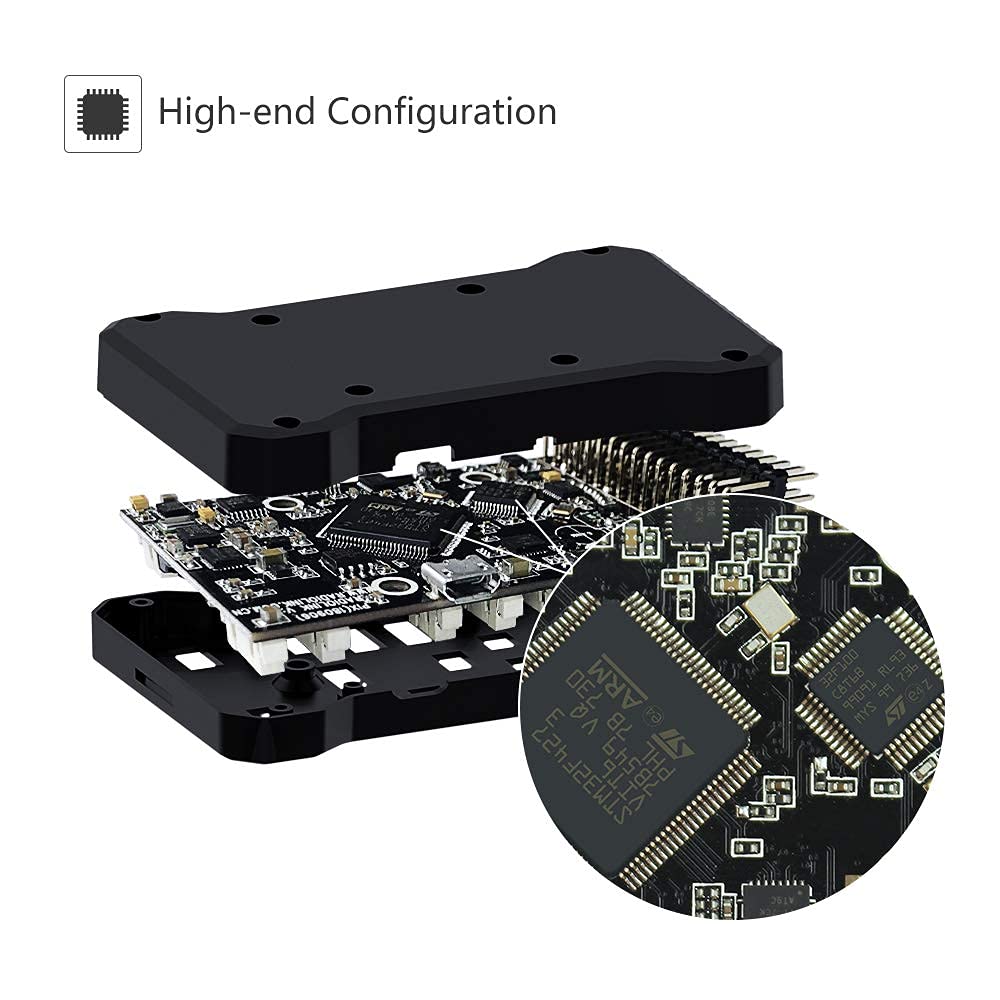
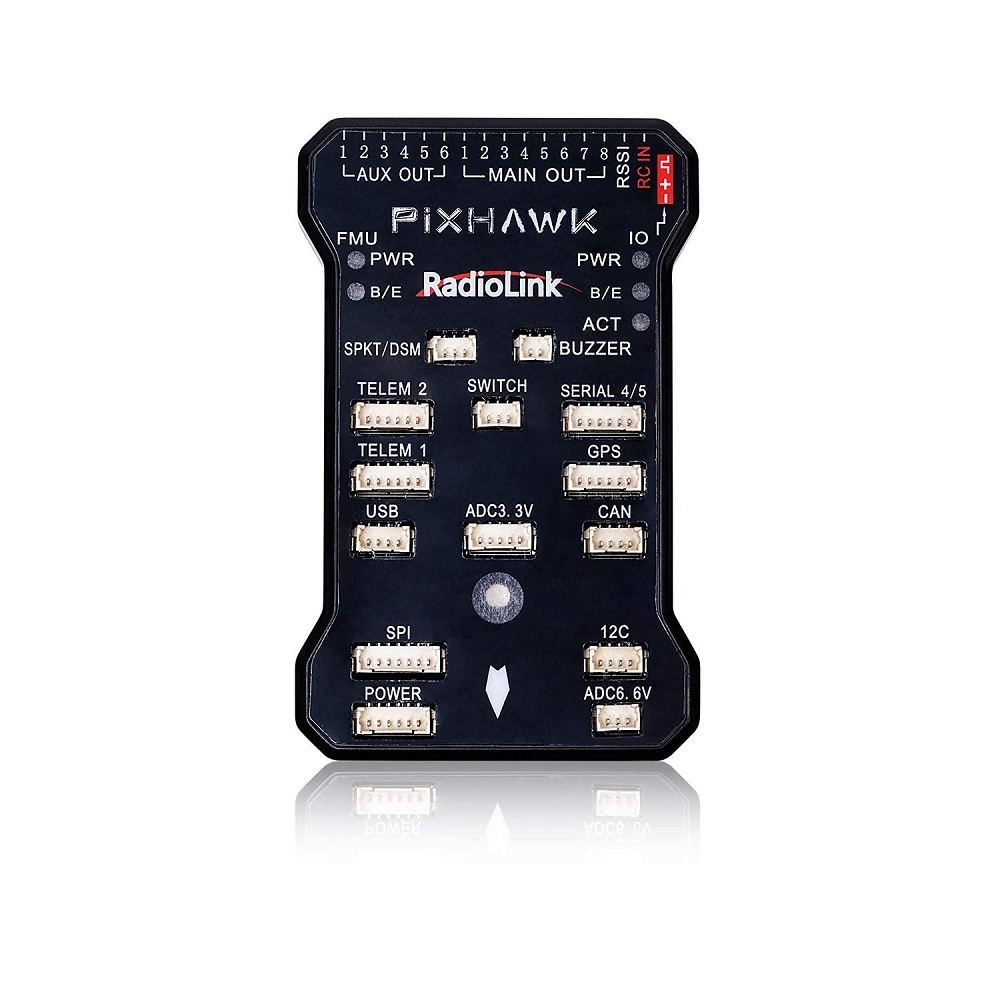
The RadioLink Pixhawk Flight Controller is a high-performance autopilot board built around a 32-bit STM32F427 Cortex M4 core, designed for multi-rotor, fixed-wing, and ground vehicle applications. It features a comprehensive sensor suite and extensive I/O for integration with GPS, telemetry, and peripherals within the ArduPilot and PX4 ecosystems.

Features

  • 32-bit STM32F427 Cortex M4 main processor (168MHz, FPU) with STM32F100 failsafe co-processor.
  • High-precision sensor suite: L3GD20H gyro, LSM303D accel/mag, MPU6000 IMU, and MS5611 barometer.
  • 14 PWM/servo outputs (8 with failsafe) supporting multi-rotor, fixed-wing, and helicopter models.
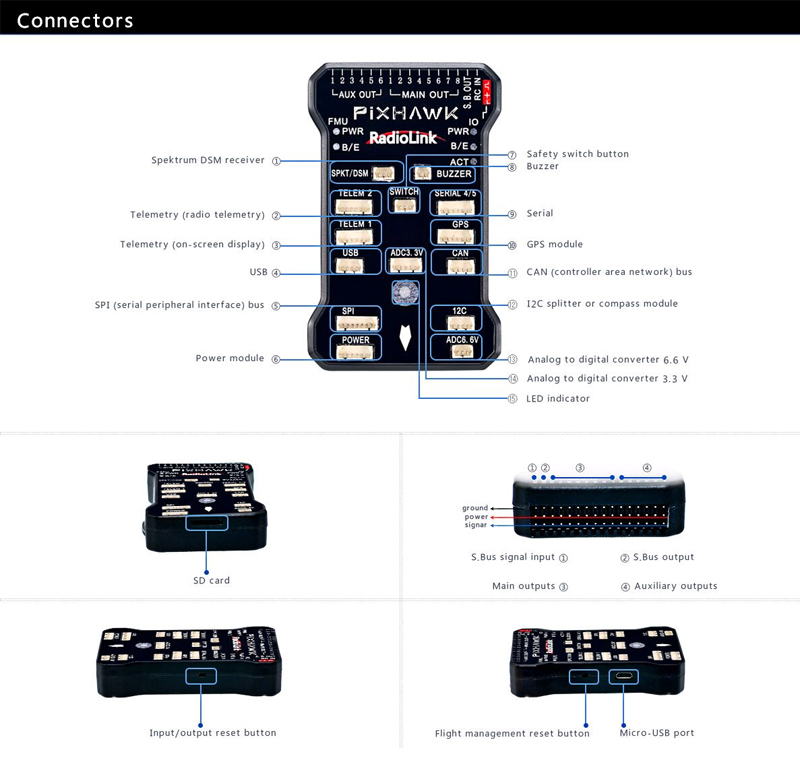
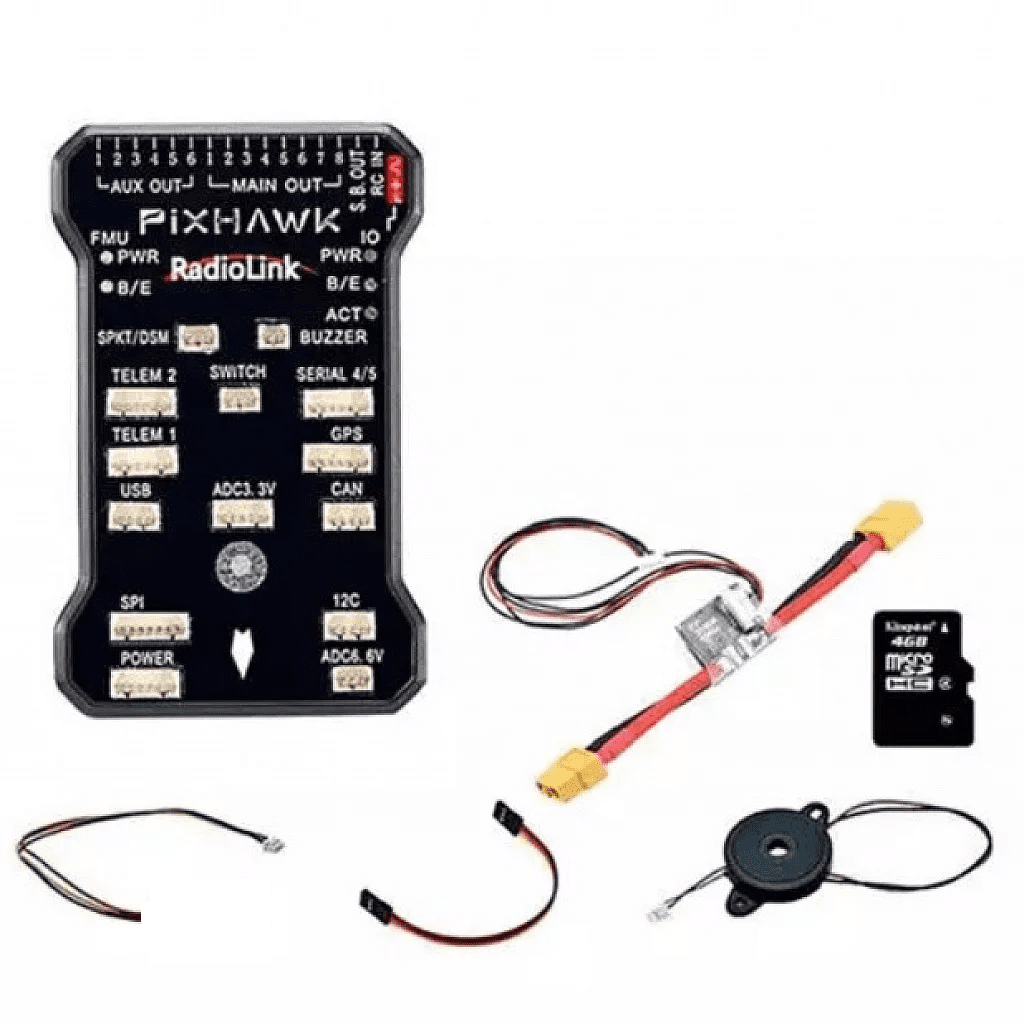
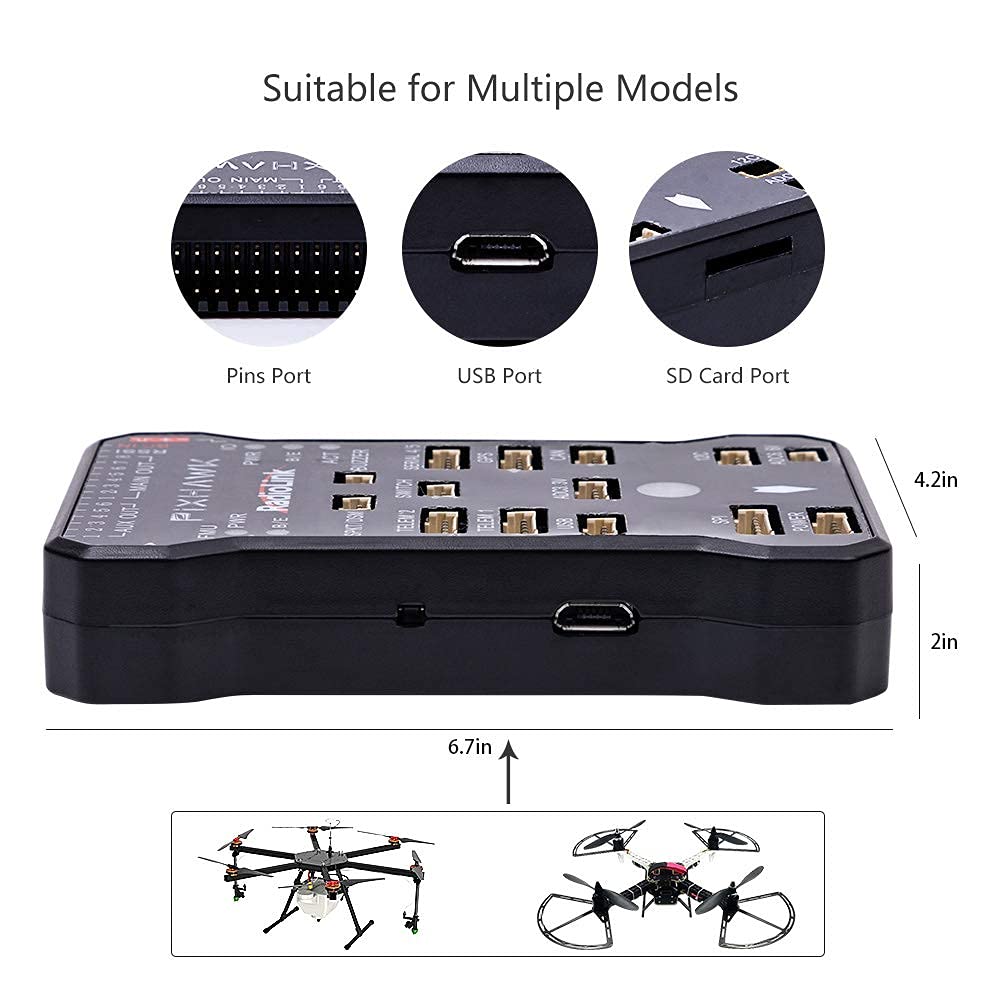
  • Extensive connectivity: dedicated ports for GPS, I2C, SPI, Spektrum DSM receivers, and telemetry.
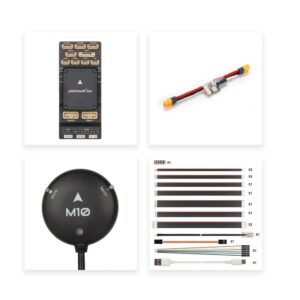
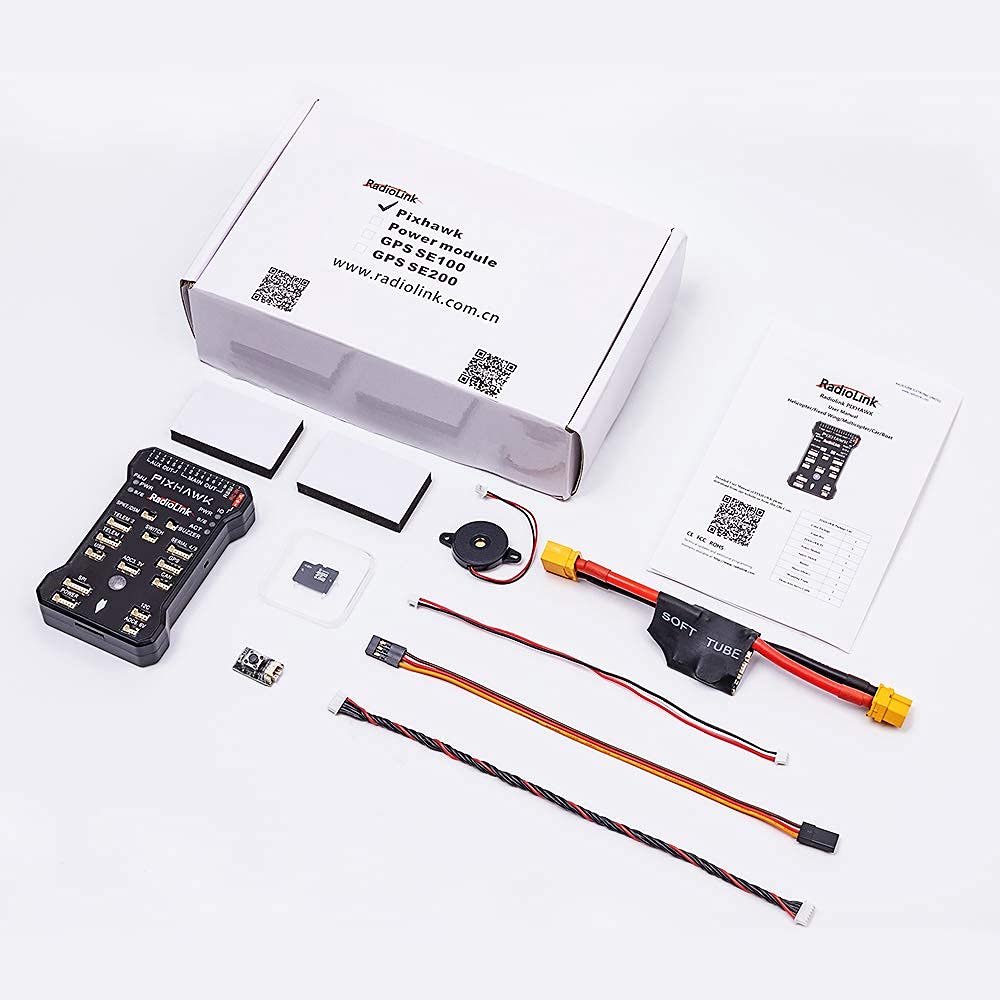
  • Includes power module, microSD card, safety switch, buzzer, and mounting accessories.

Out of stock

Description

The RadioLink Pixhawk Flight Controller delivers robust, open-source autopilot capabilities for advanced UAV platforms. Its optimized PCB layout and barometer isolation contribute to stable altitude hold and precise flight performance across a wide range of models, from agile quadcopters to long-endurance fixed-wing aircraft.

Engineered for reliability, the board integrates a dual-processor architecture. The primary STM32F427 handles high-rate flight control algorithms, while the secondary STM32F100 co-processor ensures continuous failsafe monitoring and manual override capabilities. This design is critical for professional and commercial drone operations requiring maximum operational safety.

Key Features

  • Dual-Processor Architecture: Primary 32-bit Cortex M4 core for flight control paired with a dedicated 32-bit failsafe co-processor for enhanced system reliability.
  • Comprehensive Sensor Fusion: Integrates a 16-bit gyroscope, 14-bit accelerometer/magnetometer, secondary 3-axis IMU, and high-resolution barometer for accurate attitude and altitude estimation.
  • Extensive Flight Mode Support: Compatible with ArduPilot and PX4 firmware, enabling modes including Stabilize, AltHold, Loiter, Auto, Follow Me, and RTL for versatile mission profiles.
  • Robust I/O and Power Management: Provides 14 configurable PWM outputs, dedicated power module input for voltage/current sensing, and interfaces for peripherals like optical flow and airspeed sensors.
  • Professional Build Quality: Features automatic interface detection to prevent connection errors and includes vibration-damping mounting foam for cleaner sensor data.

Applications

  • Advanced FPV and aerial photography quadcopters requiring waypoint navigation and autonomous mission execution.
  • Long-range fixed-wing UAVs for mapping, surveillance, and payload delivery missions.
  • Heavy-lift multirotor platforms for industrial inspection and cargo transport.
  • Educational and research drones for developing and testing custom flight algorithms with ArduPilot/PX4.
  • Ground rover and boat automation projects leveraging the same robust autopilot firmware.

Technical Specifications

Processor Core32-bit STM32F427 Cortex M4 with FPU
CPU Frequency168 MHz
RAM256 KB
Flash Memory2 MB
Failsafe Co-Processor32-bit STM32F100
GyroscopeST Micro L3GD20H (16-bit)
Accelerometer/MagnetometerST Micro LSM303D (14-bit)
Secondary IMUInvensense MPU6000 (3-axis accel/gyro)
BarometerMEAS MS5611
PWM/Servo Outputs14 total (8 with failsafe/manual override)
Supported Model TypesMulti-rotor, Fixed-wing, Helicopter, Ground Vehicle
Receiver CompatibilitySpektrum DSM, Standard PWM/PPM, SBUS
Dimensions (Board)85 x 52 x 15 mm
Weight (Board)37.6 g

Frequently Asked Questions

What firmware is compatible with the RadioLink Pixhawk?

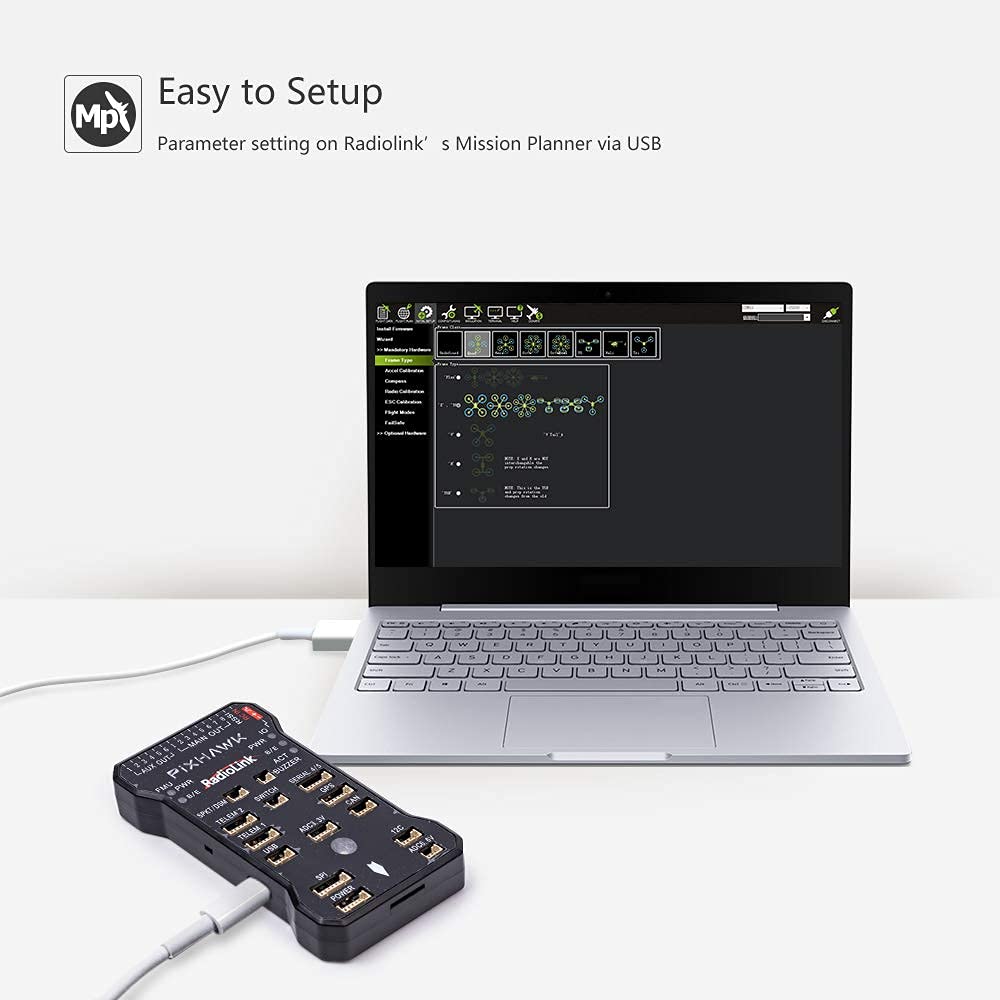
The RadioLink Pixhawk is fully compatible with the open-source ArduPilot and PX4 flight stacks. You can flash the latest stable firmware via Mission Planner or QGroundControl. The board's 2MB of flash memory supports the full feature set, including advanced navigation and scripting.

What is the purpose of the included power module?

The included power module connects between your main flight battery and the flight controller. It provides regulated 5V power to the board and peripherals while also measuring battery voltage and current consumption, which is essential for battery monitoring, telemetry, and low-battery failsafes.

How many motors or servos can this Pixhawk control?

This controller provides up to 14 PWM/servo outputs. Typically, 4-8 outputs are used for motor control on multirotors, with the remaining aux outputs available for camera gimbals, landing gear, parachute releases, or other payload servos, making it suitable for complex robotic applications.

Does it support GPS navigation and autonomous flight?

Yes, it has a dedicated GPS port (typically UART) for connecting compatible GPS/Compass modules. With a GPS connected and configured in ArduPilot/PX4, you gain access to autonomous flight modes like Loiter, Mission (waypoint navigation), Return-to-Launch (RTL), and Follow Me.

Package Includes

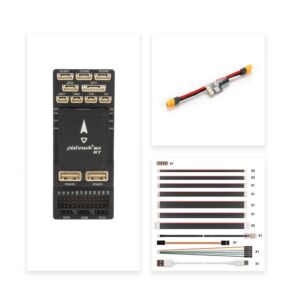
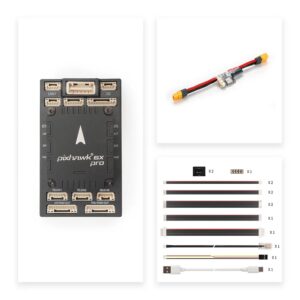
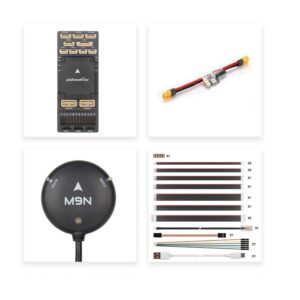
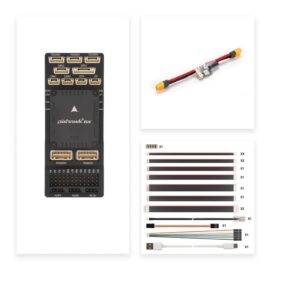
  • 1 x RadioLink Pixhawk Flight Controller Board
  • 1 x Power Module
  • 1 x MicroSD Card
  • 1 x Safety Switch
  • 1 x 3-wire Servo Cable
  • 1 x Buzzer
  • 2 x Mounting Foam Pads

Additional Information

Weight 0.163 kg
Dimensions 20 × 11 × 6 cm