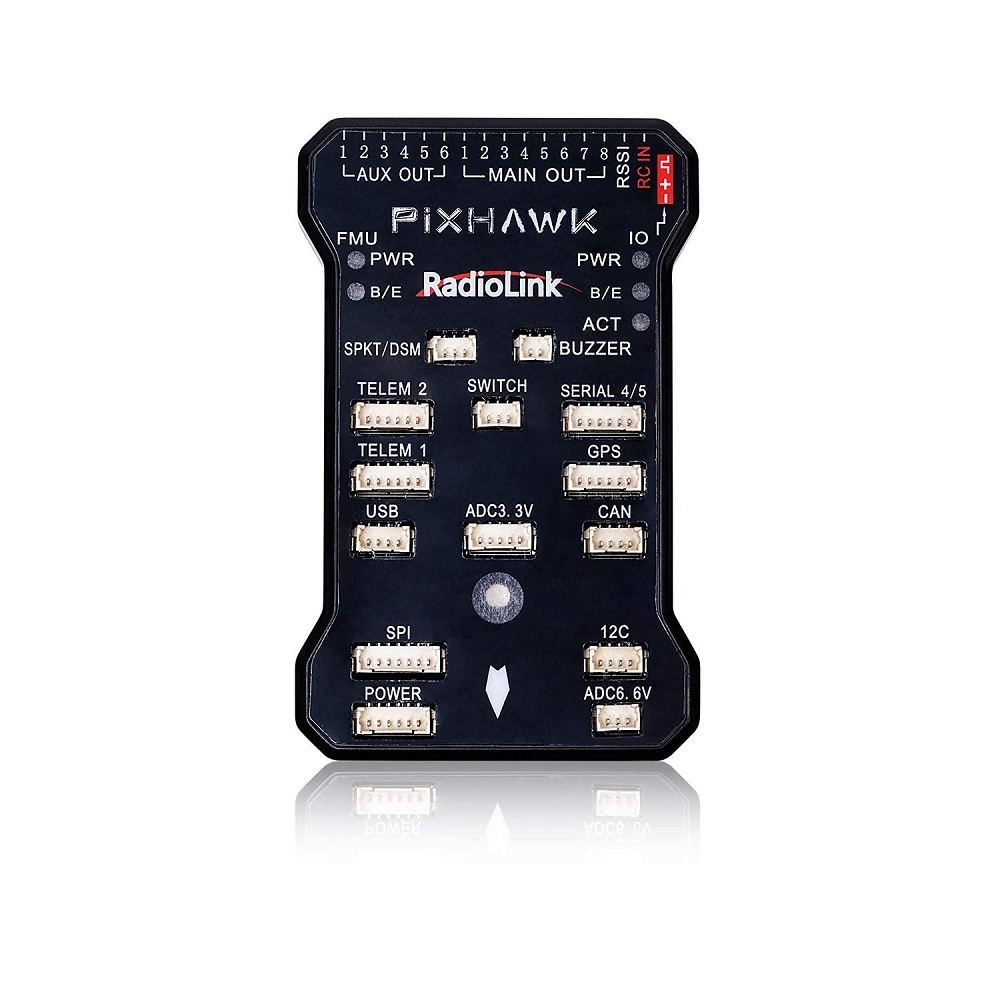
RadioLink Pixhawk Flight Controller Board
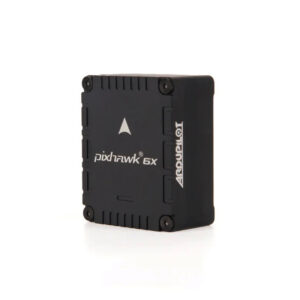
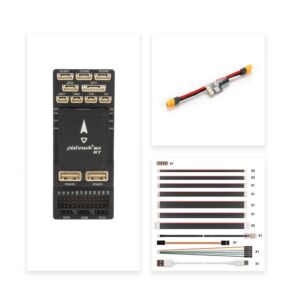
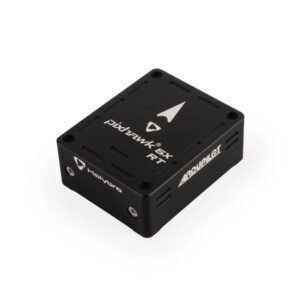
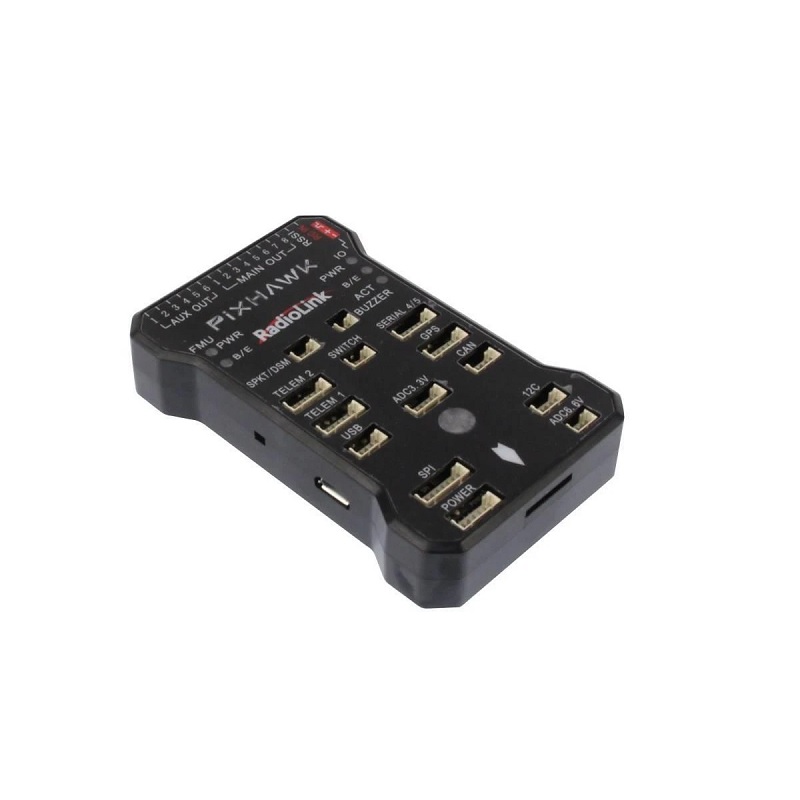
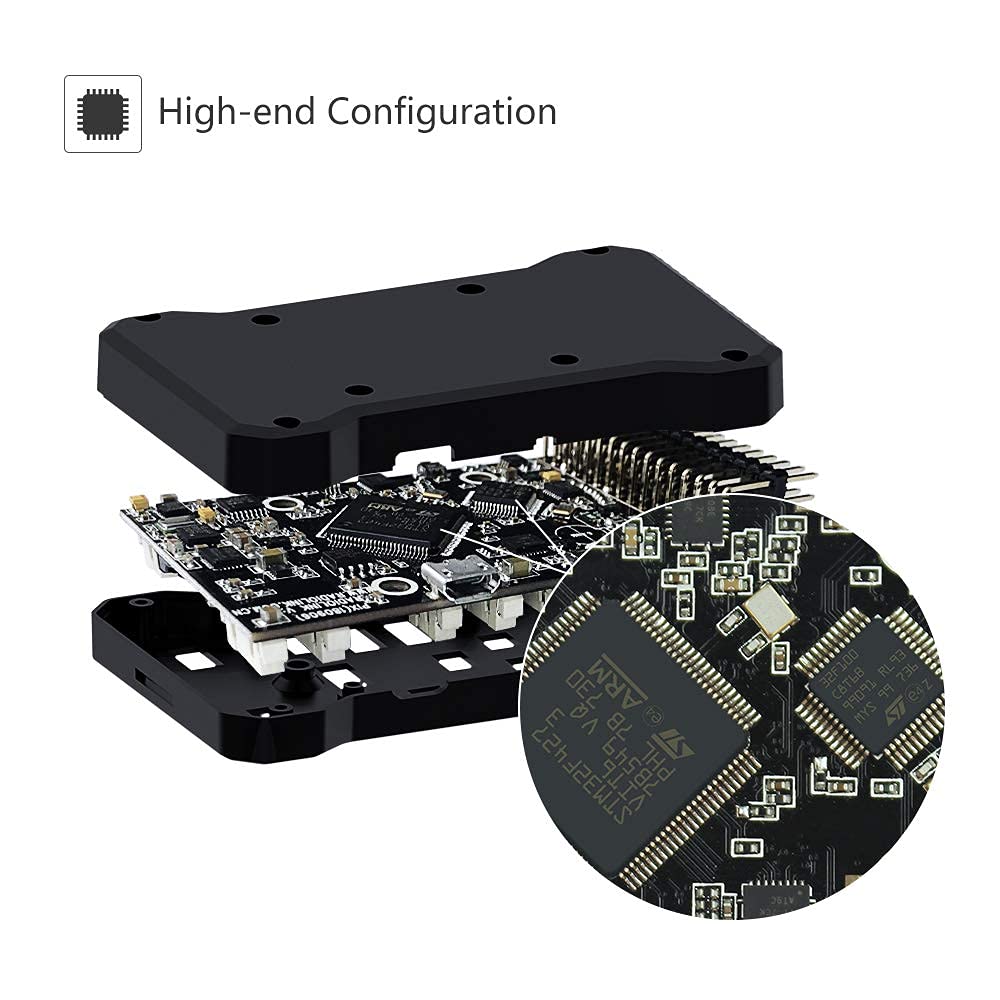
The RadioLink Pixhawk Flight Controller is a high-performance autopilot board built around a 32-bit STM32F427 Cortex M4 core, designed for multi-rotor, fixed-wing, and ground vehicle applications. It features a comprehensive sensor suite and extensive I/O for integration with GPS, telemetry, and peripherals within the ArduPilot and PX4 ecosystems.
Features
- 32-bit STM32F427 Cortex M4 main processor (168MHz, FPU) with STM32F100 failsafe co-processor.
- High-precision sensor suite: L3GD20H gyro, LSM303D accel/mag, MPU6000 IMU, and MS5611 barometer.
- 14 PWM/servo outputs (8 with failsafe) supporting multi-rotor, fixed-wing, and helicopter models.
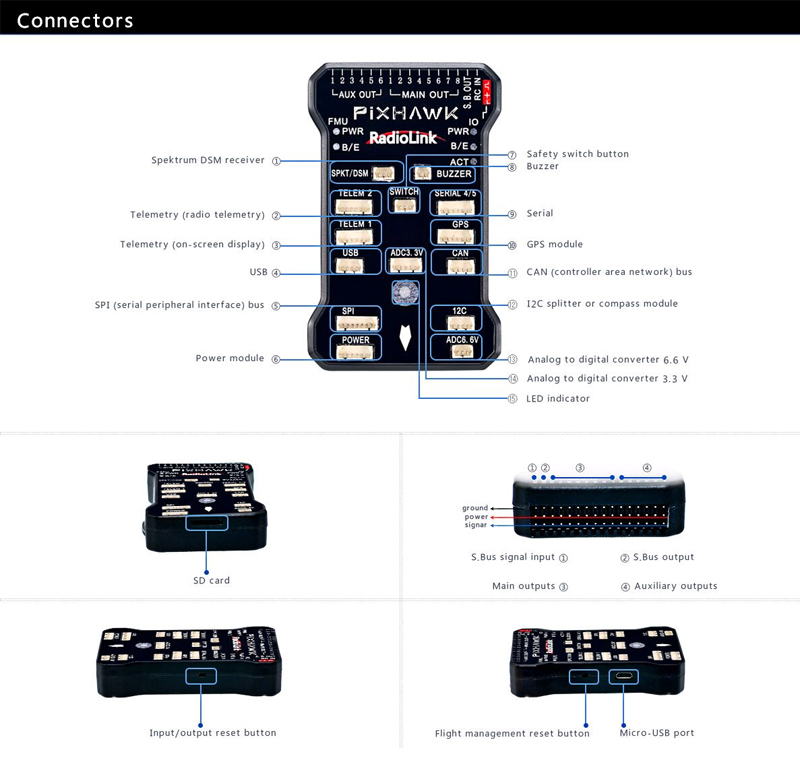
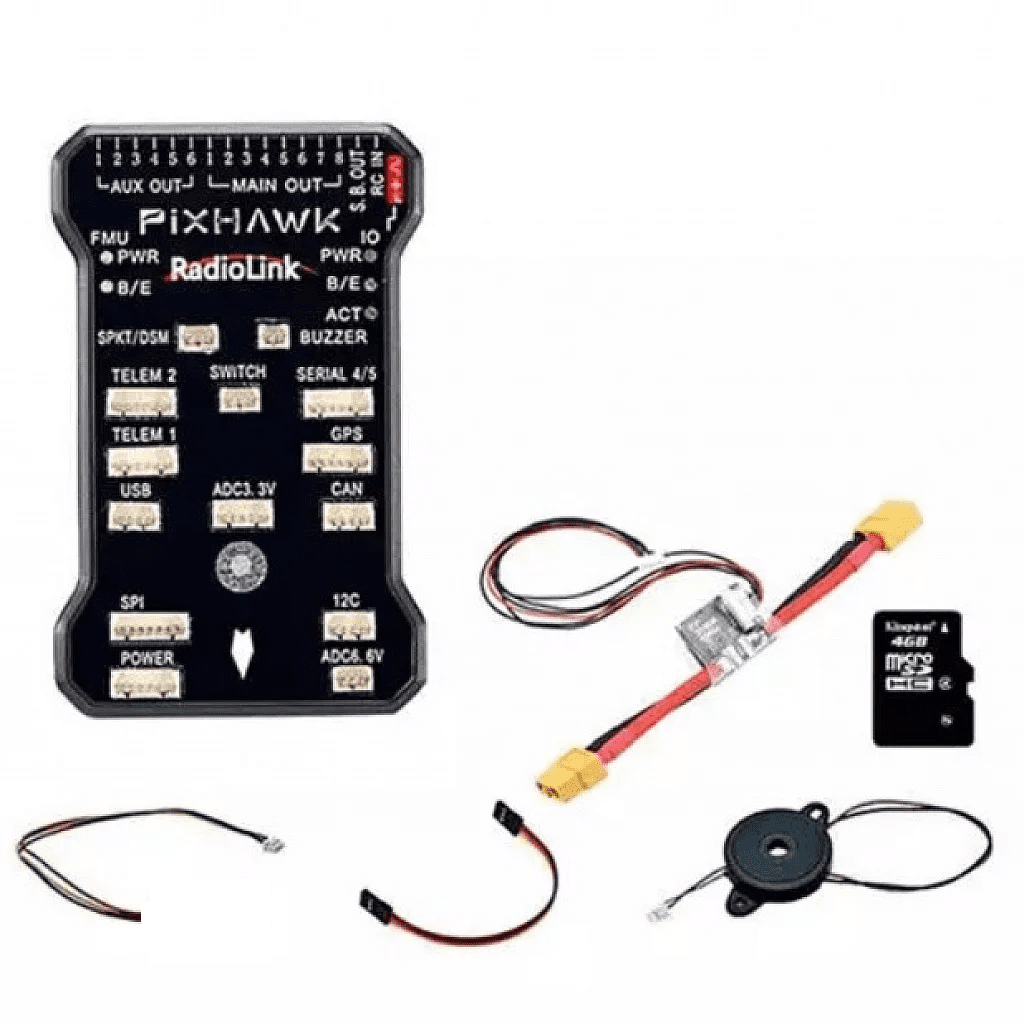
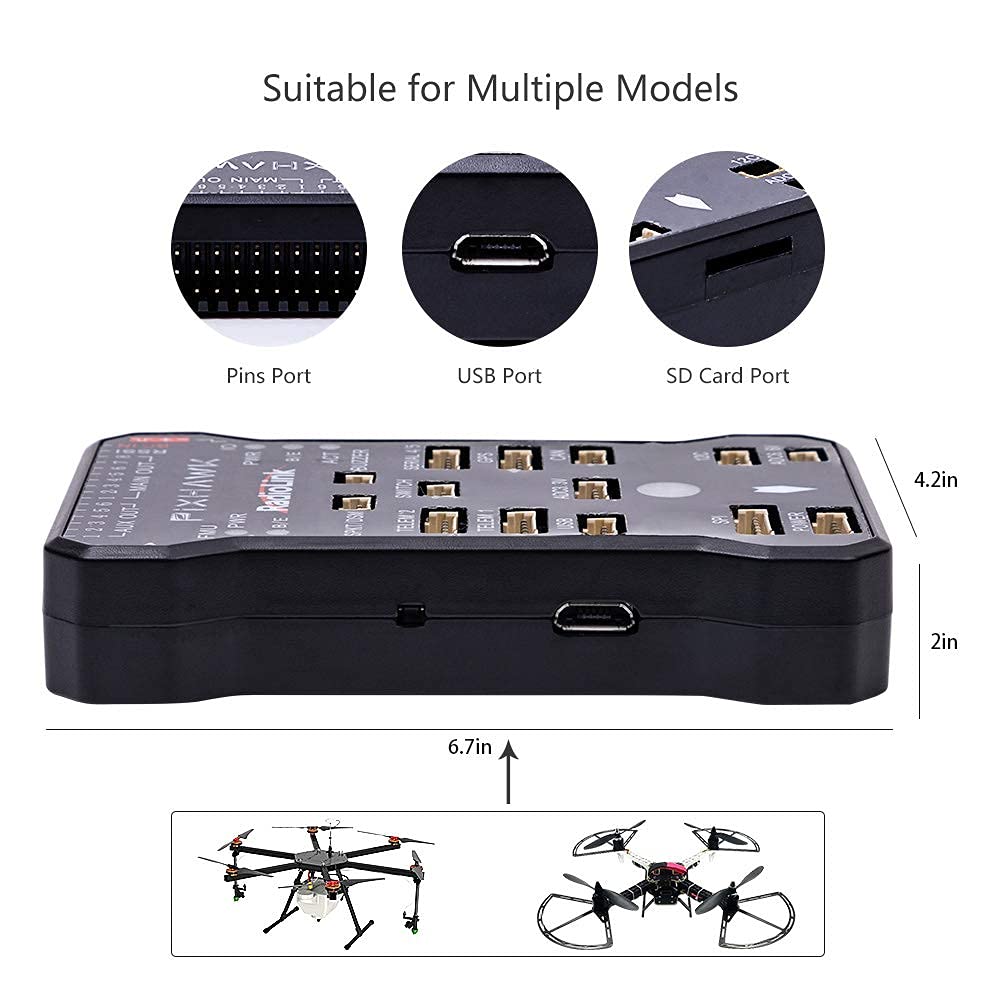
- Extensive connectivity: dedicated ports for GPS, I2C, SPI, Spektrum DSM receivers, and telemetry.
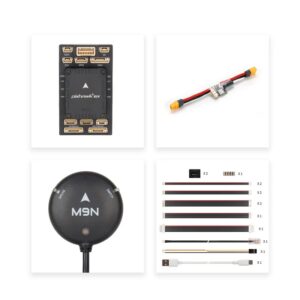
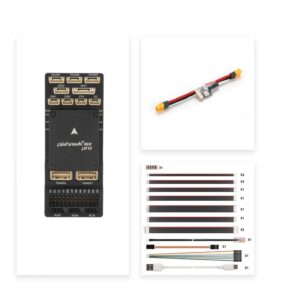
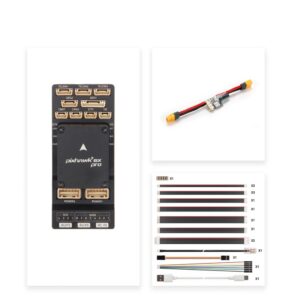
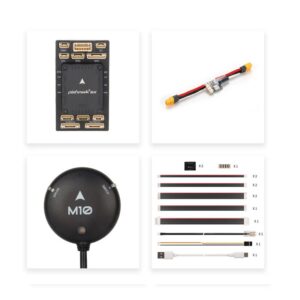
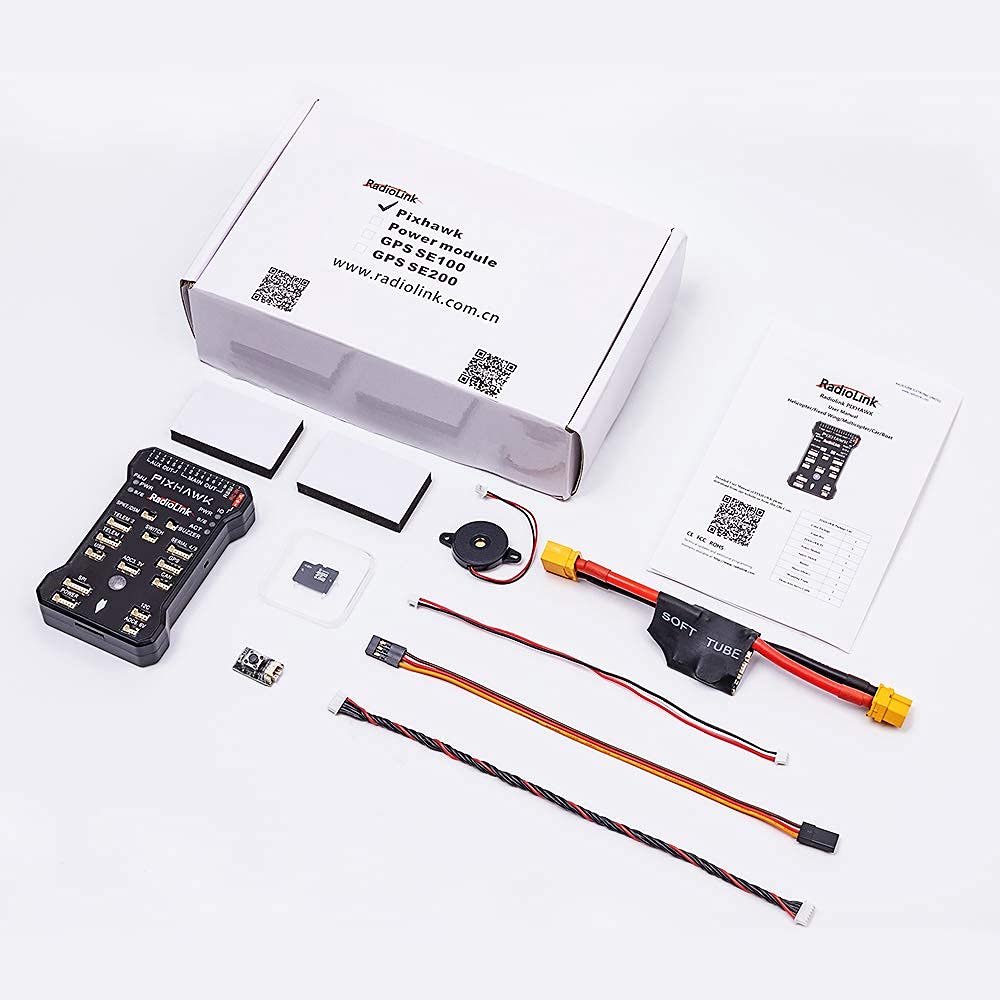
- Includes power module, microSD card, safety switch, buzzer, and mounting accessories.
Out of stock
The RadioLink Pixhawk Flight Controller delivers robust, open-source autopilot capabilities for advanced UAV platforms. Its optimized PCB layout and barometer isolation contribute to stable altitude hold and precise flight performance across a wide range of models, from agile quadcopters to long-endurance fixed-wing aircraft.
Engineered for reliability, the board integrates a dual-processor architecture. The primary STM32F427 handles high-rate flight control algorithms, while the secondary STM32F100 co-processor ensures continuous failsafe monitoring and manual override capabilities. This design is critical for professional and commercial drone operations requiring maximum operational safety.
Additional Information
| Weight | 0.163 kg |
|---|---|
| Dimensions | 20 × 11 × 6 cm |