SKU: DRFC-1897
📋 GST Invoice Available

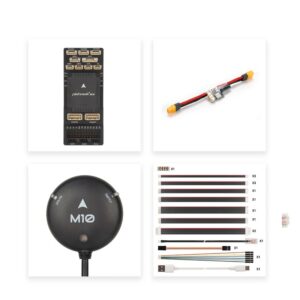
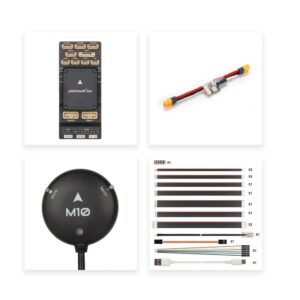
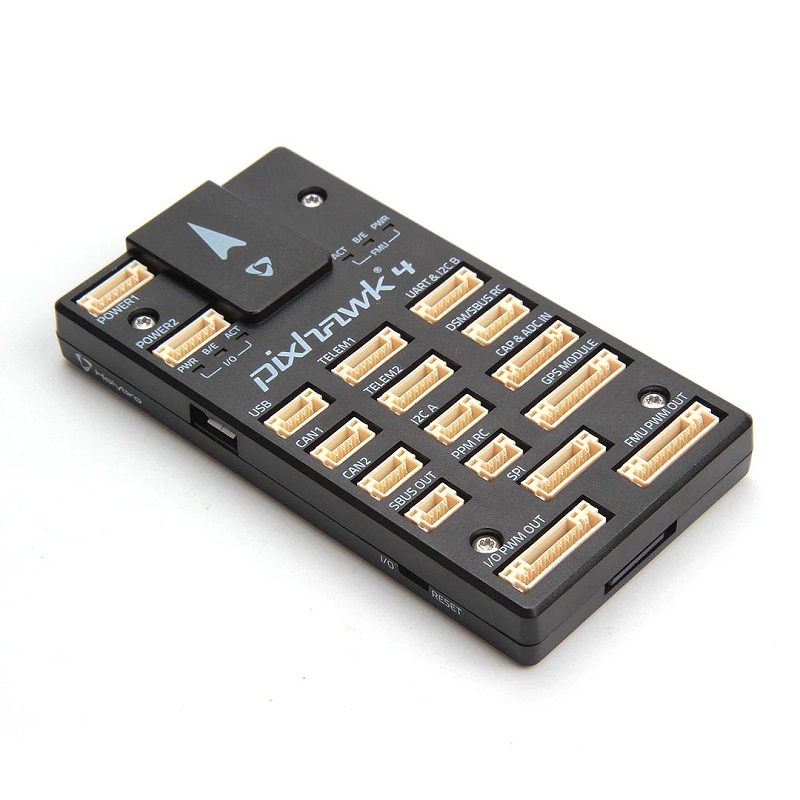
Holybro Pixhawk 4 Flight Controller & PM07 14S Power Module Set - Aluminum Case

₹25,409.00 (Inclusive of all taxes)
Out of Stock

The Holybro Pixhawk 4 is a professional-grade flight controller paired with the PM07 14S Power Module, designed for advanced autonomous UAV and robotic applications. It features a dual-processor architecture, high-fidelity sensors with vibration isolation, and extensive connectivity for sensor and payload integration, running on the NuttX real-time operating system.

Features

  • Dual STM32 Processors: Features an STM32F765 FMU and STM32F103/100 IO coprocessor for robust, real-time flight control and peripheral management.
  • High-Performance Sensor Suite: Integrates low-noise IMUs (ICM-20689, BMI055/ICM-20602), magnetometer (IST8310), and barometer (MS5611) with dedicated vibration isolation for precise data.
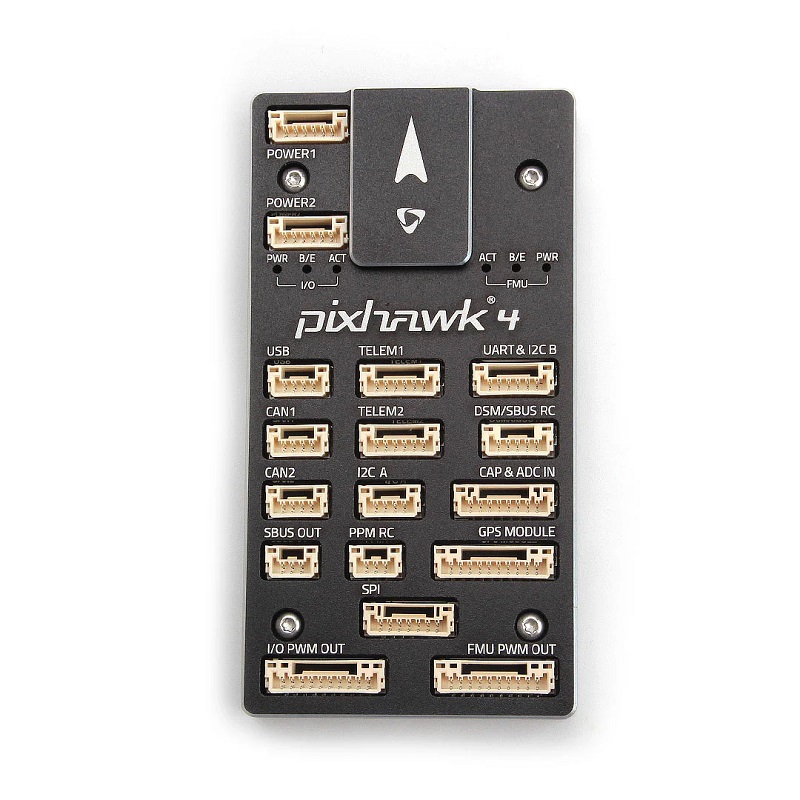
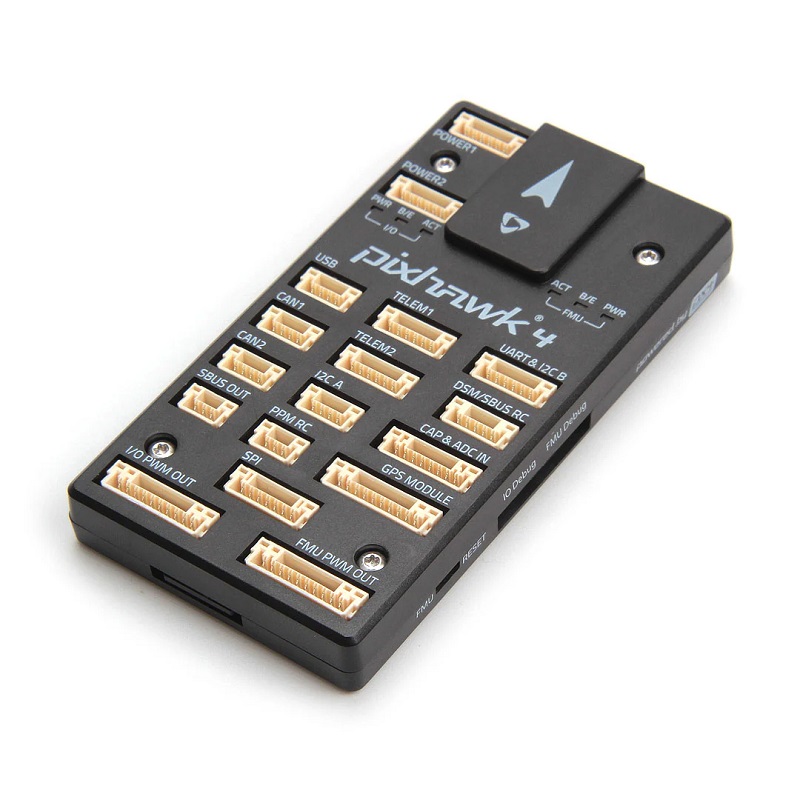
  • Extensive I/O Connectivity: Offers 2 SPI buses, 4 I2C buses, and multiple serial ports for seamless integration of GPS, compasses, telemetry, and custom payloads.
  • PM07 14S Power Module: Supports high-voltage input up to 14S LiPo (6V-58.8V) with 120A max current sensing for reliable power monitoring and distribution.
  • Developer-Optimized Platform: Provides 2MB flash and 512KB RAM on the FMU, running NuttX RTOS, facilitating the implementation of complex autonomous algorithms and models.

Out of stock

Description

The Holybro Pixhawk 4 represents a significant evolution in open-source autopilot hardware, engineered for demanding commercial, research, and industrial UAV projects. Its core strength lies in the separation of critical flight management tasks on the powerful STM32F765 processor from lower-priority I/O operations handled by a dedicated co-processor. This architecture, combined with a NuttX real-time operating system, ensures deterministic performance and reliability for complex autonomous navigation, computer vision, and control algorithms.

The flight controller’s sensor array is meticulously designed for stability and accuracy. High-performance accelerometers and gyroscopes are mounted on specialized vibration-damping material, and their data-ready signals are routed to dedicated interrupt pins, allowing for precise hardware time-stamping. This design minimizes latency and jitter, which is critical for state estimation and filter performance in dynamic flight conditions. The included PM07 14S Power Module provides robust voltage regulation and high-current sensing capabilities, making this set suitable for large multirotors, VTOL aircraft, and ground robots requiring high-power systems.

Key Features

  • Dual-Processor Design: Separates high-level flight management (STM32F765) from I/O processing (STM32F103/100) for enhanced system reliability and real-time response.
  • Advanced Vibration Isolation: Proprietary damping mounts for IMUs significantly reduce high-frequency noise, leading to cleaner sensor data and improved flight performance.
  • Precision Time-Stamping: Hardware-level routing of sensor data-ready signals to timer capture pins enables microsecond-accurate synchronization, crucial for advanced sensor fusion.
  • Expansive Connectivity: Two external SPI buses with six chip-select lines and four I2C buses allow for the addition of numerous peripherals, lidar, companion computers, or custom sensor arrays.
  • Wide Input Voltage Range: The PM07 module supports 6V to 58.8V (14S) input, with servo rail handling up to 36V, accommodating a vast range of vehicle power systems.
  • High-Current Monitoring: Integrated 120A max current sensing provides accurate battery consumption data for flight time estimation and power system diagnostics.
  • Aluminum Protective Case: Provides EMI shielding and robust physical protection for the flight controller board in harsh operational environments.

Applications

  • Heavy-lift Cinematography & Mapping Drones: Provides the processing power and sensor stability required for carrying high-payload cameras and executing precise automated survey grids.
  • VTOL (Vertical Take-Off and Landing) & Fixed-Wing UAVs: The robust processing and extensive I/O are ideal for managing complex transition logic and long-endurance autonomous missions.
  • Autonomous Ground Robots & Rovers: Serves as a central navigation and control brain for robotic platforms used in research, logistics, and inspection.
  • Advanced Research & Prototyping: The open-source PX4/ArduPilot ecosystem and expansive connectivity make it a preferred platform for developing and testing new algorithms in academia and industry.
  • Industrial Inspection & Delivery Systems: Offers the reliability and customization needed for beyond-visual-line-of-sight (BVLOS) operations in infrastructure inspection or automated delivery networks.

Technical Specifications

Item TypeFlight Controller & Power Module Set
FMU ProcessorSTM32F765
IO ProcessorSTM32F103, STM32F100
Accel/Gyro (Primary)ICM-20689
Accel/Gyro (Secondary)BMI055 / ICM-20602
MagnetometerIST8310
BarometerMS5611
Power Output (BEC)4.9V - 5.5V
PM07 Input Voltage6V - 58.8V (14S LiPo)
PM07 Max Current Sensing120 A
USB Power Input4.75V - 5.25V
Servo Rail Input0V - 36V
Operating SystemNuttX RTOS
Dimensions (LxW)84mm x 44mm
Weight (Controller)49g

Frequently Asked Questions

What is the maximum battery voltage supported by the included PM07 Power Module?

The Holybro PM07 Power Module included in this set supports a wide input voltage range from 6V up to 58.8V, which corresponds to a 14S LiPo battery configuration. It features robust 120A current sensing for accurate power system monitoring and provides a regulated 5V output to power the flight controller and peripherals.

Which firmware and ground control station software is the Pixhawk 4 compatible with?

The Holybro Pixhawk 4 is fully compatible with the open-source PX4 and ArduPilot firmware ecosystems. You can flash either firmware using the QGroundControl (for PX4) or Mission Planner/ArduPilot Configurator (for ArduPilot) ground station software. It comes pre-configured to work seamlessly with these platforms for autonomous flight, mission planning, and parameter tuning.

What are the key advantages of the dual-processor design and vibration isolation?

The dual-processor design separates critical flight stack tasks on the high-performance STM32F765 from I/O management on a separate chip, preventing peripheral communication delays from affecting core flight control loops. The advanced vibration isolation mechanically filters high-frequency motor and propeller vibrations from the IMUs, resulting in cleaner gyroscope and accelerometer data. This leads to more accurate state estimation, smoother flight, and better performance in aggressive maneuvers or with less balanced propellers.

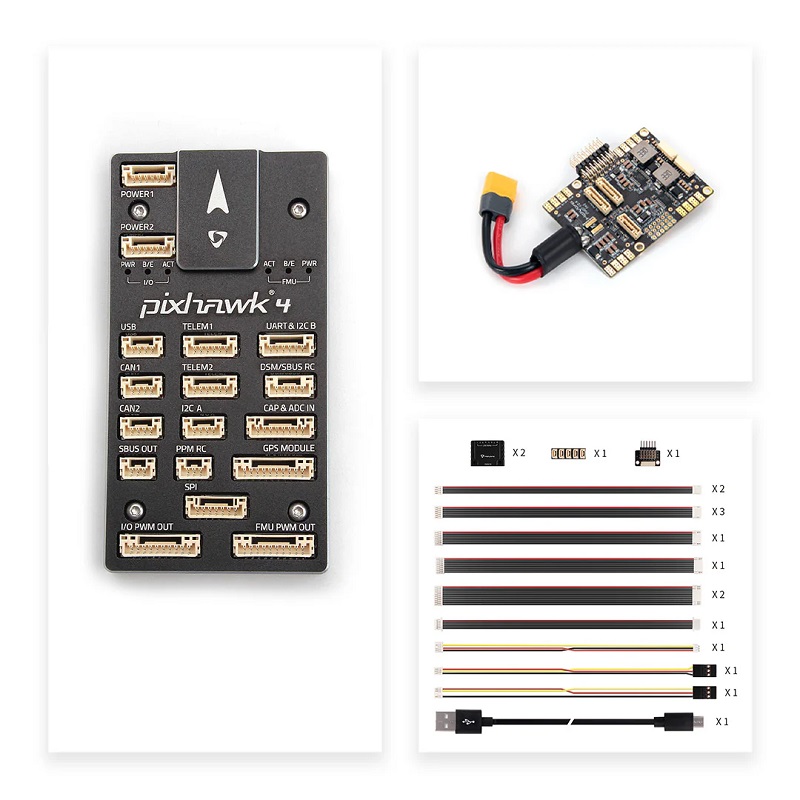
Package Includes

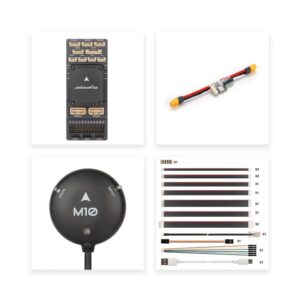
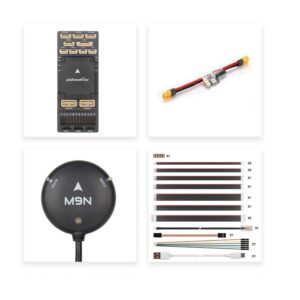
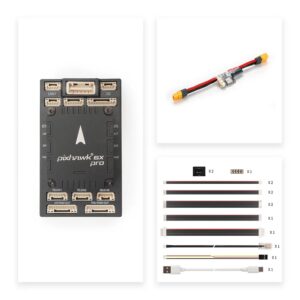
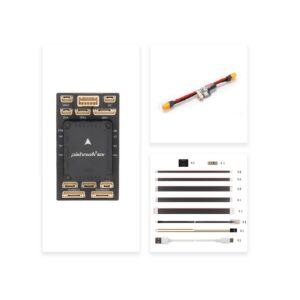
  • 1 x Pixhawk 4 Flight Controller (Aluminum Case)
  • 1 x PM07 14S Power Module
  • 1 x Cable Set

Additional Information

Weight 0.049 kg
Dimensions 4.4 × 8.4 cm