SKU: DRFC-1871
📋 GST Invoice Available

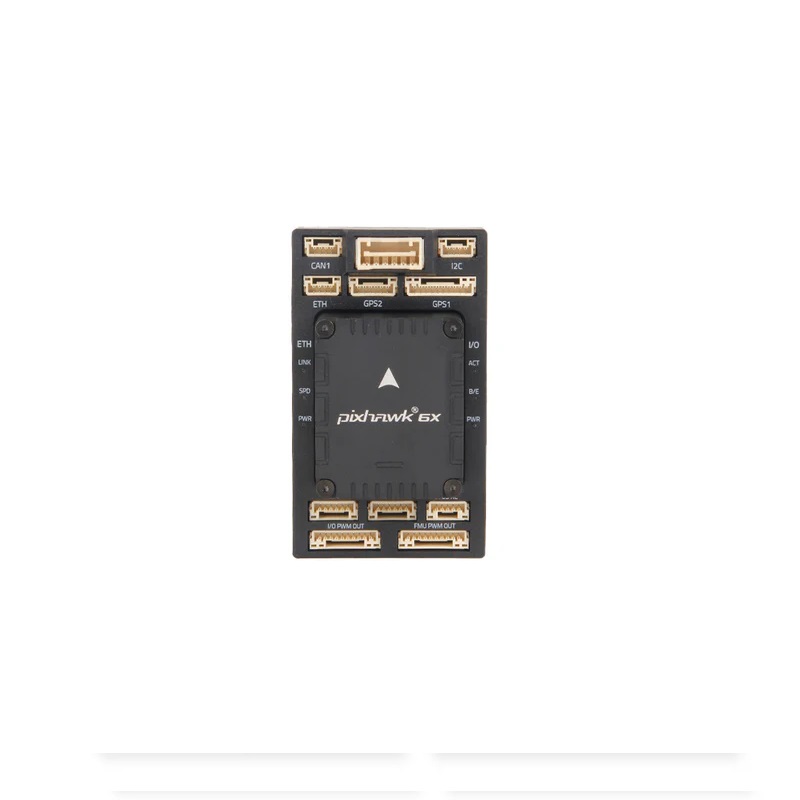
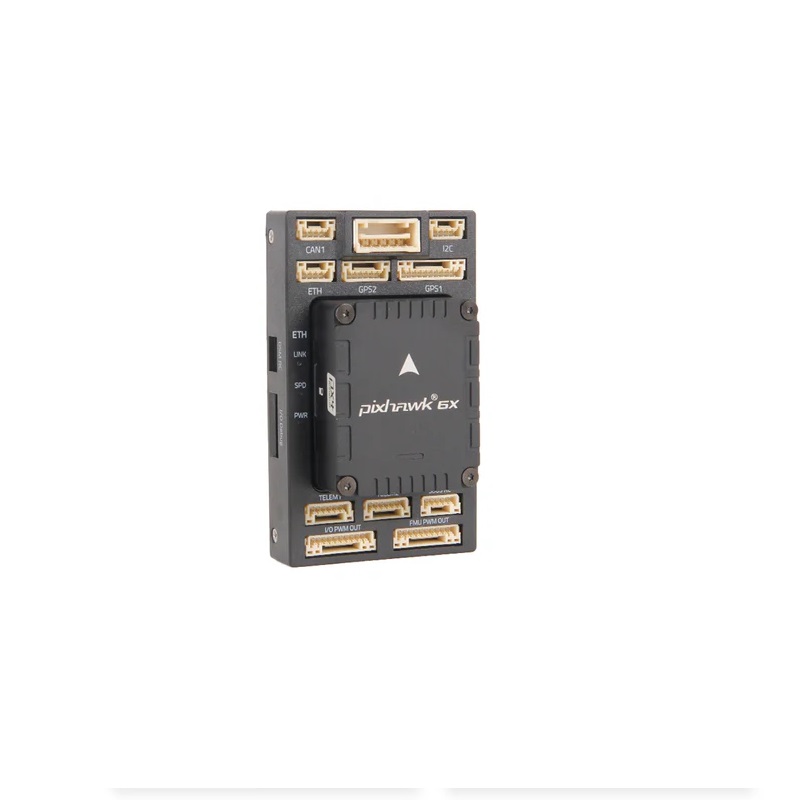
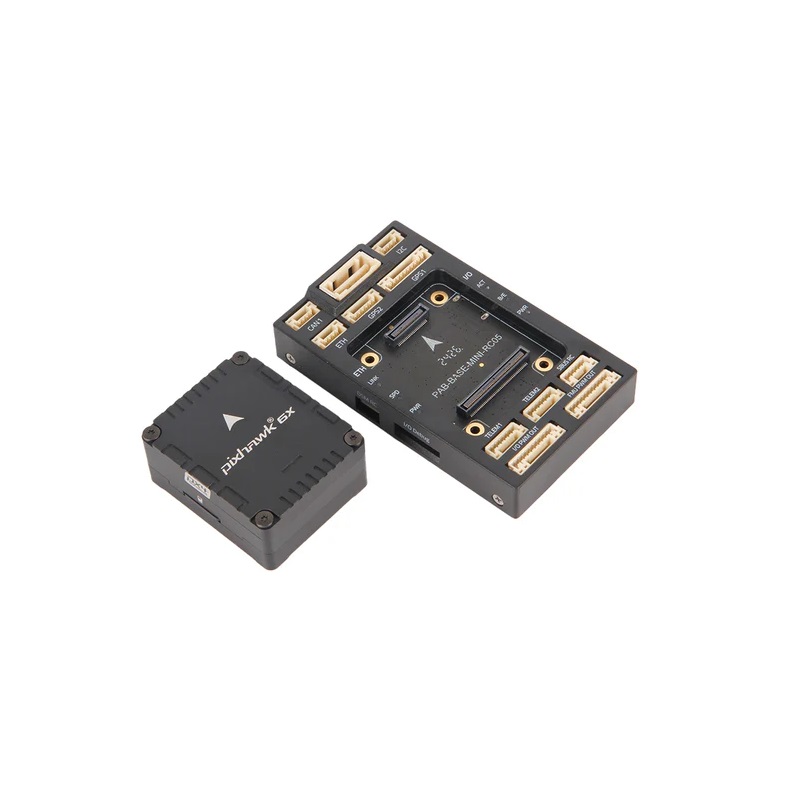
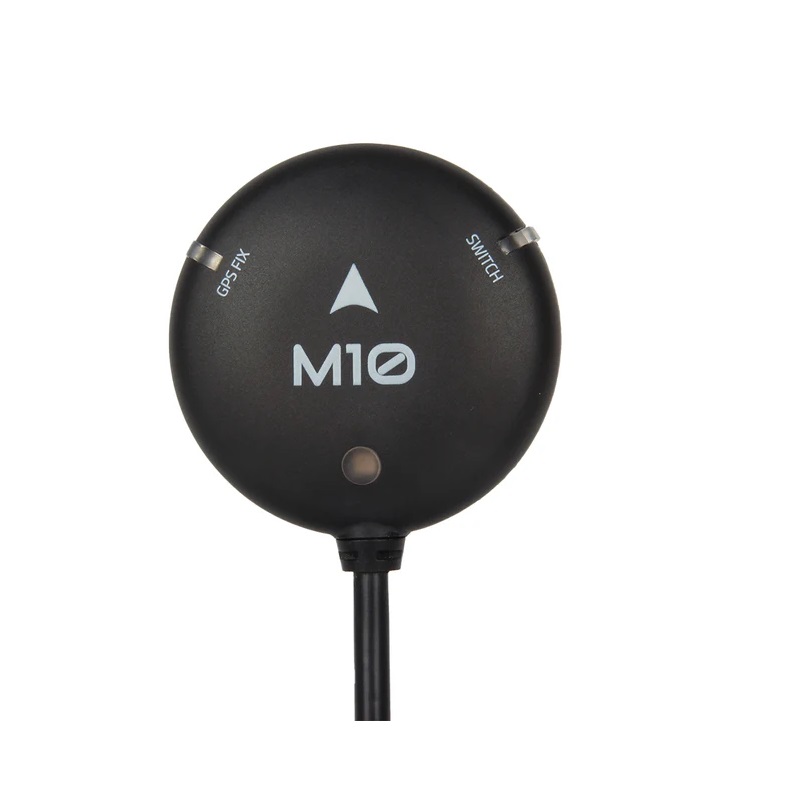
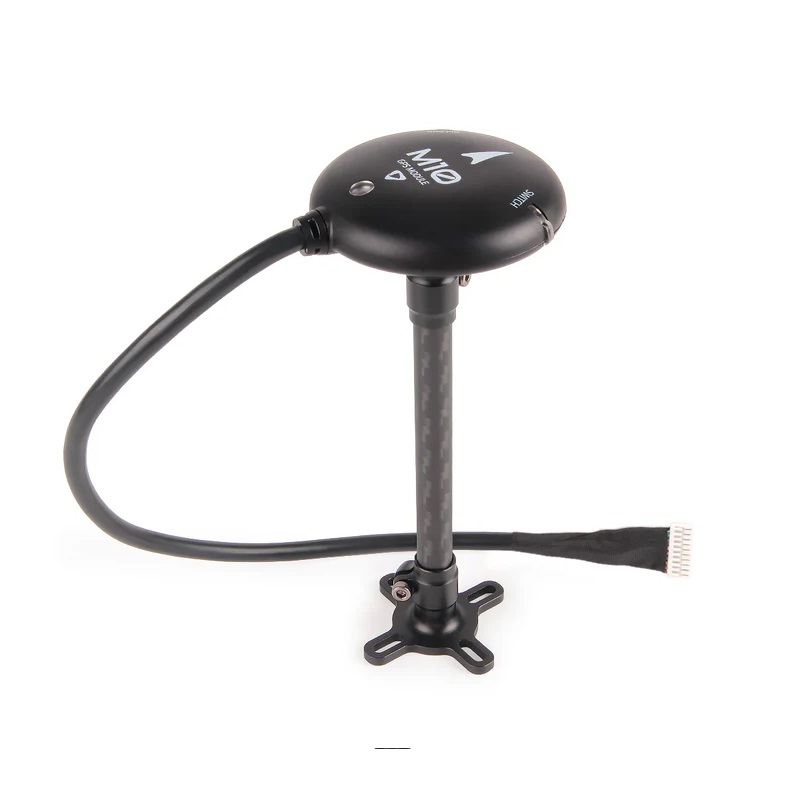
Holybro Pixhawk 6X (Rev8) Mini Set + M10 GPS

₹42,029.00 (Inclusive of all taxes)
Out of Stock

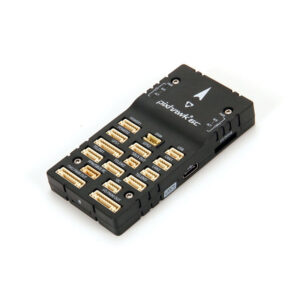
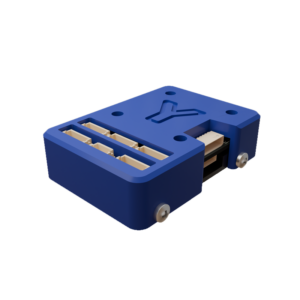
The Holybro Pixhawk 6X (Rev8) Mini Set is a high-reliability flight controller system designed for commercial and industrial UAV applications. Featuring triple-redundant ICM-45686 IMUs, dual barometers, and an STM32H753 processor, it integrates seamlessly with the included M10 GPS module for precise navigation and is compatible with ArduPilot and PX4 firmware.

Features

  • Triple-redundant ICM-45686 IMU sensors with BalancedGyroâ„¢ technology for exceptional reliability.
  • High-performance STM32H753 processor (480 MHz) for fast data processing and complex flight control algorithms.
  • Integrated NXP Semiconductors EdgeLock SE050 secure element for enhanced system security and data protection.
  • Modular design with vibration-isolated IMU board and separate power domains for sensor integrity.
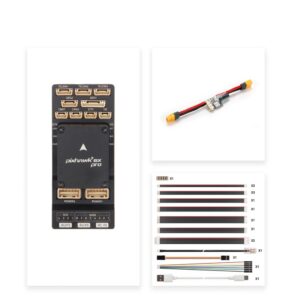
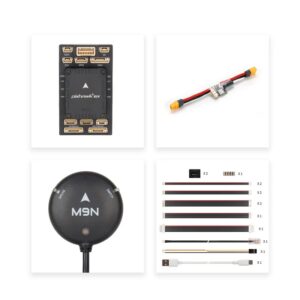
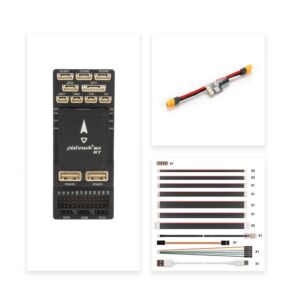
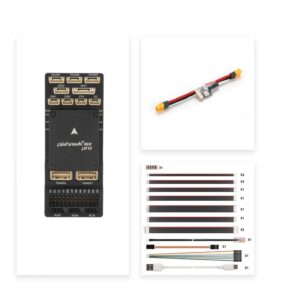
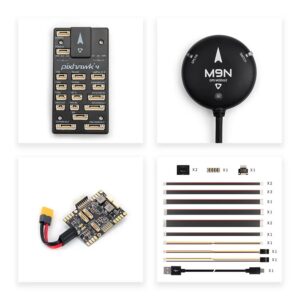
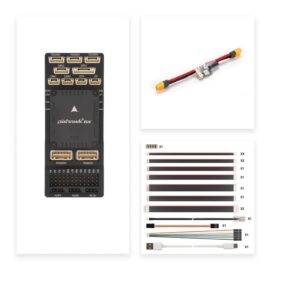
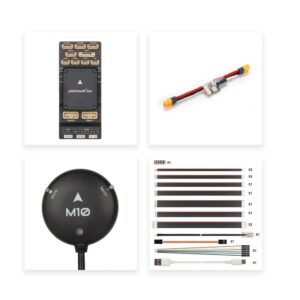
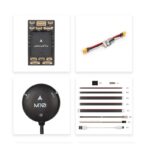
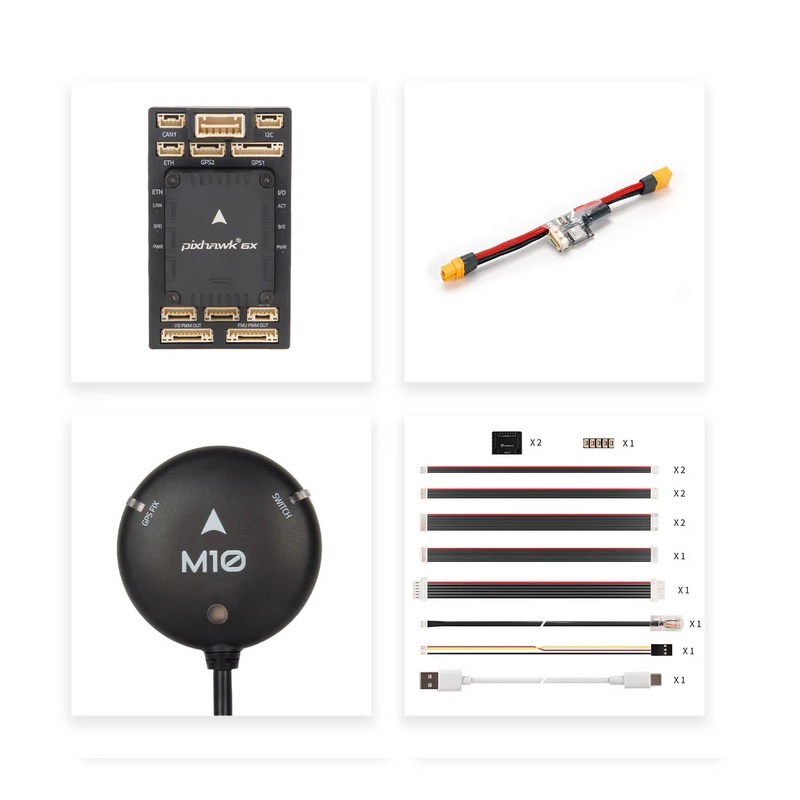
  • Complete set includes Mini Baseboard, PM02D HV Power Module, cable set, and M10 GPS module.

Out of stock

Description

The Holybro Pixhawk 6X (Rev8) Mini Set represents a significant advancement in flight control reliability for demanding UAV operations. Its core architecture separates the Flight Management Unit (FMU), Inertial Measurement Unit (IMU), and baseboard into isolated, vibration-damped modules. This design, coupled with triple-redundant sensors on independent power buses, ensures continued operation even in the event of a single sensor failure, making it ideal for beyond-visual-line-of-sight (BVLOS) and commercial missions.

Powered by the robust STM32H753 microcontroller, the system handles high-rate data processing from its advanced sensor suite, which includes dual barometers and a magnetometer. The inclusion of an Ethernet interface facilitates high-bandwidth communication with companion computers for advanced autonomy stacks. The integrated NXP Semiconductors EdgeLock SE050 secure element provides a hardware root of trust, enabling secure boot and encrypted communications critical for sensitive data and operational security.

Key Features

  • Triple Redundant Sensor Array: Three independent ICM-45686 IMUs and two barometer sensors (ICP20100 & BMP388) provide fault-tolerant attitude and altitude estimation.
  • High-Performance Compute Core: STM32H753 processor (480 MHz) paired with an STM32F103 co-processor for efficient I/O handling and complex navigation tasks.
  • Advanced Vibration Damping: Proprietary isolation material minimizes high-frequency resonance, protecting sensor accuracy in high-vibration environments.
  • Secure Element Integration: NXP Semiconductors EdgeLock SE050 enables secure key storage, encrypted communication, and authenticated firmware updates.
  • Flexible Power Architecture: Accepts input via USB (4.75–5.25V), servo rail (0–36V), and dedicated power module for versatile system integration.
  • Modular Connectivity: Features 100-pin and 50-pin Pixhawk® Autopilot Bus connectors for easy expansion with peripherals and companion computers.
  • Temperature-Controlled IMU: Actively managed thermal environment ensures consistent sensor performance across a wide operational temperature range.

Applications

  • Commercial mapping, surveying, and inspection drones requiring high reliability for BVLOS operations.
  • Precision agriculture platforms for crop monitoring, spraying, and data collection.
  • Search and rescue (SAR) and public safety UAVs where system redundancy is critical.
  • Advanced autonomous robotics and research platforms requiring secure, high-bandwidth communication.
  • Heavy-lift cargo and delivery drones demanding robust flight control and navigation integrity.

Technical Specifications

Item TypeFlight Controller
Main ProcessorSTM32H753 (480 MHz)
I/O ProcessorSTM32F103
Accelerometer/Gyroscope3x ICM-45686
BarometerICP20100 & BMP388
MagnetometerBMM150
Secure ElementNXP Semiconductors EdgeLock SE050
Voltage Input (Servo Rail)0–36V
USB Power Input4.75–5.25V
Firmware CompatibilityArduPilot, PX4
Connectors100-pin & 50-pin Pixhawk Autopilot Bus

Frequently Asked Questions

What firmware is compatible with the Holybro Pixhawk 6X?

The Holybro Pixhawk 6X is fully compatible with both ArduPilot and PX4 open-source flight stacks. Its high-performance STM32H753 processor and extensive peripheral support make it ideal for advanced fixed-wing, multirotor, and rover applications supported by these firmware platforms.

What are the power input options and limits for this flight controller?

The Pixhawk 6X accepts power via three primary methods: a standard USB connection (4.75–5.25V), the servo rail input (0–36V), and through the dedicated power module port (using the included PM02D HV module). The servo rail input is designed to handle the full voltage range of typical LiPo batteries, making direct connection to 4S-6S packs possible when using the proper power module.

How does the triple-redundant sensor design improve reliability?

The system utilizes three physically separate ICM-45686 IMU sensors and two barometer sensors, each on an isolated power domain and data bus. The flight software continuously compares data from all sensors. If one sensor drifts or fails, the system can automatically discard its data and maintain stable flight using the remaining healthy sensors, significantly increasing overall system fault tolerance.

Package Includes

  • 1 x Pixhawk 6X Flight Controller Module (Rev8)
  • 1 x Mini Baseboard
  • 1 x PM02D HV Power Module
  • 1 x Cable Set
  • 1 x M10 GPS Module

Additional Information

Weight 0.27 kg
Dimensions 9 × 15 × 7 cm