SKU: DRFC-1868
📋 GST Invoice Available

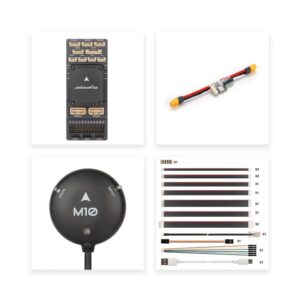
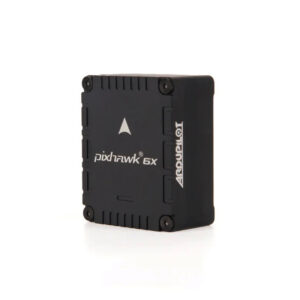
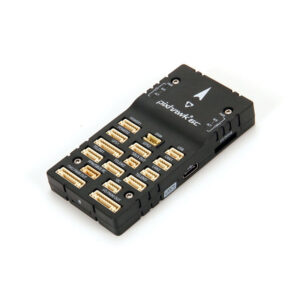
Holybro Pixhawk 6X-RT Flight Controller Module Only

₹21,589.00 (Inclusive of all taxes)
Out of Stock

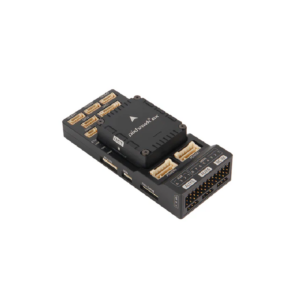
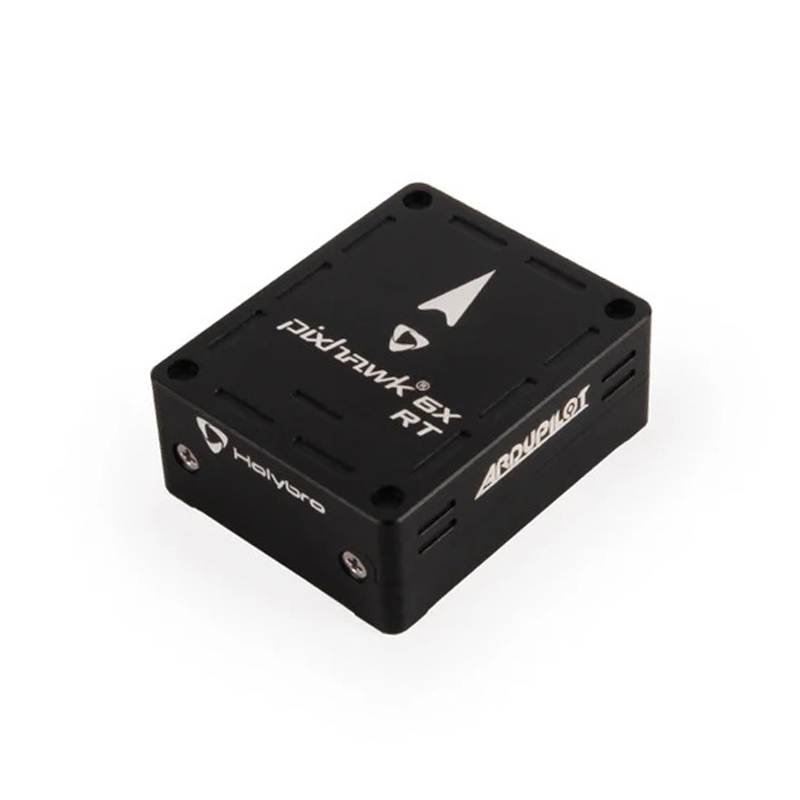
The Holybro Pixhawk 6X-RT is a high-performance flight controller module based on the Pixhawk FMUv6X-RT open standard, featuring a powerful NXP Semiconductors i.MXRT1176 MCU and triple-redundant sensor domains. It is pre-installed with PX4 Autopilot and designed for integration with Pixhawk baseboards for advanced UAV and autonomous vehicle applications.

Features

  • Powered by NXP Semiconductors i.MXRT1176 MCU with STM32F103 IO co-processor for high-performance autonomous flight.
  • Triple-redundant sensor suite: 3x IMUs (BMI088, ICM-42670-P, ICM-42686-P) and 2x barometers (BMP388) for mission-critical reliability.
  • Designed to the Pixhawk Autopilot Bus Standard with 100-pin and 50-pin connectors for modular baseboard integration.
  • Advanced vibration isolation and temperature-controlled IMU housing ensure precise sensor data in demanding environments.
  • Integrated Ethernet interface enables high-speed communication with companion computers for complex autonomous systems.

Out of stock

Description

The Holybro Pixhawk 6X-RT flight controller module is engineered for demanding UAV and robotic platforms requiring uncompromising reliability and computational power. Its core architecture separates the Flight Management Unit (FMU), Input/Output (IO) processor, and sensor systems into isolated, triple-redundant domains, each with independent power control and data buses. This design mitigates single-point failures and ensures continuous operation even under harsh electrical or physical conditions.

Pre-loaded with the open-source PX4 Autopilot firmware, the 6X-RT provides a robust software foundation for autonomous navigation, mission planning, and real-time control. The module’s physical construction utilizes durable materials with a high resonance frequency for superior vibration damping, while the active temperature control of the IMU compartment maintains optimal sensor performance across a wide operational temperature range. Its connectivity is centered on the Pixhawk Autopilot Bus, allowing seamless connection to a variety of Holybro baseboards for flexible system assembly.

Key Features

  • Triple-Redundant Sensor Architecture: Features three independent inertial measurement units (BMI088, ICM-42670-P, ICM-42686-P) and two barometric pressure sensors (BMP388) operating on isolated power and data lines for maximum fault tolerance.
  • High-Performance Compute Core: Combines an NXP Semiconductors i.MXRT1176 crossover processor for primary flight algorithms with an STM32F103 microcontroller dedicated to robust I/O handling and real-time tasks.
  • Advanced Vibration & Thermal Management: Engineered mounting and housing materials provide high-spectrum vibration isolation, while active temperature control maintains IMU sensors at a consistent optimal operating point.
  • Pixhawk Autopilot Bus Standard: Equipped with 100-pin and 50-pin connectors for direct, reliable integration with Pixhawk Baseboard, Pixhawk Mini Baseboard, and Pixhawk Raspberry Pi CM4 Baseboard.
  • High-Speed Ethernet Interface: Includes a transformerless Ethernet port with 50-ohm termination for low-latency, high-bandwidth communication with ground control stations or onboard mission computers.
  • Modular & Serviceable Design: The flight controller, sensor suite, and I/O processor are separated into distinct modules, simplifying troubleshooting, testing, and potential replacement.

Applications

  • High-endurance mapping and surveying drones requiring reliable, long-duration autonomous flight.
  • Research and development platforms for advanced autonomy algorithms in air, land, and sea vehicles.
  • Precision agriculture UAVs for automated crop monitoring, spraying, and data collection.
  • Security, surveillance, and search-and-rescue robots demanding fault-tolerant navigation systems.
  • Custom robotic and autonomous systems where modularity and sensor redundancy are critical.

Technical Specifications

Item TypeFlight Controller Module
Primary MCUNXP Semiconductors i.MXRT1176
IO ProcessorSTM32F103
Accelerometer/GyroBMI088, ICM-42670-P, ICM-42686-P (Triple Redundant)
MagnetometerBMM150
Barometer2x BMP388 (Dual Redundant)
Connector StandardPixhawk Autopilot Bus (100-pin & 50-pin)
Pre-installed FirmwarePX4 Autopilot
Key InterfaceEthernet
Shipping Weight0.05 kg
Shipping Dimensions12 x 10 x 4 cm

Frequently Asked Questions

What baseboards is the Pixhawk 6X-RT module compatible with?

The Pixhawk 6X-RT module is designed to connect directly to baseboards following the Pixhawk Autopilot Bus Standard. This includes the Holybro Pixhawk Baseboard, Pixhawk Mini Baseboard, and the Pixhawk Raspberry Pi CM4 Baseboard. The module provides the core flight processing and sensors, while the baseboard supplies power distribution, additional peripheral connectors, and optional companion computer interfaces.

What is the purpose of the triple-redundant sensors?

The triple-redundant IMUs (BMI088, ICM-42670-P, ICM-42686-P) and dual barometers (BMP388) provide enhanced reliability and fault tolerance for autonomous vehicles. The flight controller's software can perform sensor voting, automatically detecting and isolating a failed or degraded sensor. This architecture is critical for mission-critical applications like long-range drones, heavy-lift platforms, or autonomous systems operating in challenging environments where sensor failure is not an option.

Does the Pixhawk 6X-RT come with firmware pre-installed?

Yes, the Holybro Pixhawk 6X-RT flight controller module comes with the open-source PX4 Autopilot firmware pre-installed and configured. This provides a fully functional baseline for autonomous flight, including support for multi-rotor, fixed-wing, and VTOL aircraft. Users can update or customize the firmware using standard PX4 development tools like QGroundControl or the PX4 Toolchain.

Package Includes

  • 1 x Pixhawk 6X-RT Flight Controller Module

Additional Information

Weight 0.05 kg
Dimensions 10 × 12 × 4 cm