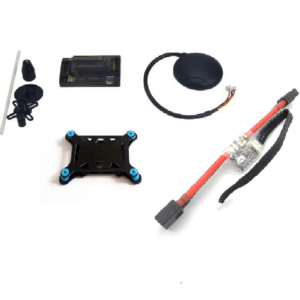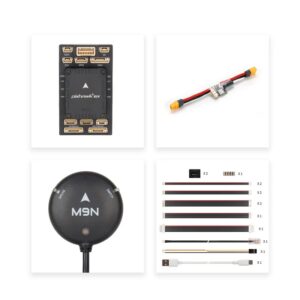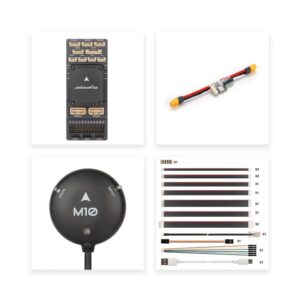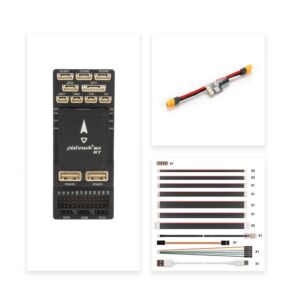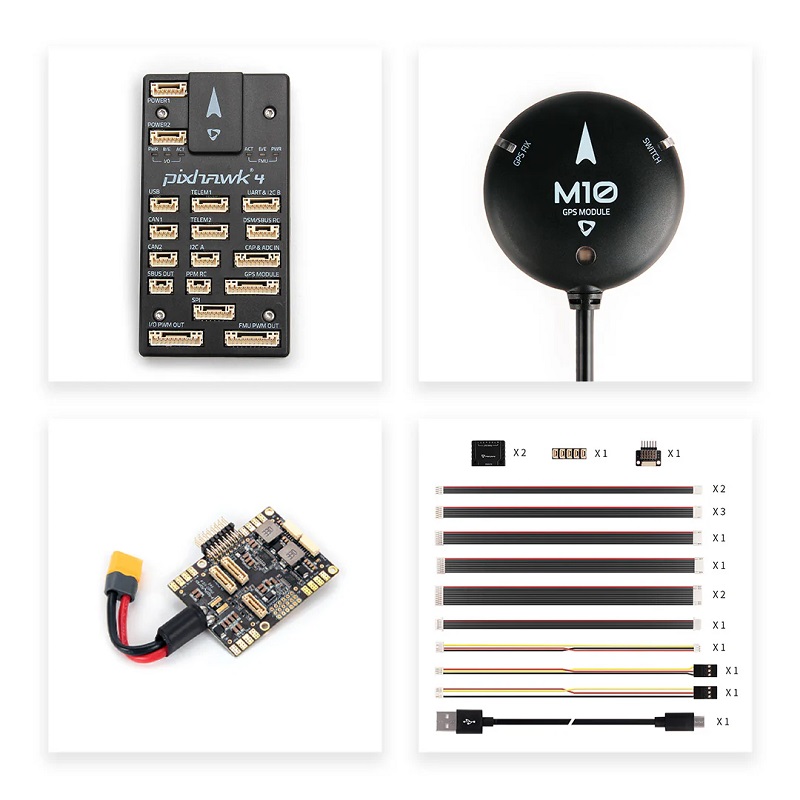
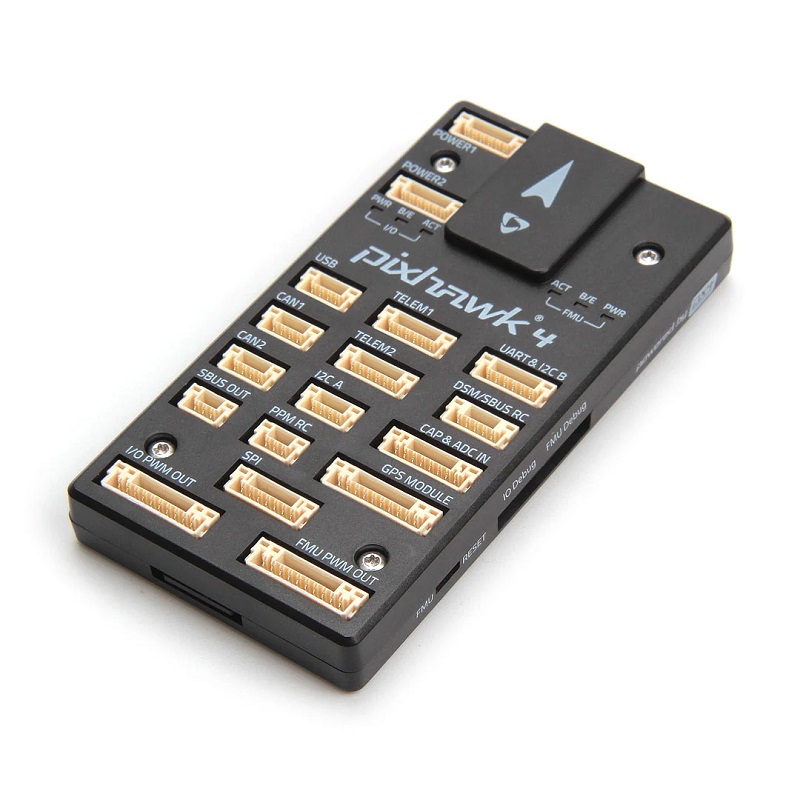
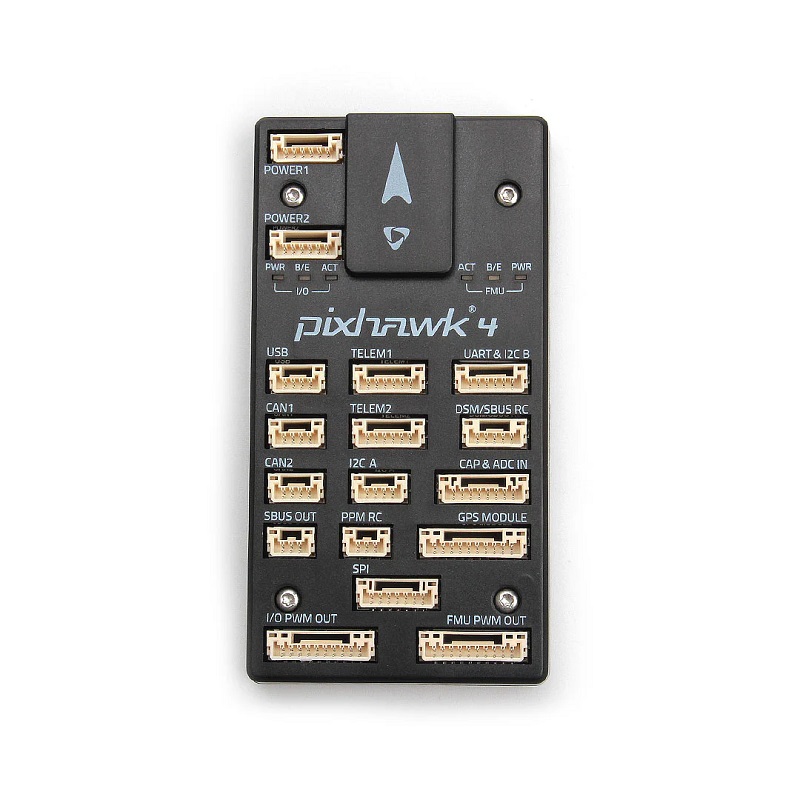
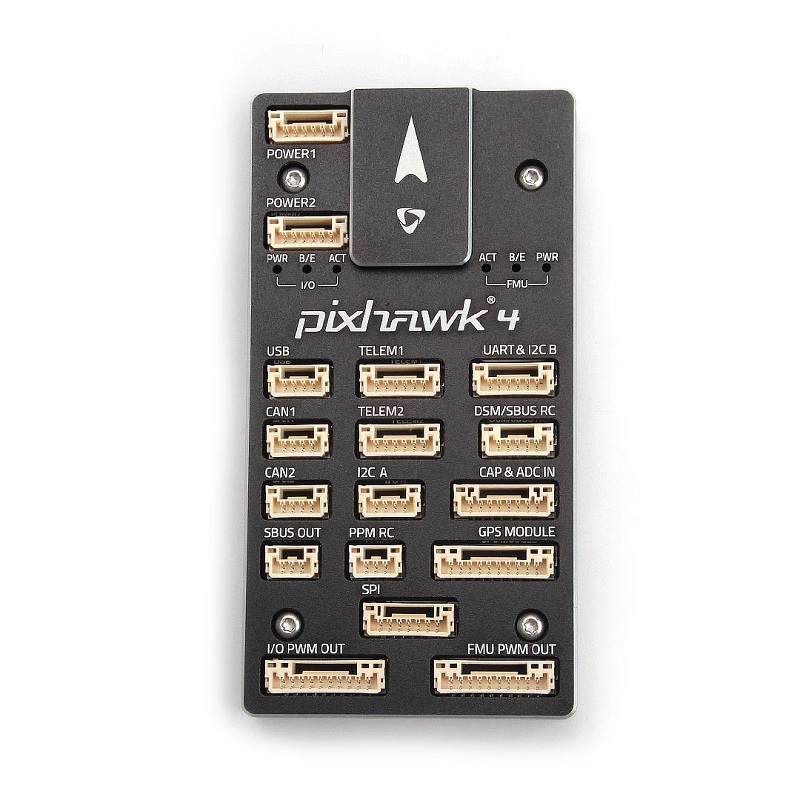
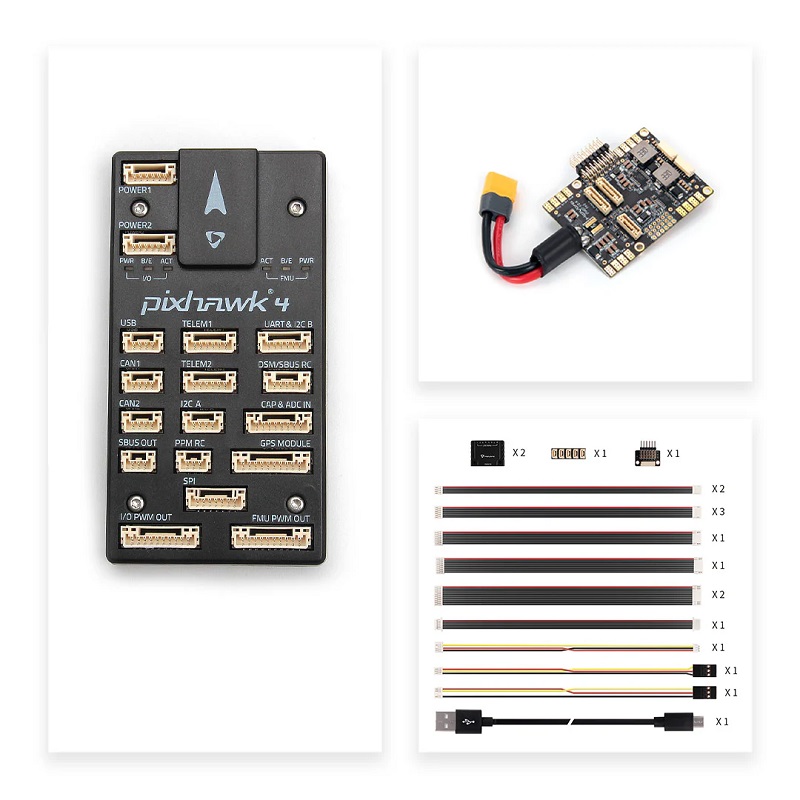
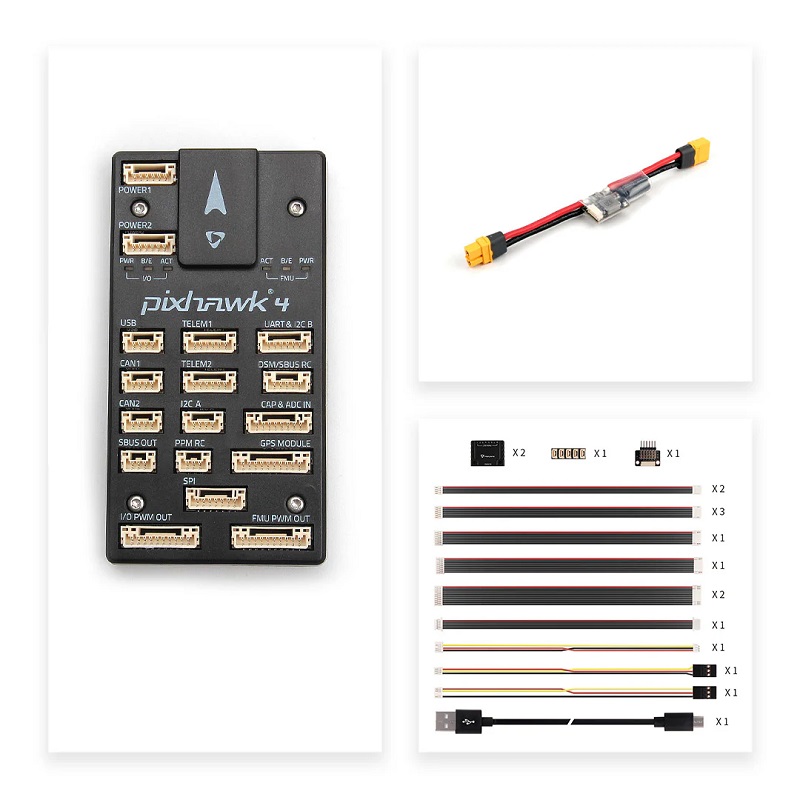
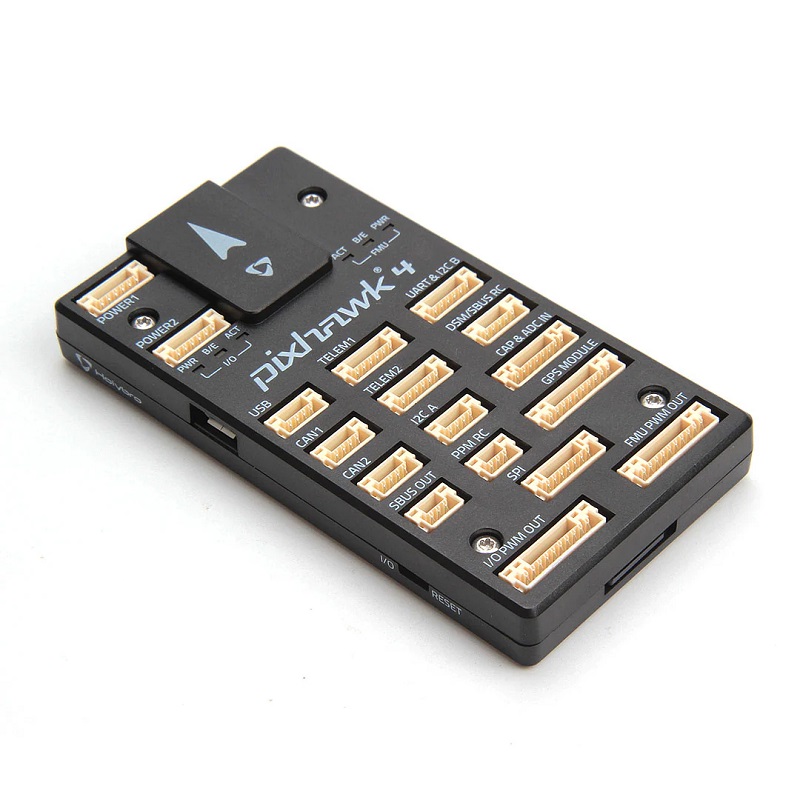
Holybro Pixhawk 4 Flight Controller & PM02 12S Power Module & M10 GPS Set
The Holybro Pixhawk 4 is a professional-grade flight controller featuring a dual-processor STM32F7/F1 architecture, low-noise IMUs with vibration isolation, and extensive I2C/SPI connectivity. This set includes the PM02 12S power module and M10 GPS for a complete autopilot solution compatible with ArduPilot and PX4 firmware.
Features
- Dual-processor design with STM32F765 main MCU and STM32F103/F100 I/O co-processor.
- High-performance, low-noise IMUs (ICM-20689, BMI055/ICM-20602) with vibration isolation for precise stabilization.
- Extensive connectivity with 2x SPI buses and 4x I2C buses for sensors, GPS, and payloads.
- Includes PM02 V3 power module supporting up to 12S LiPo batteries and M10 GPS module.
- Runs the NuttX real-time operating system, optimized for ArduPilot and PX4 firmware.
Out of stock
The Pixhawk 4 flight controller is engineered for demanding autonomous vehicle applications, from aerial drones to ground robotics. Its core is built around an STM32F765 microcontroller with 2MB of flash and 512KB of RAM, providing the computational headroom required for complex navigation algorithms and sensor fusion models. A separate STM32F103/F100 I/O processor handles real-time peripheral management, ensuring robust and responsive system control.
Sensor integrity is paramount, achieved through a suite of high-grade Bosch and InvenSense IMUs and barometers, all mounted on specialized vibration-damping material. Data-ready signals from each sensor are routed to dedicated interrupt pins, allowing for precise hardware-level time-stamping critical for accurate state estimation. The board’s electrical design supports a wide input range on the servo rail and includes robust power conditioning for clean 5V and 3.3V supplies to connected peripherals.
Additional Information
| Weight | 0.289 kg |
|---|---|
| Dimensions | 10 × 14 × 7 cm |