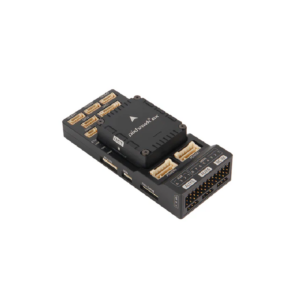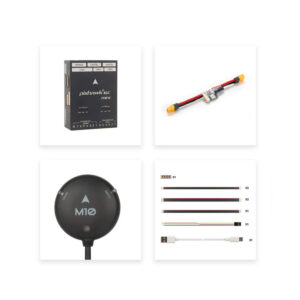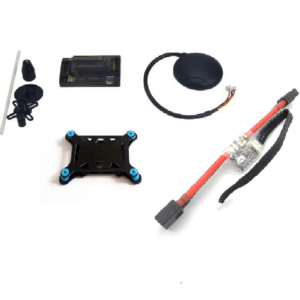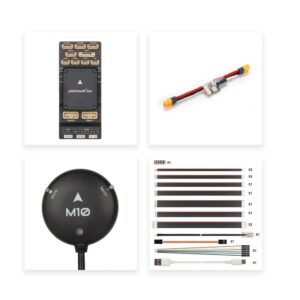
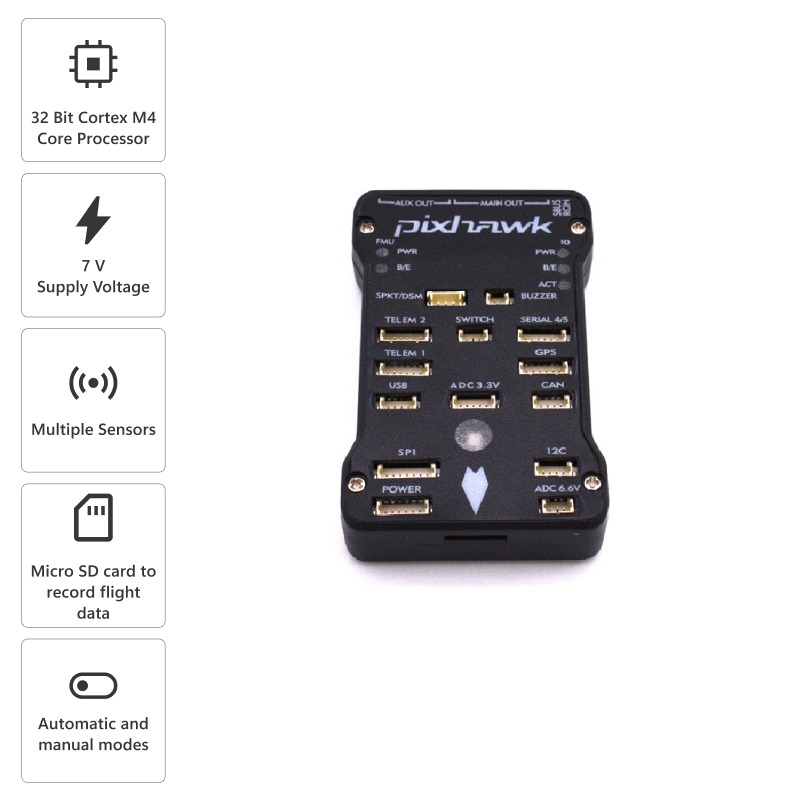
Pixhawk 2.4.8 PX4 32 Bit Autopilot Flight Controller
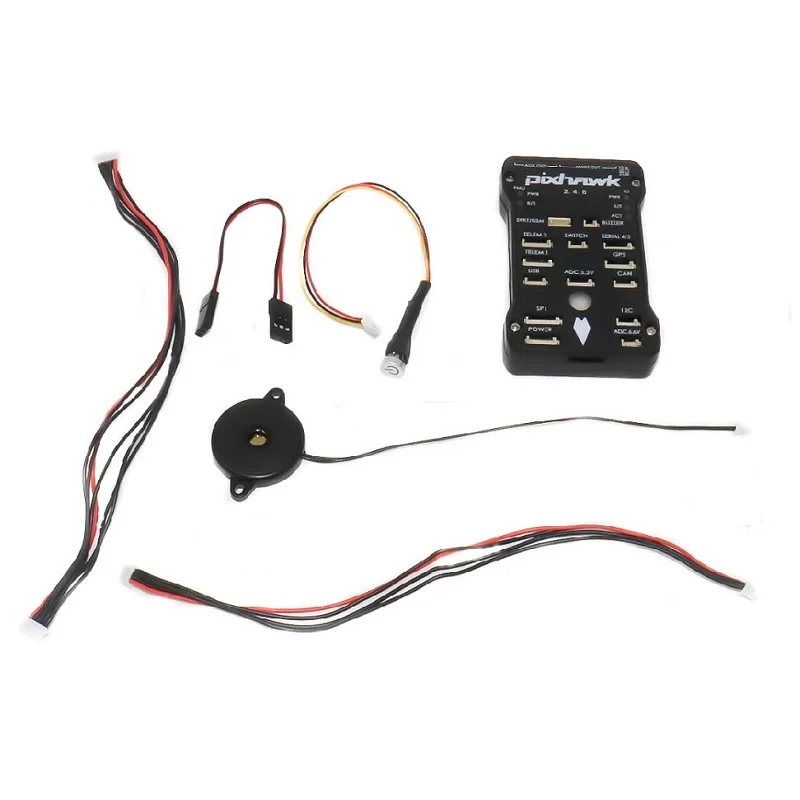
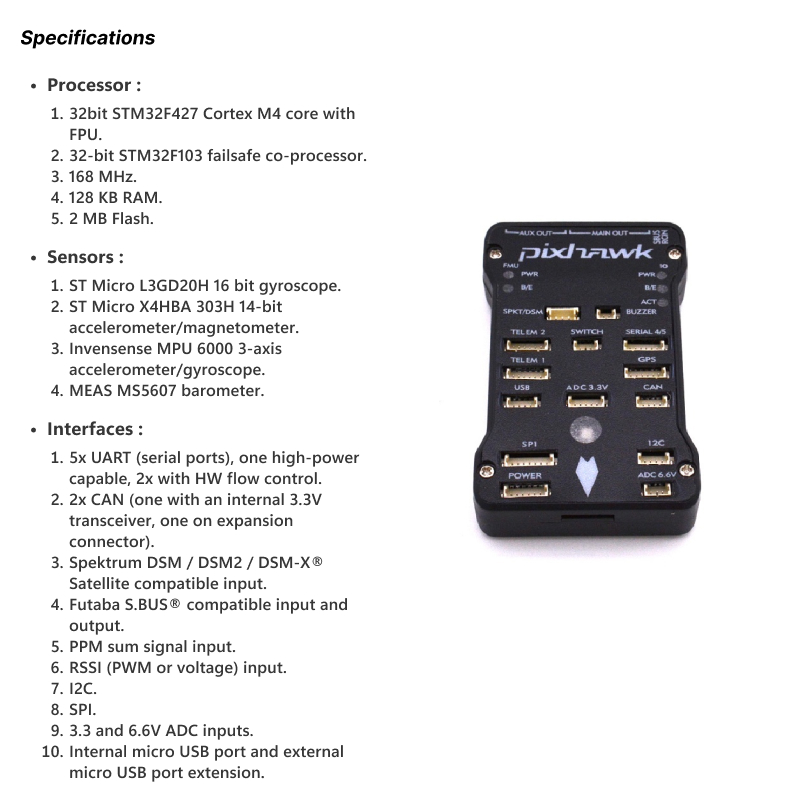
The Pixhawk 2.4.8 is a 32-bit PX4 autopilot flight controller built around a dual-processor architecture for robust, redundant control of multirotor, fixed-wing, and rover platforms. It features comprehensive sensor fusion, extensive I/O interfaces, and supports the PX4/ArduPilot firmware ecosystem for advanced autonomous mission planning.
Features
- Dual-processor design with STM32F427 Cortex-M4 main CPU and STM32F103 failsafe co-processor for redundancy.
- Integrated high-precision sensors: L3GD20H gyro, LSM303D accelerometer/magnetometer, MPU6000 IMU, and MS5607 barometer.
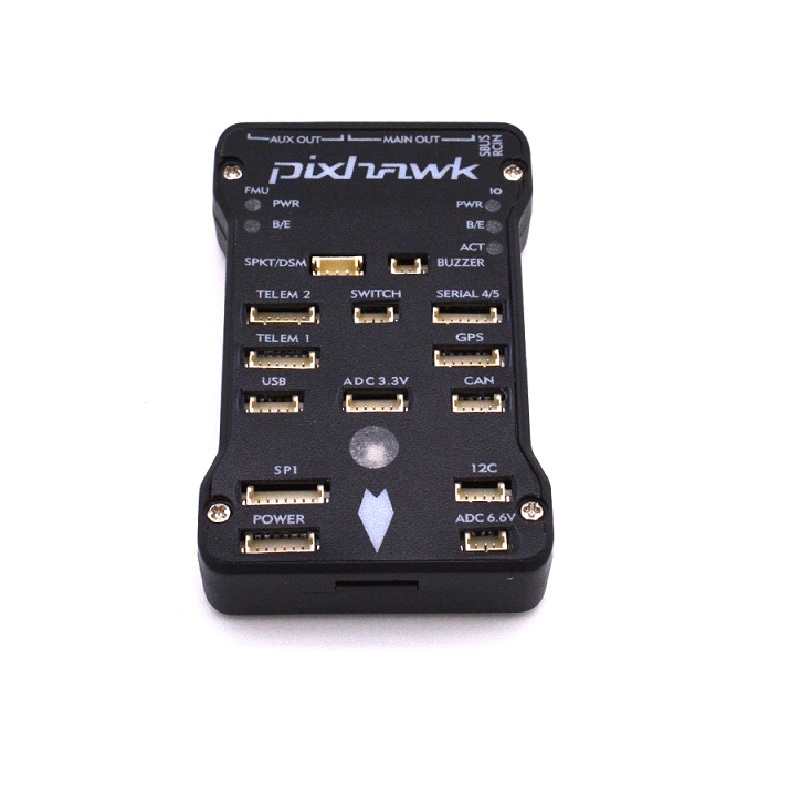
- Extensive connectivity with 5x UARTs, 2x CAN bus, I2C, SPI, S.BUS, DSM, and 14 PWM/servo outputs.
- Onboard microSD slot for high-rate flight data logging and mission storage.
- Redundant power input with automatic failover and backup power supply for safety-critical applications.
Out of stock
The Pixhawk 2.4.8 flight controller represents a mature, open-source autopilot platform designed for professional UAV development and research. Its core architecture leverages a high-performance 168 MHz STM32F427 Cortex-M4 processor with a floating-point unit (FPU), paired with a dedicated STM32F103 co-processor that acts as an independent failsafe controller. This hardware redundancy ensures continued operation or safe termination if the primary system encounters a fault.
Sensor data is fused from a suite of industrial-grade components, including a 16-bit ST L3GD20H gyroscope, a 14-bit ST LSM303D accelerometer/magnetometer combo, an Invensense MPU6000 3-axis accelerometer/gyroscope, and a MEAS MS5607 barometer. This multi-sensor array provides accurate attitude estimation, navigation, and altitude hold capabilities across diverse environmental conditions. The board supports a wide input voltage range via dual power ports and includes a microSD card slot for extensive data logging.
Additional Information
| Weight | 0.04 kg |
|---|---|
| Dimensions | 8.2 × 5 × 1.6 cm |