SKU: DRFC-2068
📋 GST Invoice Available

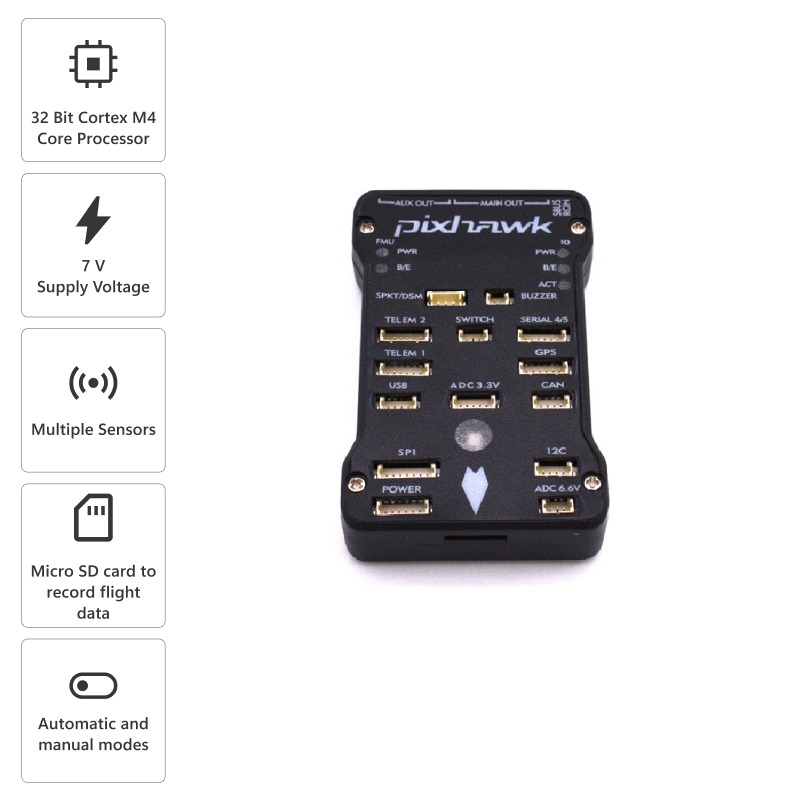
Pixhawk 2.4.8 PX4 32 Bit Autopilot Flight Controller

₹6,929.00 (Inclusive of all taxes)
Out of Stock

The Pixhawk 2.4.8 is a 32-bit PX4 autopilot flight controller built around a dual-processor architecture for robust, redundant control of multirotor, fixed-wing, and rover platforms. It features comprehensive sensor fusion, extensive I/O interfaces, and supports the PX4/ArduPilot firmware ecosystem for advanced autonomous mission planning.

Features

  • Dual-processor design with STM32F427 Cortex-M4 main CPU and STM32F103 failsafe co-processor for redundancy.
  • Integrated high-precision sensors: L3GD20H gyro, LSM303D accelerometer/magnetometer, MPU6000 IMU, and MS5607 barometer.
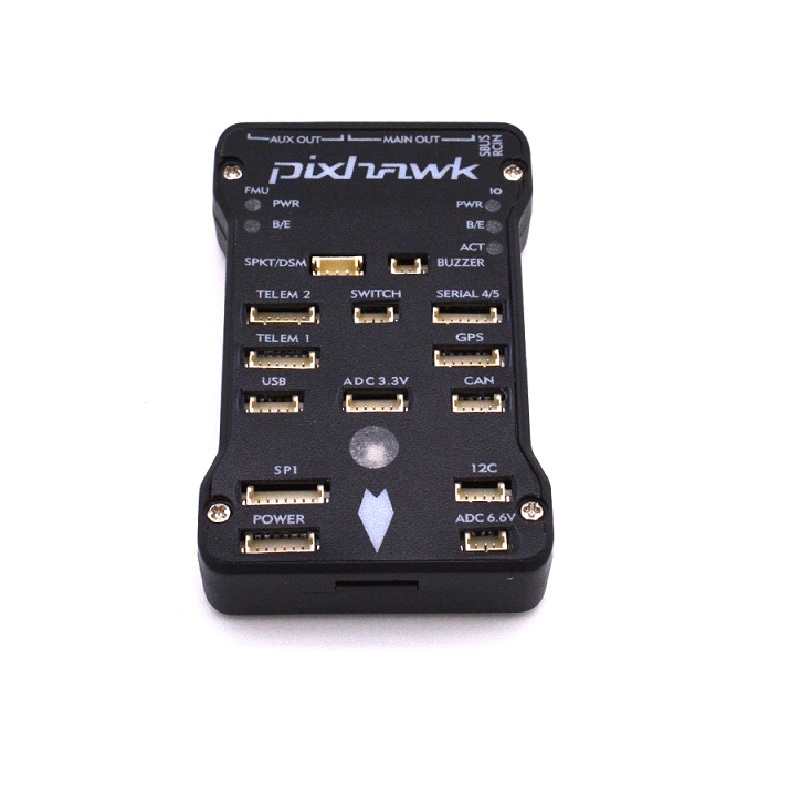
  • Extensive connectivity with 5x UARTs, 2x CAN bus, I2C, SPI, S.BUS, DSM, and 14 PWM/servo outputs.
  • Onboard microSD slot for high-rate flight data logging and mission storage.
  • Redundant power input with automatic failover and backup power supply for safety-critical applications.

Out of stock

Description

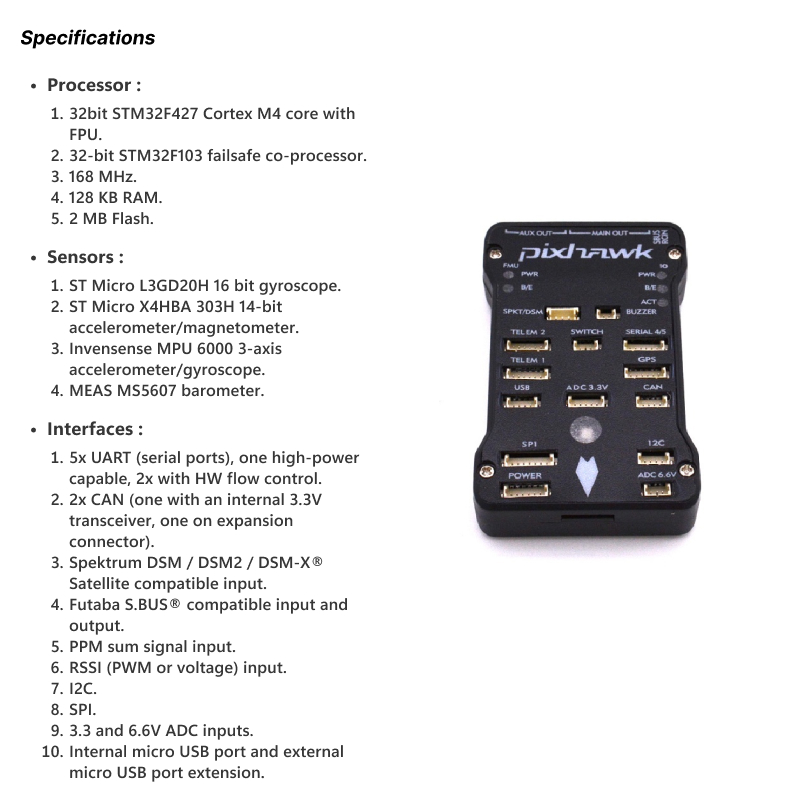
The Pixhawk 2.4.8 flight controller represents a mature, open-source autopilot platform designed for professional UAV development and research. Its core architecture leverages a high-performance 168 MHz STM32F427 Cortex-M4 processor with a floating-point unit (FPU), paired with a dedicated STM32F103 co-processor that acts as an independent failsafe controller. This hardware redundancy ensures continued operation or safe termination if the primary system encounters a fault.

Sensor data is fused from a suite of industrial-grade components, including a 16-bit ST L3GD20H gyroscope, a 14-bit ST LSM303D accelerometer/magnetometer combo, an Invensense MPU6000 3-axis accelerometer/gyroscope, and a MEAS MS5607 barometer. This multi-sensor array provides accurate attitude estimation, navigation, and altitude hold capabilities across diverse environmental conditions. The board supports a wide input voltage range via dual power ports and includes a microSD card slot for extensive data logging.

Key Features

  • Dual-Processor Redundancy: Primary STM32F427 Cortex-M4 core (168 MHz, 2MB Flash) with dedicated STM32F103 failsafe co-processor for enhanced system reliability.
  • Comprehensive Sensor Suite: Integrates L3GD20H gyro, LSM303D accel/mag, MPU6000 IMU, and MS5607 barometer for robust 10-DOF inertial navigation and altitude estimation.
  • High-Density Connectivity: Features 5x UART serial ports (2 with HW flow control), 2x CAN bus interfaces, I2C, SPI, Spektrum DSM/DSM2/DSM-X, Futaba S.BUS, PPM, and RSSI inputs.
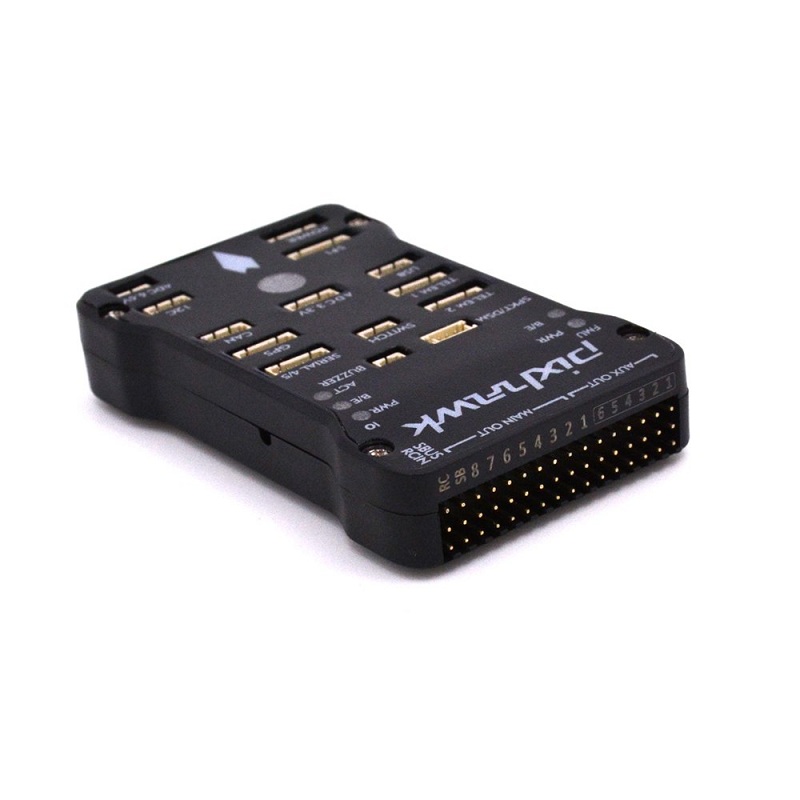
  • Expanded Control Outputs: Provides 14 PWM/servo outputs for controlling complex multirotor, fixed-wing, or gimbal setups.
  • Data Logging & Mission Storage: Onboard microSD card slot supports high-frequency logging of flight parameters, sensor data, and mission waypoints.
  • Redundant Power Architecture: Dual power inputs with automatic failover and integrated backup power supply for uninterrupted operation.
  • Developer-Friendly Ecosystem: Runs the NuttX RTOS and is fully compatible with the open-source PX4 and ArduPilot firmware stacks, enabling extensive customization.

Applications

  • Professional-grade autonomous multirotor drones for mapping, surveying, and inspection.
  • Fixed-wing UAV platforms requiring advanced waypoint navigation and fail-safe redundancy.
  • Heavy-lift and cargo drone systems where control reliability is paramount.
  • Research and development platforms for testing new UAV algorithms and control strategies.
  • Rover and ground vehicle autopilot applications leveraging the extensive I/O and sensor suite.

Technical Specifications

Model / NamePixhawk 2.4.8
Main Processor32-bit STM32F427 Cortex-M4 with FPU @ 168 MHz
Failsafe Processor32-bit STM32F103
RAM128 KB
Flash Memory2 MB
SensorsST L3GD20H 16-bit Gyro, ST LSM303D 14-bit Accel/Mag, Invensense MPU6000 IMU, MEAS MS5607 Barometer
Input Voltage7V (Typical, via redundant inputs)
FirmwarePX4 / ArduPilot (Mission Planner, QGroundControl)
Serial Interfaces5x UART
CAN Bus2x CAN
RC InputS.BUS, PPM, Spektrum DSM/DSM2/DSM-X Satellite, RSSI (PWM/Voltage)
Output Channels14x PWM/Servo
Data LoggingMicroSD Card Slot (Yes)
Dimensions (L x W x H)82 x 50 x 16 mm
Weight40 g

Frequently Asked Questions

What is the primary firmware supported by the Pixhawk 2.4.8?

The Pixhawk 2.4.8 is designed to run the open-source PX4 or ArduPilot firmware stacks. You can flash and configure it using ground control stations like QGroundControl or Mission Planner. These firmware options provide access to advanced autonomous flight modes, mission planning, and extensive parameter tuning for multirotor, fixed-wing, and rover vehicles.

How does the redundant failsafe system work on this flight controller?

Redundancy is achieved through a dedicated STM32F103 co-processor that runs independently from the main STM32F427 CPU. If the primary processor fails or locks up, the co-processor can take over basic flight stabilization or trigger a predefined failsafe action, such as returning to launch or landing. The system also features redundant power inputs with automatic switching.

What types of vehicles is the Pixhawk 2.4.8 suitable for?

This autopilot is highly versatile and is suitable for a wide range of unmanned vehicles, including quadcopters, hexacopters, octocopters, fixed-wing aircraft, and rovers. Its 14 PWM outputs support complex motor and servo layouts, while its robust sensor suite and dual-processor design make it ideal for professional, commercial, and research applications where reliability is critical.

Can I connect a GPS module to the Pixhawk 2.4.8?

Yes, GPS modules are connected via one of the board's five available UART serial ports, typically using the dedicated GPS/UART port. The Pixhawk is compatible with standard NMEA or u-blox protocol GPS units, as well as more advanced GPS-compass (M8N, M9N) and RTK modules for high-precision navigation when used with PX4 or ArduPilot firmware.

Package Includes

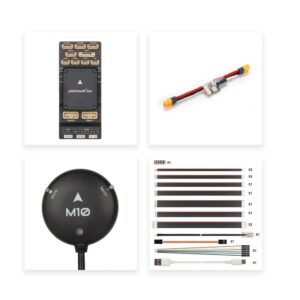
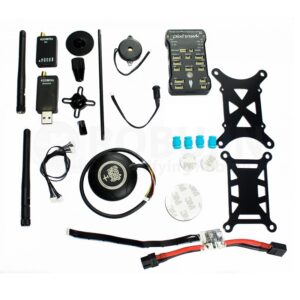
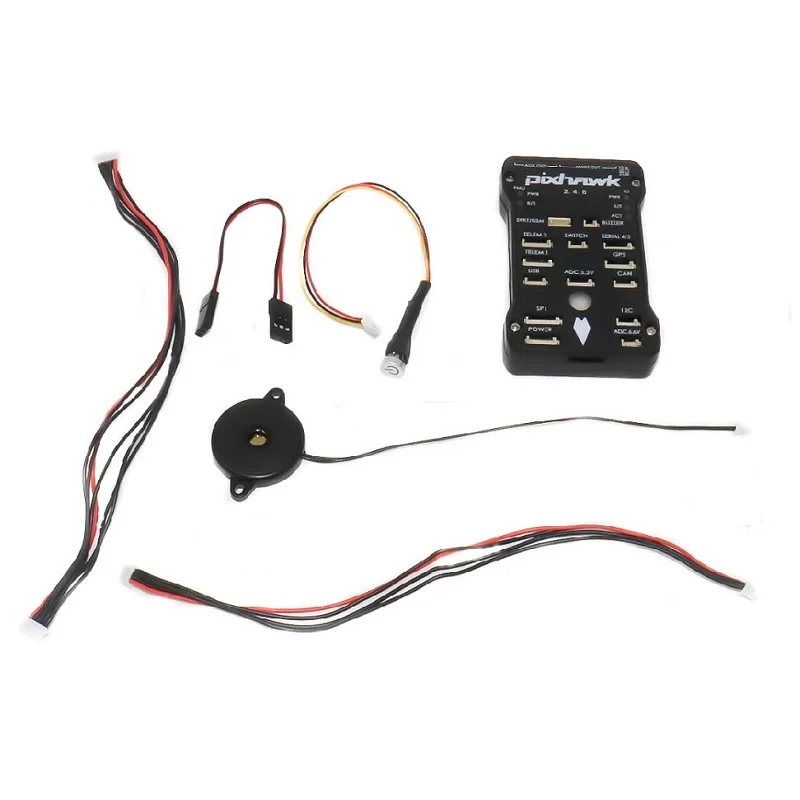
  • 1 x Pixhawk 2.4.8 32 Bit Autopilot Flight Controller
  • 3 x Connecting Cables

Additional Information

Weight 0.04 kg
Dimensions 8.2 × 5 × 1.6 cm