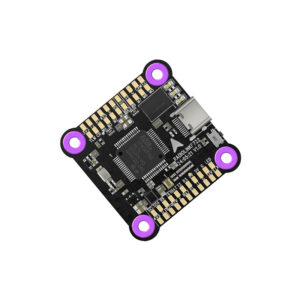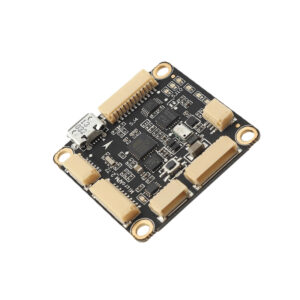
Naze32 10DOF Flight Control Board
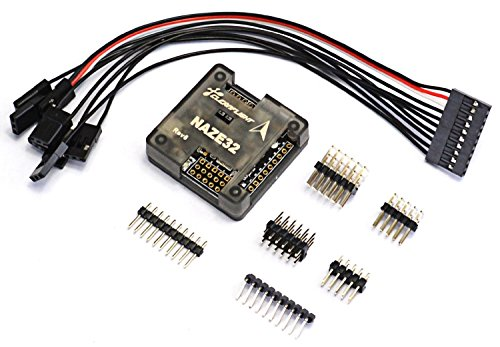
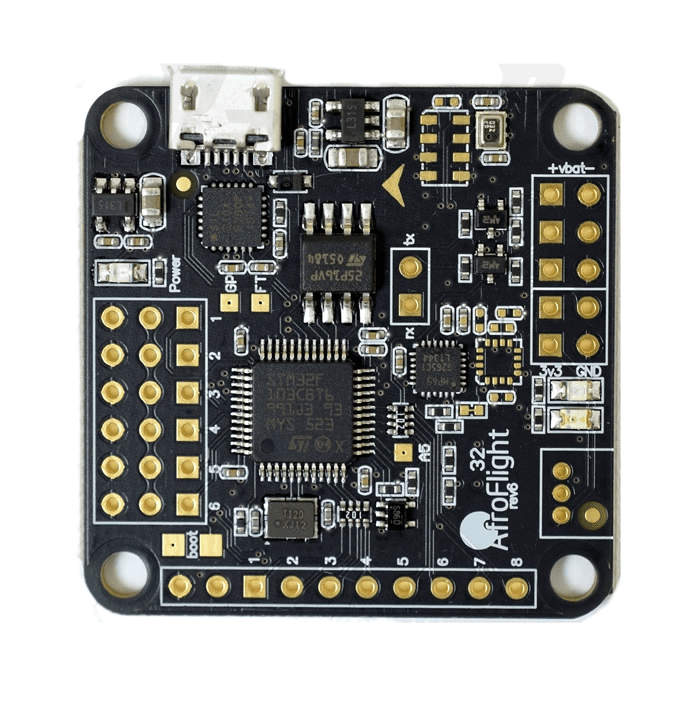
The Naze32 10DOF Flight Control Board is a classic open-source autopilot featuring a 32-bit STM32F103CB processor, MPU6500 gyro/accelerometer, BMP280 barometer, and HMC5833 magnetometer. It supports MultiWii and Cleanflight firmware for versatile multirotor configurations, including GPS-assisted flight modes.
Features
- 10DOF sensor suite: MPU6500 gyro/accelerometer, BMP280 barometer, and HMC5833 magnetometer.
- 32-bit STM32F103CB processor running at 72MHz for stable flight control.
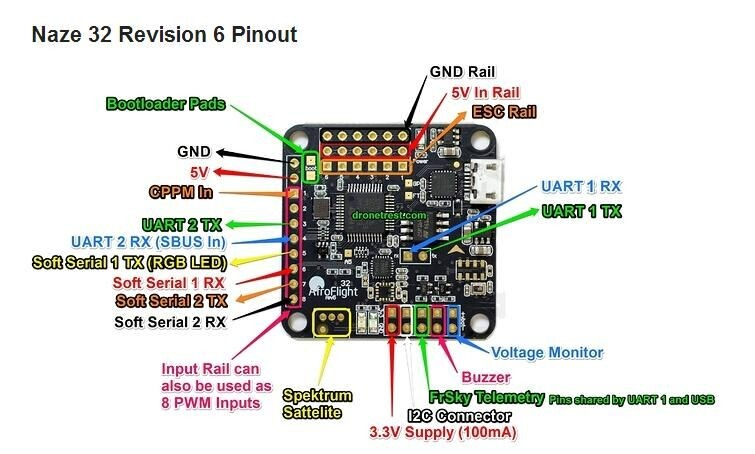
- Supports PWM, PPM, and Spektrum satellite receivers with up to 8 channels.
- Integrated FrSky telemetry inverter and battery voltage monitoring.
- Compatible with MultiWii and Cleanflight firmware for Quad, CubePilot, Octo, and other frame types.
Out of stock
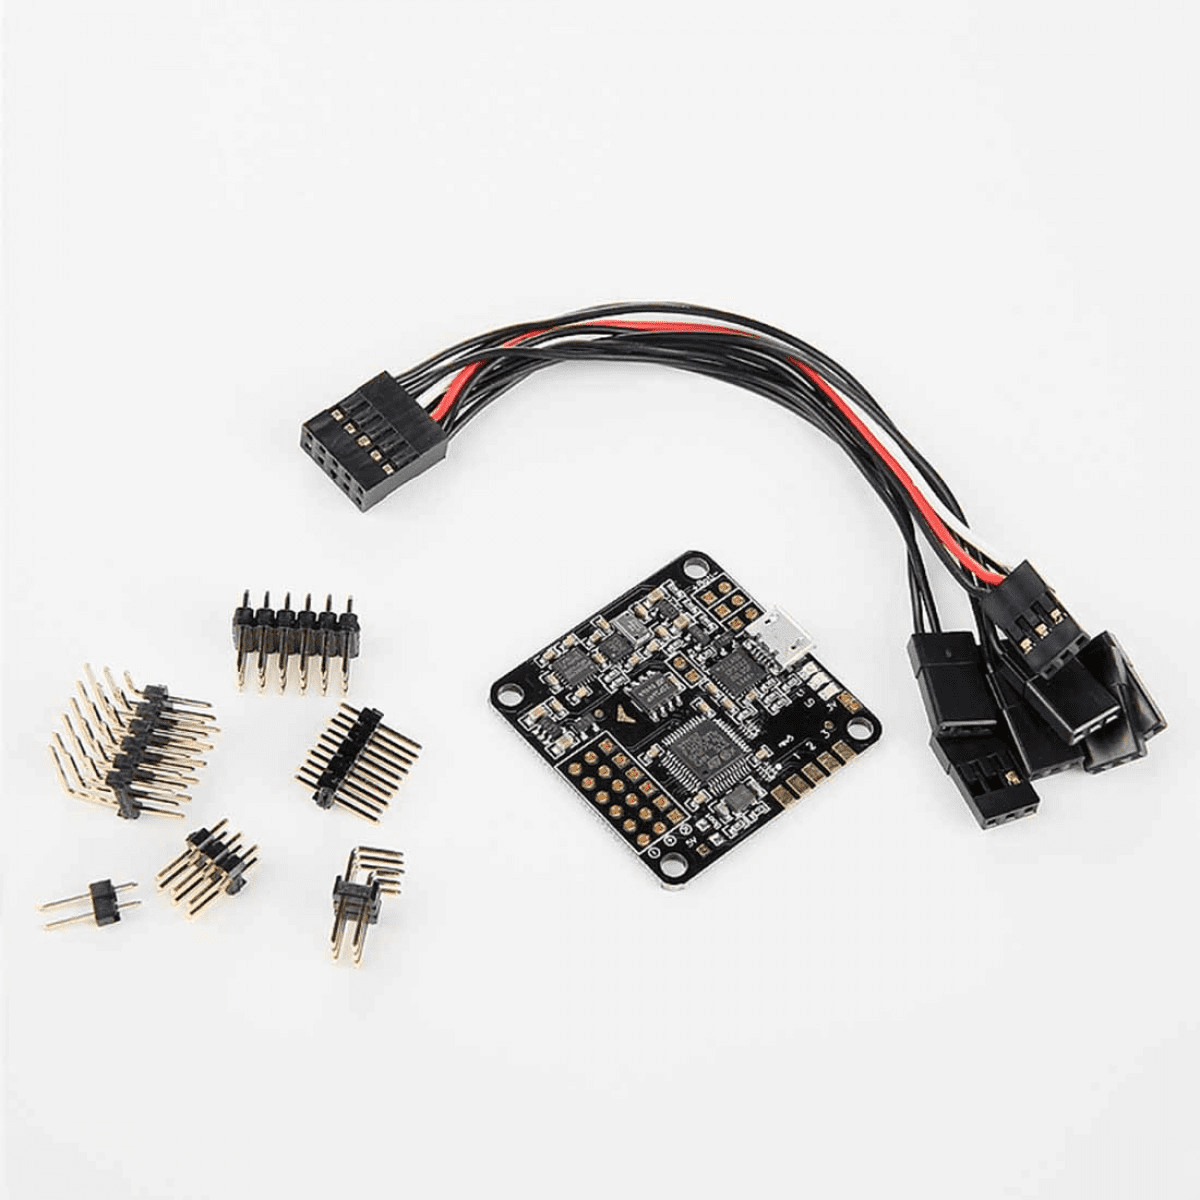
The Naze32 10DOF is a foundational flight controller in the FPV and multirotor community, built around the robust STM32F103CB microcontroller. Its integrated 10-degree-of-freedom sensor package provides essential data for advanced autonomous flight modes, including position hold and return-to-home when paired with a GPS module. The board’s design prioritizes a compact footprint with vertical pin headers, simplifying integration into a wide range of frame sizes.
Electrical design includes a flexible input voltage rail accepting up to 16V, with a dedicated sense line for monitoring 6S LiPo batteries up to 35V. The onboard FrSky telemetry inverter facilitates real-time data transmission to compatible transmitters. Configuration is handled via a MicroUSB port using the Chrome-based Baseflight or Cleanflight Configurator, offering an accessible interface for PID tuning and mode assignment without requiring specialized cables.
Additional Information
| Weight | 0.015 kg |
|---|---|
| Dimensions | 4 × 4 × 1 cm |