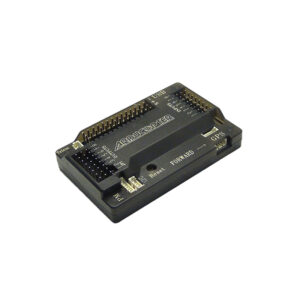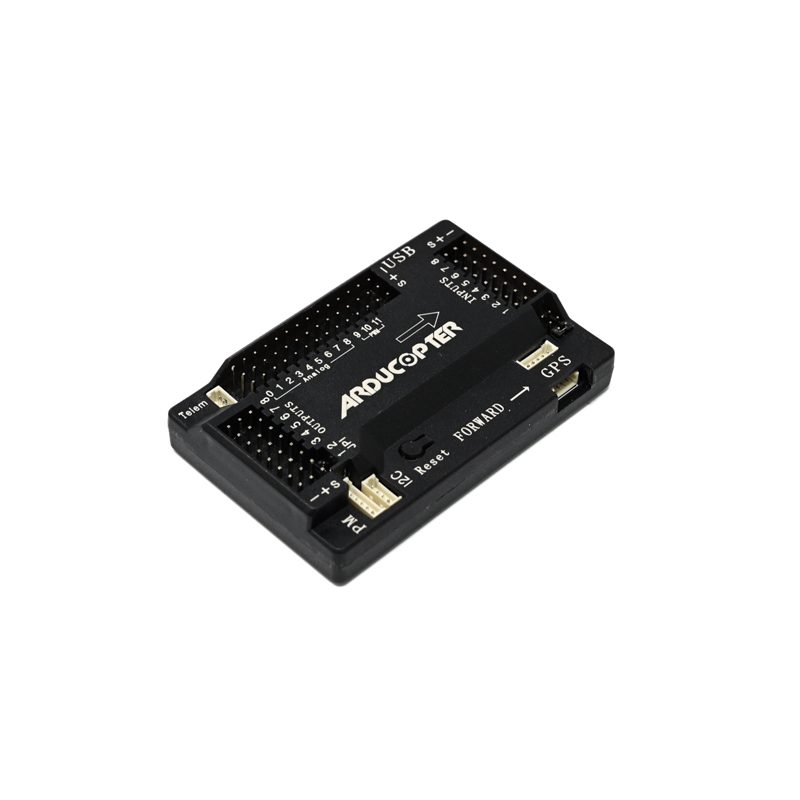
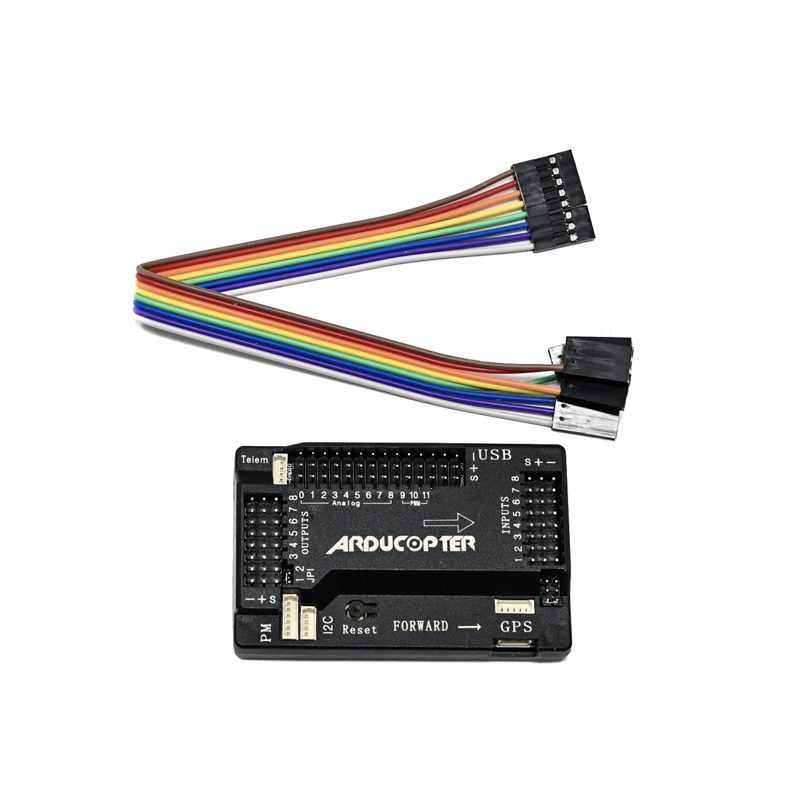
APM 2.8 Flight Controller with Built-in Compass
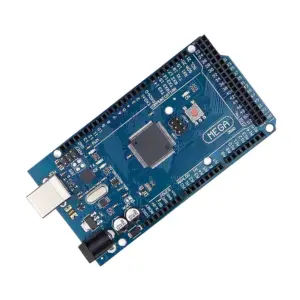
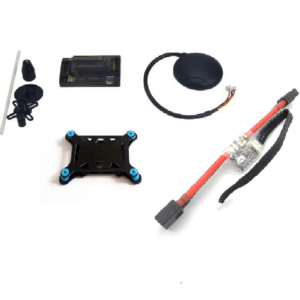
The APM 2.8 Flight Controller is an open-source autopilot system based on the ATMEGA2560 processor, designed for multirotor, fixed-wing, and rover applications. It features a built-in compass, MS5611 barometer, and MPU-6000 IMU, supporting autonomous GPS missions via the Mission Planner ground control software.
Features
- Open-source APM 2.8 autopilot with ATMEGA2560 and ATMEGA32U-2 processors.
- Integrated compass with Jumper-selectable internal/external compass operation.
- Features the MPU-6000 6-axis gyro/accelerometer and MS5611 high-performance barometer.
- Supports autonomous flight, waypoint navigation, and data logging via 4MB Dataflash.
- Compatible with Mission Planner software for configuration, simulation, and mission planning.
Out of stock
The APM 2.8 Flight Controller is a robust, open-source autopilot platform, representing an evolution of the APM 2.5/2.6 series. It integrates core sensors including a 3-axis gyrometer, accelerometer, and barometric pressure sensor to calculate precise motor commands for stable flight. The system processes sensor data to compute desired motor speeds, which are then sent to connected Electronic Speed Controllers (ESCs).
This controller is designed for versatility, capable of autonomously piloting multirotor drones, fixed-wing aircraft, and ground rovers. Its architecture supports extensive telemetry, real-time data logging, and complex GPS-guided mission execution. The inclusion of a built-in compass, configurable via a hardware Jumper, simplifies installation and reduces external wiring, making it a practical choice for custom UAV builds and educational projects.
Additional Information
| Weight | 0.082 kg |
|---|---|
| Dimensions | 7 × 4.5 × 1.5 cm |