SKU: DRFC-2000
📋 GST Invoice Available

Holybro Pixhawk 6C Mini Flight Controller

₹22,049.00 (Inclusive of all taxes)
Out of Stock

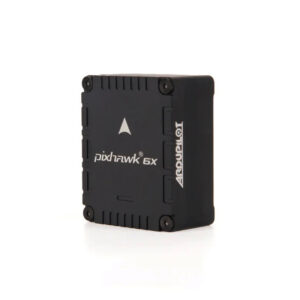
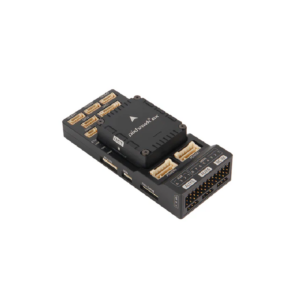
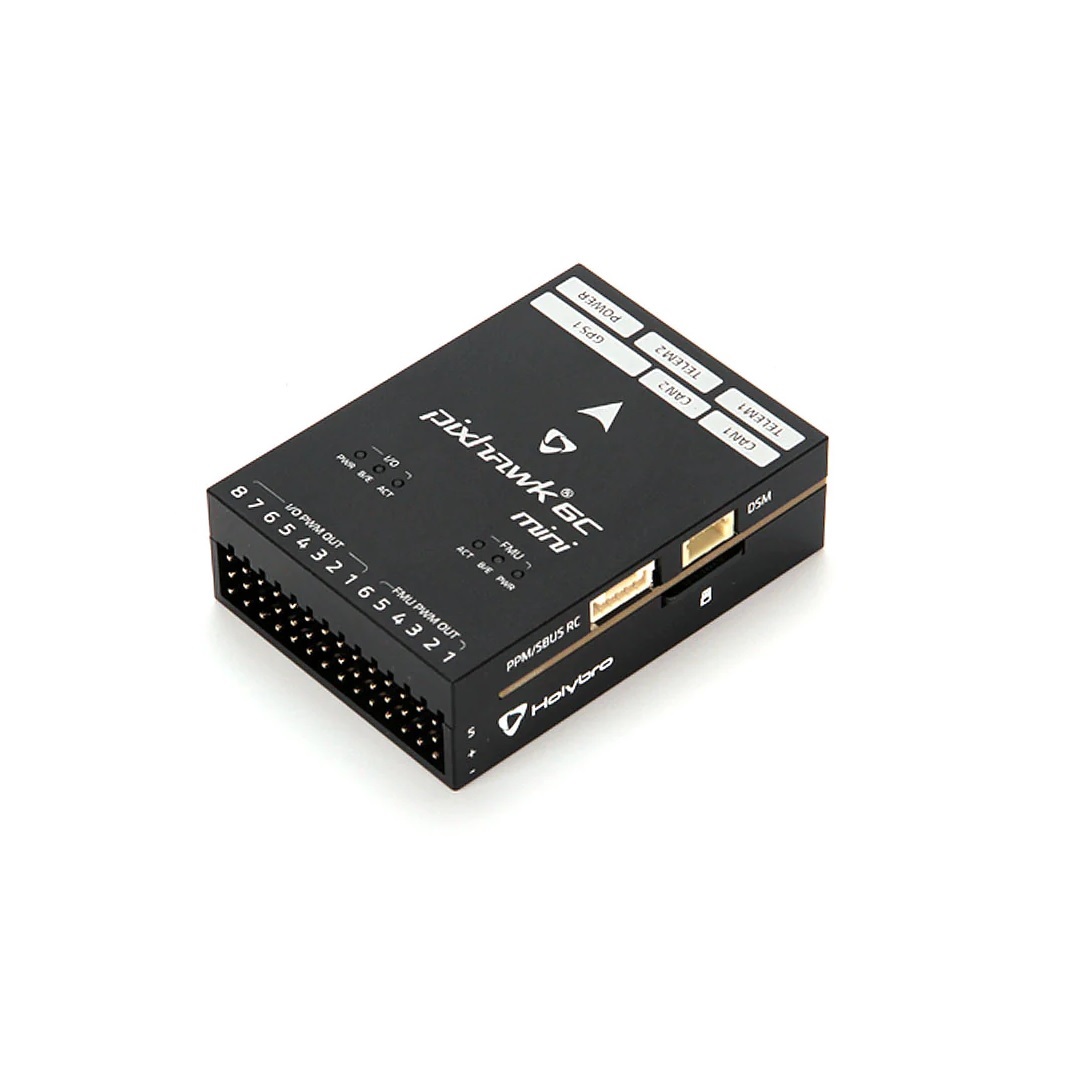
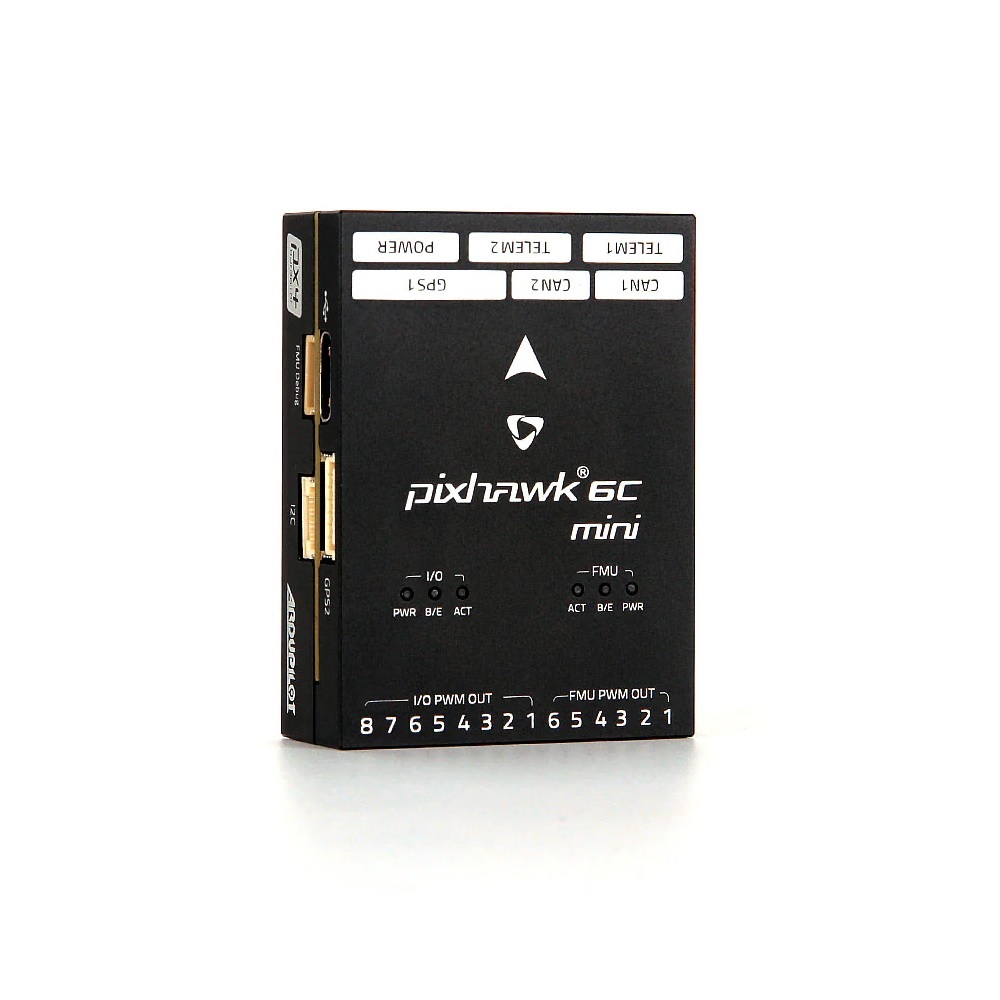
The Holybro Pixhawk 6C Mini Flight Controller is a compact, high-performance autopilot based on the Pixhawk FMUv6C open standard, featuring an STM32H743 processor and redundant, temperature-controlled IMUs for reliable autonomous vehicle control in academic and commercial applications.

Features

  • High-performance STM32H743 Arm Cortex-M7 processor running at 480 MHz with 2MB flash and 1MB RAM.
  • Redundant, temperature-controlled IMUs from Bosch and InvenSense with integrated vibration isolation.
  • Compact form factor with built-in PWM header, designed for space-constrained autonomous vehicle builds.
  • Based on the Pixhawk FMUv6C open standard, ensuring compatibility with ArduPilot and PX4 firmware.
  • Optimized for reliable operation in both academic research and commercial drone applications.

Out of stock

Description

The Pixhawk 6C Mini delivers the core processing power and sensor suite of the standard 6C in a reduced footprint. Its STM32H743 microcontroller provides substantial computational headroom for complex autonomous navigation algorithms, sensor fusion, and real-time control tasks within the PX4 or ArduPilot ecosystem.

Engineered for reliability, the board incorporates a dual IMU setup with active thermal management via onboard heating resistors. This maintains the inertial measurement units at their optimal operational temperature, significantly reducing bias drift. A mechanical vibration isolation system is integrated to dampen high-frequency noise from motors and propellers, ensuring clean sensor data for stable flight performance.

Key Features

  • STM32H743VIT6 microcontroller with Arm Cortex-M7 core @ 480 MHz for high-speed processing.
  • Dual redundant IMU configuration featuring Bosch BMI088 and InvenSense ICM-20689 sensors.
  • Onboard IMU heating resistors for precise temperature control and minimized thermal drift.
  • Integrated vibration damping system using soft mounting to filter mechanical noise.
  • Compact design (approx. 39g) with a built-in 8-channel PWM output header for direct servo/ESC connection.
  • Compliant with the Pixhawk FMUv6C and Connector Standard for broad hardware compatibility.
  • Supports a wide range of peripherals including GPS, telemetry, and CAN bus for expandability.
  • Optimized 5V regulated power architecture with robust input filtering for clean system operation.

Applications

  • Compact autonomous research and mapping drones requiring a full-featured, space-efficient autopilot.
  • Academic and educational platforms for robotics and UAV development courses.
  • Commercial drone builds for inspection, surveillance, or light payload delivery where size and weight are constrained.
  • Integration into custom VTOL (Vertical Take-Off and Landing) or hybrid unmanned aerial vehicles.
  • Upgrading legacy mini drone platforms to a modern, redundant, and high-performance flight control system.

Technical Specifications

Item TypeFlight Controller
ProcessorSTM32H743
Core ArchitectureArm Cortex-M7 @ 480 MHz
Flash Memory2 MB
RAM1 MB
IMU SensorsBosch BMI088, InvenSense ICM-20689 (Redundant)
IMU FeaturesTemperature-Controlled, Vibration Isolated
Max. Working Voltage6V
Weight39 g
Form FactorPixhawk Mini
Firmware CompatibilityPX4, ArduPilot
Built-in Outputs8-channel PWM Header

Frequently Asked Questions

What firmware is compatible with the Pixhawk 6C Mini?

The Pixhawk 6C Mini is fully compatible with the latest versions of both the PX4 and ArduPilot open-source flight stacks. You can flash the appropriate firmware via USB using QGroundControl or Mission Planner. The board's FMUv6C standard ensures full driver support and feature access within these ecosystems.

What is the purpose of the onboard IMU heaters?

The integrated heating resistors actively maintain the inertial measurement units (IMUs) at a consistent, optimal temperature. This minimizes thermal bias drift in the accelerometer and gyroscope readings, which is critical for maintaining precise attitude estimation and flight stability, especially in varying environmental conditions.

What is the maximum input voltage for the 6C Mini?

The flight controller's maximum working voltage is 6V. It is designed to be powered via its dedicated power input port from a regulated 5V source, typically supplied by a Power Module connected to the main LiPo battery. Do not apply voltage directly from a 2S+ LiPo battery without a suitable regulator or Power Module.

Does the Mini version support connecting servos directly?

Yes, a key feature of the Mini form factor is its built-in 8-channel PWM output header. This allows you to connect servos, ESCs, or other PWM actuators directly to the flight controller without requiring a separate PWM decoder or expansion board, simplifying wiring in smaller builds.

Package Includes

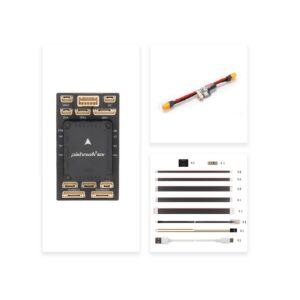
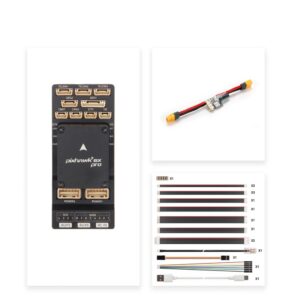
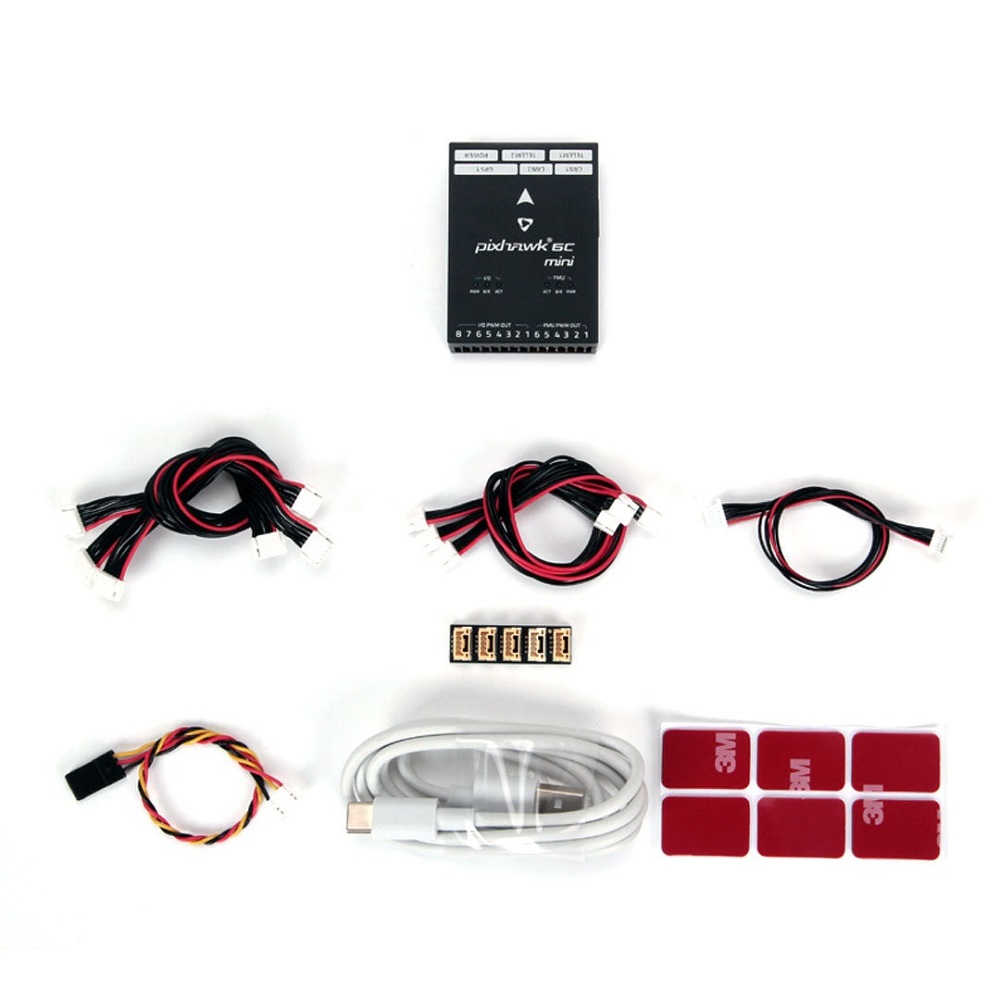
  • 1 x Pixhawk 6C Mini Flight Controller
  • 1 x Cable Set

Additional Information

Weight 0.157 kg
Dimensions 13 × 15 × 5 cm