SKU: DRFC-1978
📋 GST Invoice Available

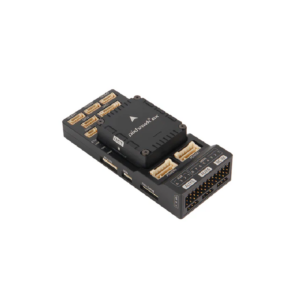
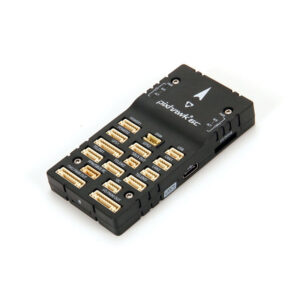
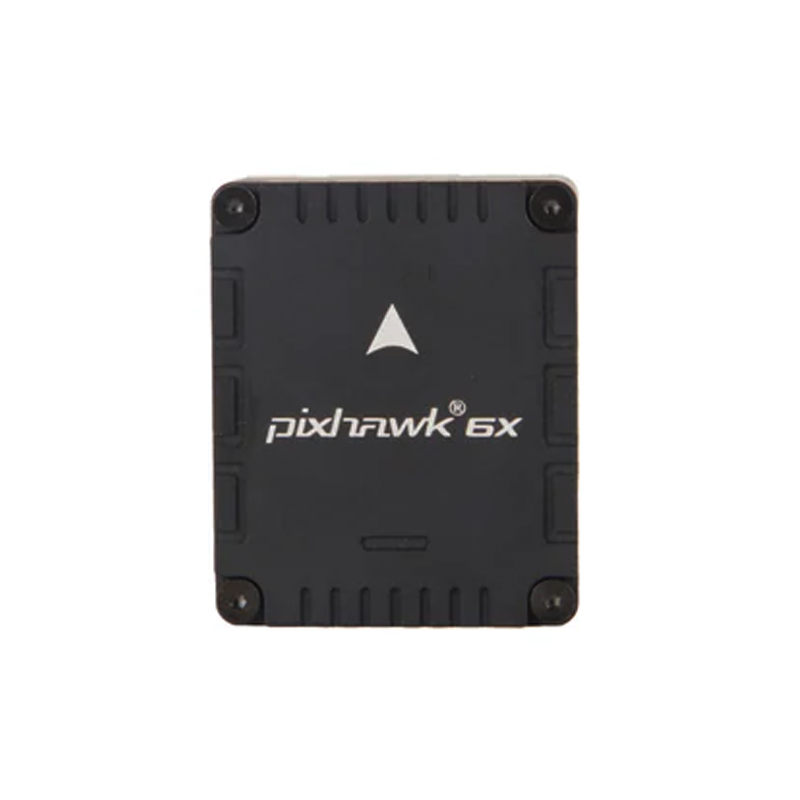
Holybro Pixhawk 6X Flight Controller Module Only (No GPS)

₹21,896.00 (Inclusive of all taxes)
Out of Stock

The Holybro Pixhawk 6X is a high-reliability modular flight controller designed for advanced UAV platforms, featuring triple-redundant IMUs, dual barometers, and a powerful STM32H753 processor for robust ArduPilot and PX4 integration.

Features

  • Triple-redundant ICM-45686 IMUs with BalancedGyroâ„¢ technology for maximum sensor reliability.
  • High-performance STM32H753 Cortex-M7 FMU processor running at 480 MHz with 2MB flash.
  • Modular design with 100-pin and 50-pin Pixhawk Autopilot Bus connectors for flexible system expansion.
  • Completely isolated sensor domains and advanced vibration damping for optimal flight stability.
  • Integrated Ethernet port for high-speed mission computer and companion computer connectivity.

Out of stock

Description

The Pixhawk 6X Flight Controller Module represents a significant leap in flight control architecture, built around a fail-operational design philosophy. Its core processing is handled by the STM32H753 FMU, providing ample computational headroom for complex autonomous navigation and data fusion algorithms. The dedicated STM32F103 IO processor manages real-time peripheral communication, ensuring low-latency control loop execution.

Electrical design emphasizes robustness, with isolated power domains for each sensor cluster to prevent single-point failures. The controller supports a wide input voltage range and includes current-limited outputs on all telemetry and servo ports. Its construction utilizes specialized damping materials tuned to suppress a broad spectrum of motor and frame vibrations, which is critical for precise attitude estimation in demanding multirotor and fixed-wing applications.

Key Features

  • Triple-Redundant Sensor Fusion: Three independent ICM-45686 IMUs and two barometer sensors (ICP20100 & BMP388) provide continuous data validation and fault tolerance.
  • High-Speed Processing Core: STM32H753 32-bit Cortex-M7 processor at 480 MHz enables complex filter algorithms and future firmware feature expansion.
  • Modular Connector System: Standardized 100-pin and 50-pin Pixhawk Autopilot Bus connectors allow clean integration with carrier boards, power modules, and accessory peripherals.
  • Advanced Vibration Isolation: Engineered damping material with a high resonant frequency effectively attenuates high-frequency noise from brushless motors.
  • Isolated Power Architecture: Separate power control and data buses for each IMU domain prevent noise cross-talk and enhance system reliability.
  • High-Bandwidth Communication: Onboard Ethernet interface supports direct connection to mission computers for high-rate data logging and advanced payload control.
  • Wide Voltage Compatibility: Accepts 4.75-5.25V logic power and can handle servo rail inputs up to 36V for flexible power system integration.

Applications

  • Advanced research and development UAV platforms requiring high-redundancy and fault-tolerant flight control.
  • Heavy-lift cinematography and industrial inspection drones where system reliability is paramount.
  • Fixed-wing and VTOL (Vertical Take-Off and Landing) aircraft utilizing complex autonomous mission profiles.
  • UAVs integrating high-bandwidth companion computers for real-time data processing and AI-based navigation.
  • Robotic platforms and rovers that leverage the Pixhawk ecosystem for robust navigation and control.

Technical Specifications

FMU ProcessorSTM32H753 Cortex-M7, 480 MHz, 2MB Flash, 1MB RAM
IO ProcessorSTM32F103 Cortex-M3, 72 MHz, 64KB SRAM
IMU (Primary)3x ICM-45686 with BalancedGyroâ„¢ Technology
BarometerICP20100 & BMP388
MagnetometerBMM150
Additional IMUsBMI088 / ICM-20649, ICM-42688-P, ICM-42670-P
Input Voltage4.75 - 5.25 V
Servo Rail Voltage0 - 36 V
Output Current Limit (Telem1)1.5 A
Output Current Limit (Other Ports)1.5 A Combined
Connectors100-pin & 50-pin Pixhawk Autopilot Bus
FirmwarePX4, ArduPilot

Frequently Asked Questions

Does the Pixhawk 6X Module include a GPS or compass?

No, this is the Flight Controller Module Only. It contains an integrated BMM150 magnetometer, but it does not include an external GPS module. You will need to connect a compatible GPS/Compass unit, such as the Holybro GPS Module, via one of its telemetry or I2C ports for full navigation capability.

What is the benefit of the triple-redundant IMU design?

The triple-redundant ICM-45686 IMUs provide fault-tolerant attitude estimation. The flight stack continuously compares data from all three sensors. If one IMU provides erroneous data due to a fault or excessive vibration, the system can isolate and disregard it, maintaining stable flight using the remaining healthy sensors, which is critical for safety in commercial and industrial applications.

What carrier boards or power modules are compatible with the Pixhawk 6X?

The Pixhawk 6X uses standard Pixhawk Autopilot Bus connectors (100-pin and 50-pin). It is designed to be compatible with Holybro's family of carrier boards (like the Carrier Board V2.4) and power modules that support this bus. Always verify connector pinout compatibility with third-party carrier boards before integration.

Can I power servos directly from the Pixhawk 6X module?

The Pixhawk 6X module itself does not have a high-current BEC for servos. The servo rail voltage (0-36V) is a pass-through. You must provide a separate, adequately rated BEC or power source on the carrier board to supply power to the servo rail. The module's onboard current limiters are for signal-level protection on telemetry ports.

Package Includes

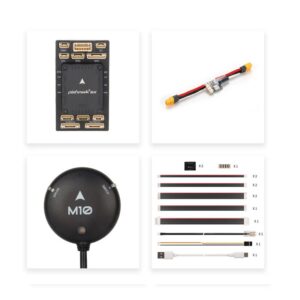
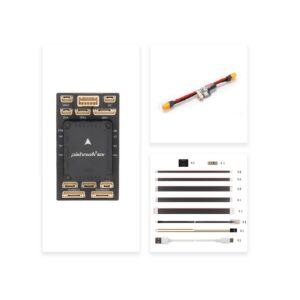
  • 1 x Pixhawk 6X Flight Controller Module

Additional Information

Weight 0.302 kg
Dimensions 15 × 10 × 7 cm