SKU: DRFC-1976
📋 GST Invoice Available

Holybro Pixhawk 6X Mini Set with M10 GPS

₹42,726.00 (Inclusive of all taxes)
Out of Stock

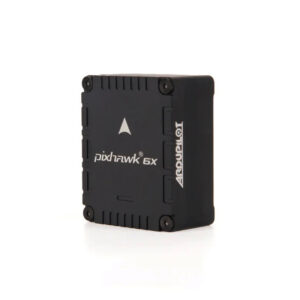
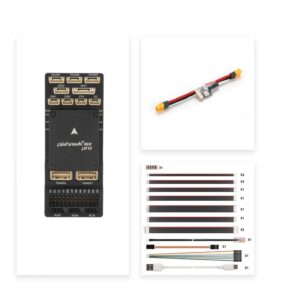
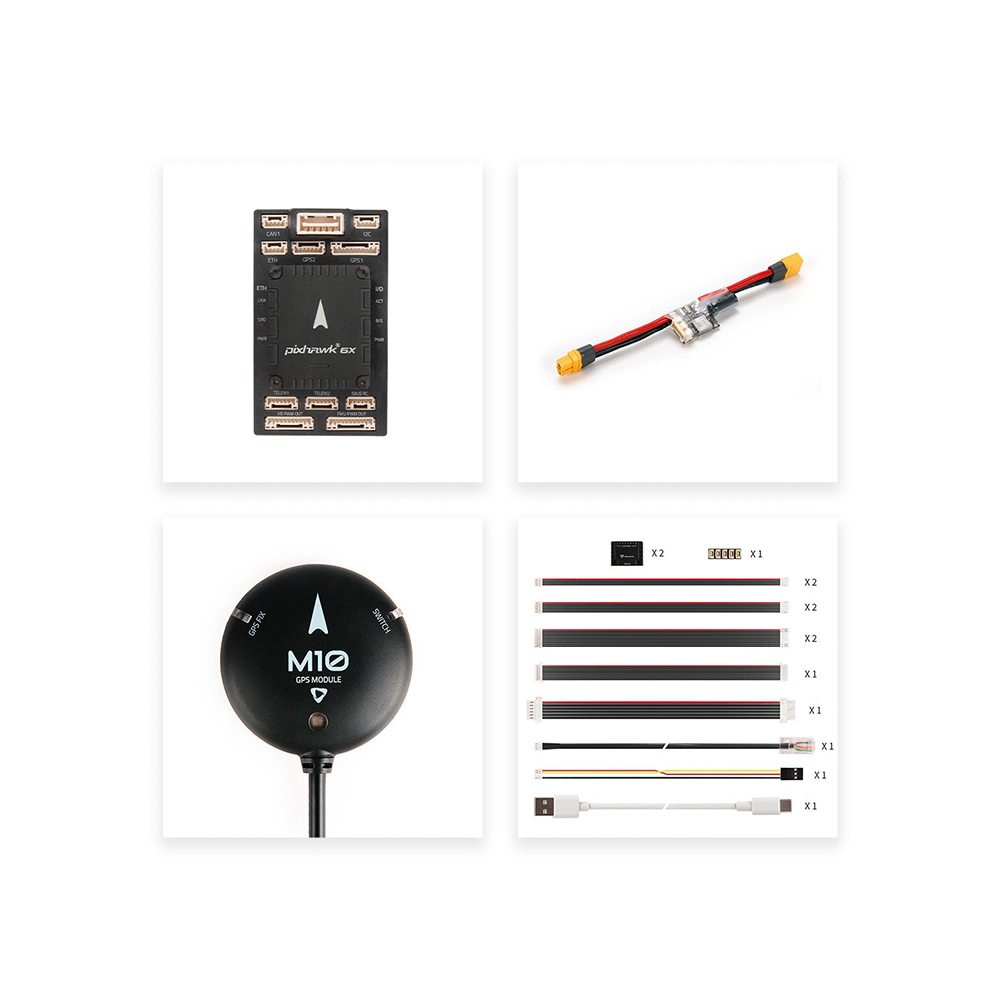
The Holybro Pixhawk 6X Mini Set is a high-reliability modular autopilot system featuring triple-redundant ICM-45686 IMUs with BalancedGyroâ„¢ technology, dual barometers, and a powerful STM32H753 processor. Designed for professional UAV applications, it includes the flight controller module, Mini Base, dual PM02D HV Power Modules, and an M10 GPS module for precise navigation.

Features

  • Triple-redundant ICM-45686 IMU sensors with BalancedGyroâ„¢ technology for maximum flight reliability.
  • High-performance STM32H753 Cortex-M7 FMU processor running at 480 MHz with 2MB flash.
  • Modular design with Pixhawk® Autopilot Bus connectors separating FMU, IO, and base systems.
  • Includes dual PM02D HV Power Modules and an M10 GPS module for complete system integration.
  • Advanced vibration isolation and isolated sensor power domains for optimal performance in harsh environments.

Out of stock

Description

The Pixhawk 6X Mini represents a significant advancement in flight controller architecture, built around a modular and redundant design philosophy. Its core computational unit is the STM32H753 Flight Management Unit (FMU), which provides substantial processing headroom for complex autonomous flight algorithms and sensor fusion. The system employs three independent ICM-45686 inertial measurement units, ensuring continuous operation even if one sensor fails, a critical feature for mission-critical UAVs.

Electrical design emphasizes robustness and flexibility. The system accepts a wide servo rail input voltage (0-36V) and incorporates isolated power domains for each sensor cluster to prevent noise cross-talk. The included PM02D HV Power Modules offer high-current capability and accurate battery monitoring. The modular connection via 100-pin and 50-pin Pixhawk Autopilot Bus connectors allows for easy integration of companion computers and custom payloads, making this set ideal for advanced research, commercial inspection, and heavy-lift drone platforms.

Key Features

  • Triple Redundant IMU Design: Three independent ICM-45686 sensors provide fault-tolerant attitude estimation using BalancedGyroâ„¢ technology.
  • High-Speed Processing Core: STM32H753 Arm® Cortex®-M7 processor at 480 MHz handles complex navigation and control loops with ease.
  • Dual Redundant Barometers: ICP20100 and BMP388 sensors deliver precise altitude hold and vertical velocity data.
  • Modular Expansion System: Standardized Pixhawk Autopilot Bus connectors enable seamless integration with peripherals and mission computers.
  • Advanced Vibration Damping: Proprietary isolation material with a tuned resonance frequency minimizes high-frequency motor and propeller vibrations.
  • Robust Power Management: Supports high-voltage servo rails and includes dual high-power PM02D modules for reliable electrical distribution.
  • Integrated High-Precision GPS: Bundle includes an M10 GPS module for superior global positioning and satellite lock performance.

Applications

  • Advanced autonomous UAV platforms for aerial mapping, surveying, and photogrammetry.
  • Heavy-lift cargo and delivery drones requiring fault-tolerant flight control systems.
  • Research and development platforms for testing new autonomy algorithms and sensor suites.
  • Industrial inspection drones operating in GPS-denied or magnetically challenging environments.
  • Long-endurance fixed-wing and VTOL (Vertical Take-Off and Landing) aircraft.

Technical Specifications

FMU ProcessorSTM32H753 (32-bit Arm® Cortex®-M7, 480 MHz, 2MB Flash, 1MB RAM)
IO ProcessorSTM32F103 (32-bit Arm® Cortex®-M3, 72 MHz, 64KB SRAM)
Primary Accel/Gyro3x ICM-45686 (with BalancedGyroâ„¢ Technology)
BarometerICP20100 & BMP388
MagnetometerBMM150
Max Input Voltage6V (FMU), 0-36V (Servo Rail)
USB Input Voltage4.75 - 5.25V
Output Current Limit (Telem1)1.5A
Output Current Limit (Other Ports)1.5A Combined
Supported FirmwarePX4, ArduPilot

Frequently Asked Questions

What firmware is compatible with the Pixhawk 6X Mini?

The Pixhawk 6X Mini is fully compatible with the latest versions of both PX4 and ArduPilot open-source flight stacks. The high-performance STM32H753 processor and ample memory support advanced features like EKF2, mission planning, and real-time telemetry. Setup is performed via QGroundControl or Mission Planner.

What is the purpose of the triple-redundant IMU sensors?

The triple-redundant ICM-45686 IMUs provide fault-tolerant attitude and heading reference. If one sensor fails or provides erroneous data, the flight controller's EKF (Extended Kalman Filter) can vote or isolate the faulty sensor, maintaining stable flight. This is critical for professional and commercial UAV operations where system reliability is paramount.

What are the power input requirements and what do the included PM02D modules do?

The FMU accepts up to 6V, typically from a regulated 5V BEC. The servo rail can handle 0-36V, directly from a LiPo battery. The two included PM02D HV Power Modules are high-current power distributors and battery monitors. They step down battery voltage to power the system and provide precise current/voltage sensing data to the flight controller.

Can I connect a companion computer (like a Raspberry Pi) to this flight controller?

Yes, the modular design with Pixhawk Autopilot Bus connectors (100-pin and 50-pin) is specifically intended for high-speed integration with mission computers. An Ethernet interface is available on the base for low-latency, high-bandwidth communication, making it ideal for running companion computer software like MAVSDK or ROS.

Package Includes

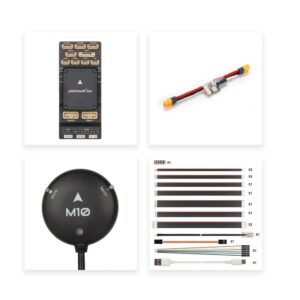
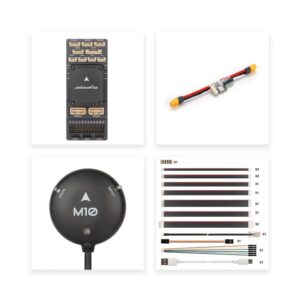
  • 1 x Pixhawk 6X Flight Controller Module
  • 1 x Pixhawk Mini Base
  • 2 x PM02D HV Power Module
  • 1 x M10 GPS Module
  • 1 x Cable Set

Additional Information

Weight 0.302 kg
Dimensions 10 × 15 × 7 cm