SKU: DRFC-1974
📋 GST Invoice Available

Holybro Pixhawk 6X Standard Set with M10 GPS

₹37,369.00 (Inclusive of all taxes)
Out of Stock

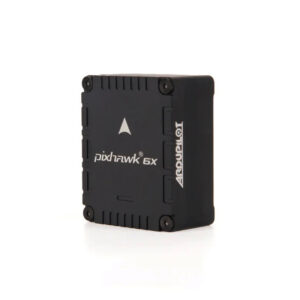
The Holybro Pixhawk 6X Standard Set is a high-reliability, modular flight controller system designed for professional UAV and robotic applications. It features triple-redundant IMUs, a powerful STM32H753 processor, and includes an M10 GPS module for precise navigation, fully compatible with ArduPilot and PX4 firmware.

Features

  • Triple-redundant ICM-45686 IMU sensors with BalancedGyroâ„¢ technology for maximum reliability.
  • High-performance STM32H753 Cortex-M7 FMU processor (480 MHz, 2MB Flash, 1MB RAM).
  • Modular design with separate FMU, IO, and base board connected via Pixhawk Autopilot Bus.
  • Includes M10 GPS module and two PM02D HV Power Modules for robust power management.
  • Advanced vibration isolation and isolated sensor domains for optimal flight stability.

Out of stock

Description

The Pixhawk 6X represents a significant advancement in flight controller architecture, built around a modular concept that physically separates the Flight Management Unit (FMU), Input/Output (IO) processor, and base carrier board. This design enhances reliability by isolating critical sensor domains and power rails. The system is powered by a flagship STM32H753 microcontroller, providing ample processing headroom for complex autonomous missions and high-rate control loops.

Engineered for demanding environments, the controller incorporates three independent ICM-45686 inertial measurement units, offering sensor-level triple redundancy. Combined with dual barometers (ICP20100 & BMP388), this setup ensures continued operation even in the event of a single sensor failure. The included M10 GPS module delivers high-precision positioning, making the system ideal for survey, mapping, and inspection drones requiring centimeter-level accuracy.

Key Features

  • Triple Redundant IMUs: Three ICM-45686 sensors with BalancedGyroâ„¢ technology provide unmatched sensor reliability and fault tolerance.
  • High-Speed Processing Core: STM32H753 Cortex-M7 processor at 480 MHz enables complex navigation algorithms and high-bandwidth filtering.
  • Modular Pixhawk Bus: Utilizes 100-pin and 50-pin Pixhawk Autopilot Bus connectors for flexible system expansion and easy module replacement.
  • Isolated Power & Sensor Domains: Critical sensor buses and power supplies are electrically isolated to prevent noise interference and enhance system integrity.
  • Advanced Vibration Damping: Proprietary damping material with a tuned resonance frequency effectively isolates the IMU stack from frame vibrations.
  • Comprehensive I/O Suite: Features multiple UART, CAN, I2C, and SPI ports, plus an Ethernet interface for high-speed companion computer integration.
  • Wide Input Voltage Range: Supports servo rail input from 0-36V, compatible with a broad spectrum of LiPo batteries and power systems.

Applications

  • Professional aerial surveying and photogrammetry mapping drones requiring high-precision GPS.
  • Heavy-lift cargo and delivery UAVs where system redundancy and reliability are critical.
  • Advanced research and development platforms for autonomous navigation and AI integration.
  • Industrial inspection drones for infrastructure, agriculture, and energy sectors.
  • Robotic ground vehicles and rovers utilizing the Pixhawk ecosystem for navigation.

Technical Specifications

FMU ProcessorSTM32H753 (32-bit Arm Cortex-M7, 480 MHz, 2MB Flash, 1MB RAM)
IO ProcessorSTM32F103 (32-bit Arm Cortex-M3, 72 MHz, 64KB SRAM)
Accel/Gyro (Primary)3x ICM-45686 with BalancedGyroâ„¢
BarometerICP20100 & BMP388
MagnetometerBMM150
Max Input Voltage (Logic)6V
Servo Rail Input Voltage0-36V
USB Input Voltage4.75-5.25V
Output Current Limit (Telem1)1.5A
Output Current Limit (Other Ports)1.5A combined
GPS ModuleM10 GPS (Included)
Firmware CompatibilityArduPilot, PX4

Frequently Asked Questions

What is the primary advantage of the triple-redundant IMU setup in the Pixhawk 6X?

The triple-redundant ICM-45686 IMUs provide sensor-level fault tolerance. The flight controller's algorithm can vote between the three sensors, automatically isolating and discarding faulty readings. This dramatically increases system reliability in harsh vibration environments or in the event of a physical sensor failure, which is critical for commercial and industrial drone operations.

What is the maximum voltage I can supply to the servo rail, and what power modules are included?

The servo rail on the Pixhawk 6X base board accepts an input voltage range of 0-36V, making it compatible with 2S to 8S LiPo battery systems (approximately 8.4V to 33.6V). The Standard Set includes two PM02D HV Power Modules, which are required to step down this high voltage to the 5V logic level needed by the flight controller and peripherals.

Is the Pixhawk 6X compatible with both ArduPilot and PX4 firmware?

Yes, the Holybro Pixhawk 6X is fully supported by both the ArduPilot and PX4 open-source autopilot firmware ecosystems. You can flash either firmware via the USB port. Its modular design and standardized Pixhawk Autopilot Bus ensure broad peripheral compatibility, including the included M10 GPS, which is a standard sensor for both platforms.

What is the purpose of the modular design with separate FMU and base boards?

The modular design enhances serviceability, upgradeability, and system resilience. The core FMU module containing the processors and IMUs can be easily replaced or upgraded without changing the entire carrier board and wiring harness. It also allows for physical separation, enabling better vibration isolation for the IMUs and providing flexibility for custom integration into different vehicle frames or robotic platforms.

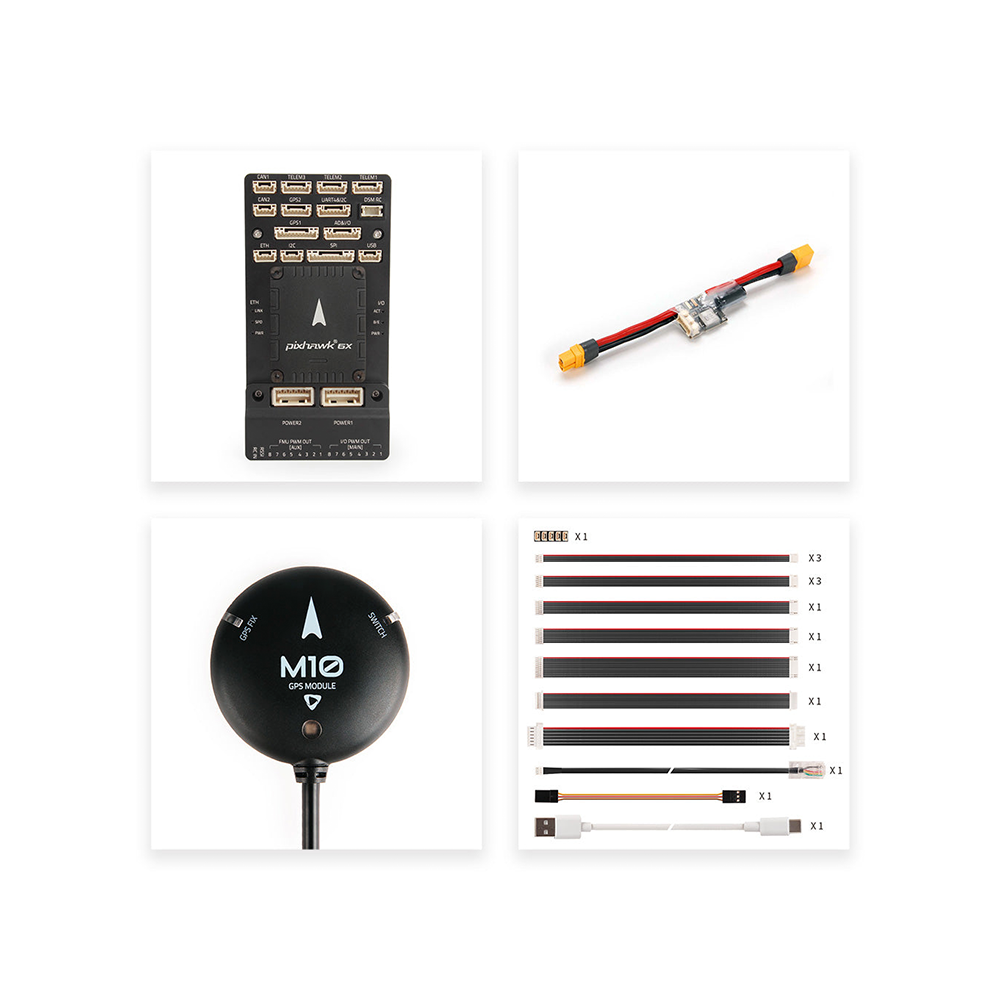
Package Includes

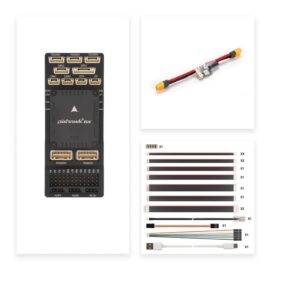
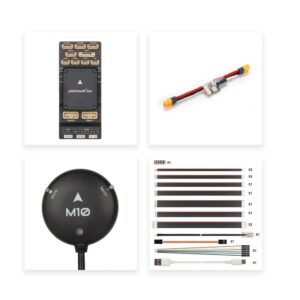
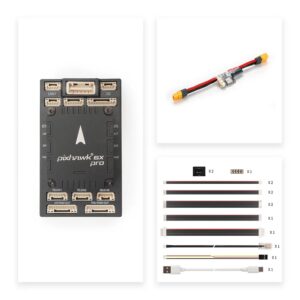
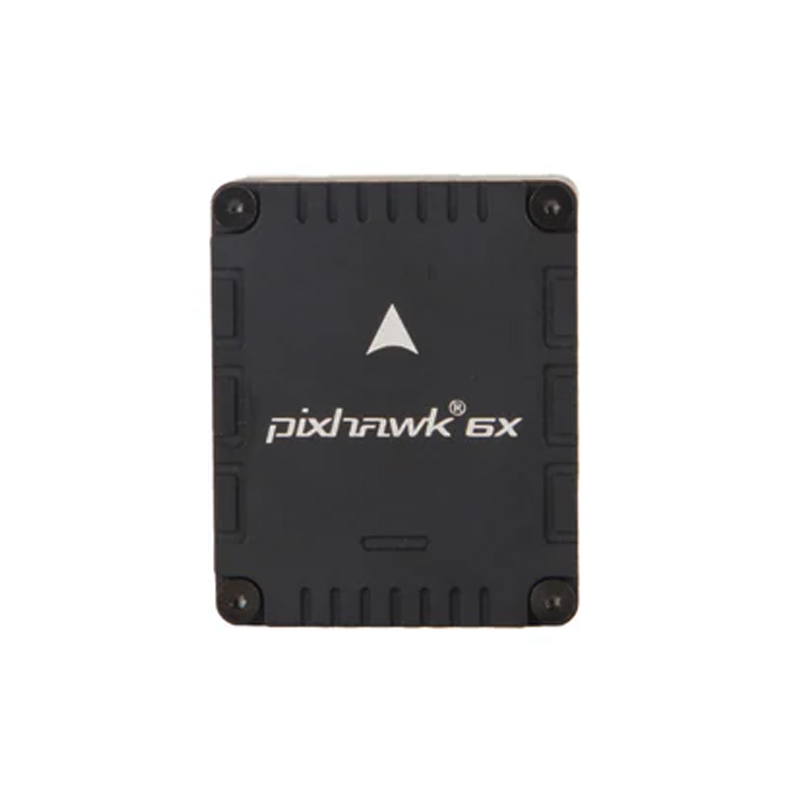
  • 1x Pixhawk 6X Flight Controller Module
  • 1x Pixhawk Standard Base Carrier Board
  • 2x PM02D HV Power Module
  • 1x M10 GPS Module
  • 1x Cable Set

Additional Information

Weight 0.302 kg
Dimensions 15 × 10 × 7 cm