SKU: DRFC-1947
📋 GST Invoice Available

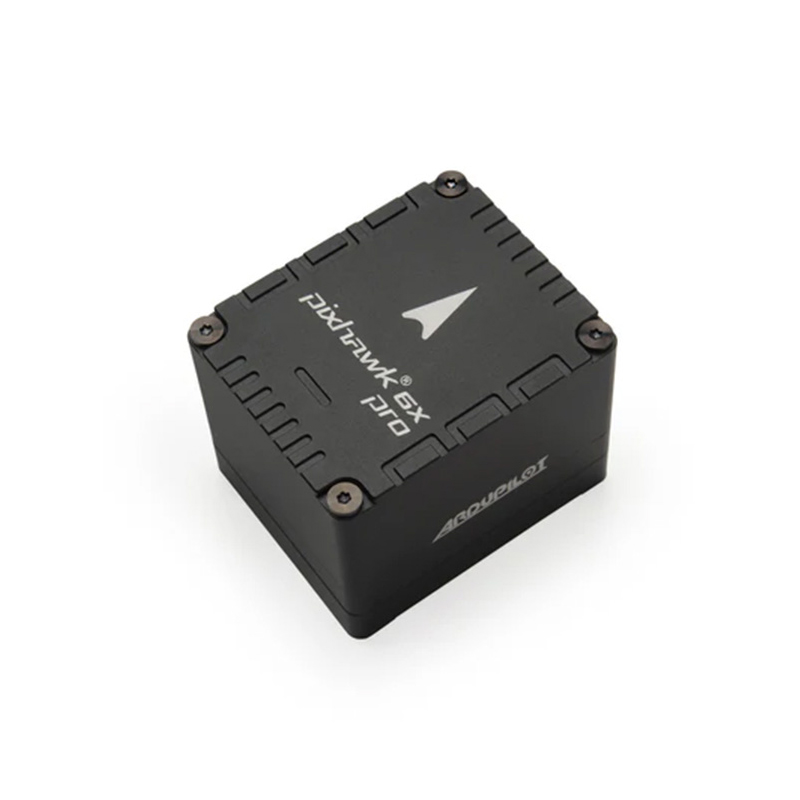
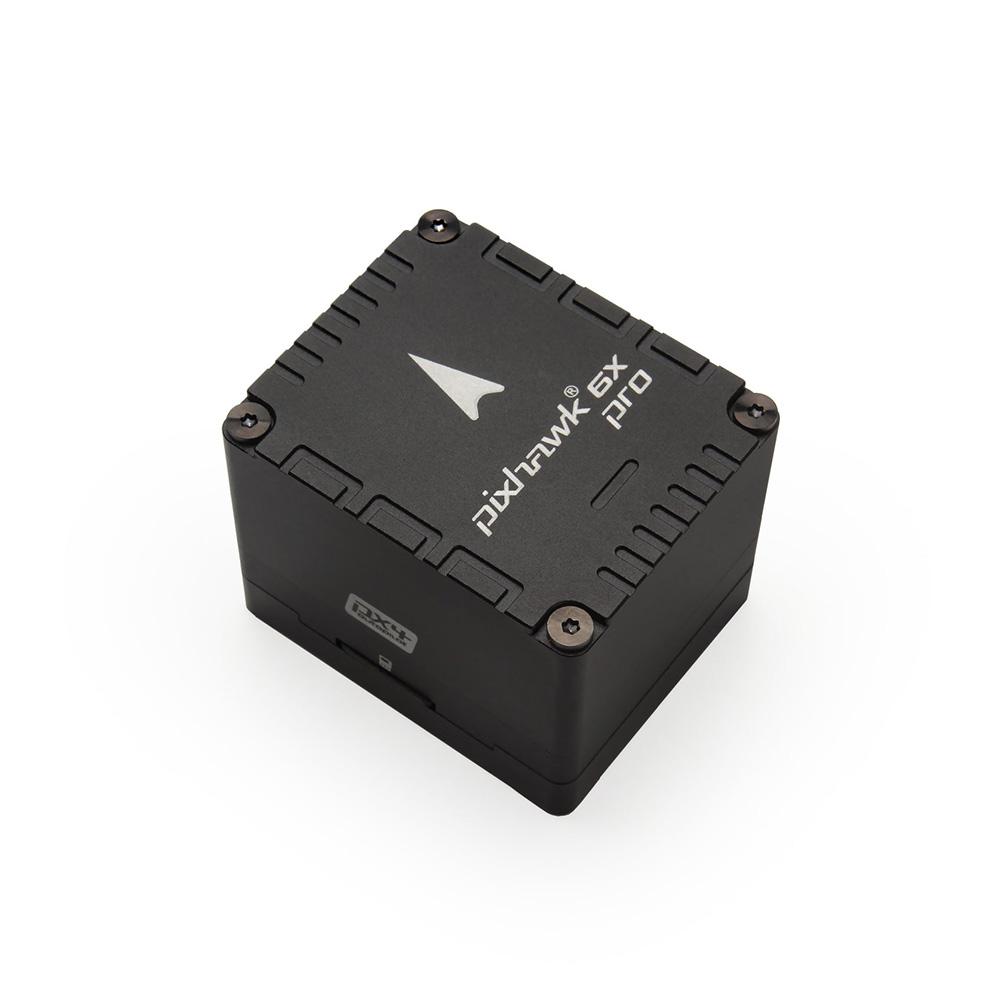
Holybro Pixhawk 6X Pro Flight Controller Module

₹61,499.00 (Inclusive of all taxes)
Out of Stock

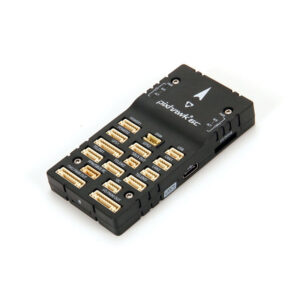
The Holybro Pixhawk 6X Pro is a high-performance, modular flight controller designed for professional UAV and drone applications, featuring a powerful STM32H753 processor, triple-redundant industrial-grade IMUs, and vibration-isolated sensor mounting for reliable operation under demanding conditions.

Features

  • High-Performance FMU: STM32H753 Arm Cortex-M7 processor running at 480 MHz with 2MB flash and 1MB RAM.
  • Triple-Redundant IMUs: Includes ADIS16470 (±40g), IIM-42652 (±16g), and ICM-45686 (±32g) sensors for exceptional reliability and fault tolerance.
  • Advanced Vibration Isolation: Custom silicone-based damping material protects critical IMUs from vibration and shock.
  • Modular System Design: Separates FMU, IMU, and base systems with independent power control for flexibility and robustness.
  • Professional Interfaces: Features Ethernet connectivity for high-speed mission computer integration and supports ArduPilot and PX4 firmware.

Out of stock

Description

The Pixhawk 6X Pro represents a significant evolution in flight control hardware, engineered for demanding commercial, industrial, and advanced research UAV platforms. Its core architecture leverages a powerful STM32H753 main processor paired with a dedicated STM32F103 I/O processor, ensuring high-speed data processing and reliable real-time control loop execution. The separation of the Flight Management Unit (FMU), Inertial Measurement Unit (IMU), and baseboard into distinct modules enhances system resilience and simplifies maintenance.

Central to its design is the implementation of triple-redundant inertial sensors, including the high-dynamic-range ADIS16470 industrial IMU. This sensor suite, combined with double-redundant barometers, provides unparalleled state estimation accuracy and fault tolerance in environments with significant vibration or aggressive maneuvering. The dedicated vibration isolation system for the primary IMUs utilizes a custom-formulated silicone material to effectively dampen high-frequency mechanical noise, preserving sensor fidelity.

Integration capabilities are extensive, featuring an onboard Ethernet port for connecting companion computers, multiple serial ports for peripherals, and a comprehensive set of PWM, SBUS, and CAN bus interfaces. This makes the 6X Pro suitable for complex autonomous missions, payload integration, and swarming applications where reliable, high-bandwidth communication is critical.

Key Features

  • Industrial-Grade Sensor Fusion: Combines three distinct IMUs (ADIS16470, IIM-42652, ICM-45686) with advanced Kalman filtering for robust attitude and position estimation.
  • Vibration-Damped IMU Mounting: Key inertial sensors are mounted on a custom silicone isolation system to minimize high-frequency vibration corruption of sensor data.
  • Dual-Processor Architecture: High-speed STM32H753 FMU handles navigation algorithms, while the STM32F103 IO processor manages all peripheral communications.
  • Modular & Serviceable Design: The IMU board, FMU, and carrier board are separate units, allowing for easy replacement and upgrade of individual components.
  • Extended Connectivity: Includes 10x PWM/SBUS outputs, 5x serial ports, 2x CAN bus ports, and a dedicated Ethernet interface for mission computer links.
  • Wide Power Input Range: Supports 2-6S LiPo input voltages (7-26V) with robust power conditioning and filtering for stable operation.
  • Temperature-Controlled IMU: The primary IMU board includes thermal management to maintain consistent sensor performance across a wide operational temperature range.

Applications

  • High-payload commercial drone platforms for surveying, mapping, and inspection.
  • Advanced research and development UAVs requiring robust sensor redundancy and data logging.
  • Industrial-grade autonomous vehicles for agriculture, logistics, and environmental monitoring.
  • Heavy-lift cinematography drones where stable flight in turbulent conditions is critical.
  • Swarm robotics and coordinated multi-agent systems leveraging the Ethernet interface.

Technical Specifications

Item TypeFlight Controller Module
Main FMU ProcessorSTM32H753, 32-bit Arm Cortex-M7, 480MHz, 2MB Flash, 1MB RAM
IO ProcessorSTM32F103, 32-bit Arm Cortex-M3, 72MHz, 64KB SRAM
Primary IMU (Isolated)ADIS16470, ±40g Accelerometer, Industrial Grade
Secondary IMU (Isolated)IIM-42652, ±16g Accelerometer
Tertiary IMU (Hard-Mounted)ICM-45686 with BalancedGyro Technology, ±32g Accelerometer
BarometersDual Redundant
Firmware CompatibilityArduPilot, PX4
Power Input2-6S LiPo (7-26V DC)
InterfacesEthernet, 5x UART, 2x CAN, I2C, SPI, 10x PWM/SBUS, USB-C
Shipping Weight0.12 kg
Shipping Dimensions15 × 11 × 6 cm

Frequently Asked Questions

What is the primary advantage of the triple-redundant IMU system on the Pixhawk 6X Pro?

The triple-redundant IMU system, featuring the ADIS16470, IIM-42652, and ICM-45686 sensors, provides exceptional fault tolerance and data integrity. The flight stack's EKF2 estimator can automatically detect and isolate a failed sensor, allowing the vehicle to continue safe operation using the remaining healthy IMUs. This is critical for professional applications where mission success and platform safety are paramount.

What firmware is compatible with the Holybro Pixhawk 6X Pro?

The Pixhawk 6X Pro is fully compatible with the latest versions of both ArduPilot (Copter, Plane, Rover) and PX4 Pro flight stacks. Its modular design and standard Pixhawk form factor ensure it is supported as a high-end target within these open-source ecosystems. Users can flash firmware via the USB-C port or through a ground station software like Mission Planner or QGroundControl.

What is the purpose of the vibration isolation on the IMU board?

The custom silicone-based vibration isolation system mechanically decouples the primary IMUs (ADIS16470 and IIM-42652) from high-frequency vibrations generated by motors and propellers. This damping is essential because high-frequency vibration can cause noise and aliasing in accelerometer and gyroscope readings, degrading the accuracy of the state estimation filter and leading to poor flight performance or instability.

Can the Pixhawk 6X Pro interface with a companion computer?

Yes, the Pixhawk 6X Pro is designed for seamless companion computer integration. It provides a dedicated Ethernet port for high-bandwidth, low-latency communication, as well as multiple serial (UART) ports. This allows the flight controller to offload complex computational tasks like vision-based navigation, AI object detection, or advanced path planning to an onboard Raspberry Pi or similar mission computer while maintaining tight control loop timing.

Package Includes

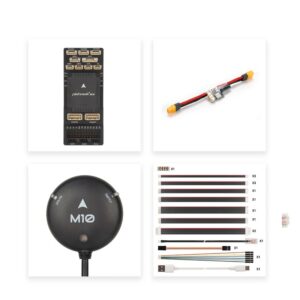
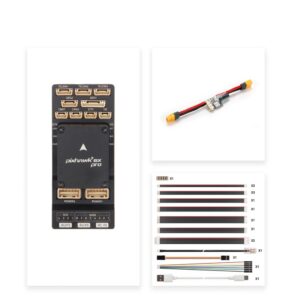
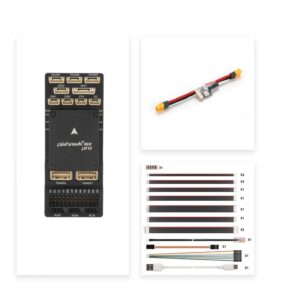
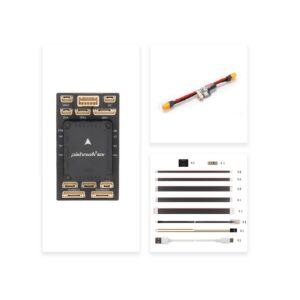
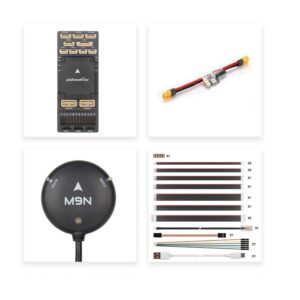
  • 1 x Pixhawk 6X Pro Flight Controller Module

Additional Information

Weight 0.12 kg
Dimensions 15 × 11 × 6 cm