SKU: SENS-4268
📋 GST Invoice Available

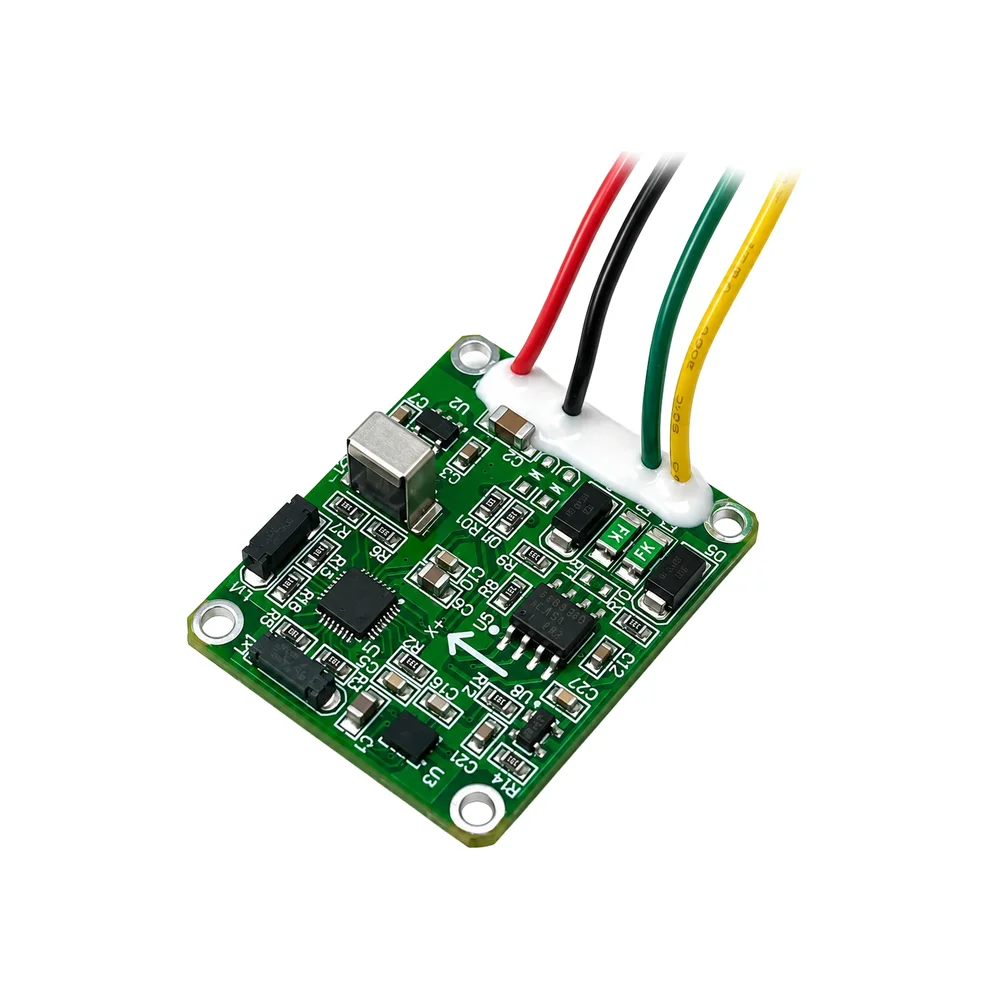
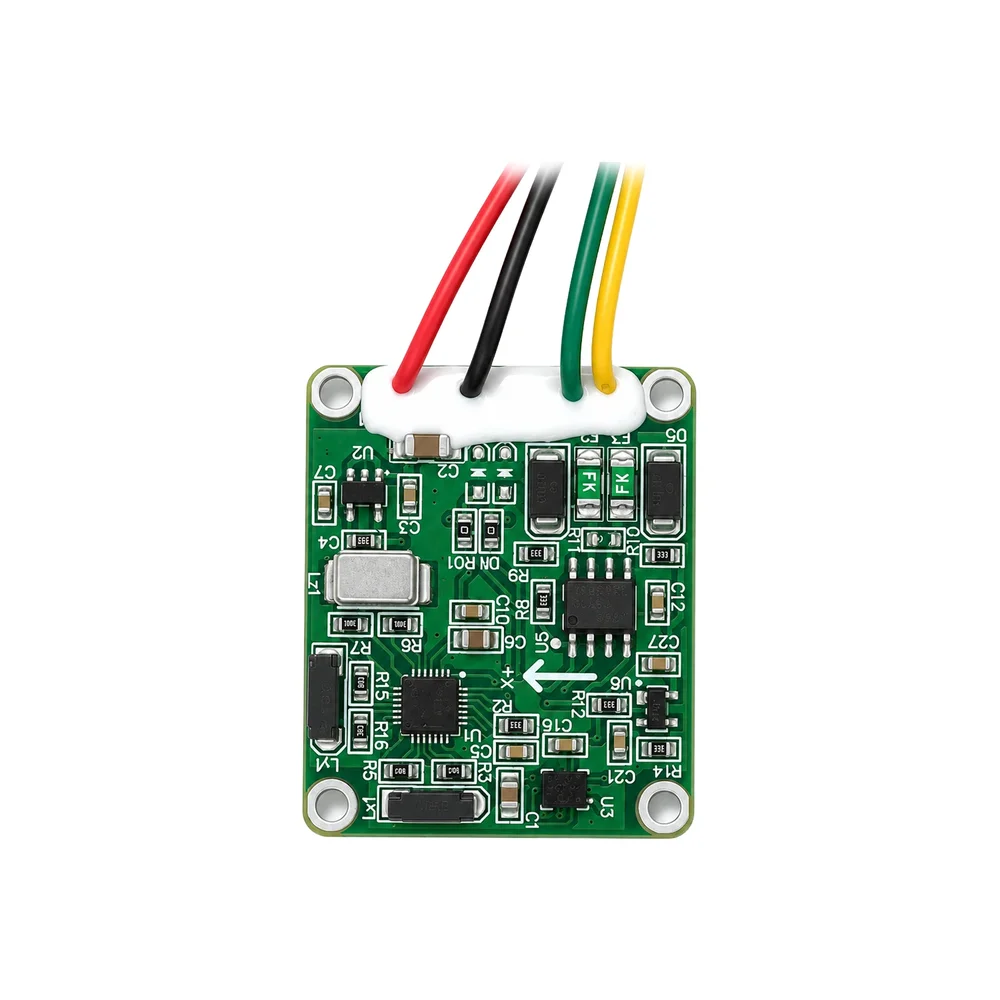
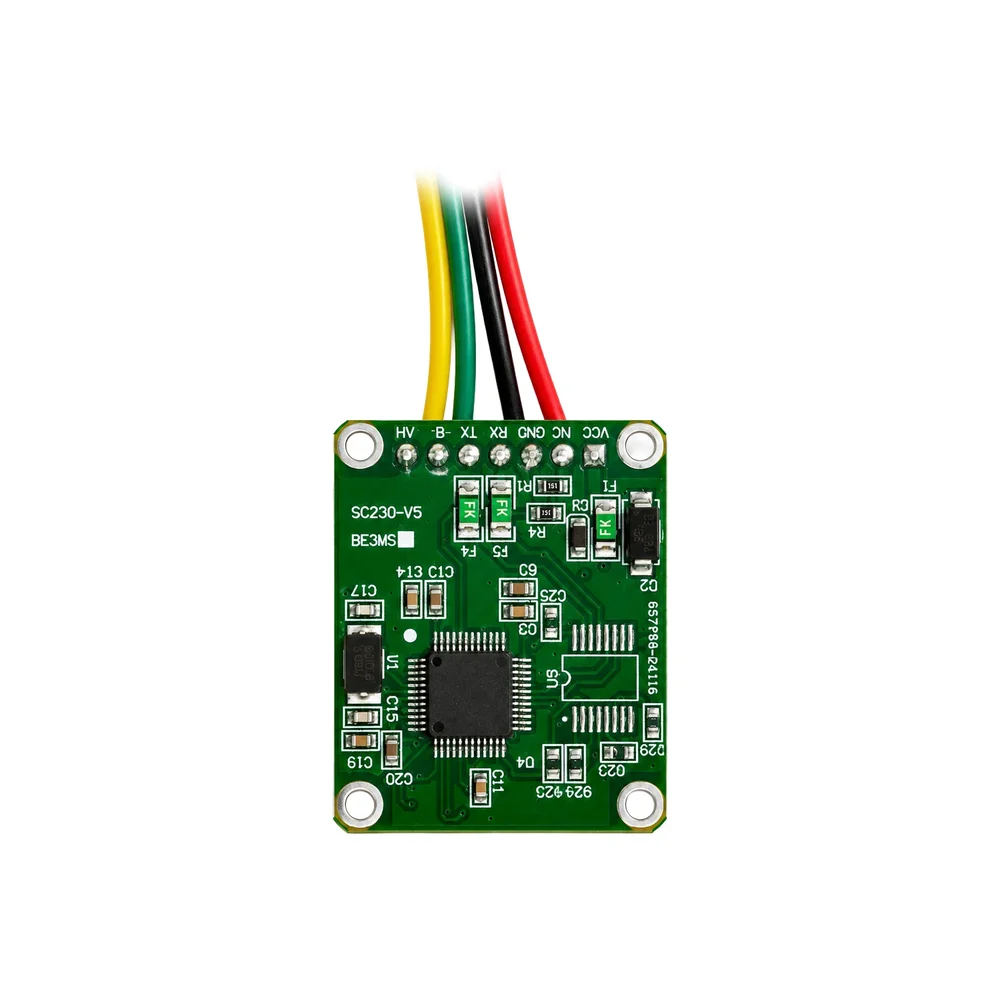
BWSENSING SEC340 3D Electronic Compass Sensor - RS485/RS232/TTL Interface

₹17,329.00 (Inclusive of all taxes)
Out of Stock

The BWSENSING SEC340 is a high-precision MEMS-based 3D electronic compass sensor with integrated tilt compensation, delivering 1° RMS heading accuracy. It features flexible RS485, RS232, and TTL serial interfaces for direct integration into robotics, marine navigation, and industrial automation systems.

Features

  • High-precision MEMS magnetic sensor with 1° RMS heading accuracy and 0.1° resolution.
  • Integrated tilt compensation for pitch and roll up to ±40°, ensuring stable readings in dynamic orientations.
  • Multi-interface support includes RS485, RS232, and TTL serial communication for versatile system connectivity.
  • Features hard and soft magnetic calibration for reliable operation in magnetically disturbed environments.
  • Compact, lightweight industrial design suitable for embedded navigation and automation applications.

Out of stock

Description

The BWSENSING SEC340 utilizes advanced MEMS magnetic sensing technology to provide accurate three-axis geomagnetic field measurements. Its integrated algorithm performs real-time tilt compensation using onboard accelerometers, correcting for pitch and roll angles up to ±40°, which is critical for maintaining heading accuracy on moving platforms.

This digital compass sensor outputs calibrated heading, pitch, and roll data through a configurable serial interface (RS485, RS232, or TTL). It includes comprehensive support for hard and soft magnetic interference calibration, making it robust for use in environments with ferrous materials or electromagnetic noise. The device is engineered for stability and repeatability, with low power consumption from a single 5V DC supply.

Key Features

  • MEMS-based 3D magnetic field sensor with high stability and low noise.
  • Tilt-compensated heading output with 1° RMS accuracy and 0.1° resolution.
  • Wide tilt compensation range of ±40° for pitch and roll axes.
  • Multi-protocol serial interface: RS485 (Modbus), RS232, and 3.3V/5V TTL UART.
  • Onboard hard magnetic and soft magnetic distortion calibration algorithms.
  • High repeatability of 0.3° and tilt resolution of 0.01°.
  • Ultra-compact form factor designed for space-constrained embedded systems.
  • Industrial-grade construction suitable for robotics, UAVs, and marine navigation.

Applications

  • Autonomous robot and UAV (drone) navigation and heading control.
  • Marine compassing and attitude reference for small vessels and buoys.
  • Industrial automation for positioning and orientation of robotic arms and AGVs.
  • Attitude and heading reference systems (AHRS) for motion tracking platforms.
  • Surveying equipment and antenna pointing systems requiring precise directional data.

Technical Specifications

Product Type3D Electronic Compass Sensor
Sensor TechnologyMEMS Magnetic Sensing
Supply Voltage5V DC
Heading Accuracy1° RMS
Heading Resolution0.1°
Heading Repeatability0.3°
Tilt (Pitch/Roll) Range±40°
Tilt Resolution0.01°
Pitch Accuracy0.1°
Roll Accuracy0.1°
Output InterfaceRS485 / RS232 / TTL
Calibration SupportHard Magnetic, Soft Magnetic

Frequently Asked Questions

What communication interfaces does the SEC340 compass sensor support?

The SEC340 supports three serial communication protocols: RS485 (typically using Modbus RTU), RS232, and TTL-level UART (3.3V/5V logic compatible). This allows flexible integration with PLCs, industrial controllers, microcontrollers like Arduino/STM32, and single-board computers like Raspberry Pi. The interface is selectable via hardware configuration.

How does the tilt compensation work and what is its range?

The sensor uses integrated MEMS accelerometers to measure its pitch and roll orientation relative to gravity. Its internal algorithm uses this tilt data to mathematically correct the raw magnetic field readings, providing an accurate horizontal heading. The compensation is effective for tilt angles up to ±40° in both pitch and roll axes, which is essential for applications on uneven or moving platforms.

Is calibration required, and what types of magnetic interference does it correct?

Yes, for optimal accuracy, calibration is recommended. The SEC340 supports two key calibration types: Hard Magnetic calibration corrects for permanent magnetic offsets caused by nearby magnets or magnetized steel. Soft Magnetic calibration compensates for distortion caused by ferrous materials in the environment that alter the local magnetic field. The sensor stores these calibration parameters internally.

What is the power supply requirement for the SEC340 module?

The module operates from a single 5V DC power supply. Ensure the power source is stable and within the specified voltage tolerance to maintain sensor accuracy and communication integrity. The current consumption is typically low, making it suitable for battery-powered embedded systems.

Package Includes

  • 1 x BWSENSING SEC340 3D Electronic Compass Sensor Module

Additional Information

Weight 0.227 kg
Dimensions 12 × 12 × 6 cm