SKU: IOWC-0417
📋 GST Invoice Available

Arducam Pan Tilt Camera Bundle for Jetson Xavier NX/Nano

₹6,480.00 (Inclusive of all taxes)
Out of Stock

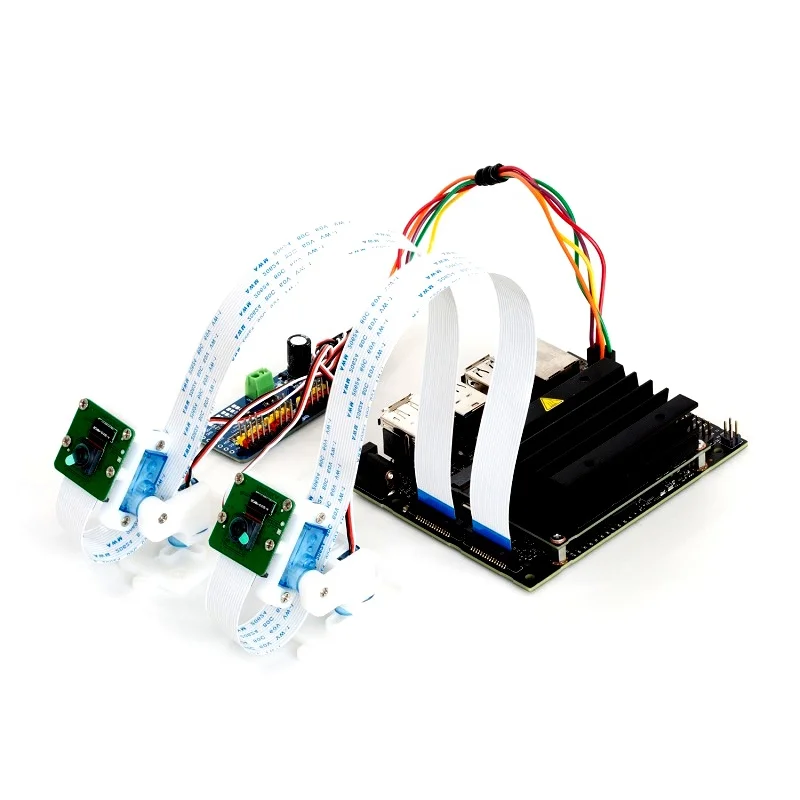
The Arducam Pan Tilt Camera Bundle provides a complete motorized vision platform for Nvidia Jetson Xavier NX and Nano boards, featuring dual 8MP IMX219 sensors and a PCA9685-based I2C servo controller for robotics and surveillance applications.

Features

  • Complete dual-camera pan-tilt kit for Nvidia Jetson Xavier NX and Jetson Nano developer boards.
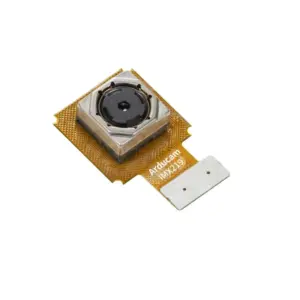
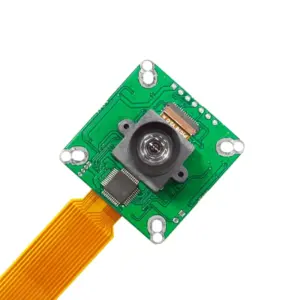
  • Features two 8MP IMX219 sensors with 30cm cables, supporting up to 60fps at 1080p.
  • Powered by four high-torque GH-S37D digital servos for precise, responsive movement.
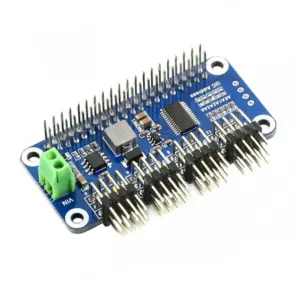
  • Includes PCA9685 PWM servo controller board with I2C interface for controlling up to 16 servos.
  • Easy assembly with epoxy brackets and jumper wires for rapid prototyping and robotics projects.

Out of stock

Description

The Arducam Pan Tilt Camera Bundle is an integrated hardware solution designed to add dynamic, computer vision capabilities to the Nvidia Jetson ecosystem. It combines high-resolution imaging with precise mechanical control, enabling developers to build advanced applications like autonomous tracking, security monitoring, and interactive robotics.

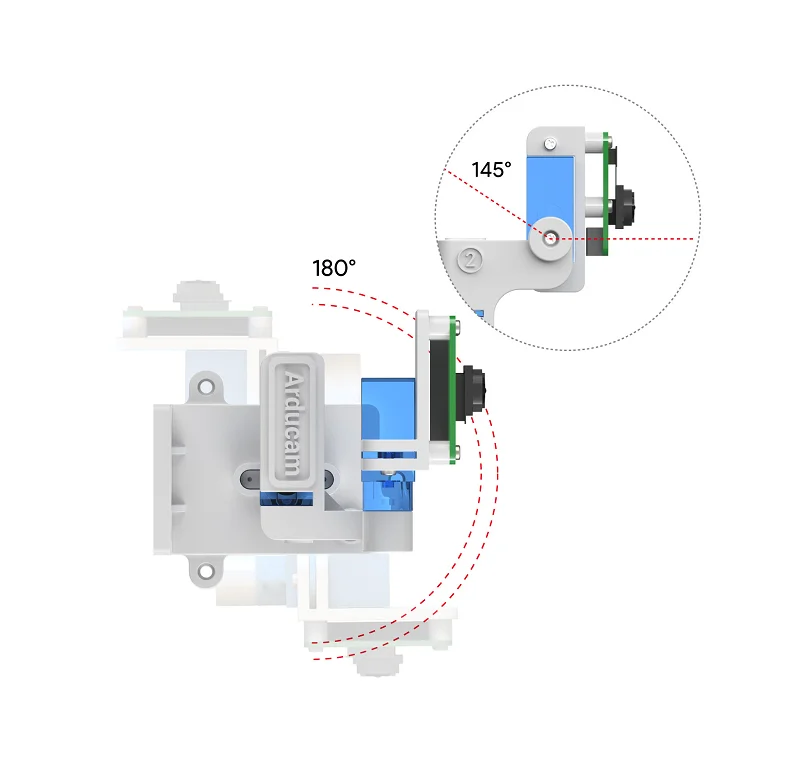
At its core are two 8-megapixel IMX219 camera modules, delivering crisp video streams at various resolutions and frame rates suitable for real-time processing on the Jetson platform. The robust pan-and-tilt mechanism is driven by four GH-S37D digital servos, offering improved torque and speed over standard analog servos for reliable positional control.

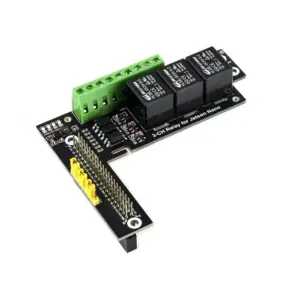
System integration is streamlined through the included PCA9685 PWM controller board, which communicates via I2C and manages servo pulse generation, freeing the host processor from timing-critical tasks. This bundle provides all necessary mechanical components, cables, and control hardware for a seamless setup.

Key Features

  • Dual 8MP IMX219 camera modules with wide 62.2° horizontal field of view for stereo vision or multi-angle applications.
  • High-performance digital servos provide 0.8 kg/cm torque at 4.8V and fast 0.09sec/60° operating speed for responsive movement.
  • PCA9685-based 12-bit PWM servo driver board with I2C interface allows precise control of up to 16 channels from the Jetson host.
  • Integrated ambient light sensor (TSL2581FN) enables automatic exposure adjustment based on environmental lighting conditions.
  • Complete mechanical kit includes pre-machined epoxy brackets, screws, and jumper wires for straightforward assembly.
  • Designed specifically for compatibility with the 40-pin GPIO header on Nvidia Jetson Xavier NX and Jetson Nano carrier boards.

Applications

  • Autonomous robotics and drone vision systems for object tracking and navigation.
  • Smart home and commercial security surveillance with remote pan-tilt control.
  • Educational and DIY projects for learning computer vision and mechatronics on the Jetson platform.
  • Interactive kiosks, telepresence robots, and automated inspection systems.

Technical Specifications

Item TypeCamera Bundle
Camera SensorIMX219 (x2)
Max Resolution8MP (3280 x 2464)
Frame Rate21fps @ 8MP, 60fps @ 1080p
Servo ModelGH-S37D Digital Servo (x4)
Servo Torque0.8 kg/cm @ 4.8V
Servo Speed0.09 sec/60° @ 4.8V
Control BoardPCA9685 PWM Driver
CommunicationI2C
Operating Voltage3.3V / 5V (Control Board); 3.6V–4.8V (Servos)
Host CompatibilityNvidia Jetson Xavier NX, Jetson Nano

Frequently Asked Questions

How do I connect and control the pan-tilt servos from my Jetson board?

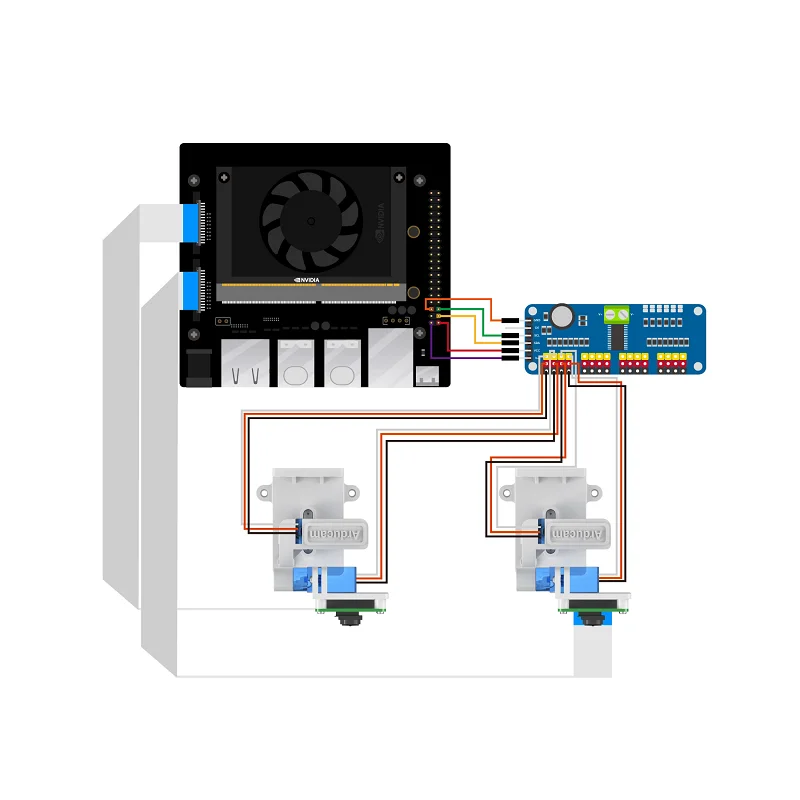
Connect the PCA9685 control board to the Jetson's I2C pins (typically SDA/SCL on the 40-pin header) using the provided jumper wires. Power the board with 3.3V or 5V. The servos plug directly into the PCA9685 outputs. You can then use Python libraries like Adafruit_PCA9685 or Jetson.GPIO to send I2C commands and set PWM pulses for precise servo angle control, enabling smooth pan and tilt movements.

What software libraries or examples are available for the IMX219 cameras?

Use the standard NVIDIA JetPack SDK and its GStreamer/V4L2 pipelines for camera access. Arducam provides specific tutorials for configuring the IMX219 on Jetson. You can capture video streams using nvgstcapture or OpenCV with the GStreamer backend. For advanced control, modify the sensor driver in the /etc/nv_tegra_release configuration files to adjust frame rate, resolution, and exposure settings for your computer vision application.

What is the power requirement for the entire bundle when operational?

The digital servos require 3.6V to 4.8V and can draw up to 350mA each under load, so a robust 5V/2A supply is recommended for all four. The PCA9685 controller board runs on 3.3V or 5V logic from the Jetson. The cameras are powered via the Jetson's CSI connector. Ensure your Jetson power adapter can supply extra current for the servos, or use a separate regulated 5V supply for the servo motor bank to avoid board brownouts.

Package Includes

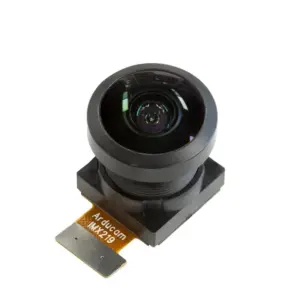
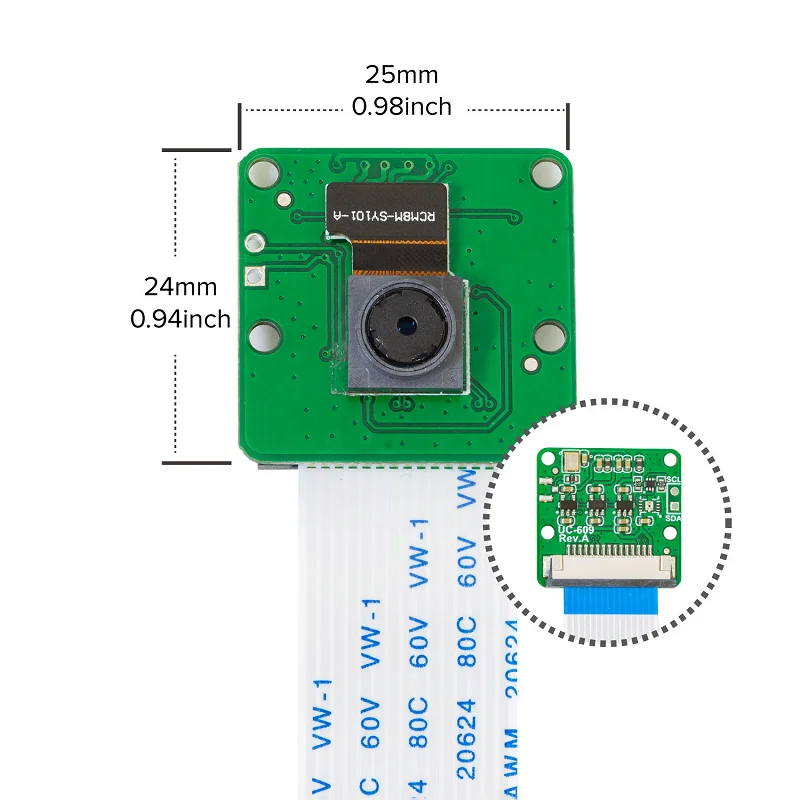
  • 2 x 8MP IMX219 Camera Modules for Jetson (with 30cm cables)
  • 4 x GH-S37D Digital Servos
  • 2 x Sets of Epoxy Bracket Pieces with Screws
  • 1 x PCA9685 PWM Servo Control Board
  • 5 x Female-to-Female Jumper Wires

Additional Information

Weight 0.02 kg
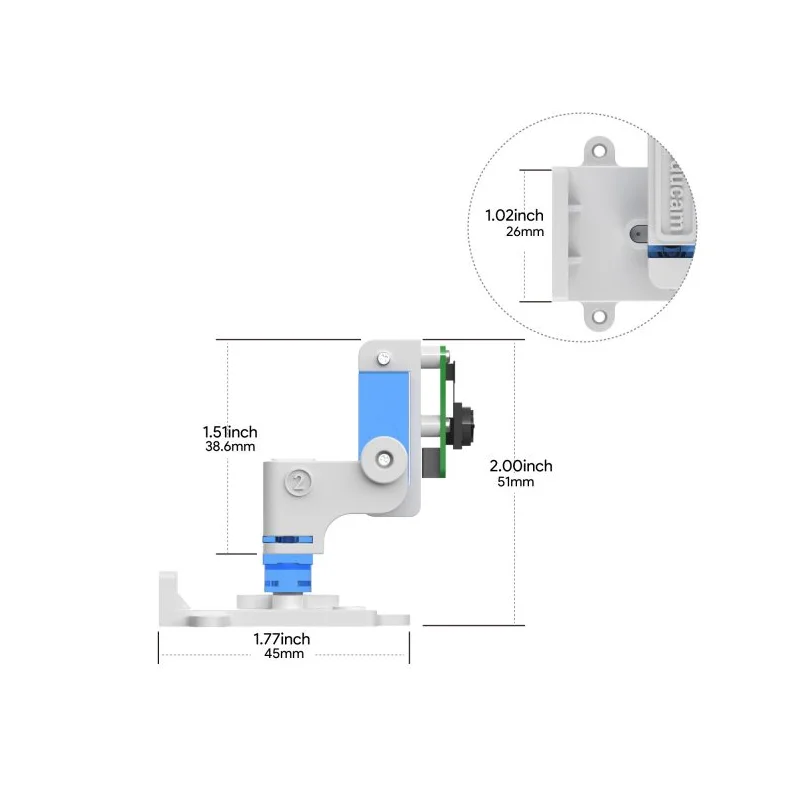
Dimensions 5 × 6 × 3 cm