SKU: IOWC-0402
📋 GST Invoice Available

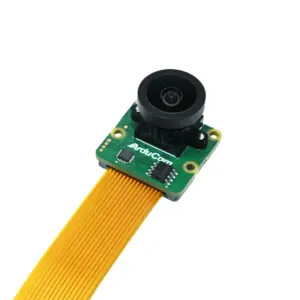
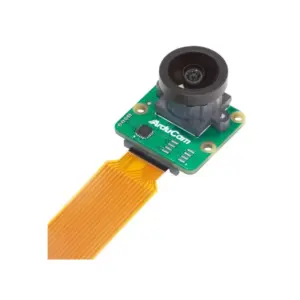
Arducam 8MP Synchronized Stereo Camera Bundle Kit for Jetson Nano

₹10,499.00 (Inclusive of all taxes)
Out of Stock

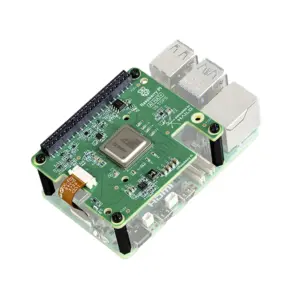
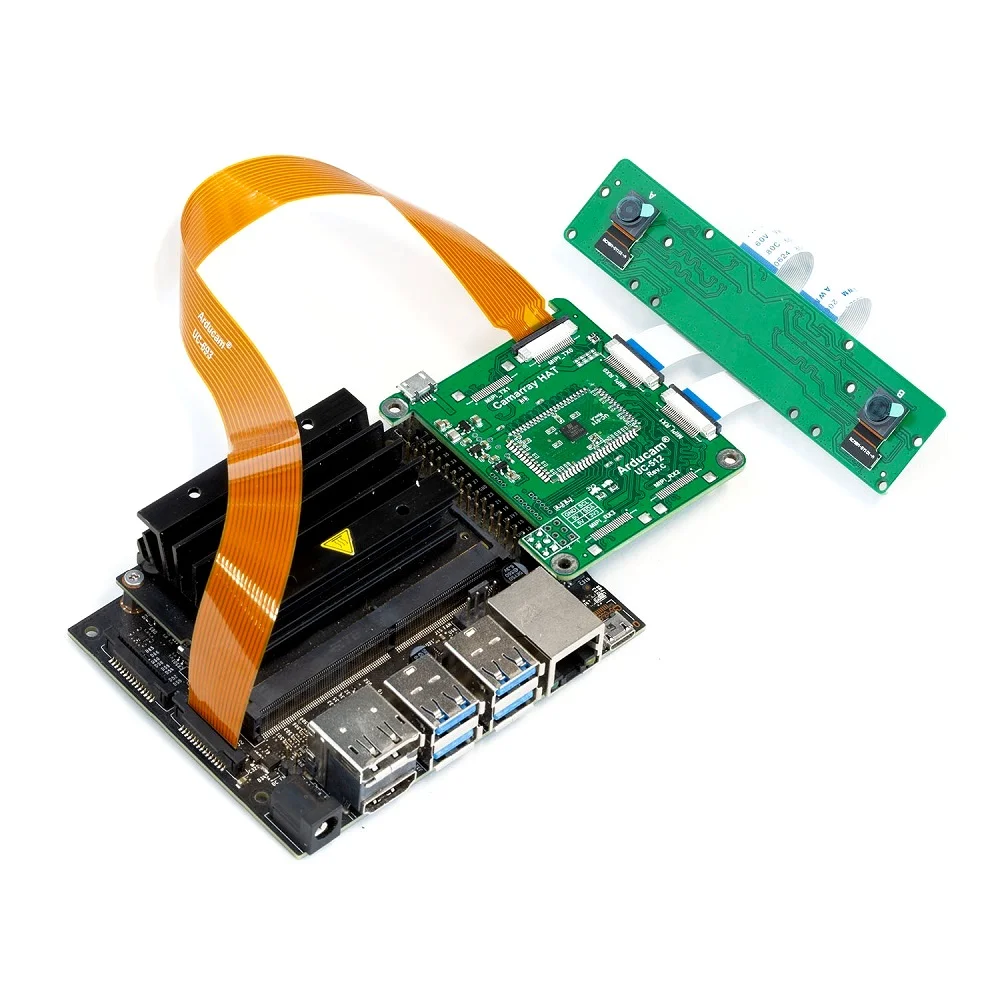
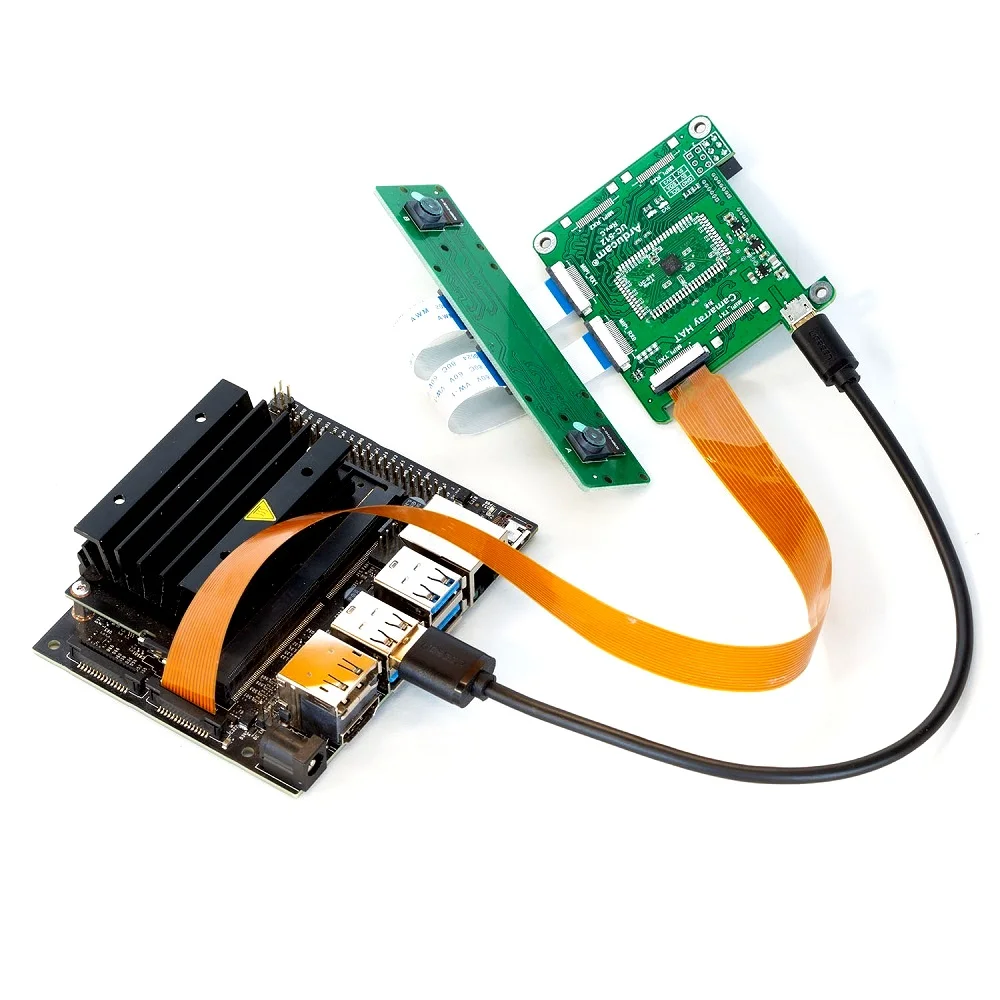
This Arducam bundle kit enables synchronized stereo vision on the NVIDIA Jetson Nano by connecting two 8MP IMX219 cameras via a single CSI-2 port using a proprietary HAT, supporting official IMX219 drivers and OpenCV for depth perception and 3D imaging applications.

Features

  • Enables synchronized stereo imaging with dual 8MP IMX219 sensors for depth mapping and 3D vision.
  • Proprietary ArduChip HAT multiplexes two MIPI camera inputs to a single Jetson Nano CSI-2 port.
  • Supports official NVIDIA IMX219 drivers with full control over exposure, gain, and camera parameters.
  • OpenCV-friendly with provided source code examples for rapid stereo vision application development.
  • Features software-switchable camera channels and digital panning for flexible image processing.

Out of stock

Description

The Arducam Synchronized Stereo Camera Bundle Kit is engineered for advanced computer vision projects on the NVIDIA Jetson Nano and Xavier NX platforms. It utilizes a custom HAT with Arducam’s ArduChip technology to multiplex two high-resolution 8MP IMX219 camera modules into a single MIPI CSI-2 interface, presenting them as a single logical device to the host board. This hardware abstraction simplifies driver installation and system configuration.

The kit provides full frame synchronization between the two cameras, a critical requirement for accurate stereo depth calculation, SLAM (Simultaneous Localization and Mapping), and 3D reconstruction. The HAT supports high-speed MIPI data lanes up to 1Gbps per lane and offers real-time software control for channel switching and digital panning functions, enabling developers to build sophisticated vision systems for robotics, autonomous navigation, and immersive AR/VR applications.

Key Features

  • Synchronized dual-camera capture for precise stereo vision and depth perception.
  • ArduChip-based HAT multiplexer expands a single Jetson CSI-2 port to support two cameras.
  • Plug-and-play compatibility with NVIDIA's official IMX219 camera driver stack.
  • Single-command driver installation simplifies setup and integration.
  • On-the-fly software switching between camera channels (Channel 0 and 1).
  • Digital panning capability at half resolution with programmable pan speed control.
  • OpenCV optimized with demonstration source code for accelerated prototyping.
  • Fixed-focus lenses with a focus distance from 200mm to infinity.

Applications

  • Stereo vision and 3D depth mapping for robotics and drones.
  • 360-degree camera and panoramic imaging systems.
  • Advanced surveillance and security with depth-aware analytics.
  • Enhanced vision goggles and AR/VR headset development.
  • Simultaneous Localization and Mapping (SLAM) for autonomous vehicles.

Technical Specifications

Sensor ModelDual IMX219
Resolution per Camera8 Megapixels
InterfaceMIPI CSI-2
MIPI Input Lanes1 or 2 lanes per camera, up to 1Gbps/lane
MIPI Output Lanes2 lanes
Compatible PlatformsNVIDIA Jetson Nano, Jetson Xavier NX
Driver SupportOfficial NVIDIA IMX219 Driver
Focus Distance200mm to Infinity
HAT Dimensions65 x 56 mm
Shipping Weight0.06 kg

Frequently Asked Questions

How do I install the drivers for this stereo camera kit on my Jetson Nano?

Driver installation is streamlined via a single command line script provided by Arducam. After physically connecting the HAT to the Jetson Nano's 40-pin GPIO and CSI-2 connector, you run the installation command which automatically configures the system to use the official NVIDIA IMX219 driver. This process enables the video nodes and grants control over camera parameters like exposure and gain through standard V4L2 interfaces, making the dual cameras appear as a single synchronized device to your applications.

Can I use this kit with the Jetson Xavier NX or other Jetson modules?

Yes, this Arducam stereo camera bundle is compatible with both the NVIDIA Jetson Nano and the Jetson Xavier NX developer kits. The compatibility stems from the use of the standard MIPI CSI-2 interface and the official IMX219 driver stack shared across these platforms. You follow the same installation procedure. Ensure your carrier board has the appropriate CSI-2 camera connector accessible. The kit is not designed for Jetson Orin or modules with different physical connectors without an adapter.

What is the benefit of the camera synchronization feature in this kit?

The hardware synchronization ensures both 8MP IMX219 cameras capture image frames at precisely the same moment. This is critical for accurate stereo vision algorithms that calculate depth by comparing the slight differences (disparity) between the two images. Without synchronization, moving objects or platform vibration can cause mismatched frames, leading to erroneous depth maps. This feature is essential for reliable 3D reconstruction, obstacle avoidance in robotics, and creating immersive 3D experiences.

How do I access and process the video streams from the two cameras using OpenCV?

After driver installation, the system presents the synchronized stereo stream through standard Video4Linux (V4L2) devices. Arducam provides demonstration source code in Python/C++ that shows how to use OpenCV's VideoCapture function to open the correct video node. The code examples illustrate capturing frames, separating the left and right camera images from the combined stream, and performing basic stereo processing like computing a depth map using OpenCV's stereo block matching algorithms.

Package Includes

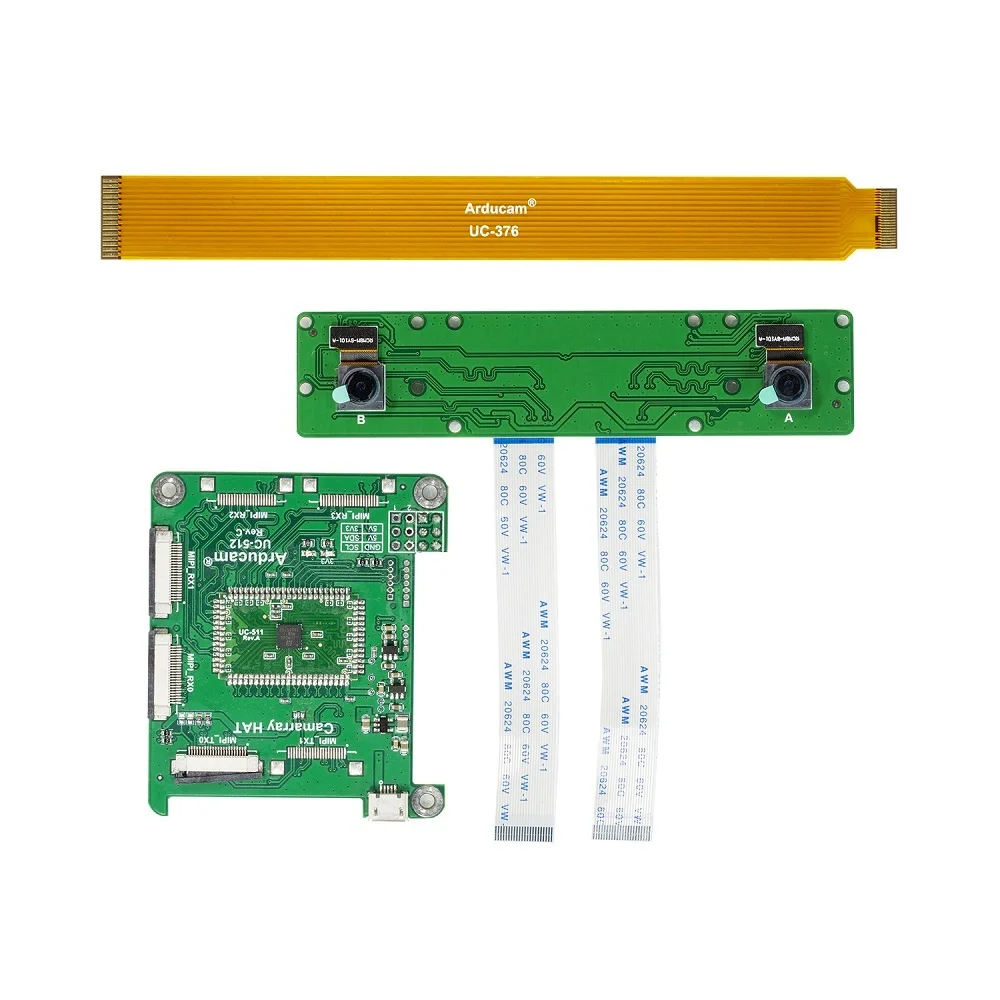
  • 1 x Arducam 8MP Synchronized Stereo Camera Bundle Kit for Jetson Nano (including HAT and two cameras)

Additional Information

Weight 0.06 kg
Dimensions 5 × 7 × 3 cm