SKU: SENS-1034
📋 GST Invoice Available

DFRobot Fermion BMI323+BMM350+BMP581 10DOF IMU Sensor Breakout Module - I2C Interface

₹2,469.00 (Inclusive of all taxes)
Out of Stock

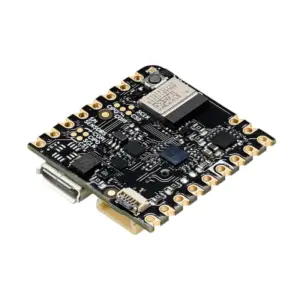
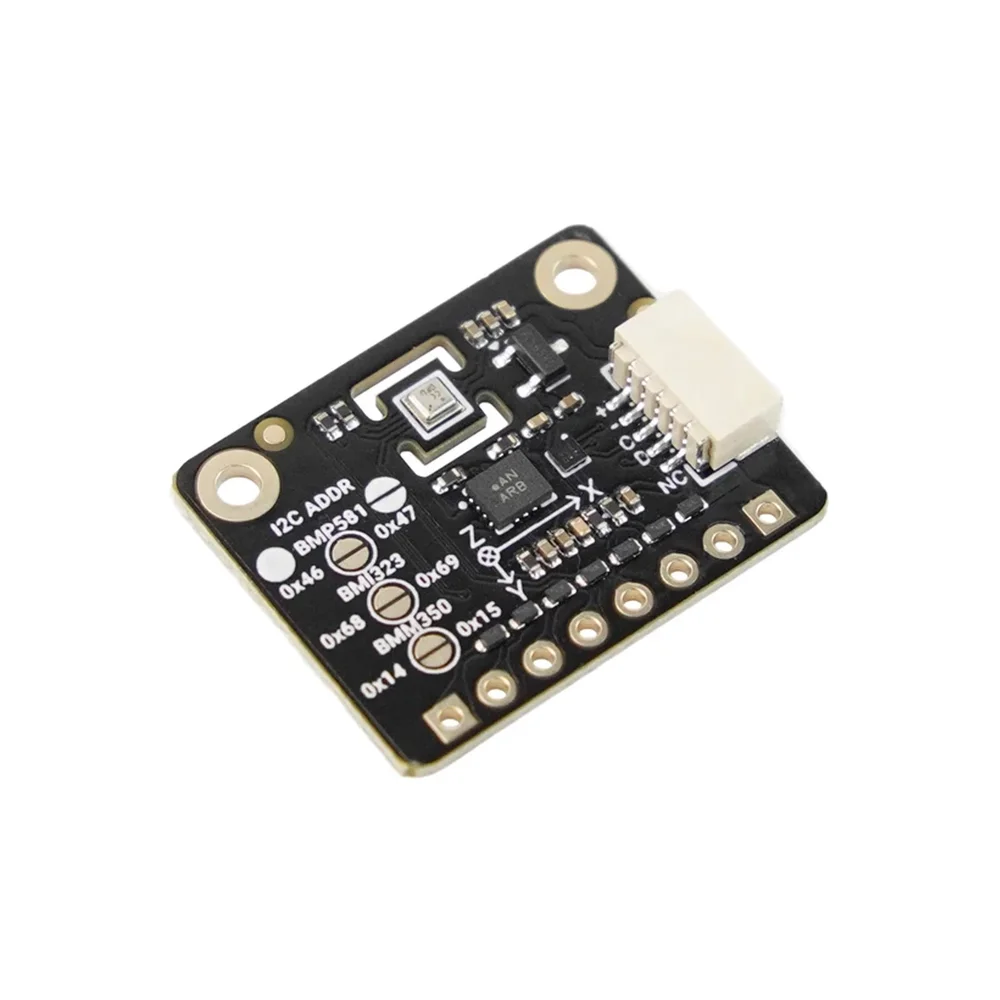
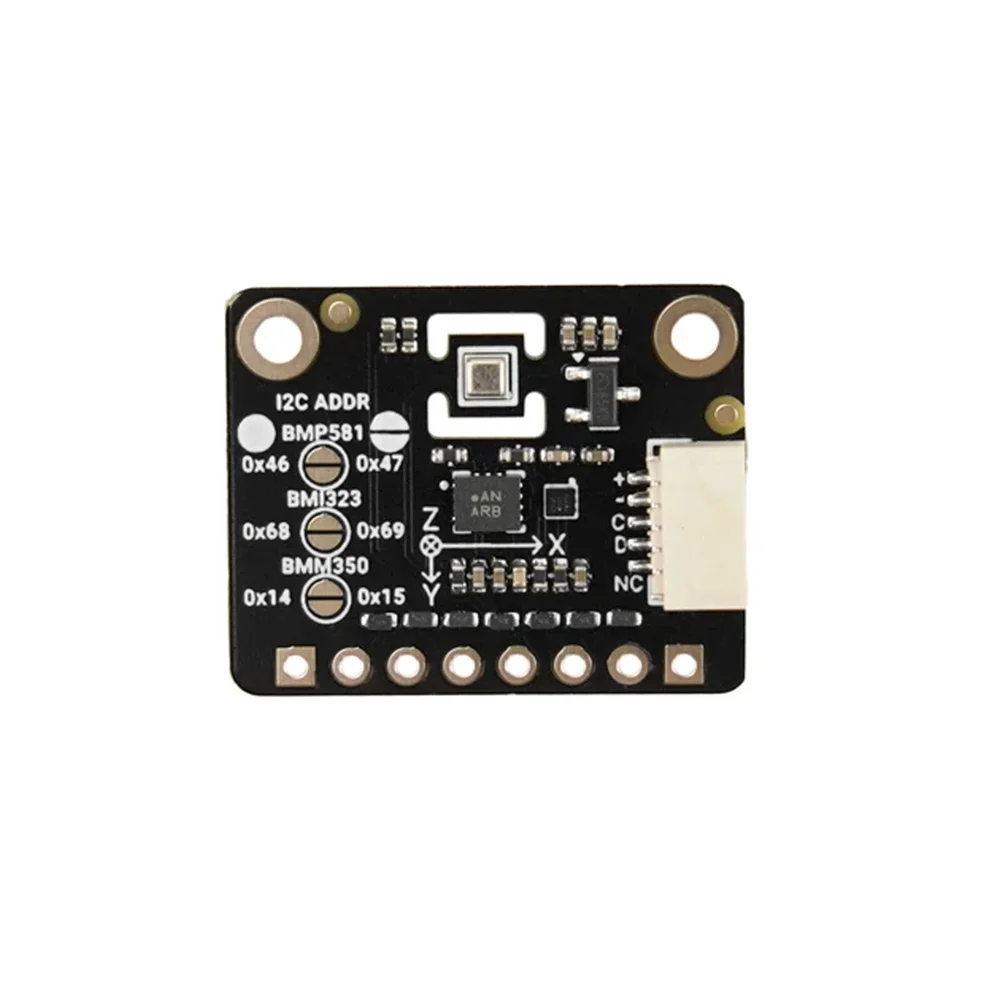
The DFRobot Fermion 10DOF IMU sensor integrates Bosch BMI323 (6-axis), BMM350 (3-axis magnetometer), and BMP581 (barometric) sensors on a compact breakout board. It provides precise motion, heading, and altitude data via a native I2C interface, compatible with Arduino, Raspberry Pi, and ESP32 platforms.

Features

  • Integrated Bosch BMI323 6-axis IMU, BMM350 magnetometer, and BMP581 barometric pressure sensor.
  • Provides 10 degrees of freedom (DOF) for comprehensive motion, orientation, and environmental sensing.
  • Native I2C interface with configurable addresses and programmable interrupt pins for efficient host communication.
  • Built-in hardware motion algorithms for step counting, tap detection, and activity recognition.
  • Supports multiple power modes (Sleep, Low Power, Normal, High Performance) for optimized energy consumption.

Out of stock

Description

This high-precision 10DOF inertial measurement unit combines three dedicated Bosch sensors on a single compact PCB. The BMI323 delivers 3-axis accelerometer and gyroscope data with configurable ranges and output data rates. The BMM350 3-axis magnetometer provides accurate heading information, while the BMP581 barometric sensor enables altitude tracking with high relative accuracy. The module’s integrated 2 KB FIFO buffer allows for efficient batch data transfer, reducing host processor load.

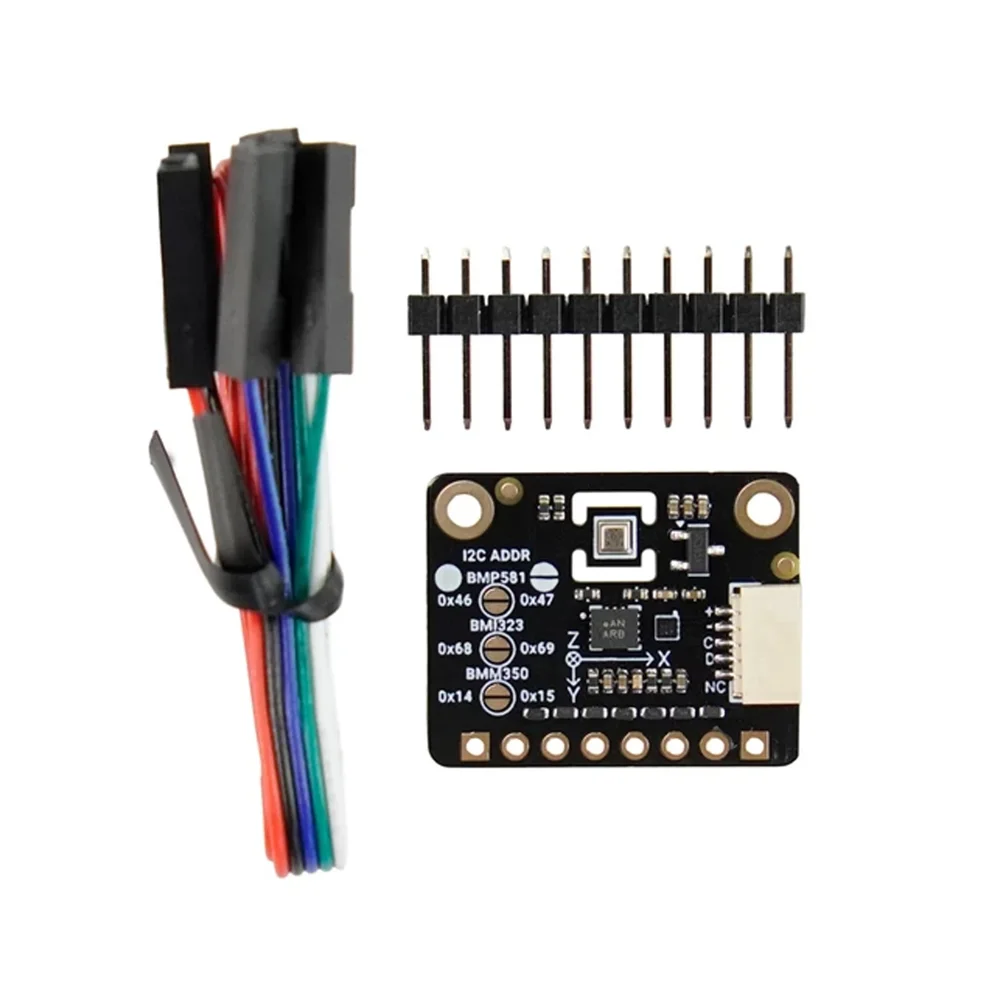
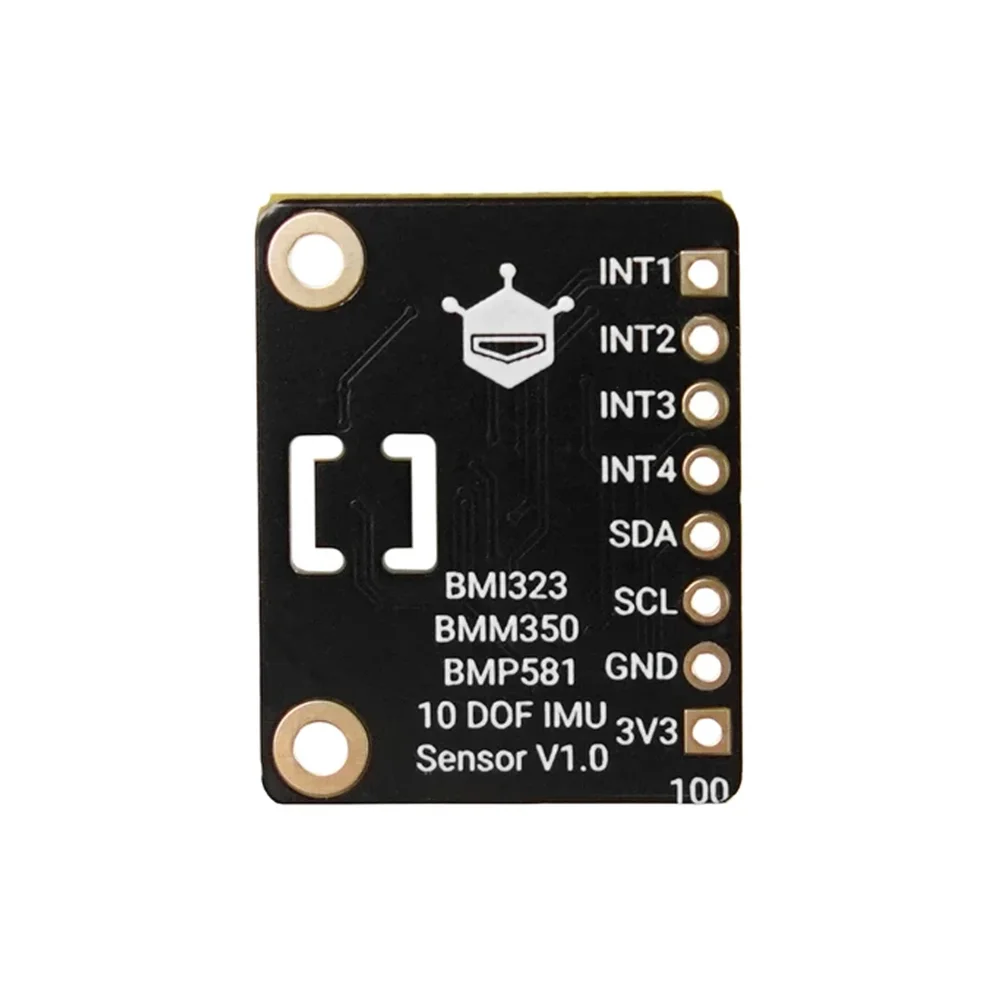
Designed for embedded integration, the breakout features both a soldered SH1.0-5P connector and standard 2.54mm pin header holes, offering flexible connection options. Its low operating current of 1.12 mA (normal mode) makes it suitable for battery-powered applications such as wearables, drones, and portable navigation systems. Comprehensive development libraries for popular platforms accelerate project deployment.

Key Features

  • Bosch Sensor Cluster: Integrates BMI323 6-axis IMU, BMM350 3-axis magnetometer, and BMP581 barometric sensor for all-in-one environmental and motion sensing.
  • High-Resolution Sensing: 16-bit resolution for accelerometer and gyroscope; magnetometer resolution of approximately 0.1 µT; pressure resolution of ~0.0156 Pa.
  • Configurable Performance: Selectable accelerometer ranges (±2g to ±16g) and gyroscope ranges (±125 to ±2000 °/s) with adjustable ODR from 0.78125 Hz to 6400 Hz.
  • Intelligent Onboard Processing: Built-in hardware algorithms for motion detection (step count, tap, tilt, free-fall) without taxing the main microcontroller.
  • Flexible Power Management: Four operating modes (Sleep, Low Power, Normal, High Performance) to balance accuracy and power consumption, with low-power current as low as 0.37 mA.
  • Robust Connectivity: Native I2C interface with default and alternate addresses for each sensor; includes four programmable interrupt pins for event-driven designs.
  • Compact Embedded Design: 24 x 19 mm PCB with 2mm mounting holes for secure mechanical integration into drones, robots, and wearable devices.

Applications

  • Drone and UAV flight stabilization, heading control, and altitude hold systems.
  • Robotics localization, SLAM (Simultaneous Localization and Mapping), and inertial navigation for autonomous platforms.
  • Wearable electronics for advanced activity tracking, step counting, and gesture recognition.
  • Electronic compass and attitude reference systems for marine, automotive, and aerospace instrumentation.
  • Indoor pedestrian navigation and dead reckoning in GPS-denied environments.

Technical Specifications

Product Type10DOF IMU Sensor Module
Sensor CombinationBosch BMI323 + Bosch BMM350 + Bosch BMP581
Motion Sensors3-axis Accelerometer + 3-axis Gyroscope (BMI323)
Magnetometer3-axis BMM350
Barometric SensorBMP581
Operating Voltage3.3 V
Operating Current (Normal)1.12 mA
Low Power Current0.37 mA
Communication InterfaceI²C
Connector TypeSH1.0-5P Connector / 2.54 mm Pin Header Holes
I²C AddressesBMI323: 0x69/0x68; BMM350: 0x15/0x14; BMP581: 0x47/0x46
Programmable Interrupt Pins4
Accelerometer Range±2g, ±4g, ±8g, ±16g (Selectable)
Accelerometer Resolution16-bit
Accelerometer ODR12.5 Hz – 6400 Hz (High Performance/Normal); 0.78125 Hz – 400 Hz (Low Power)
Gyroscope Range±125, ±250, ±500, ±1000, ±2000 °/s (Selectable)
Gyroscope Resolution16-bit
Gyroscope ODR12.5 Hz – 6400 Hz (High Performance/Normal); 0.78125 Hz – 400 Hz (Low Power)
Magnetometer Range±2000 µT
Magnetometer ResolutionApprox. 0.1 µT
Magnetometer Max Sampling Rate400 Hz
Pressure Measurement Range30 kPa – 125 kPa
Pressure ResolutionApprox. 0.0156 Pa
Pressure Relative AccuracyTypical ±6 Pa
Temperature Measurement Range-40°C to +85°C
Temperature Accuracy±0.5 K
Pressure ODR0.125 Hz – 240 Hz
PCB Size24 × 19 mm
Mounting Hole Spacing19 mm
Mounting Hole Diameter2 mm
Mounting TypeThrough-Hole Mount
Weight4 g

Frequently Asked Questions

What is the operating voltage of this 10DOF IMU module, and can it tolerate 5V logic?

The module operates strictly at 3.3V. The I2C interface is not 5V tolerant. You must use a logic level converter if connecting to a 5V microcontroller like most Arduinos to prevent damage to the sensitive Bosch sensors.

How do I connect this sensor to an Arduino or Raspberry Pi?

Connect the module's I2C pins (SDA, SCL) to your host's corresponding I2C bus, ensuring a common ground and a 3.3V power supply. The included cable and pin header offer flexible connection options. DFRobot provides dedicated libraries for Arduino and Raspberry Pi to simplify reading data from all three integrated sensors.

What are the default I2C addresses for the three sensors on this module?

Each sensor has a default and an alternate address: the BMI323 IMU uses 0x69 (default) or 0x68; the BMM350 magnetometer uses 0x15 (default) or 0x14; the BMP581 pressure sensor uses 0x47 (default) or 0x46. This allows multiple modules or other I2C devices to coexist on the same bus.

Does the module require calibration for the magnetometer?

Yes, for accurate heading (compass) functionality, the BMM350 magnetometer requires calibration to compensate for hard and soft iron distortions in its local environment. This process involves rotating the device through multiple orientations to map the local magnetic field. The provided libraries typically include helper functions for this calibration routine.

Can the built-in motion detection algorithms run independently of the main CPU?

Yes. The Bosch BMI323 features dedicated hardware that processes motion data internally to detect events like steps, taps, tilt, and free-fall. These algorithms run on the sensor itself, generating interrupts that can wake a sleeping host processor, which significantly reduces system power consumption and computational load.

Package Includes

  • 1 x Fermion: BMI323+BMM350+BMP581 High Precision 10 DOF IMU Sensor Module
  • 1 x SH1.0-5P Sensor Cable
  • 1 x 2.54 mm Black Single Row Pin Header – 10-Pin

Additional Information

Weight 0.015 kg
Dimensions 8 × 8 × 3 cm