SKU: DRFC-1896
📋 GST Invoice Available

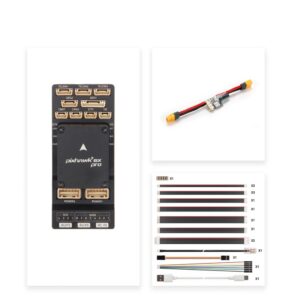
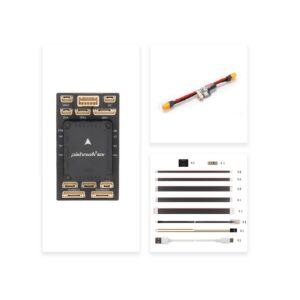
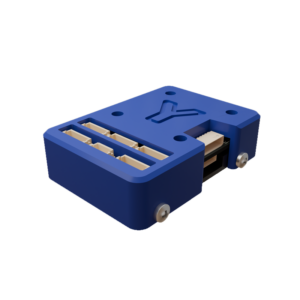
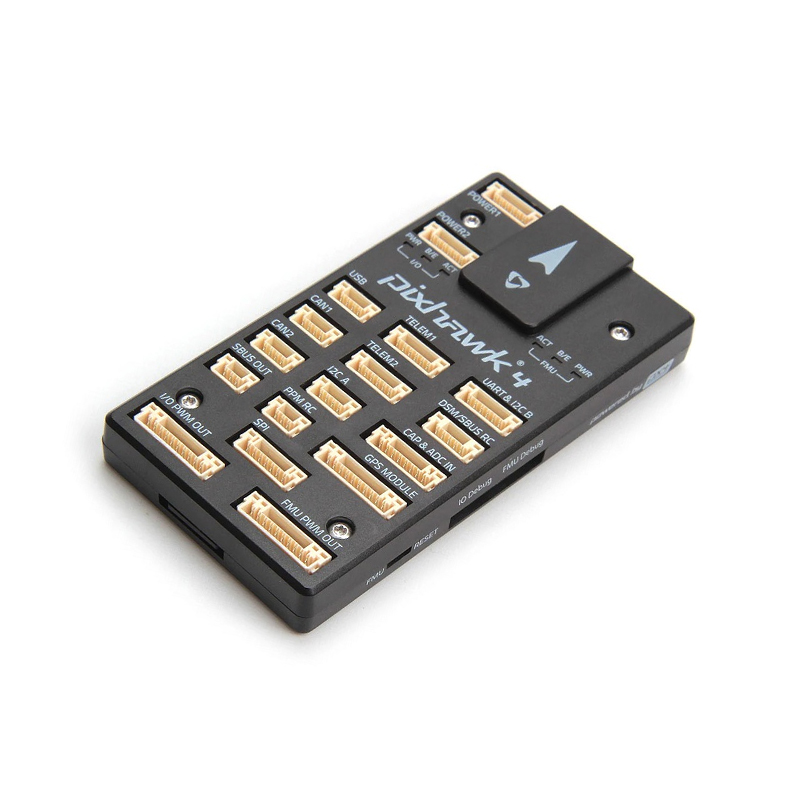
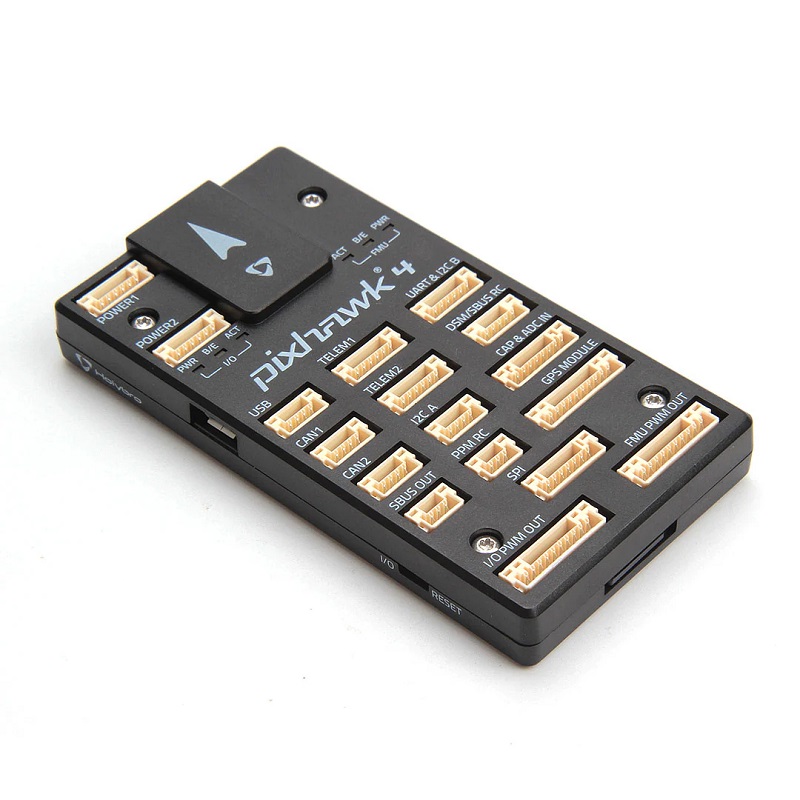
Holybro Pixhawk 4 Autopilot Flight Controller - Plastic Case

₹15,899.00 (Inclusive of all taxes)
Out of Stock

The Holybro Pixhawk 4 is a high-performance autopilot flight controller designed for autonomous drones, robots, and unmanned systems. It runs the open-source ArduPilot or PX4 firmware on the NuttX real-time OS and features advanced vibration-isolated IMUs for precise stabilization and control.

Features

  • STM32F765 FMU processor with 2MB flash and 512KB RAM for complex autonomous algorithms.
  • Dual redundant IMUs from Bosch® and InvenSense® mounted on advanced vibration isolation.
  • Comprehensive connectivity with 2x SPI and 4x I2C buses for sensor expansion.
  • Runs the NuttX real-time operating system (RTOS) for reliable, deterministic performance.
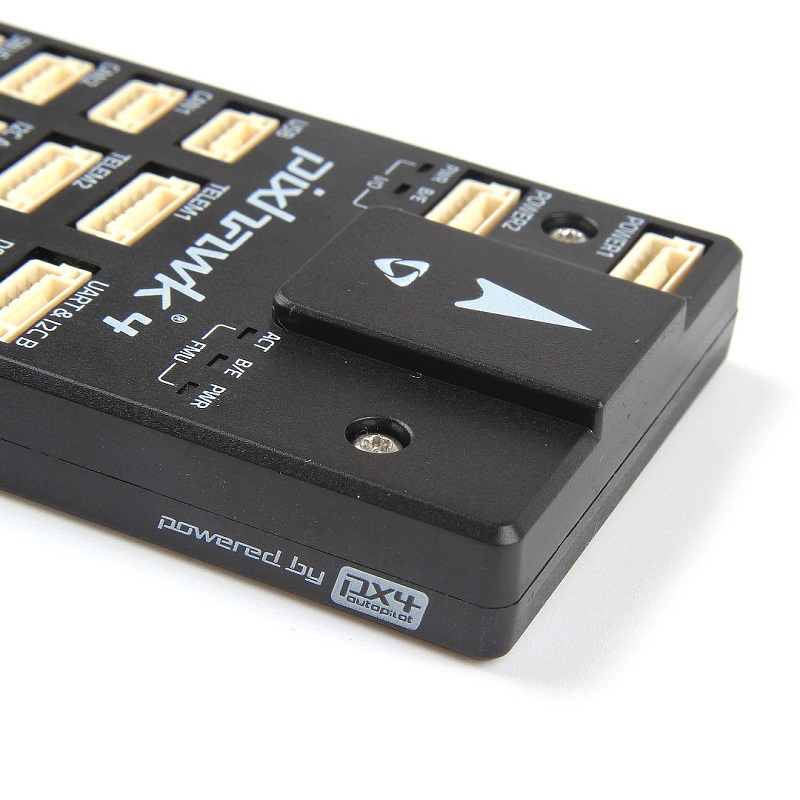
  • Protected by a durable, lightweight plastic case suitable for aerial, ground, and marine vehicles.

Out of stock

Description

The Holybro Pixhawk 4 is engineered as a robust, open-source autopilot platform for developers and researchers. Its core is the powerful STM32F765 microcontroller, providing ample processing headroom for running sophisticated navigation and control algorithms within the ArduPilot or PX4 ecosystem. The board’s design prioritizes sensor integrity, featuring two independent inertial measurement units from leading manufacturers, each isolated from frame vibrations to ensure accurate attitude estimation even in harsh operational environments.

Connectivity is a key strength, with multiple serial, SPI, and I2C ports enabling seamless integration of peripherals like GPS modules, telemetry radios, optical flow sensors, and companion computers. The inclusion of a dedicated, high-current sensing port supports advanced power monitoring. Housed in a protective plastic case, the Pixhawk 4 balances impact resistance with minimal weight addition, making it a versatile choice for a wide range of autonomous vehicle applications beyond multirotors, including fixed-wing aircraft, rovers, and boats.

Key Features

  • High-Performance Processing: STM32F765 ARM Cortex-M7 core clocked at 216 MHz with FPU, enabling fast computation for autonomous navigation.
  • Redundant, Vibration-Isolated IMUs: Features both a Bosch BMI088 and an InvenSense ICM-20689 gyro/accelerometer pair on soft-mounted isolation platforms for fault tolerance and clean data.
  • Extensive I/O Expansion: Provides 2x SPI, 4x I2C, 5x UART (serial), and 8x PWM outputs for connecting a full suite of sensors and actuators.
  • Real-Time Operating System: Pre-loaded with the NuttX RTOS, offering a stable, predictable environment for time-critical flight control tasks.
  • Robust Power Design: Accepts a wide input voltage range via multiple power ports, with integrated voltage regulation and high-current sensing capability.
  • Open-Source Firmware: Fully compatible with the mature ArduPilot and PX4 flight stacks, supported by a vast global developer community.
  • Lightweight Protective Enclosure: The injection-molded plastic case shields critical components from physical damage and EMI while minimizing added mass.

Applications

  • Primary flight controller for autonomous multirotor drones (quadcopters, hexacopters, octocopters).
  • Navigation brain for fixed-wing UAVs used in mapping, surveillance, and long-endurance missions.
  • Control system for unmanned ground vehicles (UGVs) and rovers in research and exploration.
  • Autopilot for marine surface vessels and underwater ROVs requiring precise waypoint navigation.
  • Development platform for academic research and prototyping in robotics and autonomous systems.

Technical Specifications

Item TypeAutopilot Flight Controller (Plastic Case)
FMU ProcessorSTM32F765 (ARM Cortex-M7 @ 216MHz)
Memory2MB Flash, 512KB RAM
Operating SystemNuttX Real-Time OS (RTOS)
Primary IMUsBosch BMI088 Gyro/Accel, InvenSense ICM-20689 Gyro/Accel
Input Voltage4.5V - 5.5V (USB), 6V - 36V (Power Module Input)
Max Current Sensing120 A
Connectivity Buses2x SPI, 4x I2C, 5x UART, 1x CAN
Shipping Weight0.173 kg
Shipping Dimensions15 x 9 x 5 cm

Frequently Asked Questions

What firmware is compatible with the Holybro Pixhawk 4?

The Holybro Pixhawk 4 is fully compatible with the open-source ArduPilot and PX4 flight stacks. It comes pre-loaded with the NuttX real-time operating system, providing a stable base for these firmware platforms. You can flash and configure it using Mission Planner or QGroundControl ground station software.

What is the input voltage range for the Pixhawk 4?

The Pixhawk 4 accepts power via two main methods. For logic-level power and USB programming, it requires 4.5V to 5.5V. For primary flight power, it connects to a LiPo battery via a compatible Power Module, accepting a wide range from 6V to 36V (typically covering 2S to 8S LiPo batteries). Always use a regulated power source or a dedicated flight controller power module.

How does the vibration isolation improve flight performance?

The Pixhawk 4 features newly designed, soft vibration isolation mounts for its dual IMU sensors (Bosch BMI088 and InvenSense ICM-20689). This mechanical filtering attenuates high-frequency vibrations from motors and propellers before they reach the gyroscopes and accelerometers. The result is cleaner sensor data, which leads to more accurate attitude estimation, smoother flight, and better performance of attitude control loops, especially on aggressive multirotor frames.

Package Includes

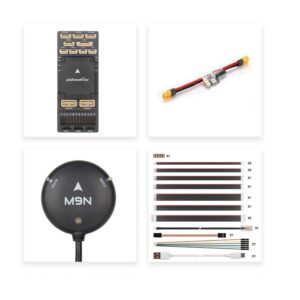
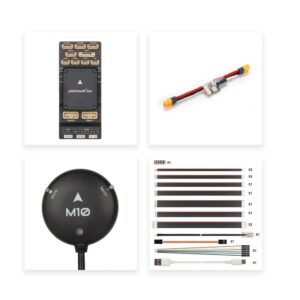
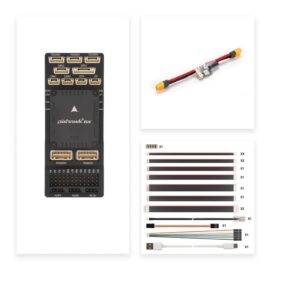
  • 1 x Holybro Pixhawk 4 Flight Controller (Plastic Case)

Additional Information

Weight 0.173 kg
Dimensions 15 × 9 × 5 cm