SKU: DRFC-2048
📋 GST Invoice Available

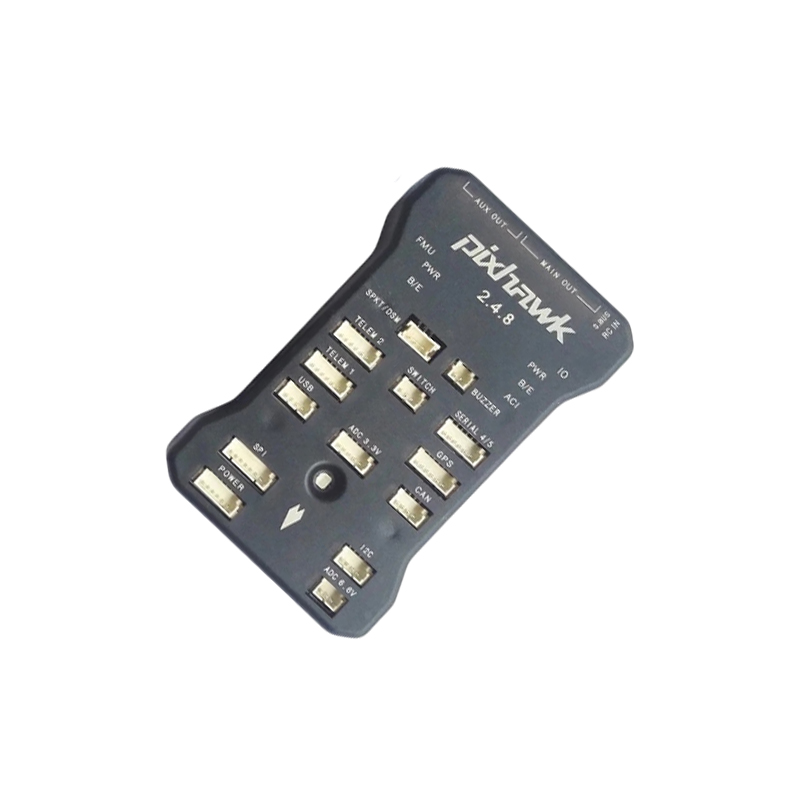
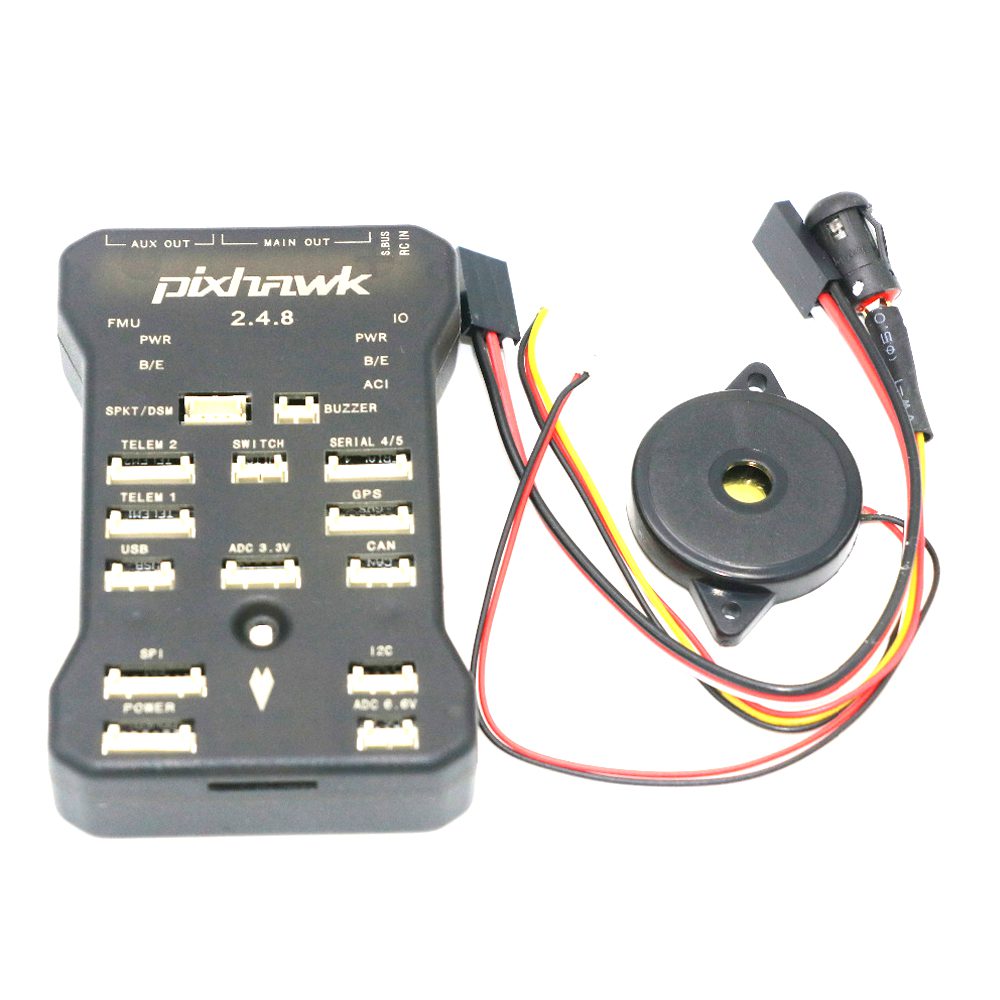
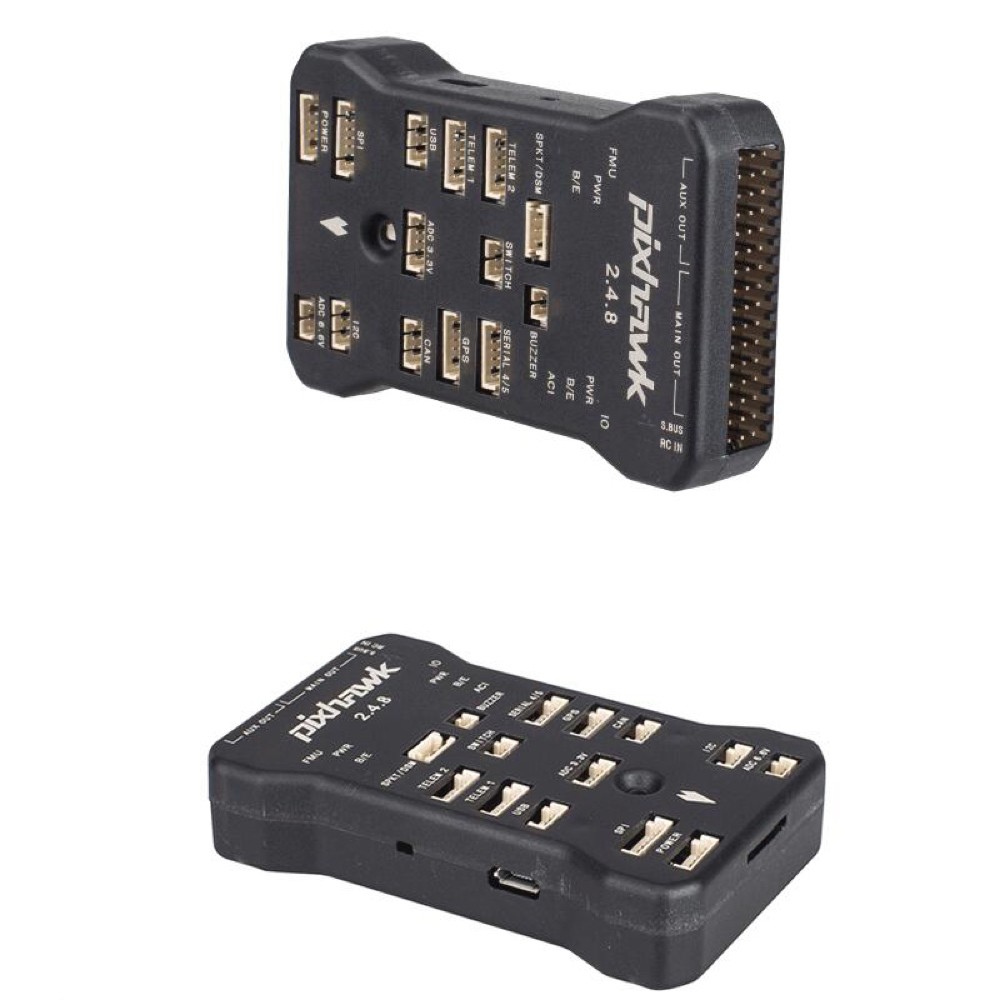
Pixhawk PX4 Autopilot PIX 2.4.8 32 Bit Flight Controller - Standard Set w/ MicroSD & Buzzer

₹5,499.00 (Inclusive of all taxes)
Out of Stock

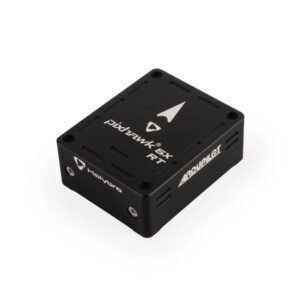
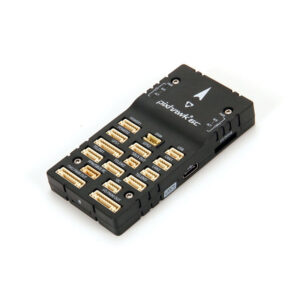
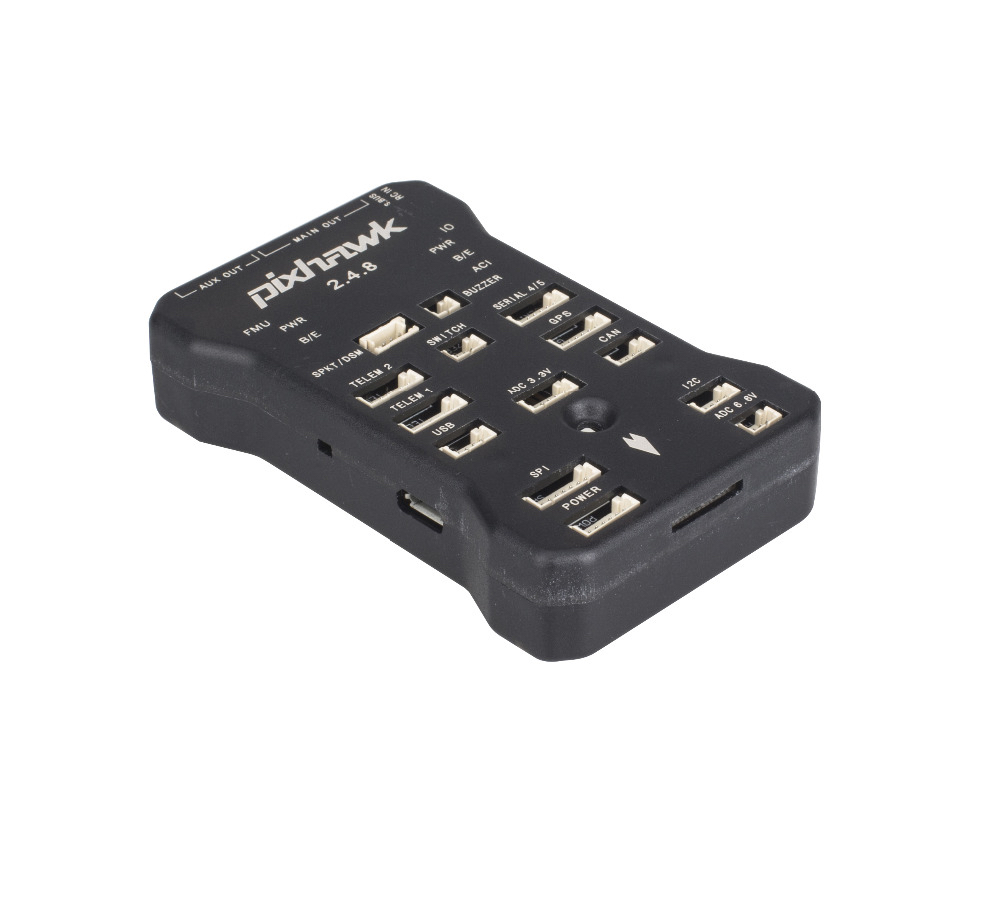
The Pixhawk PX4 Autopilot PIX 2.4.8 is a 32-bit flight controller based on the open-source ArduPilot platform, featuring an STM32F427 Cortex M4 main processor and a dedicated STM32F103 failsafe co-processor. It is designed for autonomous multirotor, fixed-wing, and rover applications, supporting extensive sensor integration and programmable GPS missions via the Mission Planner ground control software.

Features

  • 32-bit STM32F427 Cortex M4 main processor with FPU and 168 MHz clock speed.
  • Dedicated 32-bit STM32F103 failsafe co-processor for redundant backup control.
  • Comprehensive sensor suite: L3GD20H 16-bit gyro, LSM303D 14-bit accel/mag, MPU6000 IMU, and MS5607 barometer.
  • 14 PWM/servo outputs with support for S.BUS, PPM, DSM2/DSM-X satellite, and RSSI inputs.
  • Extensive connectivity: 5x UART serial ports, 2x CAN bus, I2C, SPI, and dual micro USB ports.

Out of stock

Description

The Pixhawk PX4 Autopilot PIX 2.4.8 represents a mature, open-source flight control platform built around a high-performance 32-bit ARM Cortex M4 core running the NuttX real-time operating system. Its architecture includes a dedicated failsafe co-processor, ensuring system integrity should the primary controller encounter a fault. This design provides robust support for automatic and manual flight modes, redundant power input with automatic failover, and integrated data logging via a microSD card slot.

Engineered for professional and research-grade UAV applications, the controller offers extensive bus interfaces including UART, I2C, SPI, and CAN, facilitating seamless integration with peripherals such as GPS modules, telemetry radios, airspeed sensors, and optical flow cameras. The system’s support for the ArduPilot firmware enables sophisticated autonomous behaviors, complex mission scripting, and compatibility with a wide range of vehicle types from multirotors to fixed-wing aircraft and ground rovers.

Key Features

  • Dual-processor design with primary STM32F427 and backup STM32F103 for enhanced flight safety and redundancy.
  • High-precision sensor fusion from a 16-bit gyroscope, 14-bit accelerometer/magnetometer, and a dedicated barometer for accurate altitude hold.
  • Five UART serial ports provide ample connectivity for GPS, telemetry, companion computers, and other serial peripherals.
  • Integrated microSD card slot for high-rate blackbox flight data logging and mission storage.
  • Supports redundant power input (7V nominal) with automatic failover to ensure continuous operation.
  • Hardware interfaces for a multicolor status LED and a multi-tone buzzer for audible system alerts.
  • Compatible with standard RC protocols including S.BUS, PPM, and Spektrum DSM2/DSM-X satellite for flexible receiver options.

Applications

  • Autonomous multirotor drones for aerial mapping, surveying, and inspection.
  • Fixed-wing UAVs for long-endurance surveillance and payload delivery missions.
  • Research and development platforms for testing advanced autonomy algorithms and swarm behaviors.
  • Heavy-lift cinematography drones requiring reliable waypoint navigation and stabilization.
  • Ground rover and boat automation projects leveraging the same ArduPilot firmware base.

Technical Specifications

ModelPIX 2.4.8
Main Processor32-bit STM32F427 Cortex M4 with FPU @ 168 MHz
Failsafe Processor32-bit STM32F103
Memory128 KB RAM, 2 MB Flash
GyroscopeST Micro L3GD20H 16-bit
Accelerometer/MagnetometerST Micro LSM303D 14-bit
IMUInvensense MPU6000 3-axis accelerometer/gyroscope
BarometerMEAS MS5607
PWM/Servo Outputs14
Serial Interfaces (UART)5
CAN Bus2
Input Voltage7V (Nominal, Redundant Input)
FirmwareArduPilot / PX4 (via Mission Planner)
MicroSD SlotYes
Dimensions (L x W x H)82 x 50 x 16 mm
Weight40 g

Frequently Asked Questions

What is the primary firmware used with the Pixhawk PIX 2.4.8?

The Pixhawk PIX 2.4.8 is primarily designed to run the open-source ArduPilot firmware, which can be configured and managed using the Mission Planner ground control station software. It is also compatible with the PX4 flight stack. The controller's 2 MB of flash memory and powerful STM32F427 processor provide ample resources for the full feature set of these advanced autopilot systems.

How many PWM or servo channels does this flight controller support?

This flight controller supports up to 14 PWM or servo outputs, making it suitable for complex multirotor, fixed-wing, or robotic applications requiring control over multiple actuators, servos, or gimbals. The outputs are managed through the ArduPilot firmware, which allows for flexible channel assignment and mixing.

What are the power input requirements and does it support redundancy?

The controller has a nominal input voltage of 7V and features redundant power input connections with automatic failover. This design ensures that if one power source fails, the system can seamlessly switch to the backup, which is critical for maintaining flight stability and safety in professional UAV operations.

Can I connect a GPS module and telemetry radio simultaneously?

Yes, the controller's five UART serial ports allow you to connect multiple peripherals concurrently. Typically, one UART is dedicated to a GPS module (e.g., u-blox M8N), another to a telemetry radio (e.g., 3DR or Holybro), and others can be used for a companion computer, optical flow sensor, or additional serial devices as needed for your specific autonomous application.

Package Includes

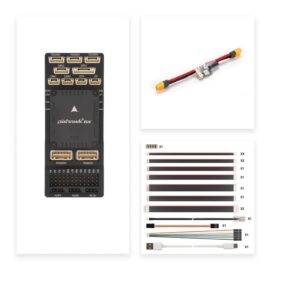
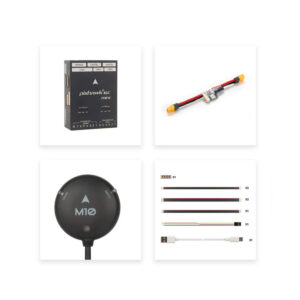
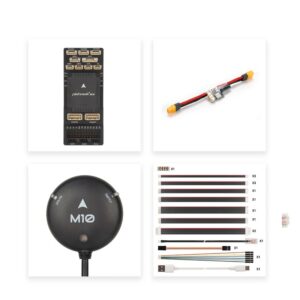
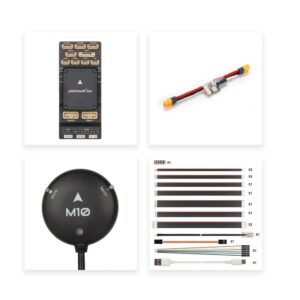
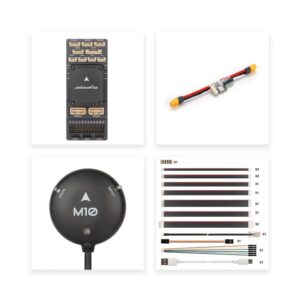
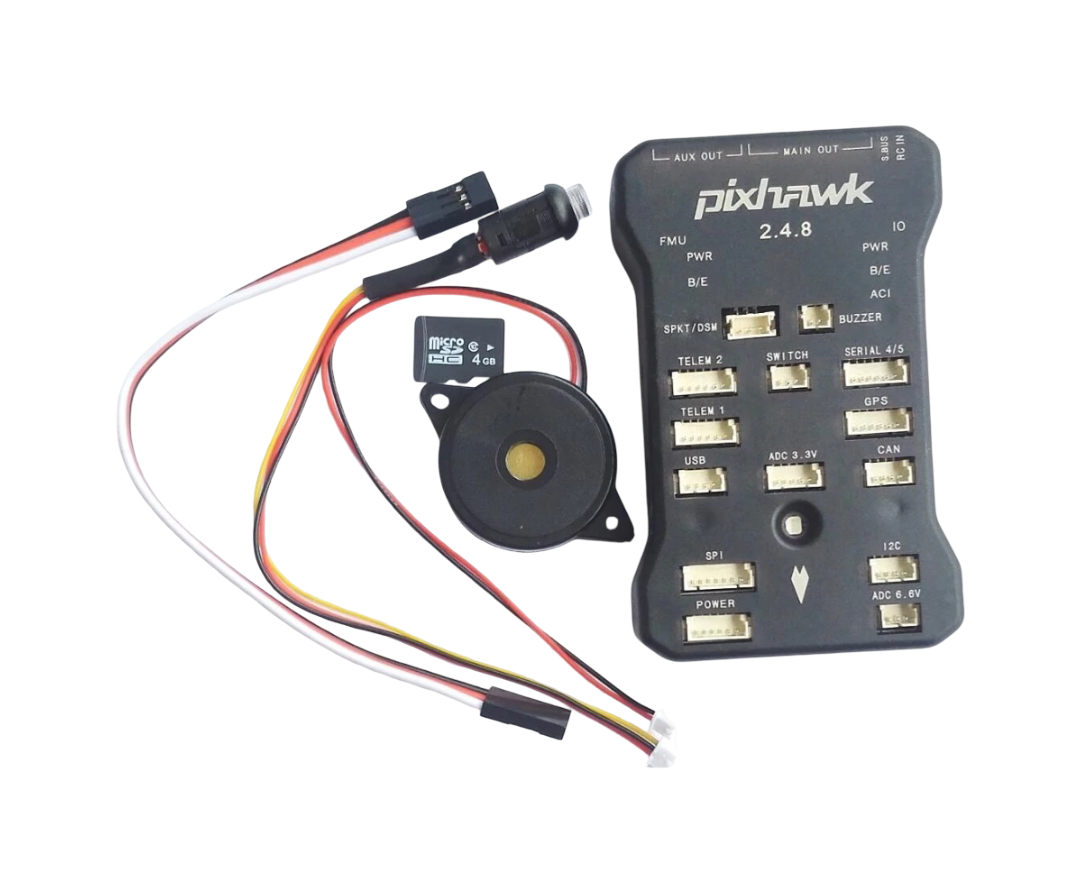
  • 1 x Pixhawk PX4 Autopilot PIX 2.4.8 Flight Controller
  • 1 x 4GB MicroSD Card with SD Adapter (pre-loaded with firmware)
  • 3 x Connecting Cables
  • 1 x Buzzer Module

Additional Information

Weight 0.04 kg
Dimensions 8.2 × 5 × 1.6 cm