SKU: DRFC-1891
📋 GST Invoice Available

Holybro Pixhawk 4 & PM07 14S Power Module Set

₹23,879.00 (Inclusive of all taxes)
Out of Stock

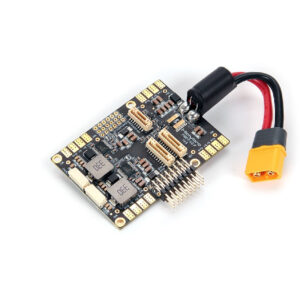
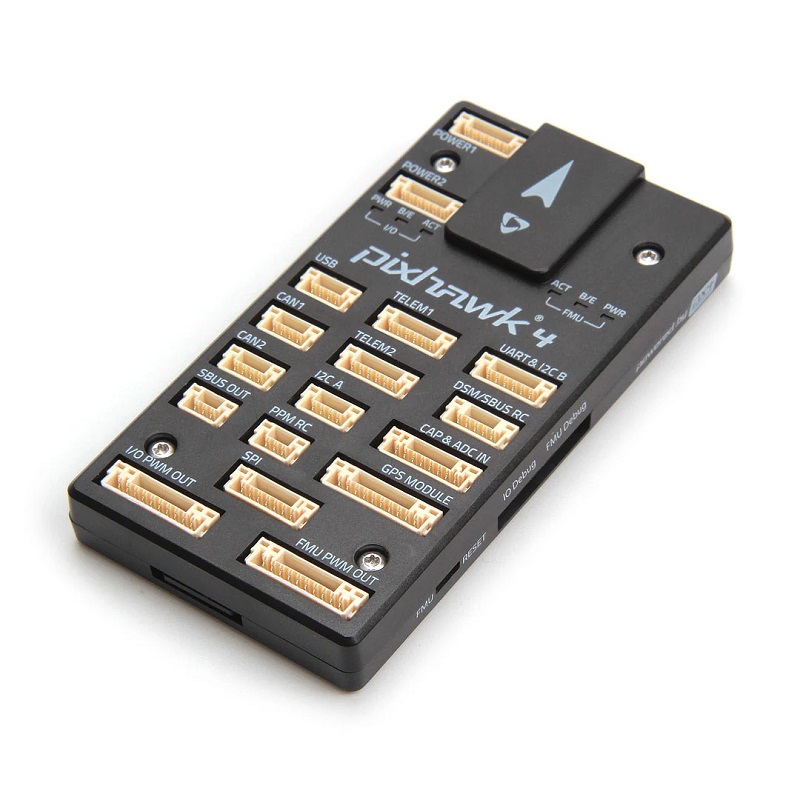
The Holybro Pixhawk 4 is a high-performance flight controller paired with the PM07 14S Power Module, designed for professional UAV and autonomous vehicle applications. It features a dual-processor architecture, low-noise IMUs with vibration isolation, and extensive I/O connectivity for complex sensor integration, running on the NuttX real-time operating system.

Features

  • Dual-processor design with STM32F765 FMU and STM32F103 IO for robust, real-time flight control.
  • Features high-precision Bosch and InvenSense IMUs (ICM-20689, BMI055) with advanced vibration isolation for stable flight data.
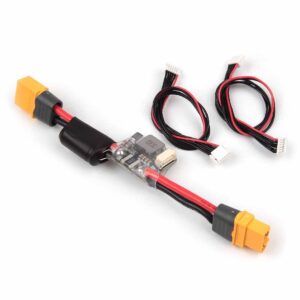
  • Includes the PM07 14S Power Module for up to 14S LiPo battery monitoring and high-current sensing up to 120A.
  • Extensive connectivity with 2x SPI and 4x I2C buses for adding peripherals, GPS, and compass modules.
  • Optimized for ArduPilot and PX4 firmware, supporting complex autonomous algorithms for drones, robotics, and research platforms.

Out of stock

Description

The Holybro Pixhawk 4 flight controller is engineered for demanding autonomous systems, leveraging a powerful STM32F765 microcontroller with 2MB flash and 512KB RAM. This computational headroom allows for the implementation of sophisticated navigation and control algorithms. The board integrates multiple, strategically placed inertial measurement units from Bosch and InvenSense, coupled with a dedicated vibration damping system, to deliver exceptionally clean sensor data critical for stabilization in high-vibration environments.

Paired with the PM07 14S Power Module, this set provides comprehensive power management, supporting input voltages from 2S to 14S LiPo batteries. The power module offers precise voltage and current telemetry, with a sensing capability up to 120A, ensuring reliable system monitoring and battery protection. The extensive I/O suite, including multiple UART, SPI, and I2C ports, facilitates seamless integration of a wide array of peripherals such as RTK GPS, optical flow sensors, and companion computers, making it a central hub for advanced robotic platforms.

Key Features

  • High-performance STM32F765 flight management unit (FMU) paired with a dedicated STM32F103 I/O processor.
  • Advanced sensor suite featuring ICM-20689 and BMI055/ICM-20602 gyro/accelerometers, an IST8310 magnetometer, and an MS5611 barometer.
  • Integrated vibration isolation system to minimize high-frequency noise for more accurate IMU readings.
  • PM07 Power Module supports 2-14S LiPo input (6-50.4V) and provides high-fidelity current sensing up to 120A.
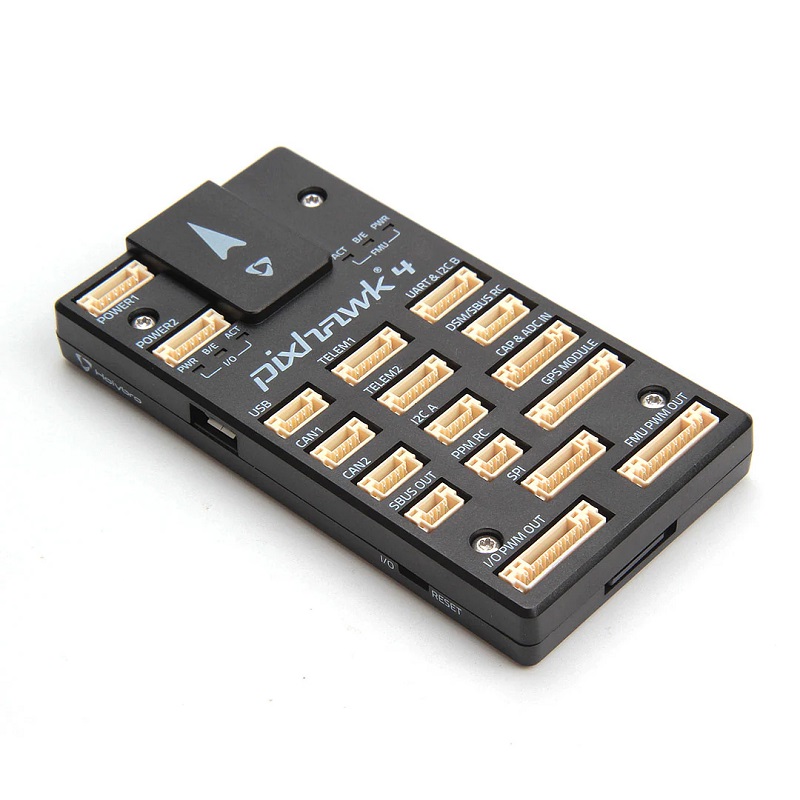
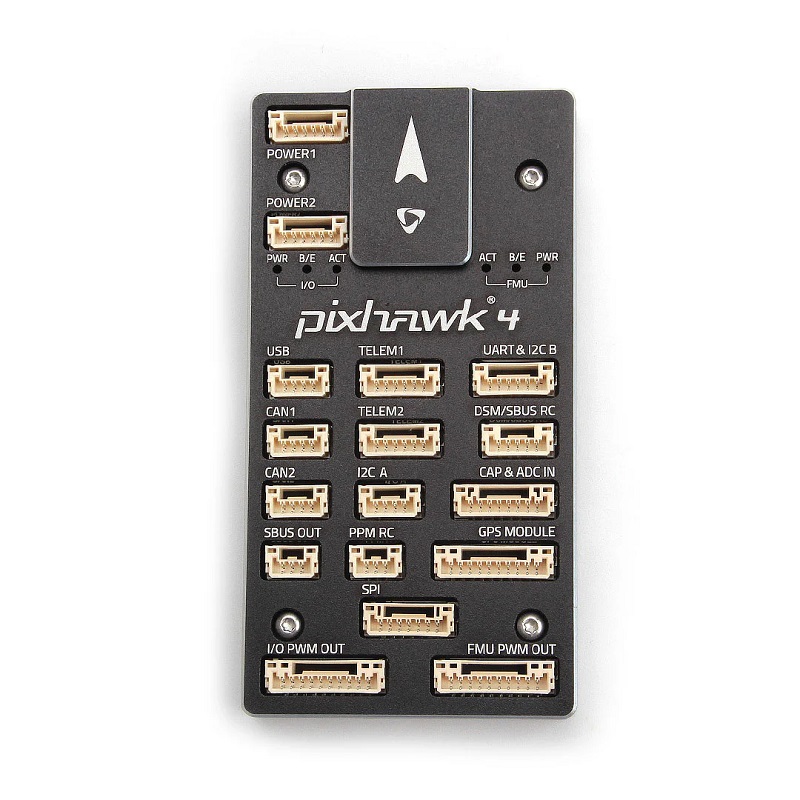
  • Comprehensive connectivity: 2x SPI buses, 4x I2C buses, multiple UARTs, CAN bus, and SBUS/PPM input.
  • Runs the NuttX real-time operating system, fully compatible with open-source ArduPilot and PX4 autopilot firmware.
  • Robust power design with separate 5V regulator for the core system and a 0-36V capable servo rail.
  • Compact form factor (84mm x 44mm) designed for integration into a wide range of multirotor, fixed-wing, and robotic vehicles.

Applications

  • High-endurance mapping and surveying drones requiring precise GPS and sensor fusion.
  • Autonomous cargo and delivery UAVs needing reliable long-range navigation and power monitoring.
  • Research and development platforms for testing advanced computer vision and swarm algorithms.
  • Heavy-lift cinematography drones where stable flight performance is critical.
  • Unmanned ground vehicles (UGVs) and robotic boats requiring robust orientation and position control.

Technical Specifications

Item TypeFlight Controller & Power Module Set
FMU ProcessorSTM32F765
IO ProcessorSTM32F103, STM32F100
Accel/Gyro (Primary)ICM-20689
Accel/Gyro (Secondary)BMI055 / ICM-20602
MagnetometerIST8310
BarometerMS5611
Core Voltage Output4.9 - 5.5V
PM07 Input Voltage2-14S LiPo (6V - 50.4V)
PM07 Max Current Sensing120 A
USB Input Voltage4.75 - 5.25V
Servo Rail Input0 – 36V
Dimensions (L x W)84 mm x 44 mm
Weight (Controller)33.3 g

Frequently Asked Questions

What firmware is compatible with the Holybro Pixhawk 4?

The Holybro Pixhawk 4 is fully compatible with the open-source ArduPilot and PX4 autopilot firmware ecosystems. It comes pre-flashed with a stable version, and you can update it via Mission Planner or QGroundControl. The NuttX RTOS provides a reliable real-time environment for executing complex autonomous flight algorithms.

What is the maximum battery voltage supported by the included PM07 Power Module?

The included PM07 Power Module supports a wide input voltage range from 2S to 14S LiPo batteries, which translates to approximately 6V to 50.4V. It provides accurate voltage and current telemetry back to the flight controller, with a maximum current sensing capability of 120 amps, making it suitable for large multirotors and fixed-wing aircraft.

How does the vibration isolation improve flight performance?

The Pixhawk 4 incorporates a specifically designed vibration isolation system that mechanically decouples the sensitive IMU sensors from high-frequency motor and propeller vibrations. This results in cleaner accelerometer and gyroscope data, which allows the flight control filters to operate more effectively, leading to smoother, more stable flight, especially in aggressive maneuvers or on high-power platforms.

What are the main connectivity options for adding peripherals?

The controller offers extensive I/O for expansion, including two dedicated external SPI buses (with six chip select lines) for high-speed sensors, four I2C buses (two for general use, two grouped with serial ports for GPS/compass), multiple UARTs for telemetry, GPS, and serial peripherals, a CAN bus for additional modules, and standard RC input (SBUS/PPM). This allows for seamless integration of RTK GPS, optical flow, lidar, and companion computers.

Package Includes

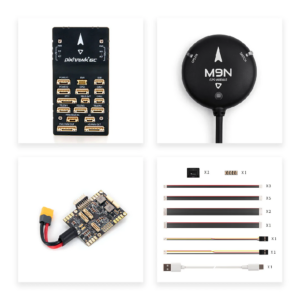
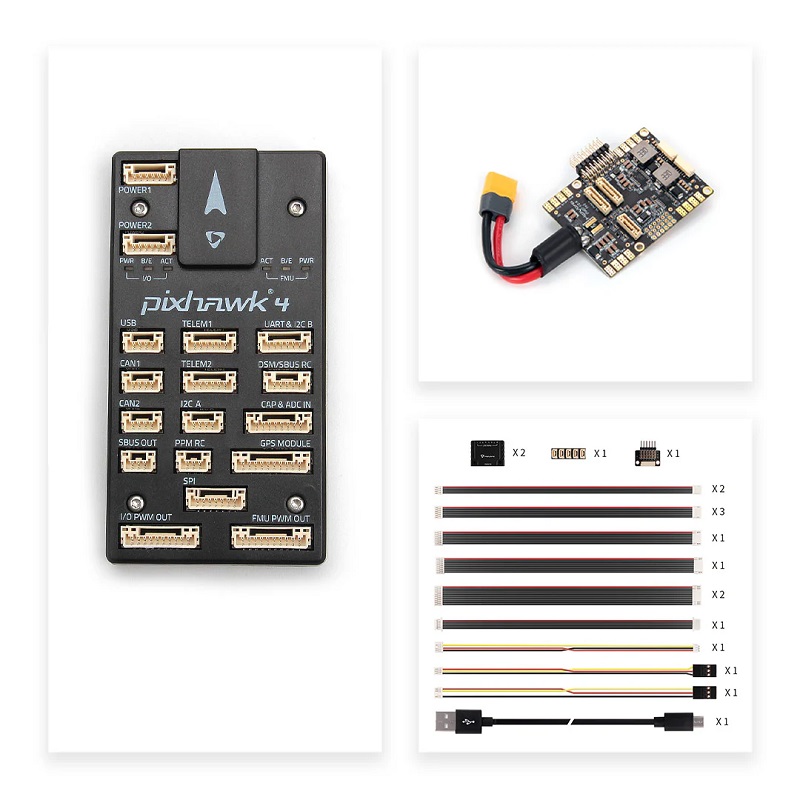
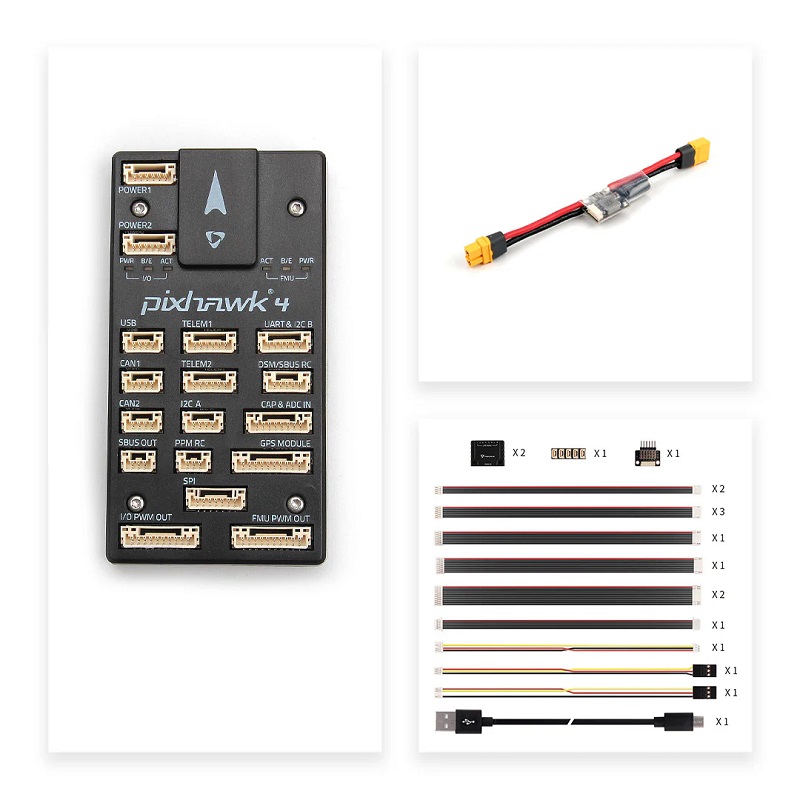
  • 1 x Pixhawk 4 Flight Controller (with plastic case)
  • 1 x PM07 14S Power Module
  • 1 x Cable Set

Additional Information

Weight 0.0333 kg
Dimensions 4.4 × 8.4 cm