SKU: SENS-2924
📋 GST Invoice Available

DFRobot Gravity BMM350 Triple-Axis Magnetometer Sensor - I2C/I3C Interface

₹1,149.00 (Inclusive of all taxes)
Out of Stock

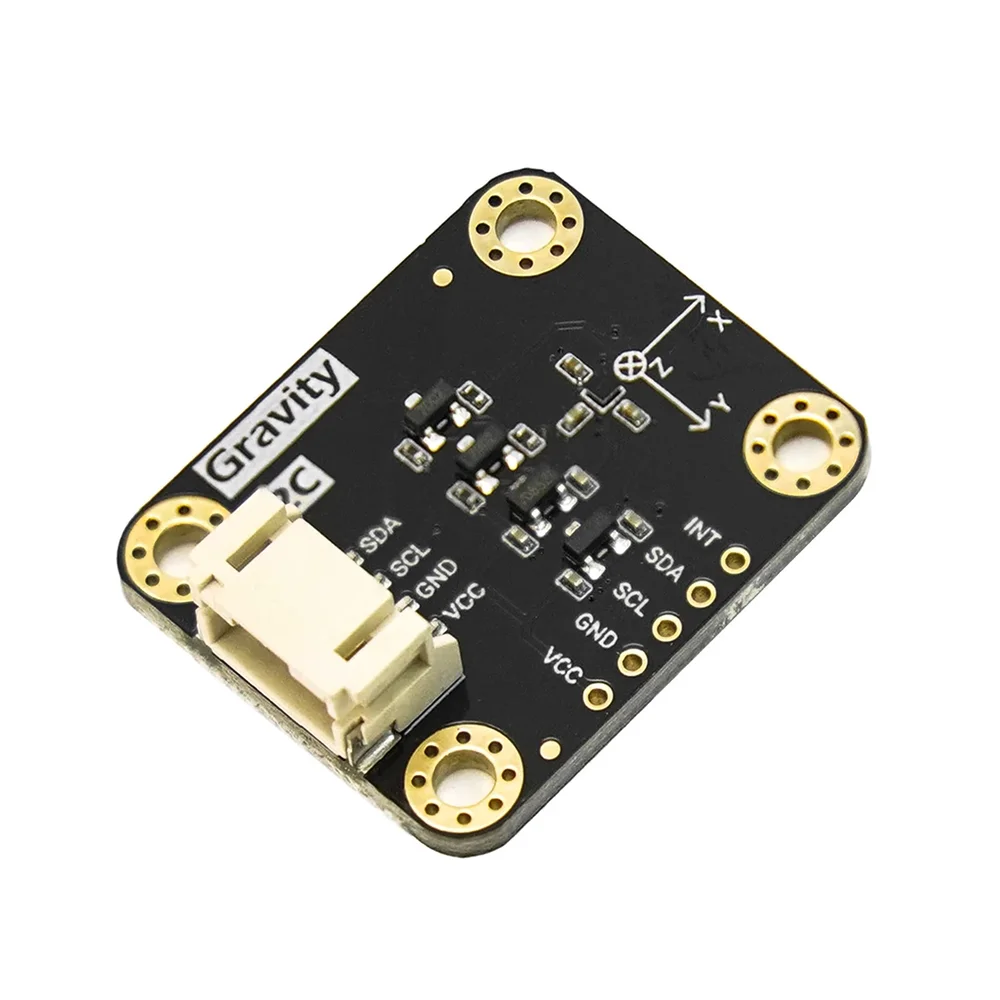
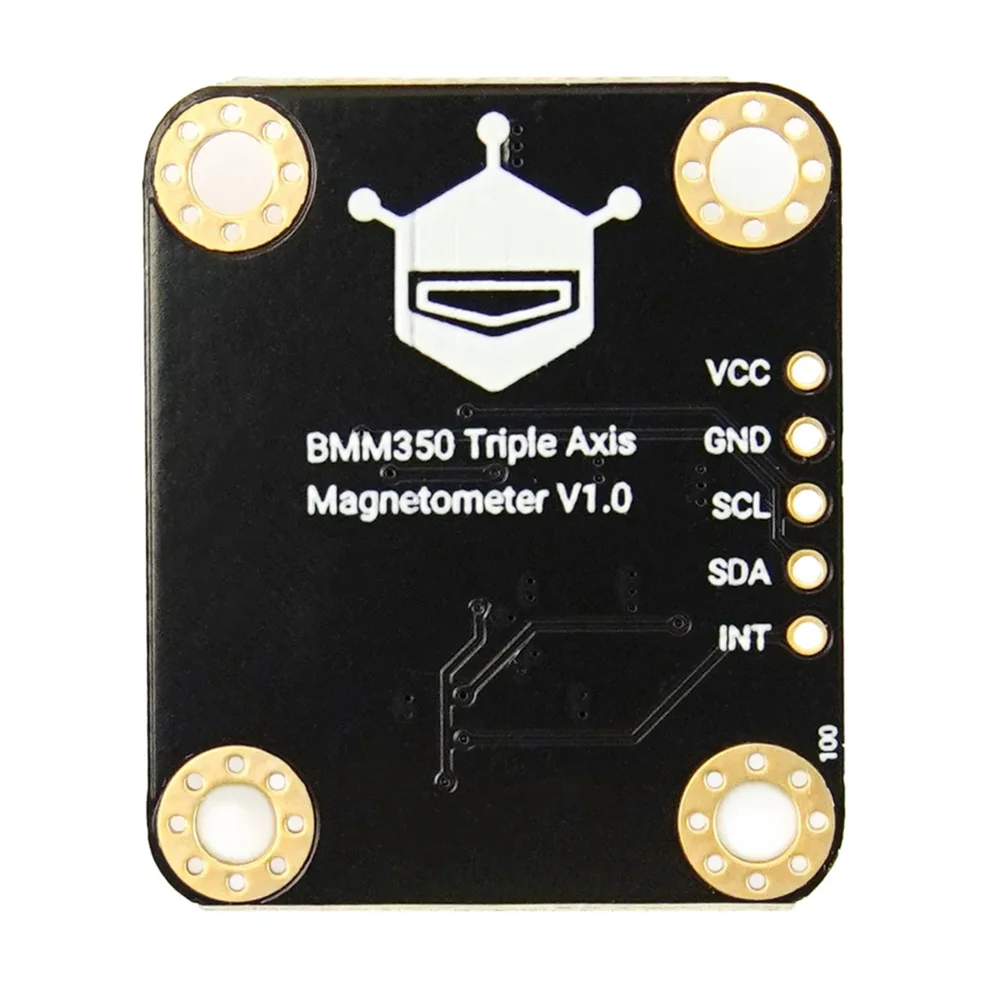
The DFRobot Gravity BMM350 is a high-precision triple-axis geomagnetic sensor module designed for AR/VR, robotics, and navigation systems. It operates on a 3.3-5V DC supply and communicates via I2C or I3C, making it compatible with Arduino, Raspberry Pi, ESP32, and other microcontrollers.

Features

  • High-sensitivity TMR (Tunnel Magneto Resistance) sensor with a ±2000μT measurement range.
  • Integrates FlipCore technology for stable operation, eliminating the need for recalibration.
  • Ultra-low power consumption of 200μA in normal mode, ideal for battery-powered applications.
  • High data sampling rate up to 400Hz with low noise (190nT rms XY-axis).
  • Features Field Shock Recovery for maintaining accuracy in magnetically noisy environments.

Out of stock

Description

The BMM350 magnetometer leverages advanced TMR and FlipCore technologies to deliver precise and stable magnetic field measurements across three axes. This design ensures minimal drift and high immunity to external magnetic interference, providing reliable heading data for navigation and orientation systems.

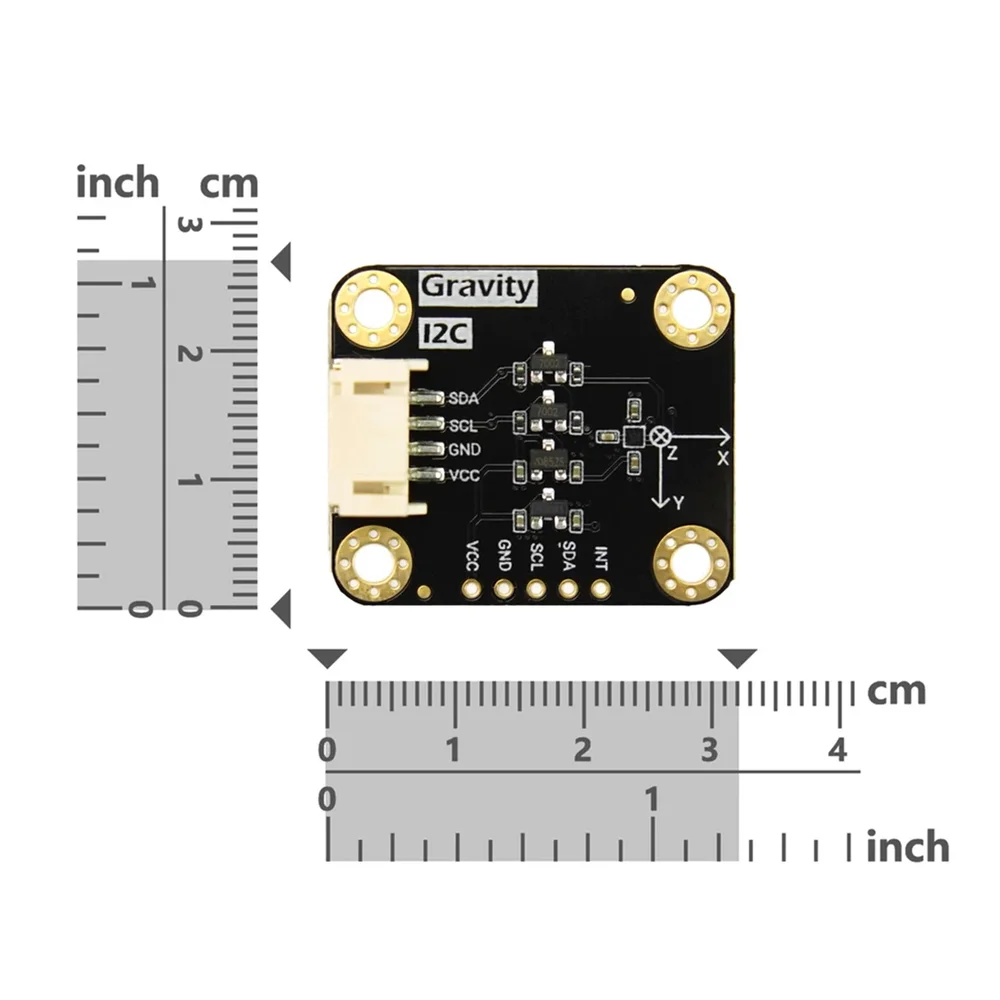
The module includes a programmable interrupt pin for event-driven applications and supports both I2C and the newer I3C communication protocols for fast, efficient data transfer. Its compact form factor and standardized Gravity interface allow for rapid integration into prototyping platforms and embedded systems requiring accurate geomagnetic sensing.

Key Features

  • Triple-axis geomagnetic sensing with a wide ±2000μT full-scale range.
  • FlipCore technology enables zero-offset performance, removing the need for user calibration.
  • Field Shock Recovery feature ensures data consistency even after exposure to strong magnetic fields.
  • Ultra-low noise floor: 190nT RMS on X/Y axes and 450nT RMS on the Z-axis.
  • Supports high-speed I2C and I3C digital communication interfaces.
  • High output data rate configurable up to 400Hz for dynamic motion tracking.
  • Low operating current of 200μA (typical) for energy-sensitive designs.
  • Standard DFRobot Gravity 3-pin interface for plug-and-play compatibility with expansion boards.

Applications

  • Augmented and Virtual Reality (AR/VR) headset orientation and controller tracking.
  • Drone and UAV flight stabilization and electronic compass navigation.
  • Robotic navigation and dead reckoning systems for autonomous platforms.
  • High-accuracy digital compasses for handheld devices and marine navigation.
  • Motion tracking and gesture recognition in interactive systems and wearables.

Technical Specifications

BrandDFRobot
ModelGravity BMM350
Sensor TypeTriple-Axis Magnetometer
Sensing TechnologyTMR (Tunnel Magneto Resistance)
Measurement Range±2000 μT
Noise Density (RMS)190 nT (XY), 450 nT (Z)
Output Data RateUp to 400 Hz
Communication InterfaceI2C, I3C
Operating Voltage3.3 to 5 VDC
Operating Current200 μA (typical)
Key FeatureFlipCore Technology, Field Shock Recovery
ConnectorGravity 3-Pin

Frequently Asked Questions

What is the operating voltage range for the BMM350 sensor?

The DFRobot BMM350 magnetometer module operates from 3.3 to 5 volts DC. This wide range ensures compatibility with most 3.3V and 5V logic microcontroller systems like Arduino, Raspberry Pi, and ESP32 without requiring a level shifter.

Does this sensor require calibration before use?

No, thanks to the integrated FlipCore technology, the BMM350 is factory-trimmed and does not require user calibration for zero-offset error. This provides stable, accurate readings out of the box, even in the presence of moderate magnetic interference.

What communication protocols are supported?

The module supports both the standard I2C (Inter-Integrated Circuit) protocol and the newer I3C (Improved Inter-Integrated Circuit) protocol. This allows for flexible integration and higher-speed data transfer compared to traditional I2C-only sensors.

What is the Field Shock Recovery feature?

Field Shock Recovery is a built-in function that allows the sensor to maintain measurement accuracy after being exposed to strong, sudden magnetic fields. It automatically compensates for temporary saturation, making it suitable for dynamic environments with magnetic noise.

How do I connect this to an Arduino or Raspberry Pi?

Use the standard 3-pin Gravity interface: connect VCC to 3.3V or 5V, GND to ground, and the signal pin (which carries the I2C SDA/SCL lines) to the corresponding I2C pins on your controller. No additional wiring or pull-up resistors are typically required.

Package Includes

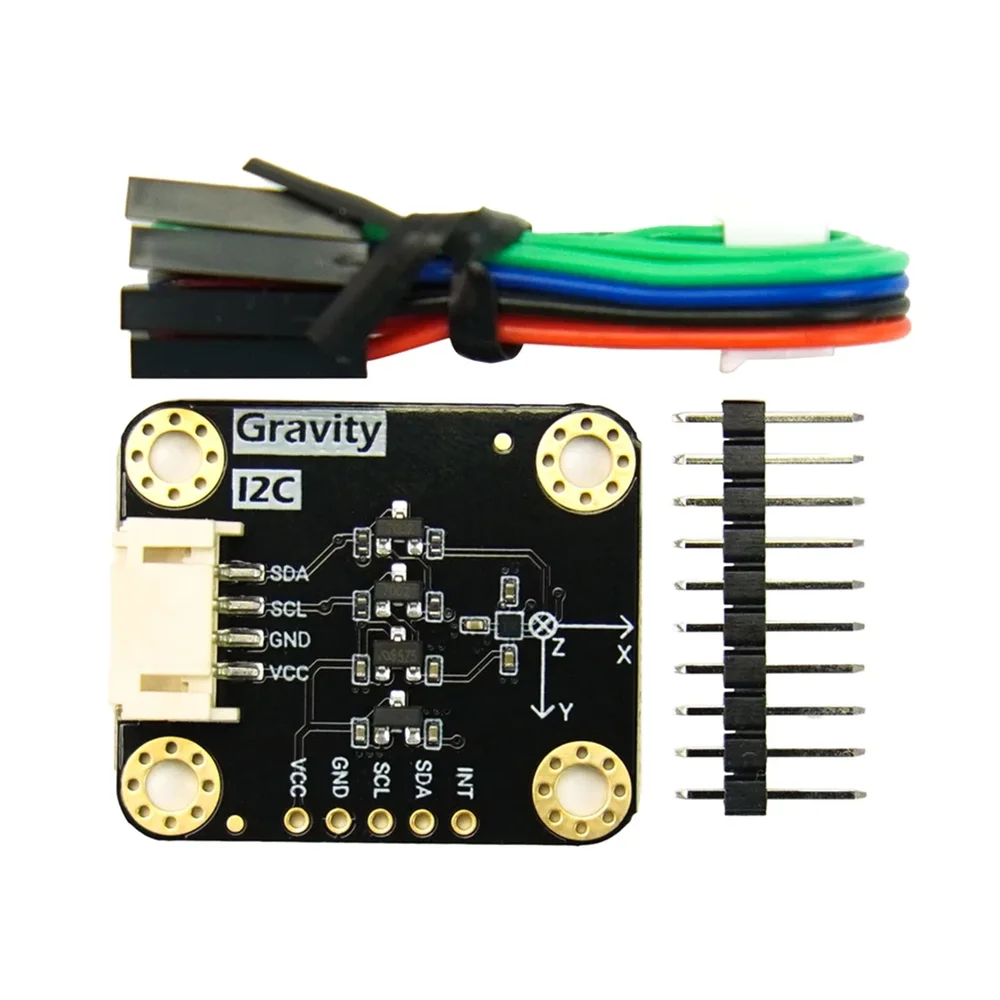
  • 1 x DFRobot Gravity BMM350 Triple-Axis Magnetometer Sensor Module

Additional Information

Weight 0.02 kg
Dimensions 6 × 5 × 2 cm