SKU: IOWC-1296
📋 GST Invoice Available

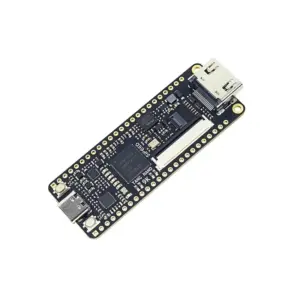
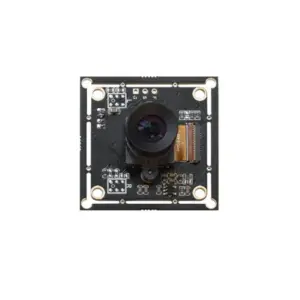
Sipeed Maix I Binocular Camera Module Dual GC0328 30k Pixels

₹1,719.00 (Inclusive of all taxes)
Out of Stock

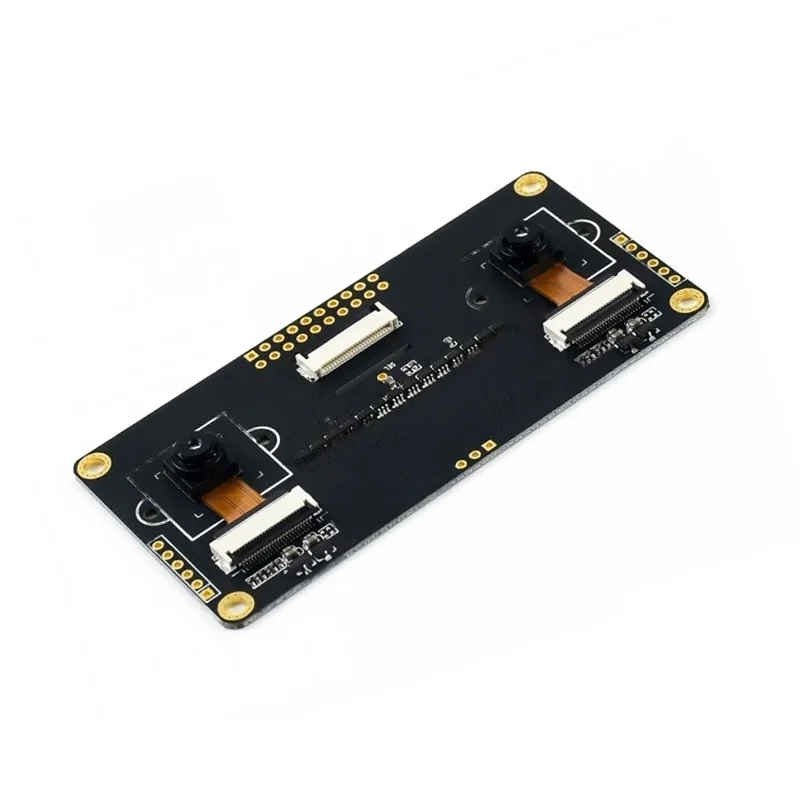
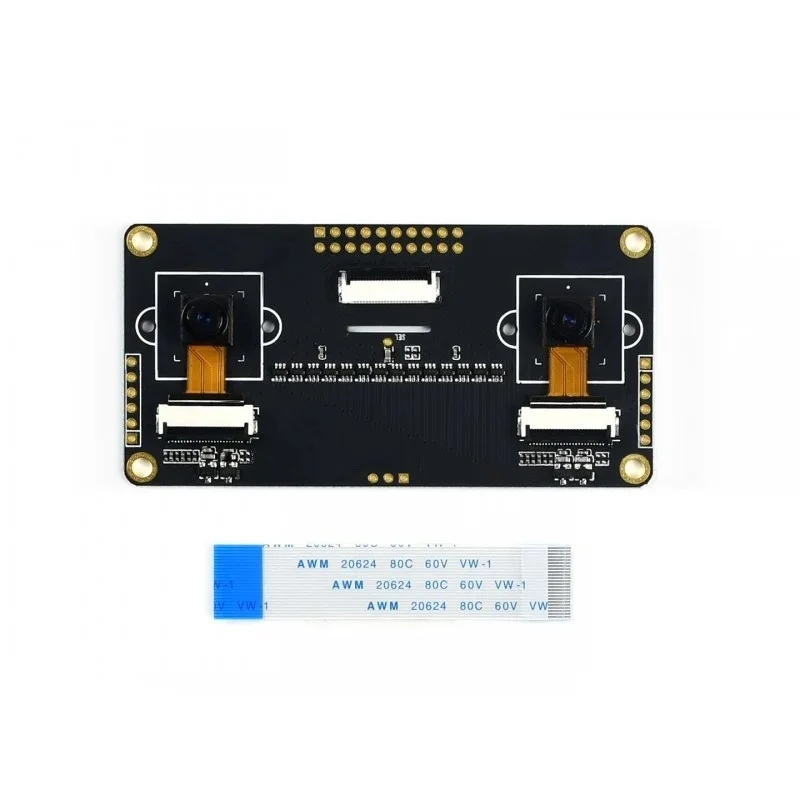
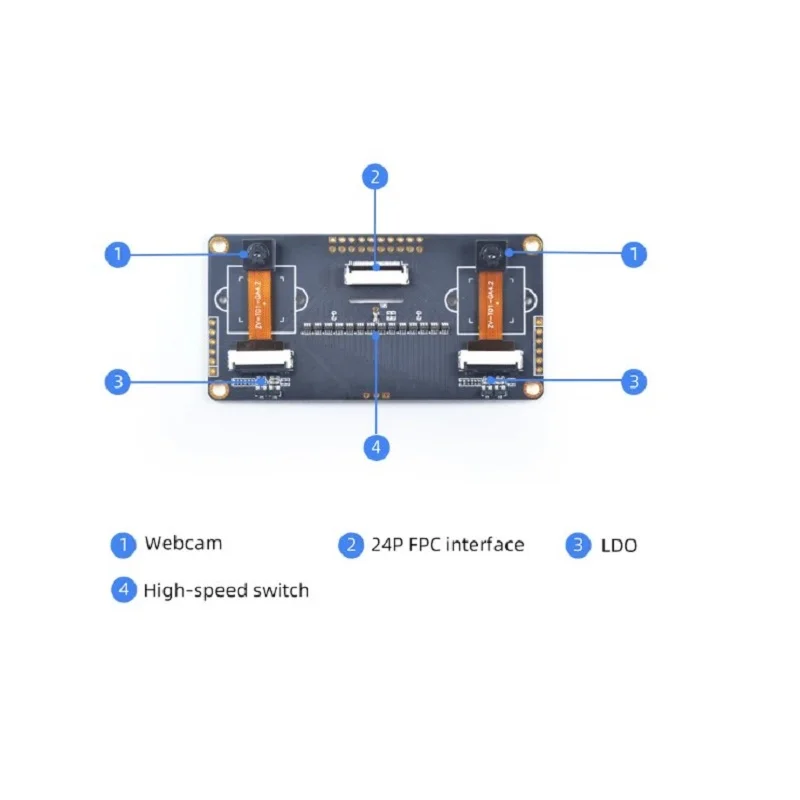
The Sipeed Maix I Binocular Camera Module integrates dual GC0328 30k-pixel sensors for stereo vision and depth perception, designed for AIoT development within the Maix ecosystem using C/C++ or MicroPython.

Features

  • Dual GC0328 30k-pixel sensors enable synchronized stereo vision and depth mapping.
  • Specifically designed for integration with the Maix AIoT ecosystem and development boards.
  • Supports C, C++, and MicroPython for flexible firmware development and machine vision applications.
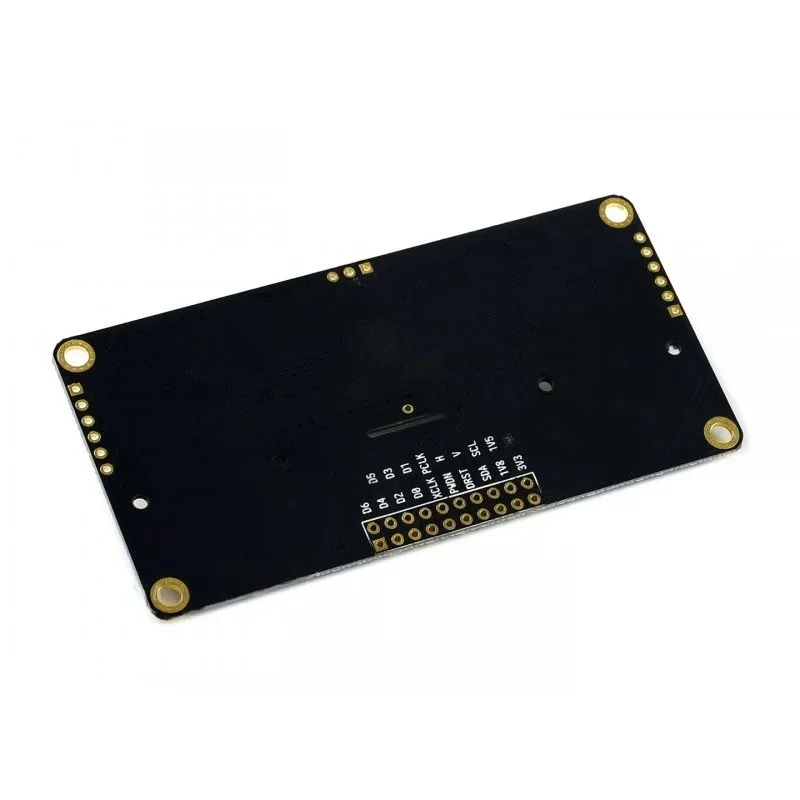
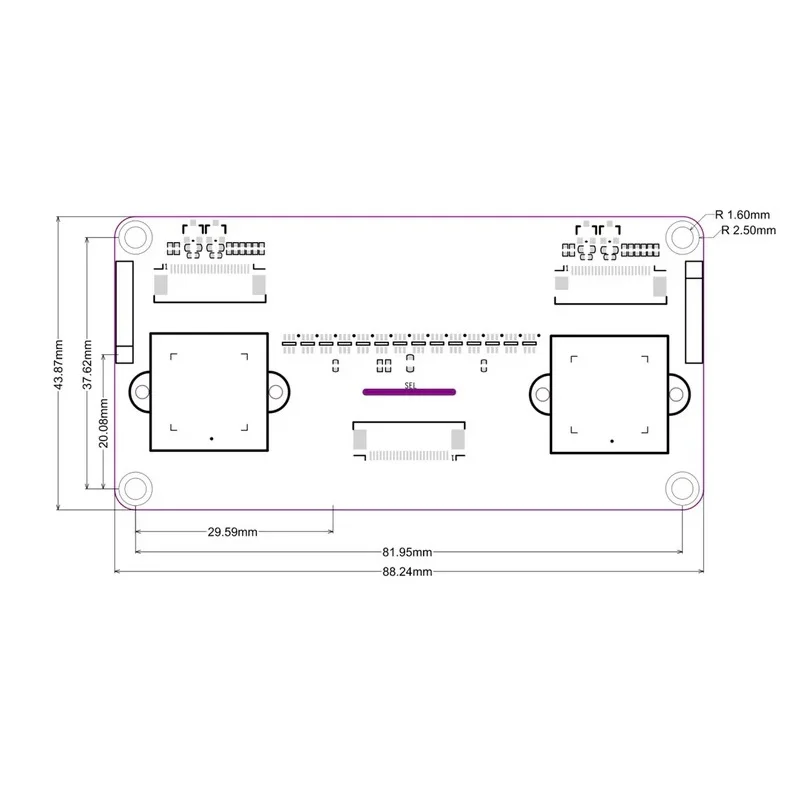
  • Compact 88.2 x 43.8 mm form factor with a 24-pin FPC interface for easy system integration.
  • Dual-voltage operation (3.3V or 1.8V) simplifies power supply design for embedded projects.

Out of stock

Description

The Sipeed Maix I Binocular Camera Module is a specialized vision sensor built for AIoT and edge computing applications requiring depth perception. Its dual GC0328 CMOS sensors capture synchronized image streams, enabling real-time stereo vision algorithms for accurate distance estimation and 3D scene reconstruction.

Engineered for the Maix platform, this module connects seamlessly to compatible AI development boards via its 24-pin FPC connector. It operates on a flexible 3.3V or 1.8V supply, accommodating various embedded power architectures. The module is designed for developers implementing advanced computer vision tasks such as object recognition, gesture control, and robotic navigation within a compact, integrated form factor.

Key Features

  • Dual-camera stereo vision system for depth perception and 3D imaging.
  • Optimized for the Maix AIoT ecosystem, ensuring hardware and software compatibility.
  • Supports multiple programming environments including C, C++, and MicroPython.
  • Synchronized image capture from both sensors for accurate depth calculation.
  • Compact and lightweight design suitable for space-constrained robotics and portable devices.
  • Enables advanced machine vision applications like object recognition and distance estimation.

Applications

  • Robotics and autonomous navigation for obstacle avoidance and mapping.
  • Smart surveillance and security systems with depth-aware monitoring.
  • Industrial automation for machine vision, part inspection, and bin picking.
  • Gesture recognition and human-machine interaction interfaces.
  • AIoT edge devices requiring stereo vision for augmented reality or spatial analysis.

Technical Specifications

SensorDual GC0328 30k-pixel CMOS
Vision CapabilityStereo Vision, Depth Perception, Machine Vision
Supply Voltage3.3V or 1.8V
Interface24-pin FPC
Supported LanguagesC, C++, MicroPython
Operating Temperature0°C to 50°C
Dimensions (L x W)88.2 mm x 43.8 mm
Weight0.015 kg

Frequently Asked Questions

What development environments are supported for programming the Maix I camera module?

The module is supported within the Maix AIoT ecosystem. You can develop firmware using the official MaixPy (MicroPython) SDK, the C/C++ based Kendryte K210 SDK (NNCase, NNCASE-TFLite Micro), or the Arduino core for K210. Development typically involves connecting the module to a compatible Maix Dock or Bit board, installing the necessary toolchain, and writing code to capture and process synchronized stereo image streams for depth mapping or object detection.

How do I connect and power the binocular camera module to my Maix development board?

Connect the module's 24-pin FPC cable to the dedicated camera interface connector on your Maix board (e.g., Maix Dock, Maix Bit). Ensure the connection is secure and the latch is closed. Power the module by supplying either 3.3V or 1.8V to the appropriate power pins on the FPC interface, as defined in the Maix I pinout diagram. The voltage selection must match your board's camera port output or be regulated externally. Always power down the system before connecting or disconnecting the FPC cable.

What is the typical workflow for capturing depth data with this module?

First, initialize both GC0328 sensors via the camera driver (e.g., using `sensor.snapshot()` in MaixPy). The SDK handles synchronization. Capture left and right image frames simultaneously. Apply a stereo vision algorithm, such as block matching or Semi-Global Matching (SGM), to compute a disparity map from the two images. Calibrate your camera pair beforehand using a checkerboard pattern to obtain intrinsic and extrinsic parameters for accurate depth calculation. Finally, convert disparity values to real-world depth measurements using the triangulation formula based on your calibrated baseline distance.

Package Includes

  • 1 x Sipeed Maix I Binocular Camera Module

Additional Information

Weight 0.015 kg
Dimensions 8.82 × 4.38 cm