SKU: DRFC-1889
📋 GST Invoice Available

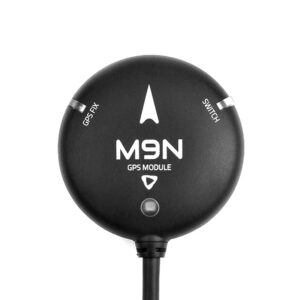
Holybro Pixhawk 5X Mini Set with M10 GPS

₹39,739.00 (Inclusive of all taxes)
Out of Stock

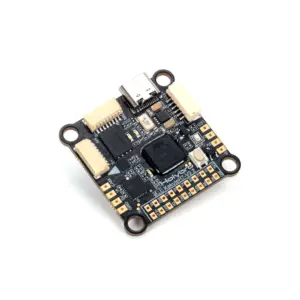
The Holybro Pixhawk 5X Mini Set is a professional-grade flight controller system based on the Pixhawk FMUv5X open standard, featuring triple-redundant IMUs, dual barometers, and an STM32F7 processor for robust autonomous vehicle control. It is fully compatible with PX4 and ArduPilot firmware and includes an M10 GPS module and HV power module.

Features

  • Triple-redundant, low-noise IMUs (ICM-20649, ICM-42688P, ICM-20602/BMI088) for enhanced stabilization and failover.
  • Dual BMP388 barometers and independent power control (LDOs) for each sensor set, ensuring reliability.
  • STM32F7 microcontroller with 2MB flash and 512KB RAM for complex autonomous algorithms.
  • Integrated SPI5 external sensor bus with dual chip select and Ethernet PHY for mission computer communication.
  • Dual SMBus smart battery ports with INA226 support for advanced power monitoring.

Out of stock

Description

The Pixhawk 5X represents the latest evolution in the Pixhawk family, engineered to the FMUv5X and Pixhawk Autopilot Bus standards. Its core is a powerful STM32F7 processor paired with Bosch and InvenSense sensor technology, delivering the computational power and precision required for demanding academic and commercial UAV applications. The system’s architecture prioritizes sensor integrity through advanced vibration isolation and independent power domains.

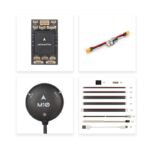
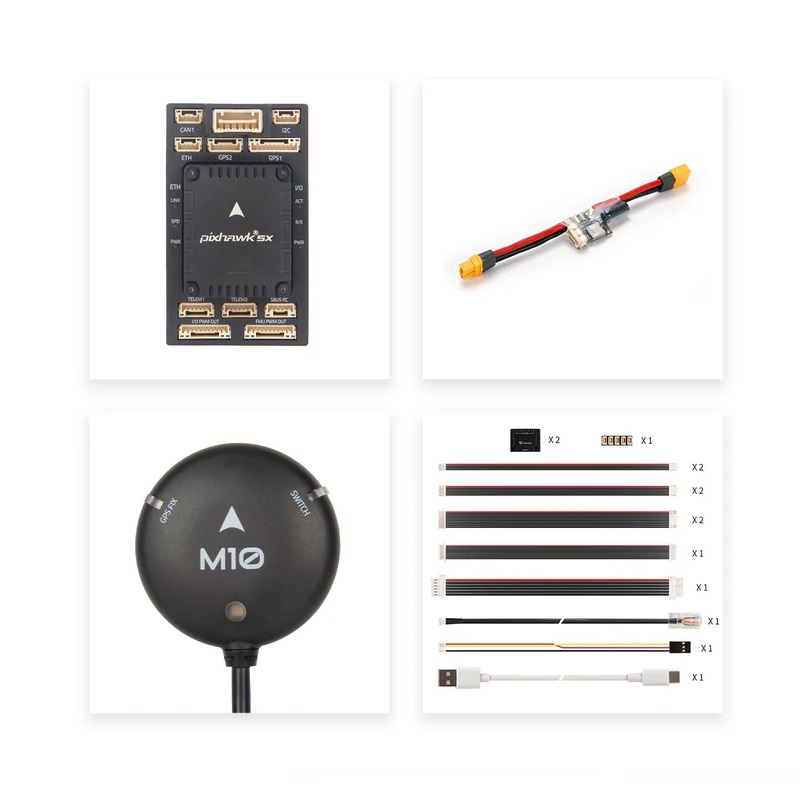
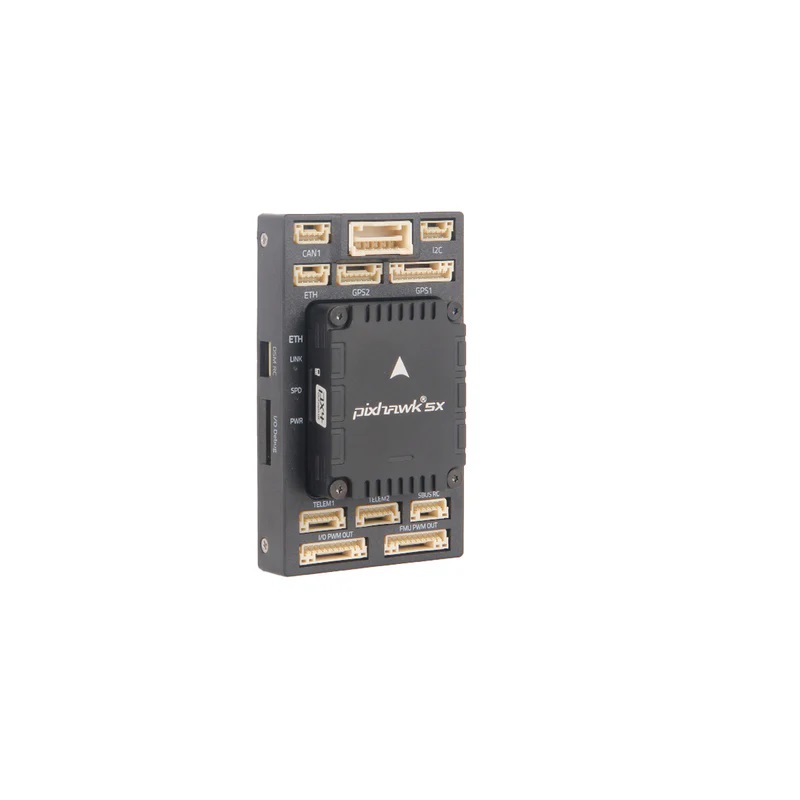
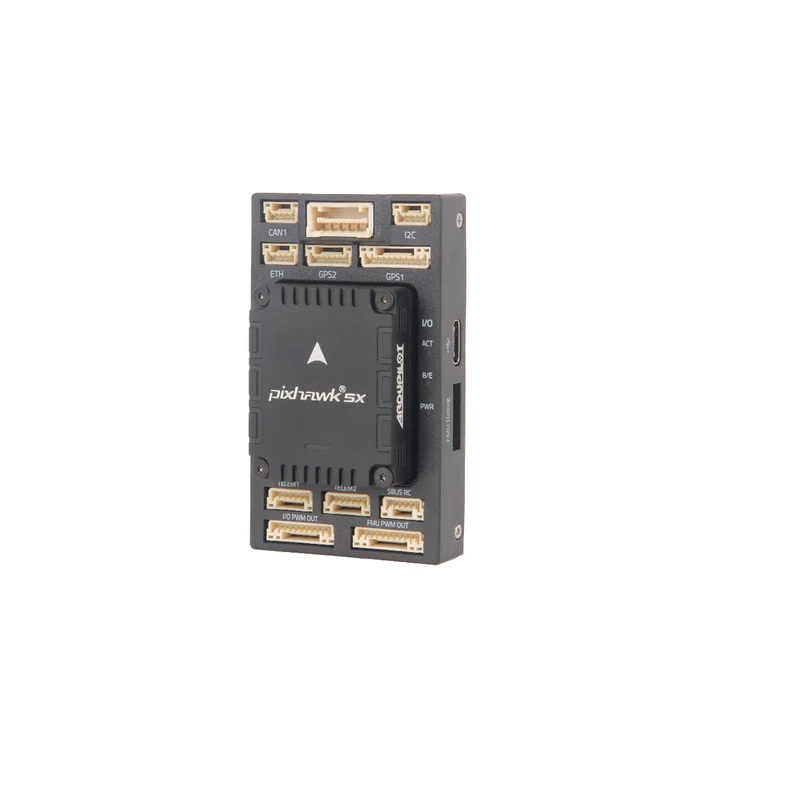
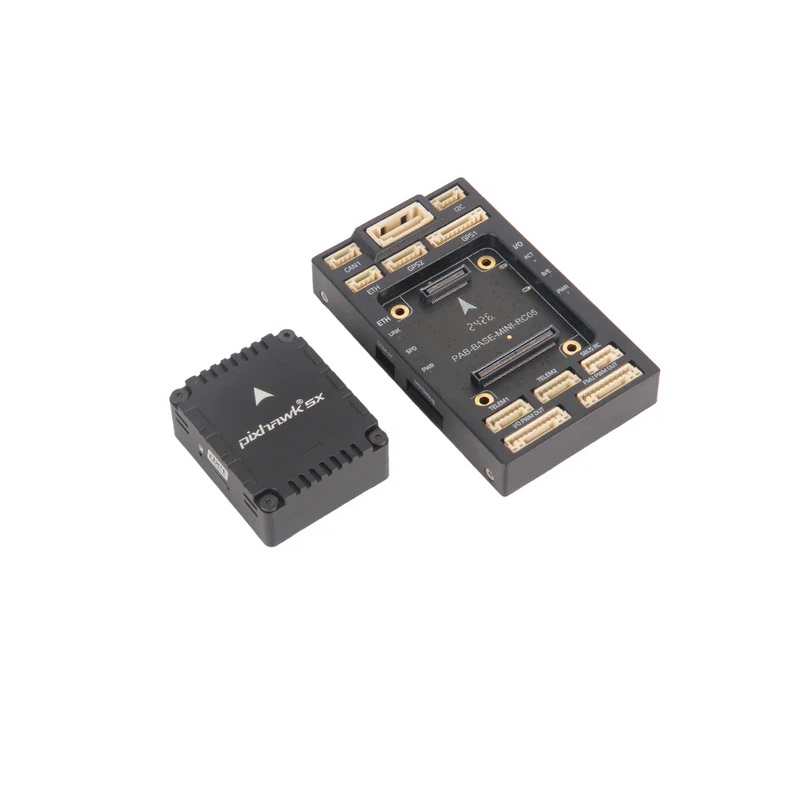
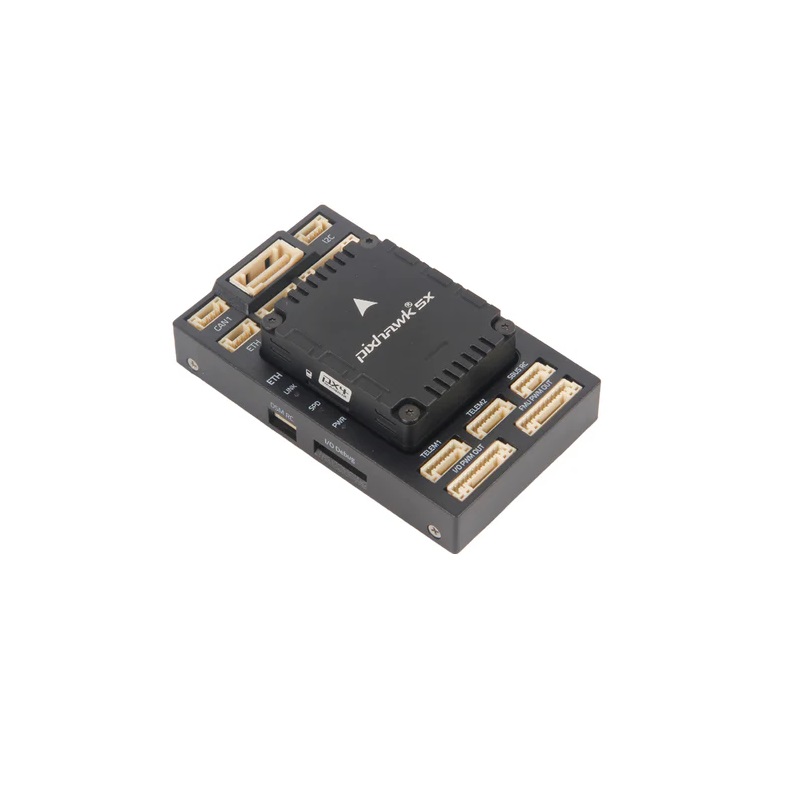
This Mini Set configuration includes the core flight controller module paired with a dedicated baseboard, an HV power module (PM02D), and a high-precision M10 GPS. The inclusion of an Ethernet PHY (LAN8742AI-CZ-TR) facilitates high-bandwidth communication with companion computers, enabling real-time data processing for advanced autonomy. The design supports a wide input voltage range on the servo rail, making it suitable for various multirotor and fixed-wing platforms.

Key Features

  • Triple-redundant inertial measurement units provide seamless sensor failover for critical flight stability.
  • Advanced mechanical and digital vibration damping ensures accurate sensor readings in high-vibration environments.
  • Independent low-dropout regulators (LDOs) power each sensor set, preventing noise cross-talk.
  • SPI5 bus with dual chip select lines offers flexible expansion for external sensors like optical flow or lidar.
  • Integrated Microchip Technology LAN8742AI-CZ-TR Ethernet PHY enables high-speed networking to ground stations or onboard mission computers.
  • Dual smart battery ports support SMBus communication and INA226 current/voltage monitoring chips.
  • Wide servo rail input voltage (0-36V) accommodates a broad range of power systems and servo types.
  • Pre-loaded with the latest PX4 Autopilot software and fully compatible with ArduPilot.

Applications

  • Advanced academic research platforms requiring robust sensor redundancy and data logging.
  • Commercial inspection and mapping drones where flight reliability and precision navigation are critical.
  • Heavy-lift and agricultural UAVs that benefit from the wide voltage servo rail and Ethernet connectivity.
  • Autonomous vehicle development integrating companion computers for complex algorithm execution.
  • Fixed-wing and VTOL (Vertical Take-Off and Landing) aircraft utilizing the full suite of navigation sensors.

Technical Specifications

Model / NamePixhawk 5X Mini
Core ProcessorSTM32F7
Memory2MB Flash, 512KB RAM
IMU 1 (Accel/Gyro)ICM-20649
IMU 2 (Accel/Gyro)ICM-42688P
IMU 3 (Accel/Gyro)ICM-20602 or BMI088
MagnetometerBMM150
Barometer2x BMP388
Main Input Voltage4.75V - 5.25V
USB Input Voltage4.75V - 5.25V
Servo Rail Input Voltage0V - 36V
External Sensor BusSPI5 with dual chip select
Ethernet PHYMicrochip Technology LAN8742AI-CZ-TR
Battery Ports2x SMBus with INA226 support
Firmware CompatibilityPX4, ArduPilot

Frequently Asked Questions

What is the main processor in the Pixhawk 5X, and what are its advantages?

The Pixhawk 5X uses an STM32F7 microcontroller featuring 2MB of flash memory and 512KB of RAM. This provides significantly increased processing power over previous generations, allowing the PX4 or ArduPilot firmware to run more complex navigation algorithms, handle higher sensor data rates, and support advanced features like real-time computer vision integration via the onboard Ethernet port.

How does the triple-redundant IMU system work, and why is it important?

The system incorporates three separate IMU chips (ICM-20649, ICM-42688P, and ICM-20602/BMI088). The flight software continuously compares data from all three. If one sensor provides anomalous readings, it is automatically voted out, and the system seamlessly fails over to the remaining healthy sensors. This is critical for safety in commercial and autonomous applications, preventing a single sensor failure from causing a crash.

What is the purpose of the SPI5 external sensor bus?

The SPI5 bus, with its dual chip select lines and data-ready signals, is designed for connecting external, high-bandwidth sensors. This allows you to add specialized peripherals like optical flow sensors, laser rangefinders (LiDAR), or additional GNSS modules directly to the flight controller's dedicated sensor bus, ensuring low-latency communication essential for precise autonomous navigation and obstacle avoidance.

Can I power servos directly from the Pixhawk 5X Mini baseboard?

Yes, the servo rail on the included baseboard accepts a wide input voltage range of 0-36V. This voltage is passed directly to the servo outputs (typically pins labeled PWM or S#). It is crucial to ensure your chosen servos are compatible with the voltage you supply to this rail, which is separate from the low-voltage (5V) logic power supplied to the flight controller module itself.

Package Includes

  • 1 x Pixhawk 5X Flight Controller Module
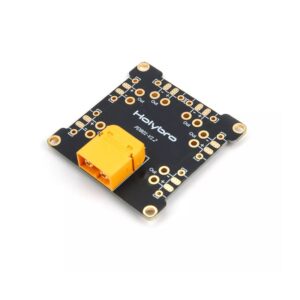
  • 1 x Standard Baseboard Mini Baseboard
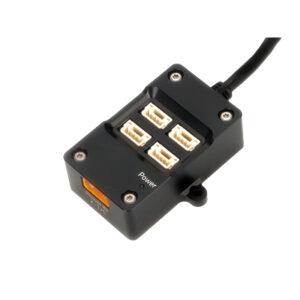
  • 1 x PM02D HV Power Module
  • 1 x Cable Set
  • 1 x M10 GPS Module

Additional Information

Weight 0.302 kg
Dimensions 14 × 10 × 7 cm