SKU: DRFC-1802
📋 GST Invoice Available

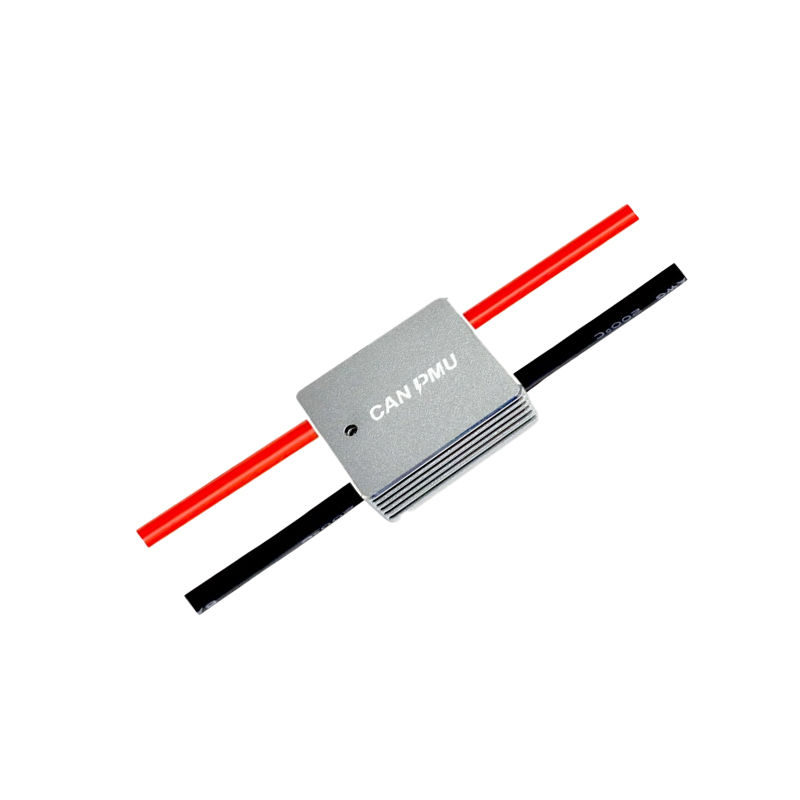
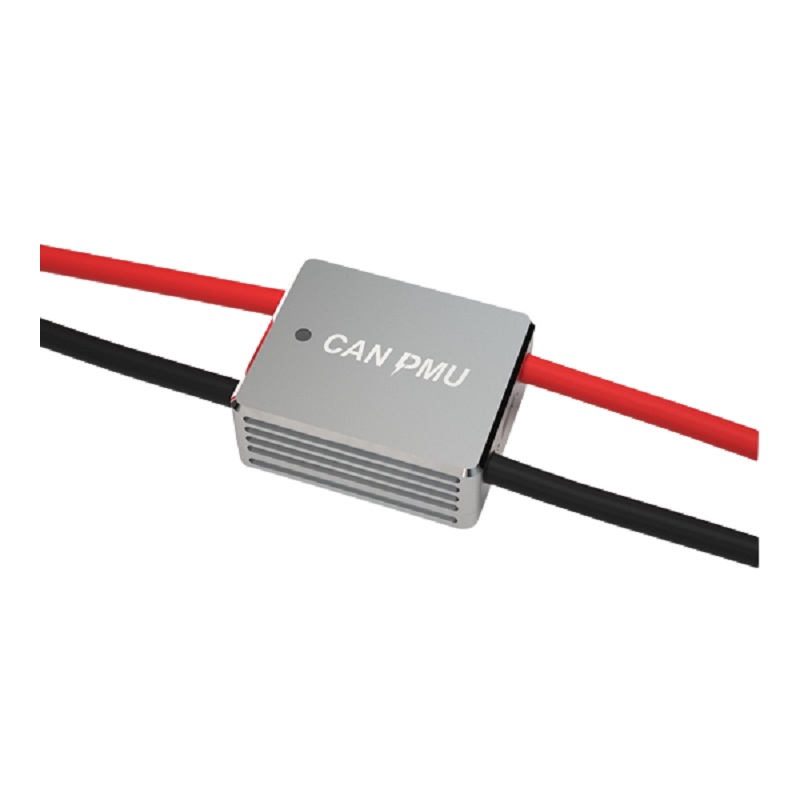
CUAV CAN PMU Autopilot Power Module

₹14,469.00 (Inclusive of all taxes)
Out of Stock

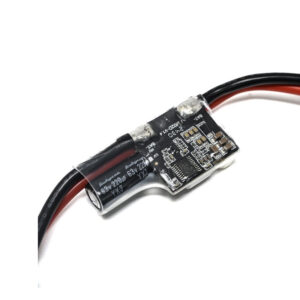
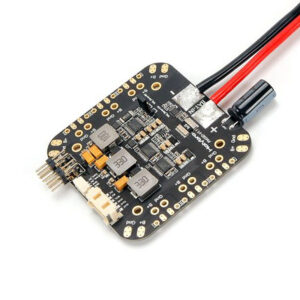
The CUAV CAN PMU is a high-precision power management module for UAV autopilot systems, featuring an integrated STM32F412 processor and UAVCAN protocol support for accurate voltage and current telemetry. It accepts a wide 6-62V input range and provides a regulated 5V/8A output for powering flight controllers and peripherals.

Features

  • High-precision STM32F412 processor running CUAV ITT compensation algorithm for accurate voltage/current measurement.
  • Wide input voltage range from 6V to 62V, supporting up to 110A max current for robust multirotor and VTOL applications.
  • Integrated UAVCAN protocol over CAN bus for seamless, noise-resistant communication with modern autopilots like Pixhawk.
  • Factory-calibrated for high consistency, featuring ±0.05V voltage accuracy and ±0.1A current accuracy.
  • Provides a stable 5V/8A power output via its dedicated POWER port for powering flight controllers and onboard electronics.

Out of stock

Description

The CUAV CAN PMU Autopilot Power Module is engineered for professional UAV platforms requiring reliable power distribution and precise energy monitoring. Its core is built around an STM32F412 microcontroller, which executes a proprietary ITT compensation algorithm to deliver highly accurate real-time telemetry for battery voltage and system current draw, critical for mission planning and battery safety.

Designed for integration into CAN bus-based drone ecosystems, it communicates via the standard UAVCAN protocol, ensuring low-noise data transmission and compatibility with autopilots like the CUAV X7, Pixhawk 6X, and Holybro Kakute series. The module’s robust construction supports a massive 6-62V input range, making it suitable for high-voltage 12S LiPo setups, while its high-current 110A capability ensures it can handle demanding propulsion systems.

Key Features

  • STM32F412 processor enables high-resolution (0.01A/V) telemetry sampling and onboard data processing.
  • Ultra-wide 6-62V DC input range compatible with 2S to 12S LiPo and Li-ion battery configurations.
  • High-current handling up to 110A maximum, with stable continuous power delivery up to 5000W.
  • UAVCAN protocol support provides a robust, daisy-chainable communication bus for scalable drone architectures.
  • Factory-level calibration ensures excellent unit-to-unit consistency and high measurement accuracy (±0.05V, ±0.1A).
  • Integrated 5V/8A BEC output powers the flight controller and auxiliary devices without requiring a separate regulator.
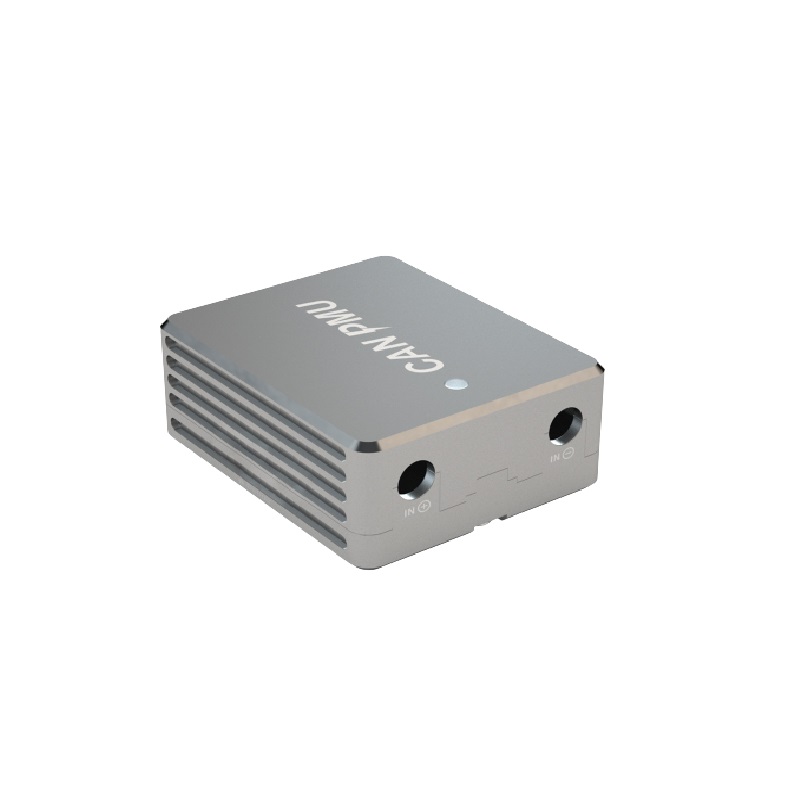
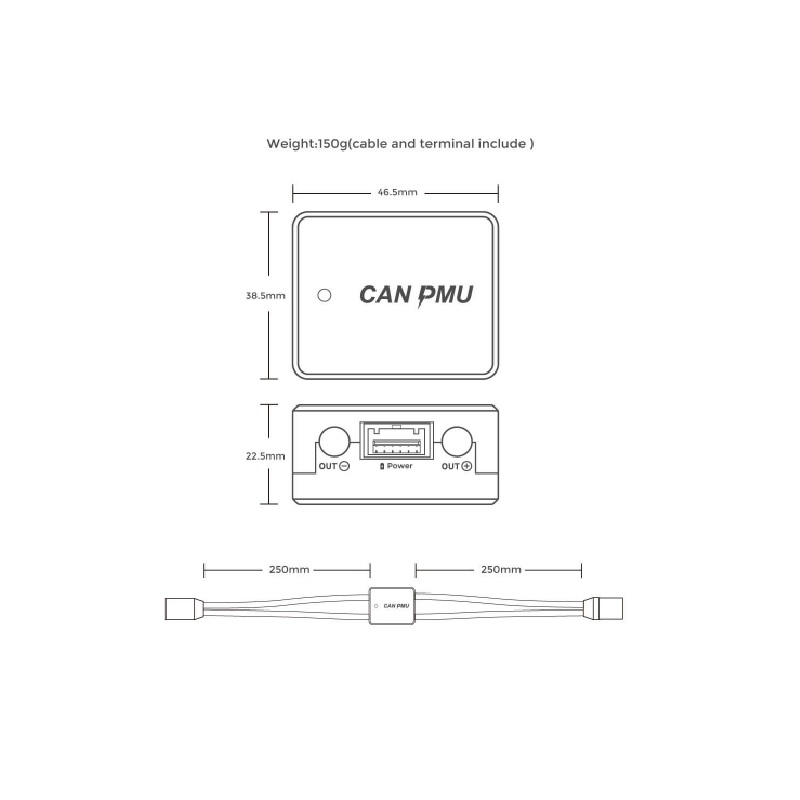
  • Compact and lightweight aluminum housing (46.5x38.5mm, 76g) designed for easy integration into tight airframes.
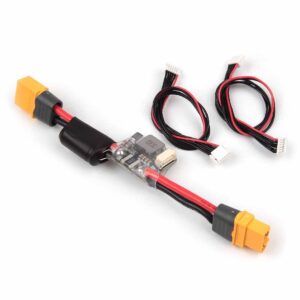
  • Standard XT90 power connectors and GHR-04V-S CAN interface facilitate reliable, solder-free connections.

Applications

  • Power management and telemetry for high-voltage, long-endurance VTOL (Vertical Take-Off and Landing) drones.
  • Integration into CUAV X7 or Pixhawk 6X-based autopilot systems for professional mapping and surveying UAVs.
  • Heavy-lift and industrial drone platforms requiring precise battery monitoring and robust 12S LiPo power distribution.
  • CAN bus-based drone architectures where reliable, daisy-chained power and data communication are essential.
  • Research and development UAVs needing accurate, real-time power consumption data logging via UAVCAN.

Technical Specifications

Item TypeModule
ProcessorSTM32F412
Input Voltage6 to 62 V
Max Current110 A
Resolution0.01A/V
Output Voltage Accuracy±0.05
Current Accuracy±0.1 A
Power Port Output5.4V/5A
Max Power Output6000 W
Max Stable Power5000 W
ProtocolUAVCAN
Firmware UpgradeSupported
Interface TypeIN/OUT: XT90 (Cable), Power: 5025850670, CAN: GHR-04V-S
Length46.5 mm
Width38.5 mm
Weight76 g

Frequently Asked Questions

What is the primary function of the CUAV CAN PMU module?

The CUAV CAN PMU serves as a precision power management and telemetry unit for drone autopilots. Its core functions are to accurately measure the system's bus voltage and total current draw using its STM32F412 processor, distribute high-power to ESCs, and provide a clean 5V rail for the flight controller, all while communicating this data back to the autopilot via the noise-resistant UAVCAN protocol.

What autopilots and flight controllers is this PMU compatible with?

This module is designed for seamless integration with any autopilot supporting the UAVCAN protocol. This includes modern flight controllers like the CUAV X7 series, Pixhawk 6X, Holybro Kakute F7, and other ArduPilot or PX4-based systems with a CAN bus interface. It connects directly via its dedicated GHR-04V-S CAN port.

What is the maximum battery configuration (cell count) this module supports?

The module supports an exceptionally wide input range of 6V to 62V. This covers standard LiPo configurations from 2S (7.4V) up to 12S (50.4V), making it suitable for everything from lightweight builds to high-voltage, heavy-lift industrial drones. Always ensure your battery voltage stays within this 6-62V operational window.

How do I connect the CUAV CAN PMU to my drone's power system and flight controller?

Connect your main battery leads (XT90 connectors) to the PMU's INPUT ports. The OUTPUT ports then feed power to your ESCs. Use the included power cable to connect the PMU's 5V POWER port to your flight controller's main power input. Finally, connect the PMU's CAN port to your flight controller's CAN bus port using a standard 4-pin JST-GH cable to enable telemetry data transmission.

Package Includes

  • 1 x CUAV CAN PMU Autopilot Power Module
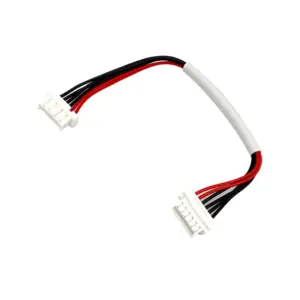
  • 1 x X7 Series Power Cable
  • 1 x V5 Series Power Cable

Additional Information

Weight 0.076 kg
Dimensions 4.65 × 3.85 cm