Arducam Time of Flight Camera for Raspberry Pi
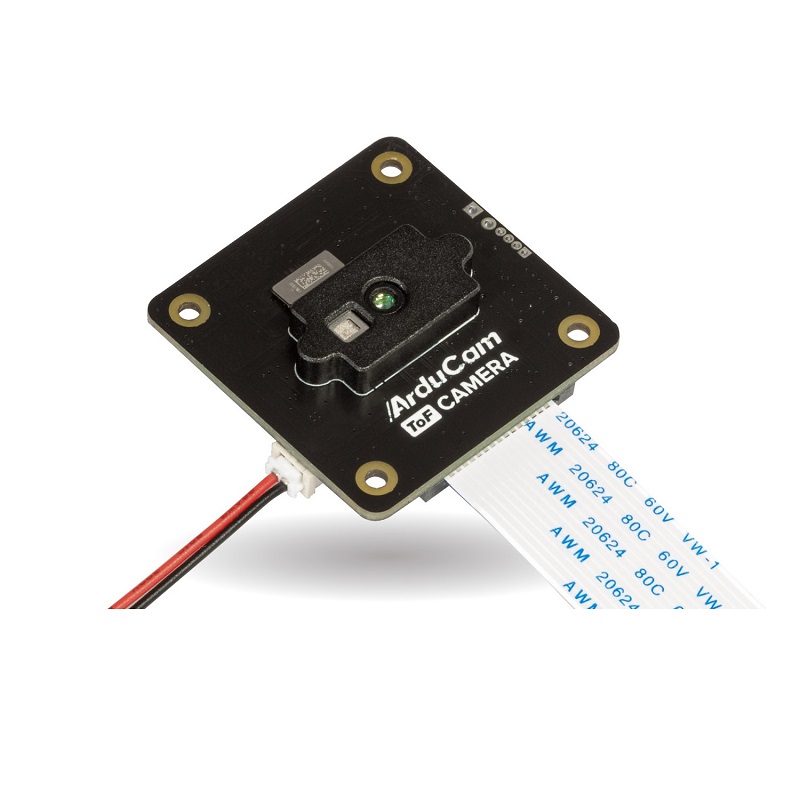
The Arducam Time of Flight Camera is a depth-sensing module designed for Raspberry Pi, providing real-time 3D imaging and distance measurement for advanced computer vision applications in UAV payloads and ground-based robotics.
Features
- Delivers 240×180 depth resolution with a 70° diagonal field of view for spatial mapping.
- Features a 940nm VCSEL illuminator supporting both near (2m) and far (4m) measurement modes.
- Operates via a 2-lane MIPI interface, outputting raw phase, depth, and grayscale amplitude frames.
- Optimized for Raspberry Pi OS Bullseye, achieving up to 30 fps on Pi 4 and CM4 platforms.
- Requires a robust 5V/4A power supply, with a typical power draw of 3.5W.
Out of stock
The Arducam Time of Flight (ToF) Camera utilizes a continuous-wave (CW) modulation method, emitting 940nm light and calculating distance based on the time-of-flight principle (d=C/2f). This enables the capture of per-pixel depth data (X, Y, Z coordinates), transforming 2D imaging into actionable 3D spatial information. The module is engineered for integration with Raspberry Pi single-board computers, providing a streamlined solution for edge-based computer vision tasks.
With a maximum sensor frame rate of 120 fps and configurable modulation frequencies of 75MHz or 37.5MHz, the camera offers flexibility for balancing precision and speed. Its compact form factor and MIPI interface make it suitable for embedded systems where size and data throughput are critical, such as in drone-based inspection, obstacle avoidance, or automated guided vehicle (AGV) navigation payloads.
Additional Information
| Weight | 0.016 kg |
|---|---|
| Dimensions | 5 × 7 × 2 cm |