CUAV Pixhawk V6X V2 Flight Controller
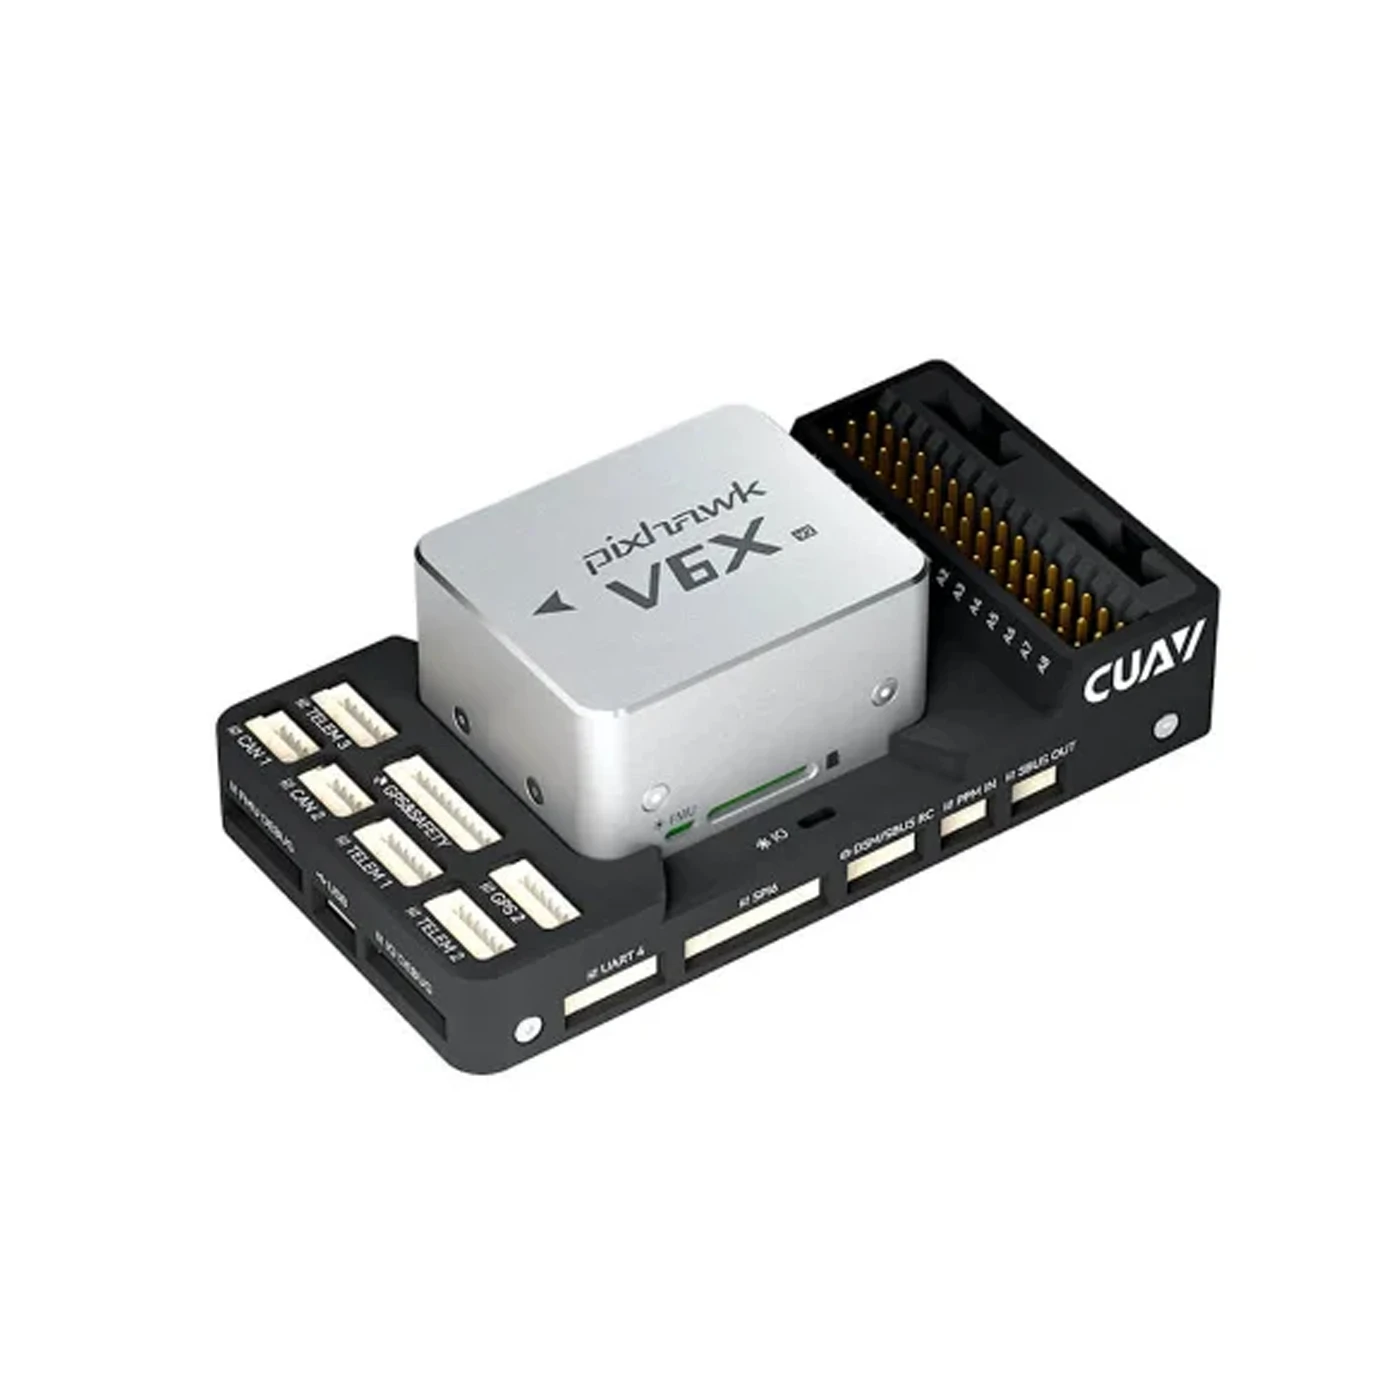
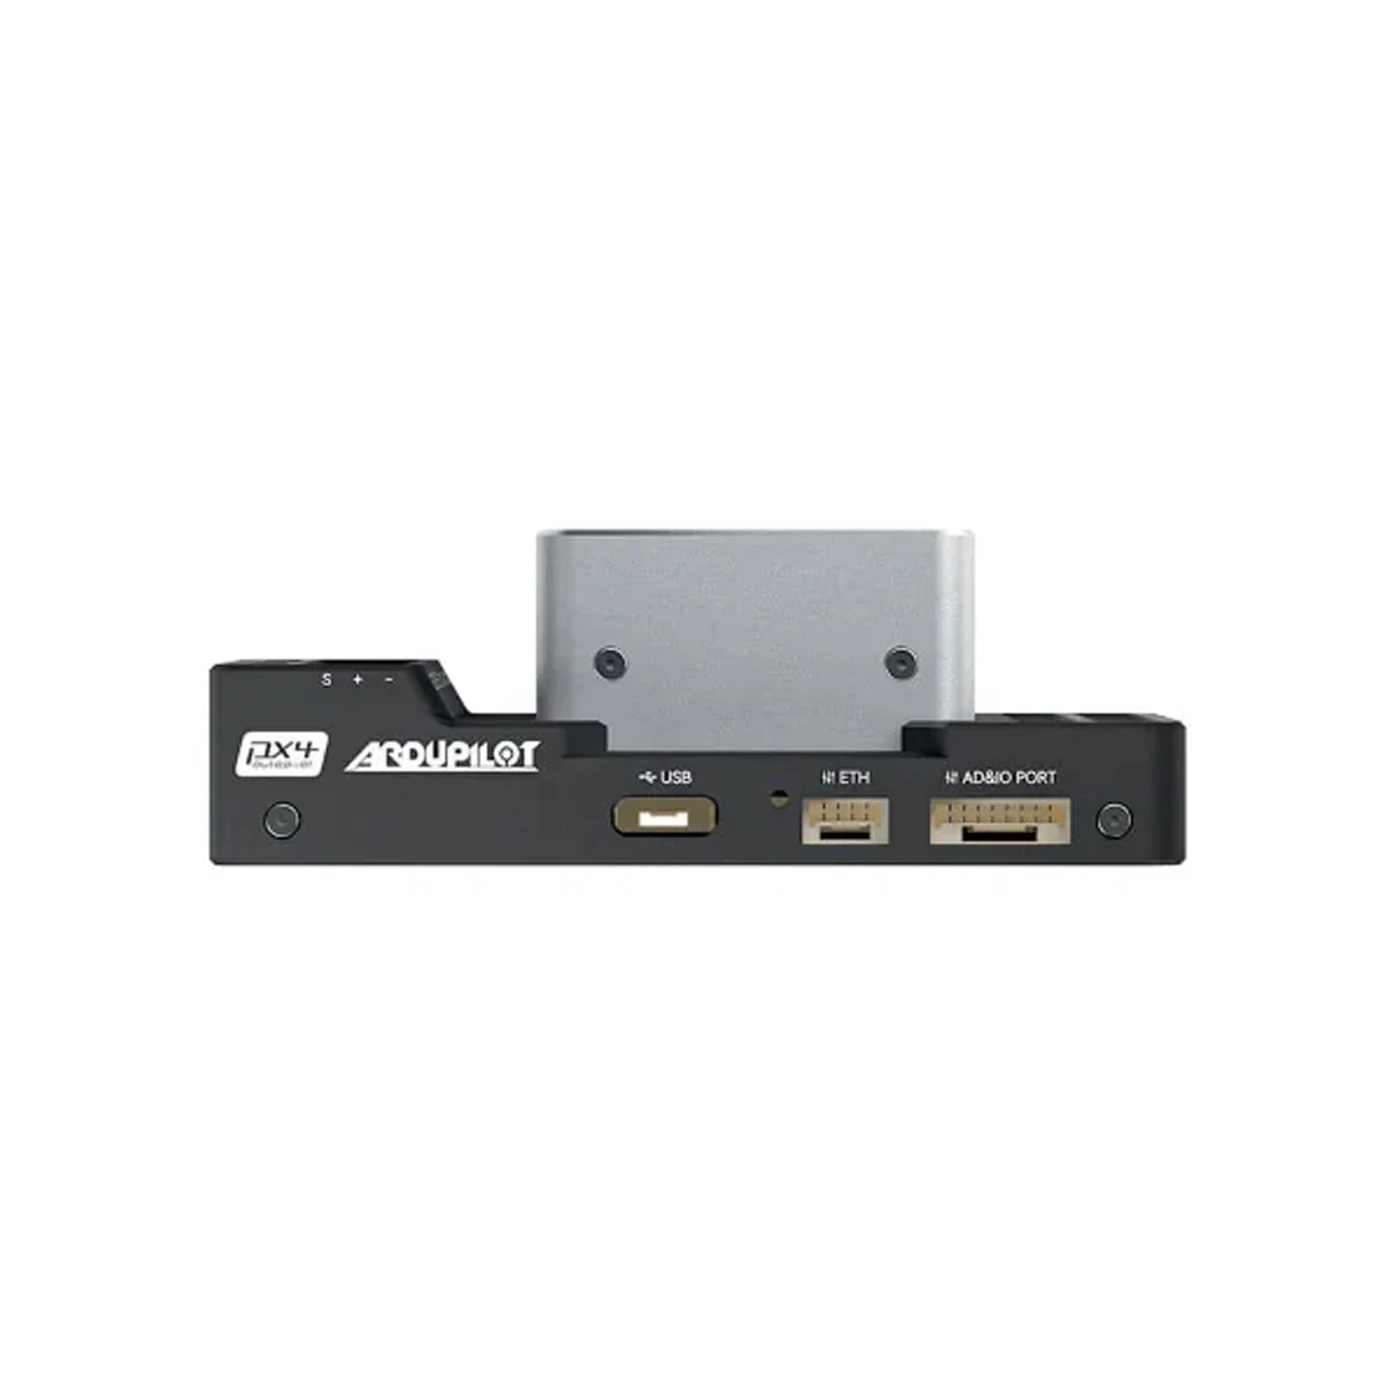
The CUAV Pixhawk V6X V2 is a high-performance flight controller designed for advanced UAV and robotics applications, featuring a powerful STM32H7 main processor, triple-redundant IMUs, and integrated 100 Mbps Ethernet. It is fully compatible with PX4 and ArduPilot firmware for autonomous drone operations.
Features
- High-performance STM32H753IIK6 processor (480MHz) with STM32F103 co-processor for real-time control.
- Triple-redundant IMU system (IIM-42652, BMI088, ICM-42686) with independent buses for enhanced reliability.
- Integrated 100 Mbps Ethernet port for high-speed communication with onboard computers and payloads.
- Wide input voltage range of 12V to 70V via the included PMU 2 Lite power module.
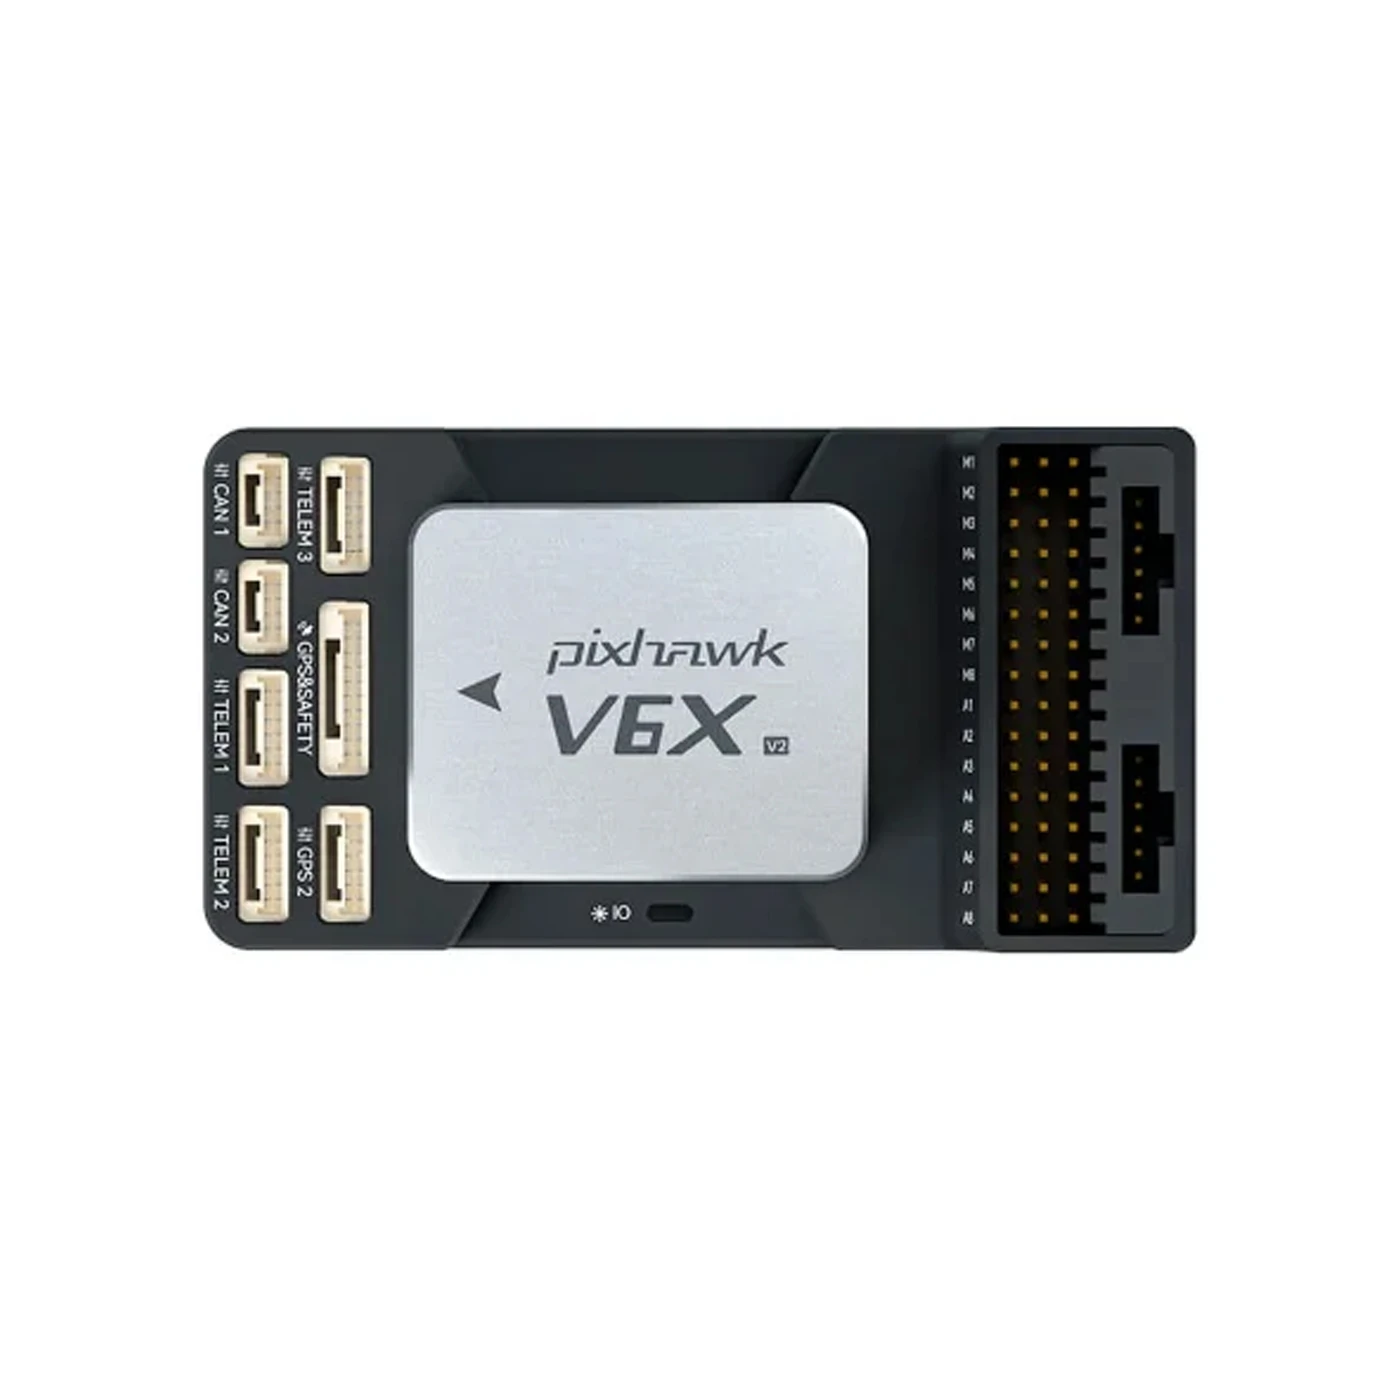
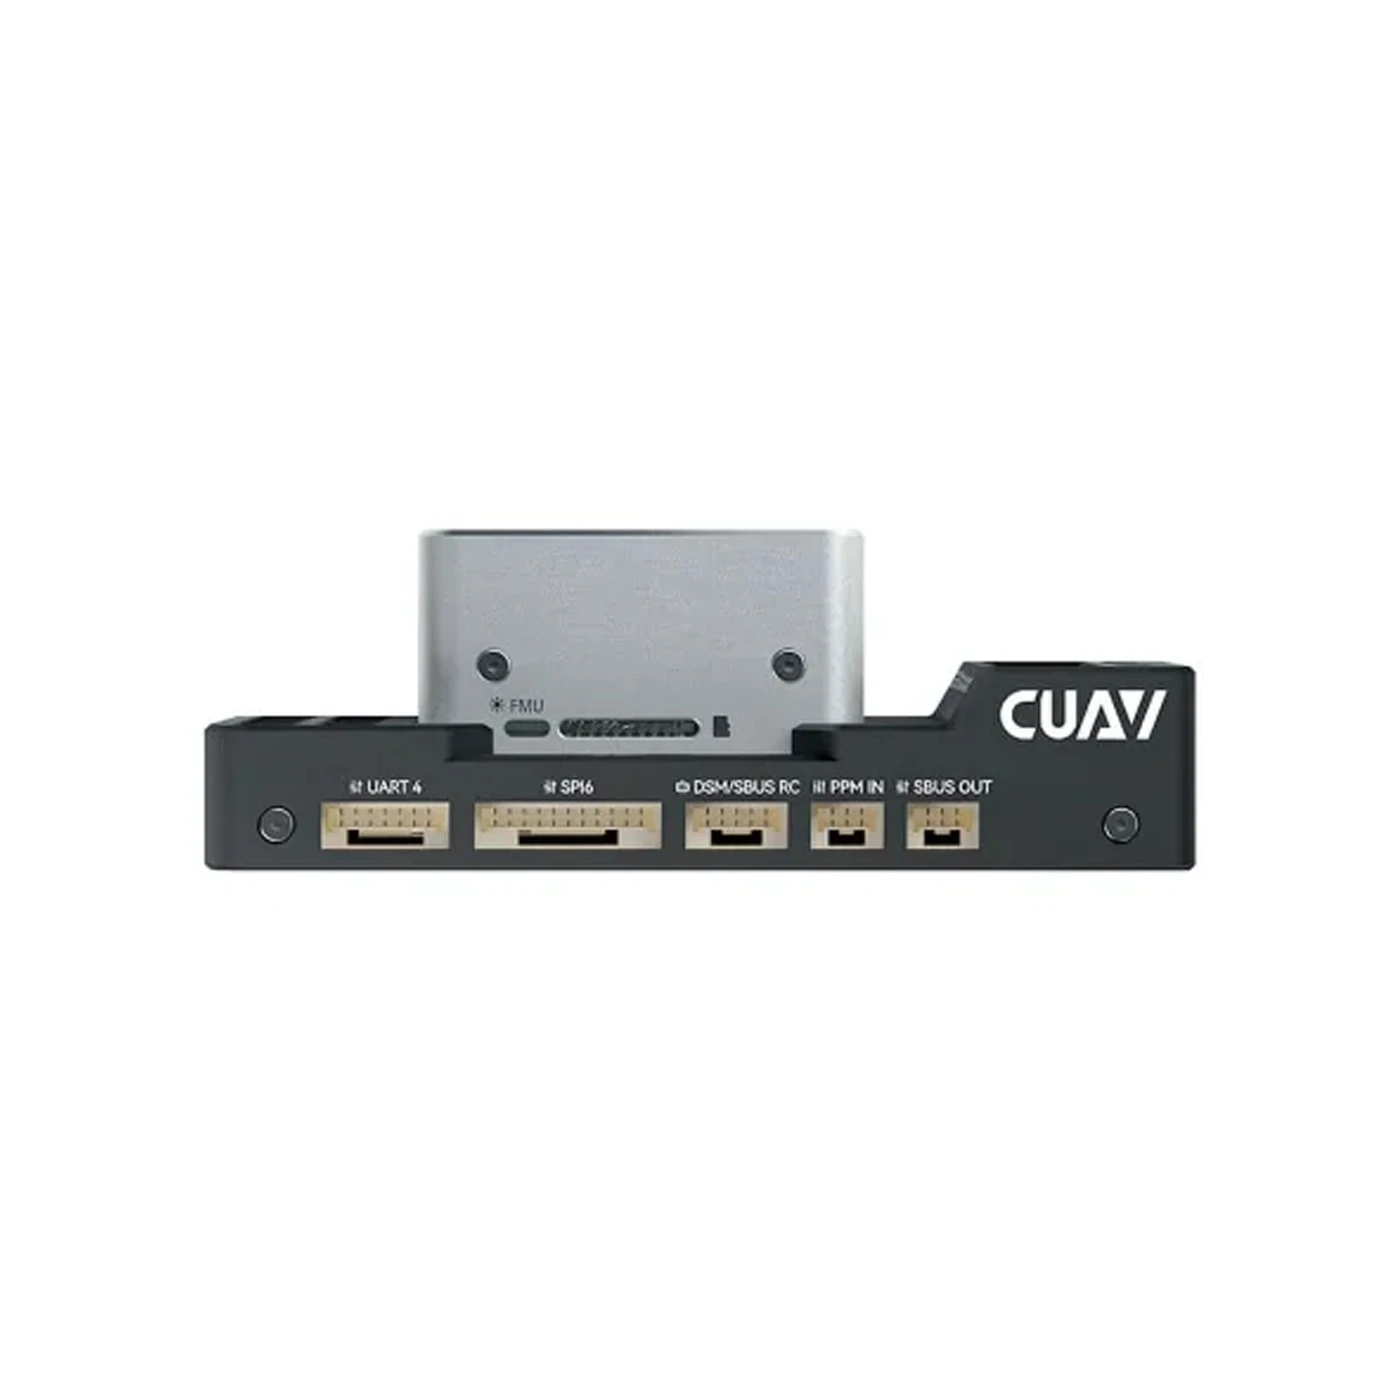
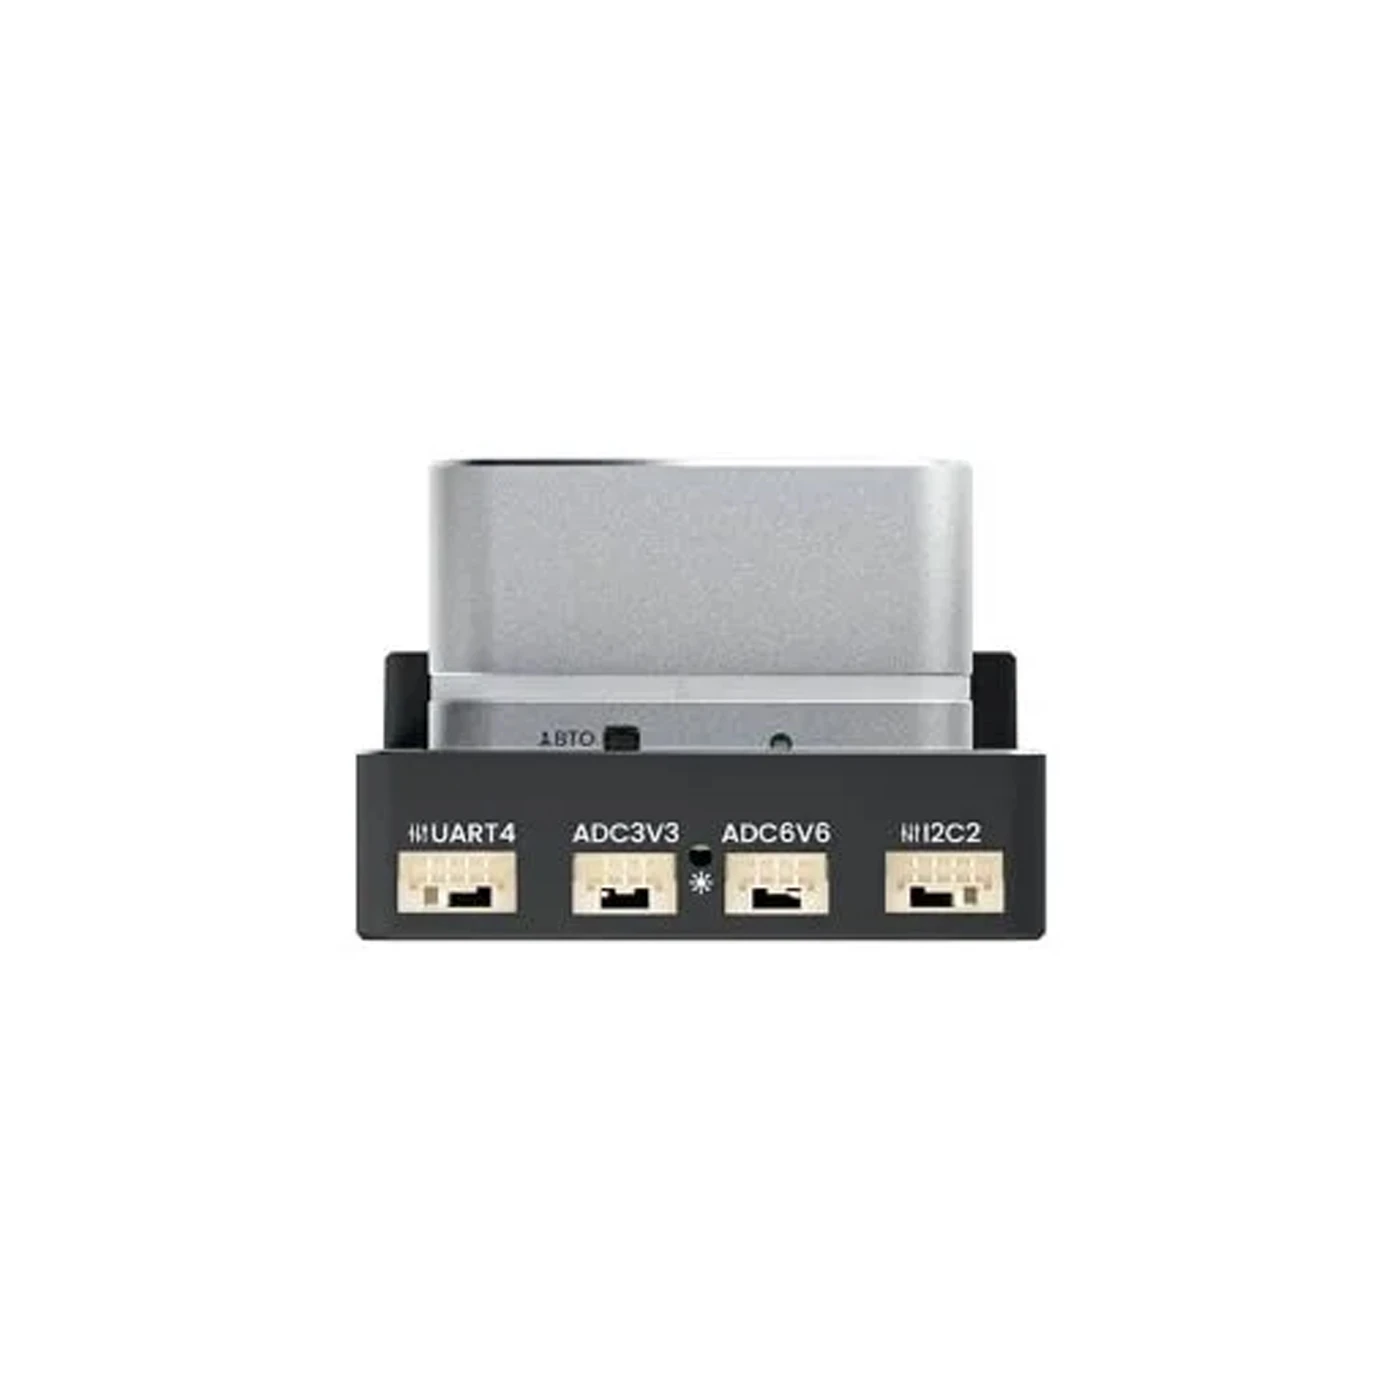
- Extensive I/O including 16 PWM outputs, dual CAN bus, dual GPS ports, and three telemetry ports.
Out of stock
The Pixhawk V6X V2 is a next-generation autopilot built to the Pixhawk FMU v6X standard, engineered for demanding commercial and industrial UAV platforms. Its robust electrical design centers on the STM32H7 main processor, delivering the computational power required for complex autonomous navigation, mission planning, and real-time sensor fusion. A dedicated STM32F103 Cortex-M3 co-processor handles critical real-time tasks, ensuring system responsiveness and safety.
Structural durability and flight integrity are ensured through a triple-redundant inertial measurement unit (IMU) configuration, dual barometers, and a factory-calibrated thermal compensation system. This design maintains sensor accuracy across a wide operating temperature range from -20°C to +85°C. The integrated 100 Mbps Ethernet port facilitates seamless data exchange with companion computers, high-resolution mapping payloads, and other onboard systems, making it ideal for aerial surveying, inspection, and heavy-lift drone applications.
Additional Information
| Weight | 0.427 kg |
|---|---|
| Dimensions | 17 × 19 × 6 cm |