SKU: DRFC-0894
📋 GST Invoice Available

Pixhawk 2.4.8 Flight Controller Kit w/ GPS & Power Module

₹10,124.73 (Inclusive of all taxes)
Out of Stock

The Pixhawk 2.4.8 is a high-performance autopilot module suitable for a wide range of robotic platforms, offering robust flight control capabilities. This comprehensive kit includes a high-precision NEO-M8N GPS, an anti-vibration mount, and a power module, providing a complete solution for autonomous navigation and stable operation.

Features

  • Advanced 32-bit ARM CortexM4 FC with NuttX RTOS for reliable real-time operation.
  • Integrated backup power and failsafe co-processor for enhanced system redundancy.
  • High-precision u-blox NEO-M8N GPS module offering up to 0.6m positional accuracy.
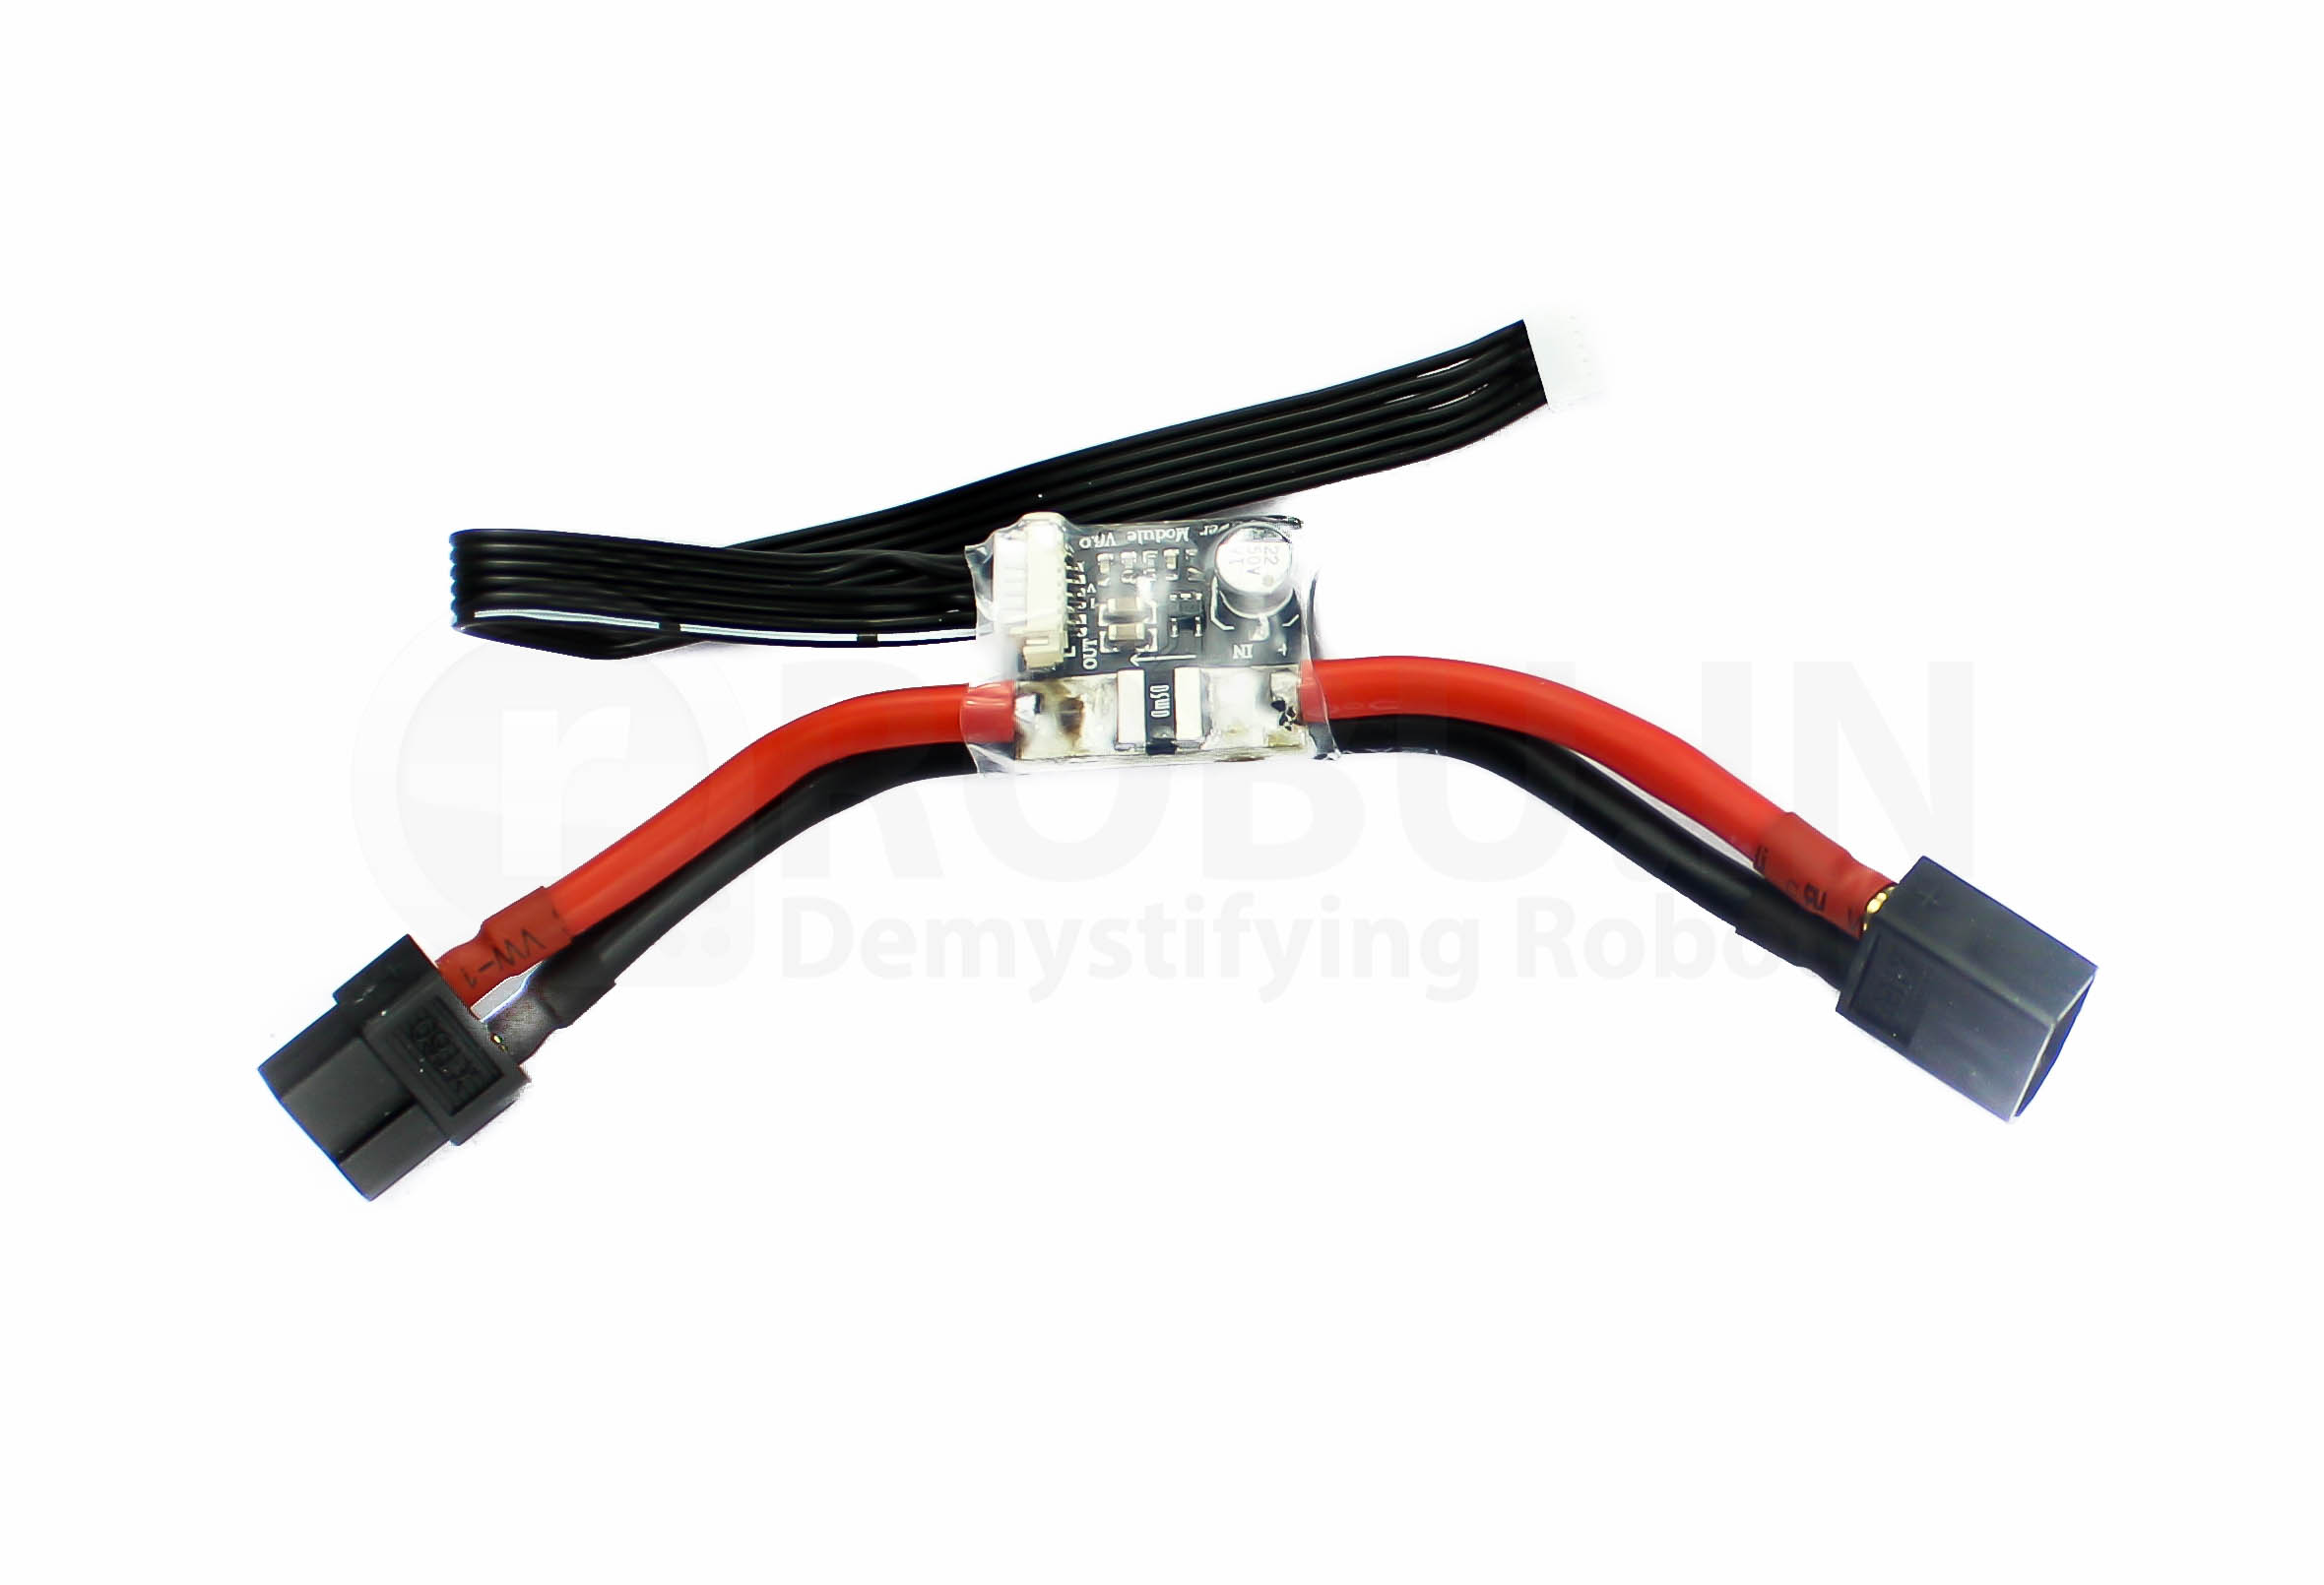
  • 90A current sensing power module supports 6S LiPo batteries with 5.3V/3A BEC output.
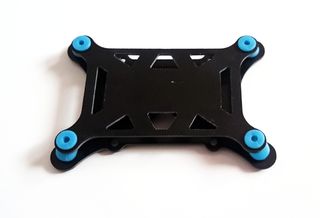
  • Includes a glass fiber anti-vibration mount to protect sensitive electronics from flight oscillations.

Out of stock

Description

The Pixhawk PX4 2.4.8 Flight Controller is a robust, high-performance autopilot-on-module engineered for a diverse array of robotic platforms, including fixed-wing aircraft, multirotors, helicopters, and ground vehicles. It integrates the functionality of PX4FMU and PX4IO, running the NuttX RTOS on an advanced 32-bit ARM CortexM4 processor, providing exceptional real-time control and processing capabilities for high-end research, amateur, and industrial applications.

This comprehensive kit enhances the Pixhawk’s core capabilities with essential peripherals. The included u-blox NEO-M8N GPS module delivers superior navigational accuracy, boasting an ultimate precision of 0.6 meters and supporting multiple global navigation satellite systems (GPS/QZSS, GLONASS, BeiDou). An anti-vibration mount, constructed from glass fiber, effectively isolates the flight controller and other sensitive electronics from airframe vibrations, ensuring stable sensor readings. Furthermore, the Pixhawk PX4 2.4.8 Power Module offers a streamlined solution for power delivery and monitoring, providing clean LiPo power (up to 6S / 90A) and crucial telemetry for current consumption and battery voltage via a single 6-position cable.

Key Features

  • Utilizes advanced 32-bit STM32F427 Cortex M4 core with FPU and NuttX RTOS.
  • Provides 14 PWM/servo outputs for extensive control over motors and servos.
  • Comprehensive bus interfaces include 5x UART, 2x CAN, I2C, SPI, and multiple ADC inputs.
  • Integrated backup power and a 32-bit STM32F103 failsafe co-processor for system redundancy.
  • u-blox NEO-M8N GPS module with 72-channel receiver, supporting GPS/QZSS, GLONASS, and BeiDou.
  • GPS module offers 2.0m CEP position accuracy and supports up to 18 Hz single GNSS update rate.
  • Power Module supports up to 28V (6S LiPo) with max 90A current sensing and 5.3V/3A BEC output.
  • Glass fiber anti-vibration mount ensures stable sensor performance for various flight controllers.

Applications

  • Autonomous mapping & survey UAVs
  • FPV freestyle and long-range drones (DIY builds)
  • Industrial & agricultural spraying drones
  • Fixed-wing aircraft and VTOL platforms
  • Robotic platforms (cars, boats, general robotics)

Technical Specifications

Flight Controller Processor32bit STM32F427 Cortex M4 with FPU (168 MHz, 2 MB Flash, 128 KB RAM)
Failsafe Co-processor32-bit STM32F103
GyroscopeST Micro L3GD20H (16 bit), Invensense MPU 6000 (3-axis)
Accelerometer/MagnetometerST Micro X4HBA 303H (14 bit)
BarometerMEAS MS5607
PWM / Servo Outputs14
Interfaces5x UART, 2x CAN, Spektrum DSM/DSM2/DSM-X, Futaba S.BUS, PPM sum, RSSI, I2C, SPI, 3.3/6.6V ADC
GPS Receiver Type72-channel u-blox M8 engine
GPS Satellite SupportGPS/QZSS L1 C/A, GLONASS L10F, BeiDou B1, SBAS L1 C/A
GPS Position Accuracy2.0 m CEP (ultimate 0.6 m)
Power Module Input VoltageMax 28V (6S LiPo)
Power Module Current SensingMax 90A
Power Module BEC Output5.3V @ 3A max
Anti-Vibration Mount MaterialGlass fiber
GPS Folding Mount Rod Length14 cm
GPS Plate Diameter40 mm

Frequently Asked Questions

What are the main processing units and sensors on the Pixhawk 2.4.8 FC?

The Pixhawk 2.4.8 utilizes a 32-bit STM32F427 Cortex M4 core operating at 168 MHz with 2MB Flash and 128KB RAM, complemented by an STM32F103 failsafe co-processor. It integrates an ST Micro L3GD20H gyroscope, X4HBA 303H accelerometer/magnetometer, Invensense MPU 6000, and a MEAS MS5607 barometer for precise flight dynamics.

What is the positional accuracy and satellite support for the included NEO-M8N GPS module?

The u-blox NEO-M8N GPS module offers an ultimate accuracy of 0.6 meters, with a CEP of 2.0 meters. It supports concurrent GNSS reception including GPS/QZSS L1 C/A, GLONASS L10F, and BeiDou B1 protocols, enhancing reliability and precision for navigation in various global regions.

How does the power module integrate with the Pixhawk and what are its capabilities?

The included power module connects directly to the Pixhawk via a 6-pos DF13 cable, providing clean power from a LiPo battery. It is capable of handling up to 28V input (6S LiPo) and sensing currents up to 90A, while also delivering a regulated 5.3V at 3A max output for the flight controller and peripherals.

What operating systems and software can the Pixhawk 2.4.8 run, and what platforms does it support?

The Pixhawk 2.4.8 is designed to run the NuttX RTOS real-time operating system, supporting popular autopilot firmware like ArduPilot and PX4. Its versatile architecture makes it suitable for fixed-wing aircraft, multirotors, helicopters, as well as ground and marine robotic platforms, offering adaptability across various autonomous applications.

Package Includes

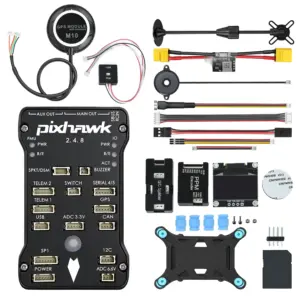
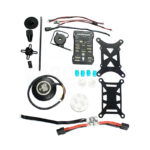
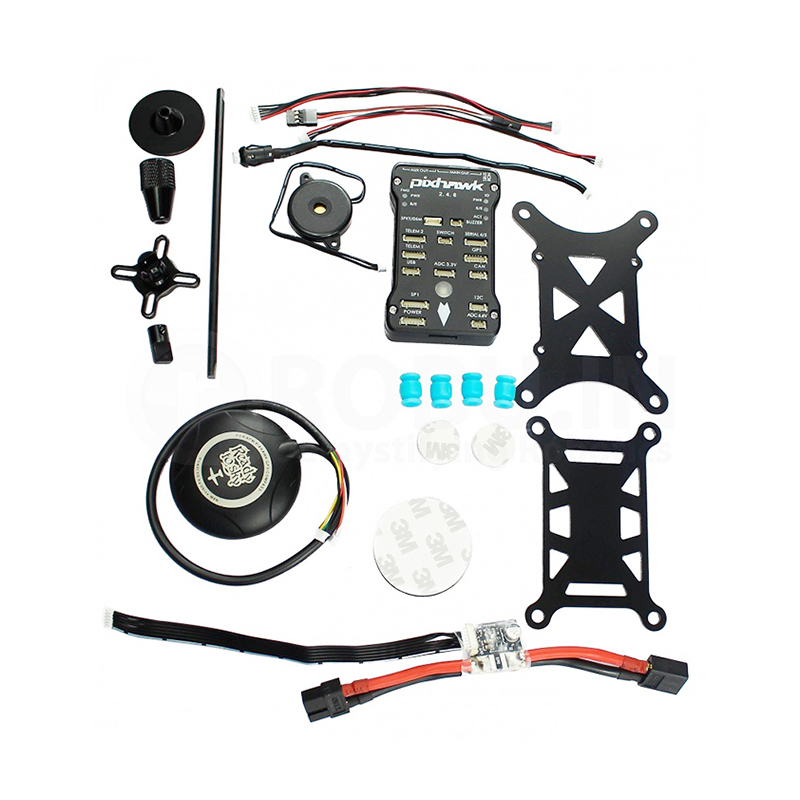
  • 1 x Pixhawk V2.4.8 Flight board with Original Shell
  • 3 x Connecting Cables
  • 1 x Buzzer Module
  • 1 x Glass Fiber Flight Controller Anti-vibration/Shock absorber Set
  • 1 x NEO-M8N GPS Module with translucent Shell
  • 1 x GPS Folding Base Antenna set
  • 1 x APM 2.5.2/2.6/2.8 Pixhawk Power Module

Additional Information

Dimensions 15 × 10 × 6 cm