SKU: IOWC-0221
📋 GST Invoice Available

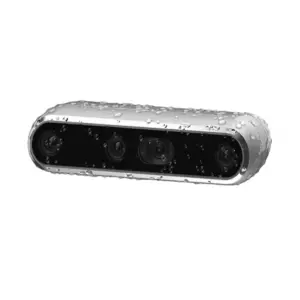
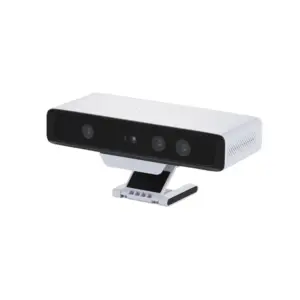
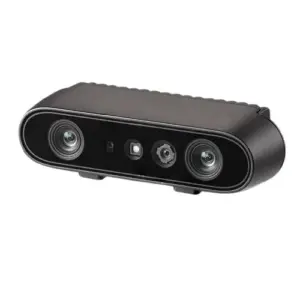
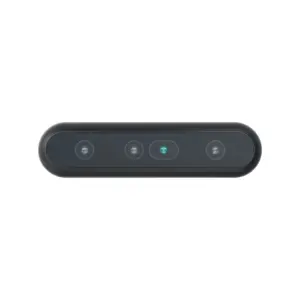
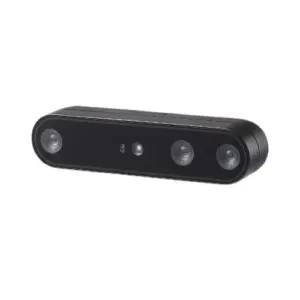
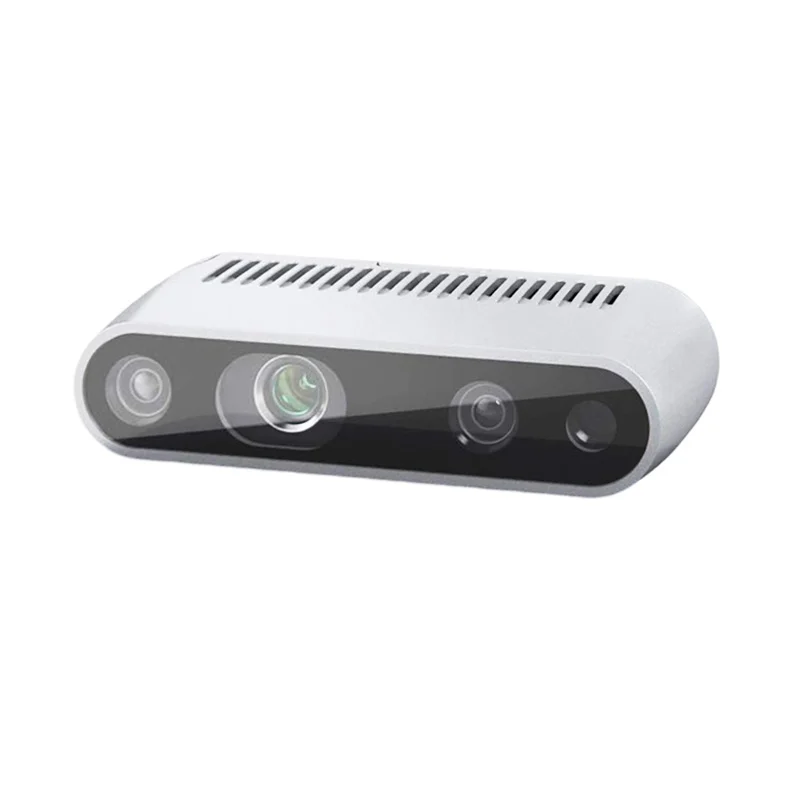
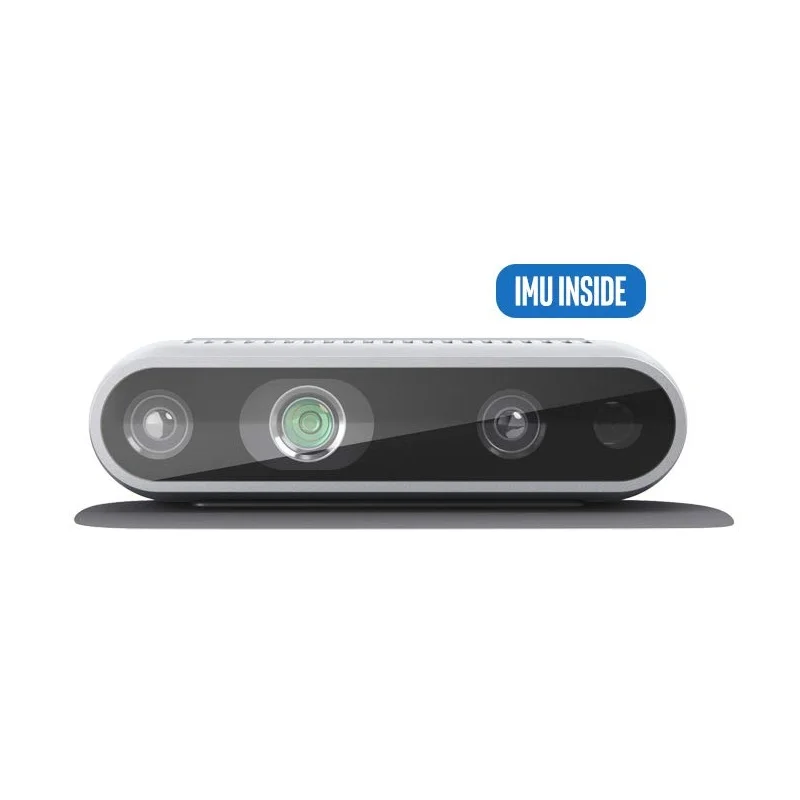
Intel Intel RealSense Depth Camera D435i w/ IMU

₹46,089.00 (Inclusive of all taxes)
Out of Stock

The Intel Intel RealSense D435i is a USB 3.0 depth camera featuring an integrated inertial measurement unit (IMU) for enhanced 3D scanning and spatial awareness in robotics, AR/VR, and computer vision applications, compatible with Intel RealSense SDK 2.0 and ROS.

Features

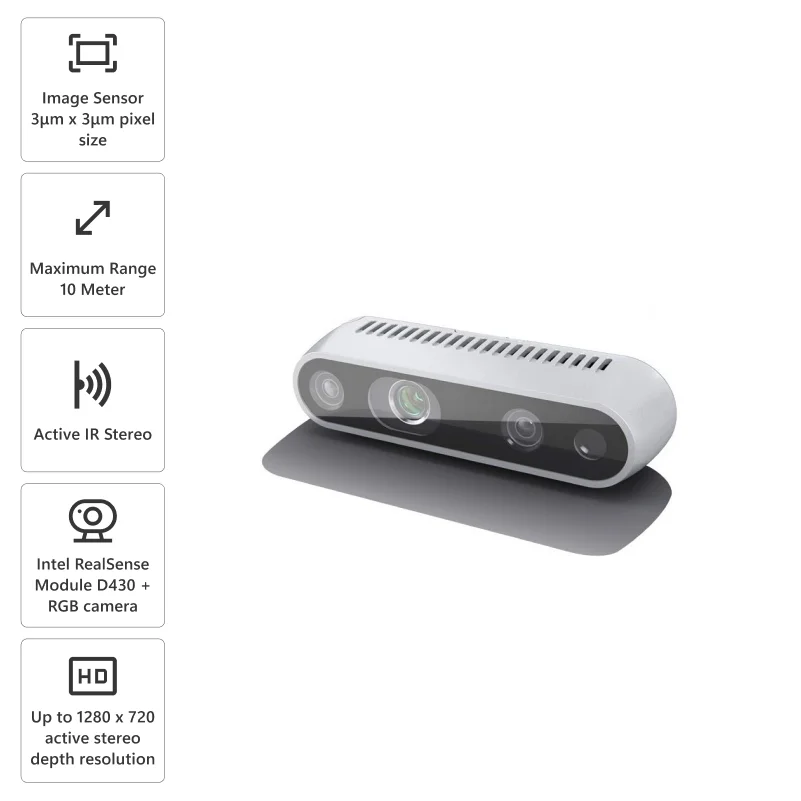
  • Active IR stereo depth sensing with a 10-meter maximum range and up to 90 fps at 720p resolution.
  • Integrated BMI055 IMU provides inertial data time-synchronized with depth frames for improved motion tracking.
  • Global shutter image sensor with a wide 91.2° horizontal FOV enables accurate high-speed capture.
  • USB 3.0 interface delivers high-bandwidth depth and RGB streams (up to 1080p) for real-time processing.
  • Out-of-the-box compatibility with Intel Intel RealSense SDK 2.0 and Robotic Operating System (ROS) for rapid development.

Out of stock

Description

The Intel Intel RealSense D435i depth camera builds upon the proven D430 depth module by integrating a Bosch BMI055 inertial measurement unit (IMU), fusing visual and inertial data for robust spatial perception. Its active infrared stereo vision system uses a global shutter and a 50mm baseline to deliver precise depth maps up to 10 meters, even in dynamic environments.

Designed for seamless integration, the camera streams synchronized depth, RGB, and IMU data over a single USB 3.0 Type-C connection, minimizing system latency. The included Intel RealSense SDK 2.0 provides cross-platform APIs for accessing raw sensor streams, point cloud generation, and post-processing filters, accelerating development for autonomous navigation, 3D scanning, and human-machine interaction.

Key Features

  • Combines depth sensing with an integrated 6-axis IMU (accelerometer + gyroscope) for motion-aware 3D reconstruction.
  • Active IR stereo technology with global shutter ensures reliable depth accuracy for fast-moving objects.
  • Wide field of view (91.2° H x 65.5° V) captures expansive scenes for robotics and augmented reality.
  • High-frame-rate streaming up to 90 fps for real-time depth perception and gesture recognition.
  • Fully supported by Intel's open-source Intel RealSense SDK 2.0, with wrappers for Python, C++, and ROS.
  • Compact, ruggedized form factor with a standard 1/4"-20 tripod mount for flexible deployment.

Applications

  • Robotics navigation and SLAM (Simultaneous Localization and Mapping) for autonomous drones and rovers.
  • 3D scanning, object recognition, and volumetric measurement in industrial automation.
  • Augmented and virtual reality experiences requiring real-time depth mapping and user interaction.
  • Gesture-based human-computer interfaces and interactive digital signage.
  • Biometric authentication and access control systems using facial depth analysis.

Technical Specifications

Depth SensorIntel Intel RealSense Module D430 (Active IR Stereo)
Inertial Measurement UnitBosch BMI055 (6-Axis Accelerometer + Gyroscope)
Depth ResolutionUp to 1280 x 720 @ 90 fps
RGB SensorYes, up to 1920 x 1080
Field of View (H x V)91.2° x 65.5°
Operating Range0.2 m to ~10 m
InterfaceUSB 3.0 Type-C
Shutter TypeGlobal Shutter
Software SupportIntel Intel RealSense SDK 2.0, ROS, OpenCV
Dimensions (L x W x H)95 x 25 x 25 mm

Frequently Asked Questions

What software is needed to start developing with the Intel RealSense D435i?

Install the Intel Intel RealSense SDK 2.0 (librealsense) from GitHub, which provides drivers, APIs for C++, Python, and .NET, and ready-to-use tools like the Intel RealSense Viewer for data capture and calibration. For robotics, use the official ROS wrapper (Intel RealSense-ros) to publish depth, RGB, and IMU topics directly into your ROS 1 or ROS 2 environment, enabling immediate integration with navigation stacks and SLAM algorithms.

How do I synchronize the depth data with the IMU readings?

The D435i hardware timestamps all IMU data frames to align precisely with the depth sensor's clock. Within the Intel RealSense SDK, you can enable synchronized streaming of both data types; the API provides callback functions that deliver correlated depth and inertial packets. For advanced sensor fusion, you can access the raw gyroscope and accelerometer data at up to 200 Hz and apply your own Kalman filter or use ROS's imu_filter_madgwick node.

What is the power requirement and how is the camera connected?

The D435i is powered entirely via its USB 3.0 Type-C port, drawing up to 2.5W. A standard USB 3.0 host port (providing 900mA at 5V) is required for full functionality, including streaming high-resolution depth and RGB at 90 fps. Use the included cable or a certified USB 3.0 Gen 1 cable for reliable data transfer. The camera does not support USB 2.0 for depth streaming due to bandwidth constraints.

Can the D435i be used outdoors or in bright sunlight?

The active IR stereo system projects a pattern using an infrared laser, which can be washed out by direct sunlight, reducing effective range and accuracy. For outdoor use, employ shade, operate during lower ambient IR conditions (dawn/dusk), or consider the D455 model with a longer baseline. The global shutter helps with motion in bright conditions, but maximum reliable depth range will be less than the rated 10 meters under intense sunlight.

Package Includes

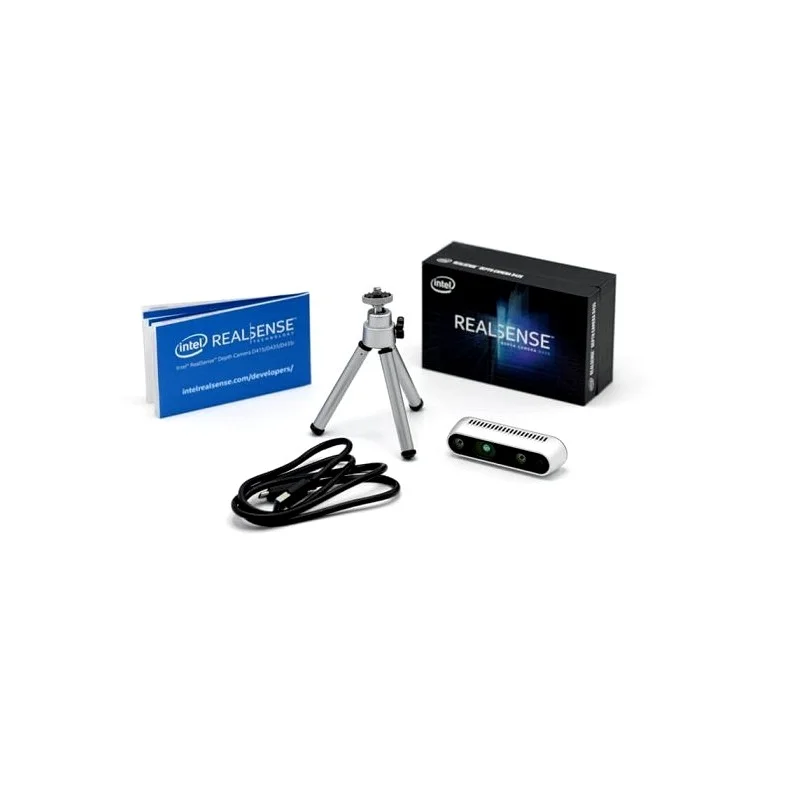
  • 1 x Intel Intel RealSense D435i Depth Camera
  • 1 x USB 3.0 Type-C Cable
  • 1 x Desktop Tripod
  • Software & SDK access (Intel RealSense SDK 2.0)

Additional Information

Weight 0.1 kg
Dimensions 9.5 × 2.5 × 2.5 cm