DFRobot Gravity 4×8 Flexible Array Tactile Pressure Sensor (UART Cascade Support)
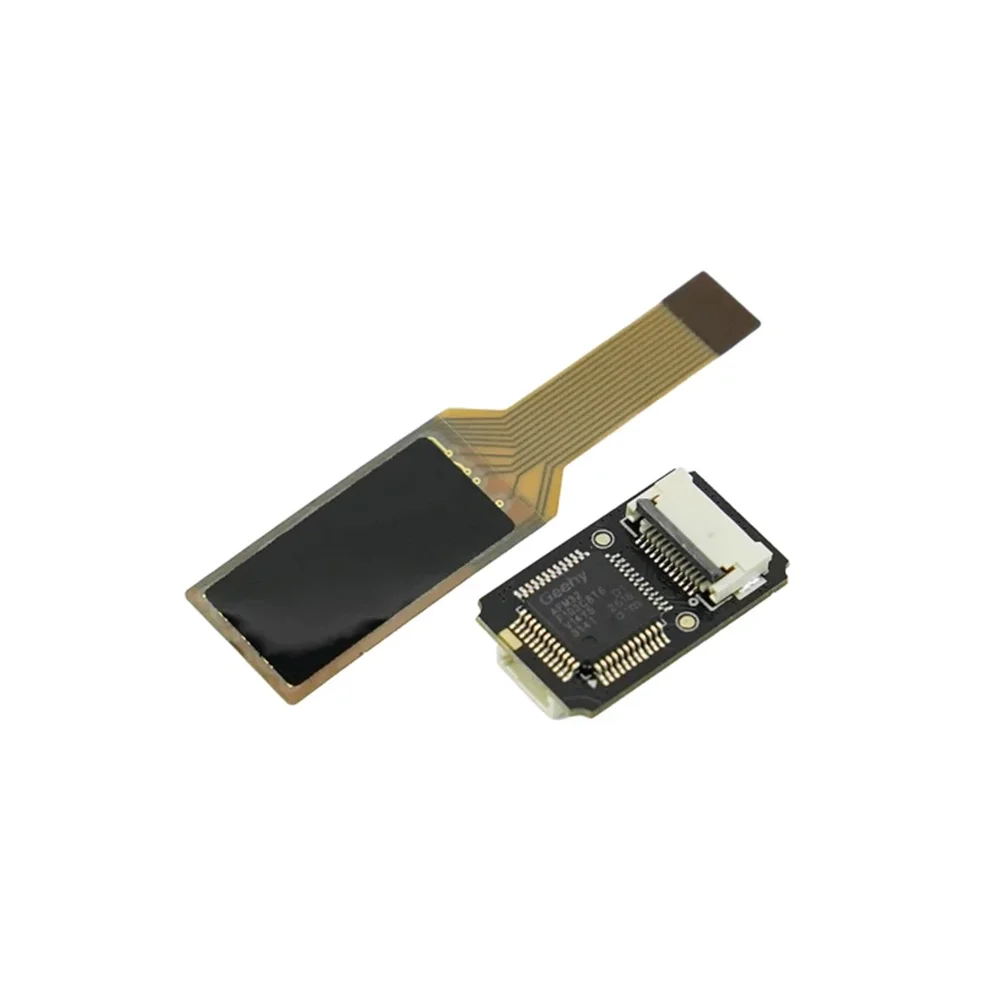
The DFRobot Gravity 4×8 Flexible Array Tactile Pressure Sensor is a 32-point Matrix sensor for precise pressure mapping and tactile feedback. It features a UART interface with cascade support for easy daisy-chaining and is compatible with Arduino, ESP32, and Raspberry Pi for robotics, wearables, and human-machine interface projects.
Features
- 4×8 Matrix with 32 independent sensing points for detailed pressure distribution mapping.
- Ultra-thin, flexible FPC construction with adhesive backing for mounting on flat or curved surfaces.
- UART communication interface with built-in cascade support for connecting multiple sensors in series.
- High durability rated for over 1,000,000 operating cycles at 1kg force for long-term reliability.
- Fast response time below 10μs and configurable 20Hz/50Hz sampling frequency for dynamic sensing applications.
Out of stock
This sensor utilizes a grid of 32 individual force-sensitive elements arranged in a 4×8 Matrix across a compact 20mm x 10mm active area, with a 2.5mm pitch between points. Each point operates on a compression-based sensing principle, providing independent readings within a range of 20g to 5kg per point, with a trigger force as low as 20g. The flexible printed circuit (FPC) design ensures minimal added bulk and conforms to various surfaces.
The integrated UART interface simplifies digital communication, eliminating the need for complex analog signal conditioning. The cascade functionality allows multiple sensor arrays to be linked via a single serial bus, significantly reducing wiring complexity in multi-sensor systems. It is engineered for stable operation across an industrial temperature range of -20°C to +65°C, making it suitable for both controlled lab environments and demanding applications.
Additional Information
| Weight | 0.01 kg |
|---|---|
| Dimensions | 6 × 6 × 3 cm |