SKU: DRFC-2012
📋 GST Invoice Available

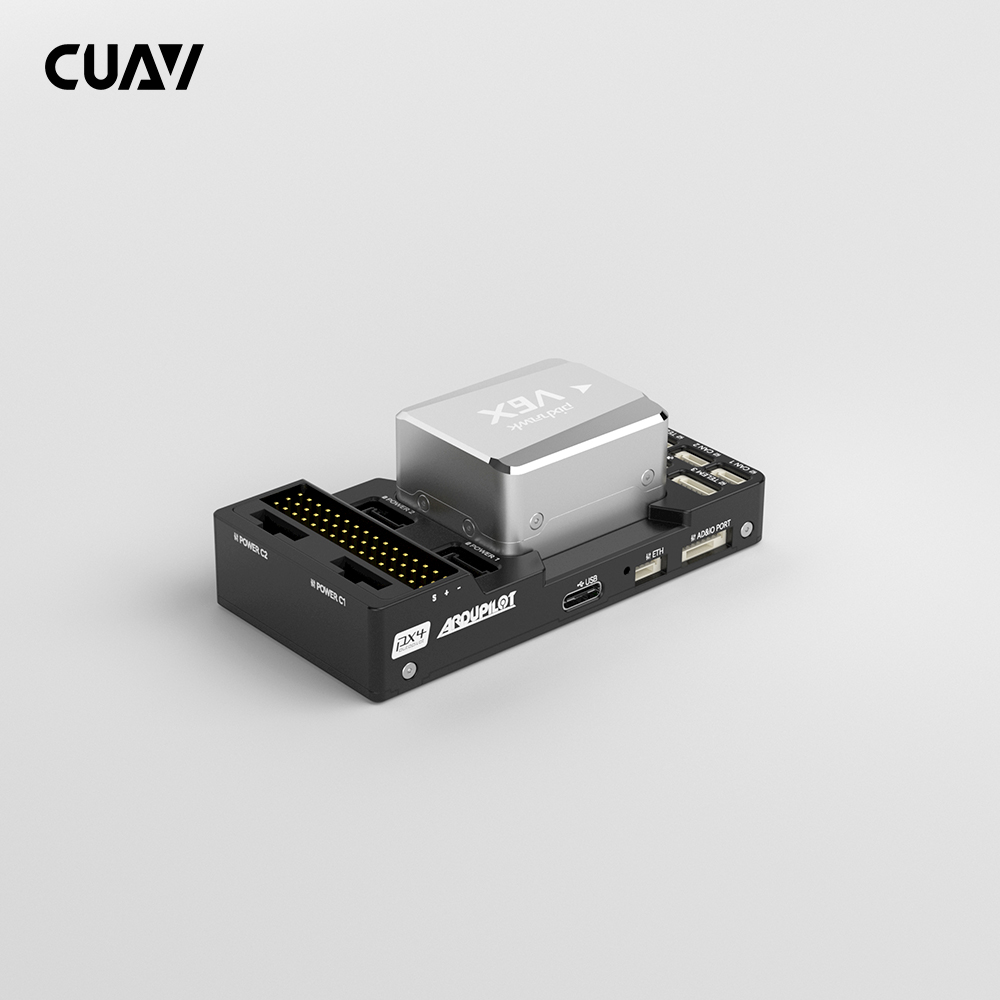
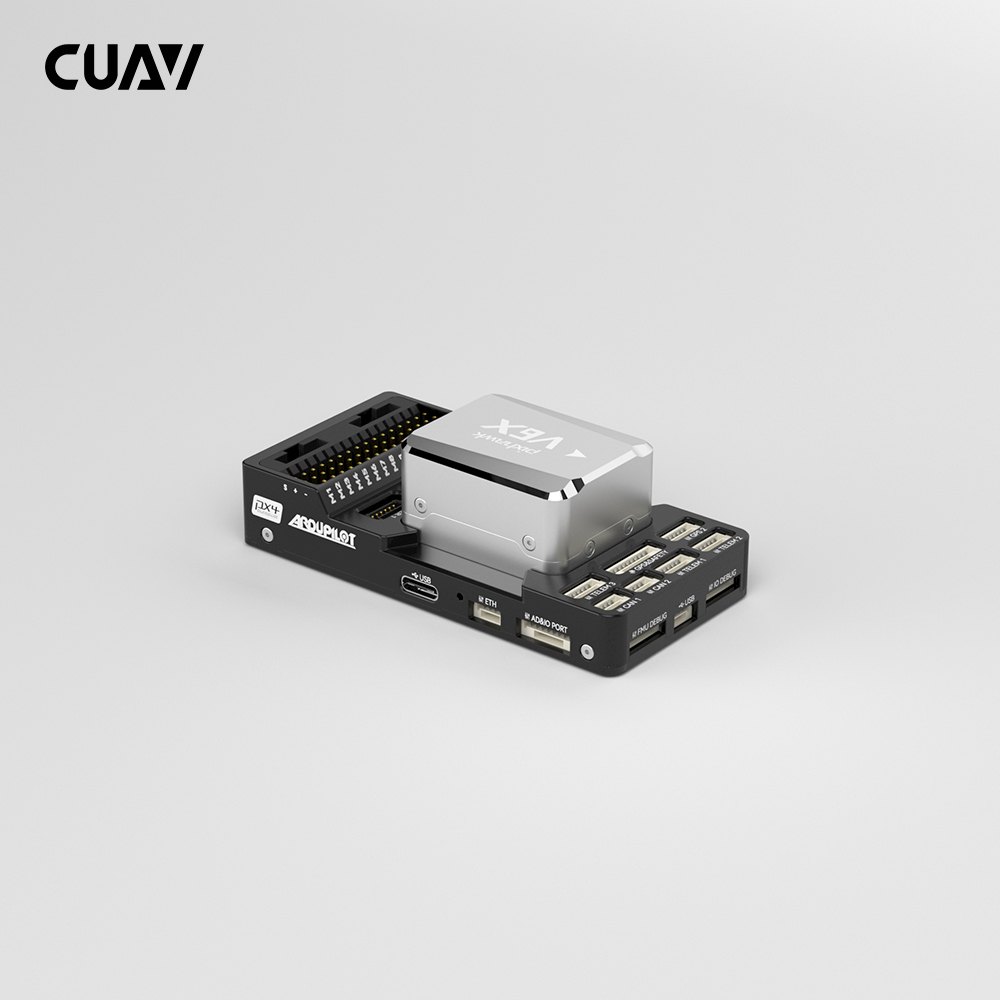
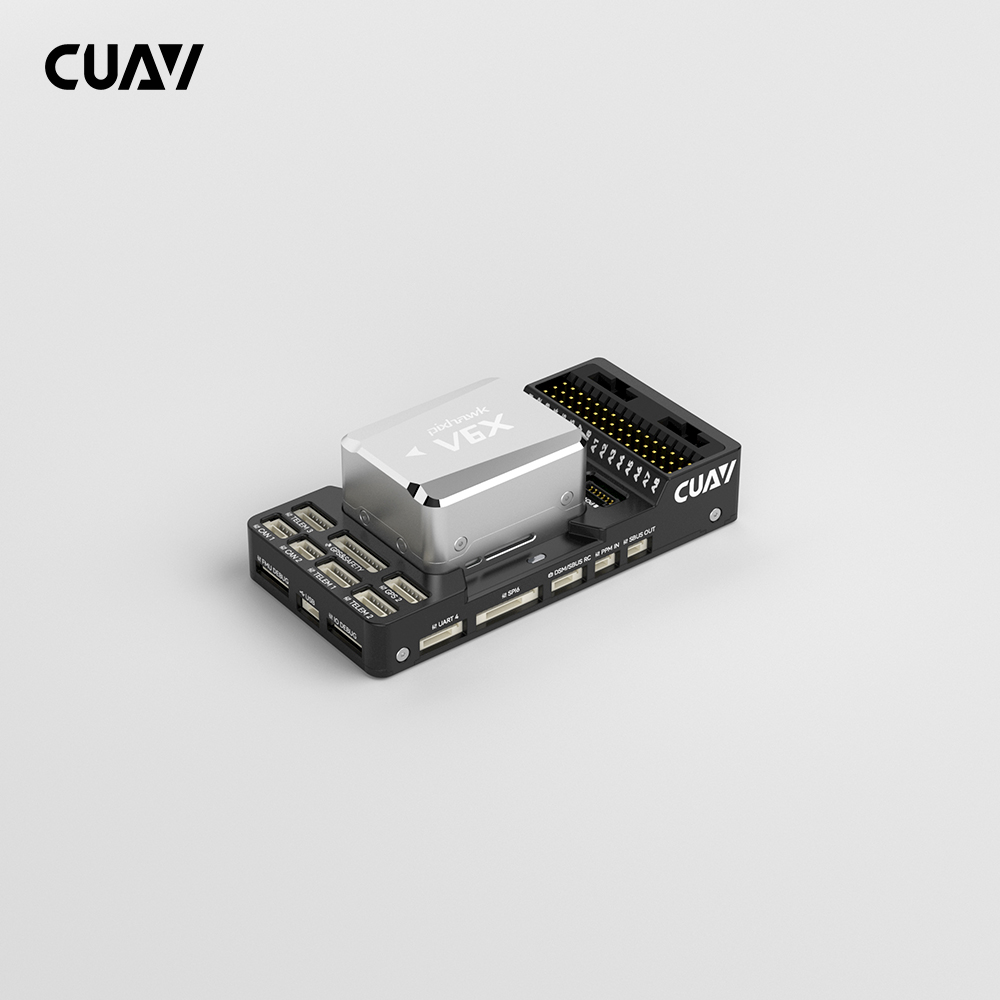
CUAV V6X Flight Controller

₹29,999.00 (Inclusive of all taxes)
Out of Stock

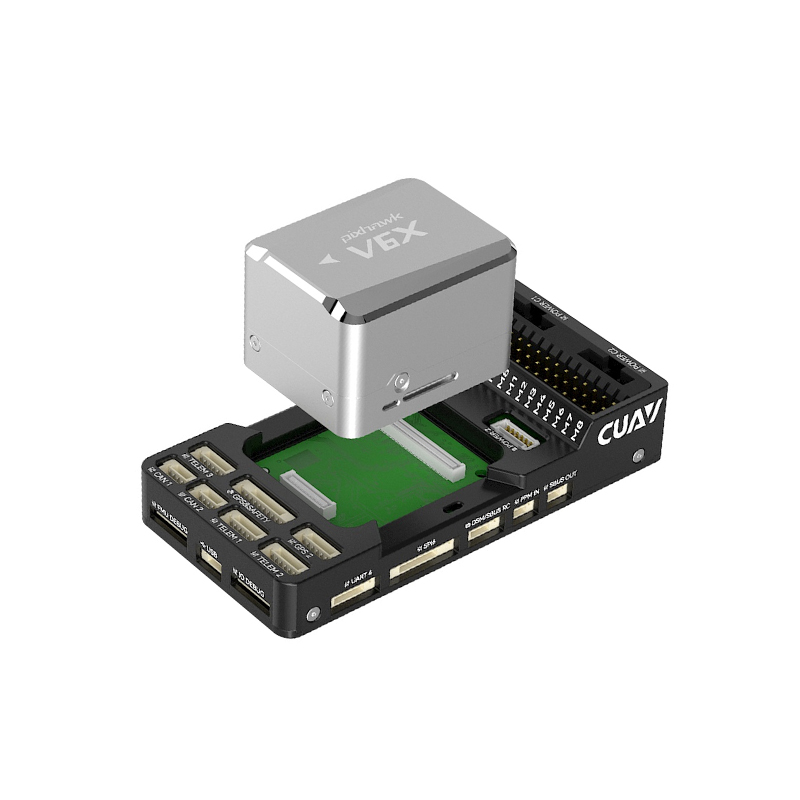
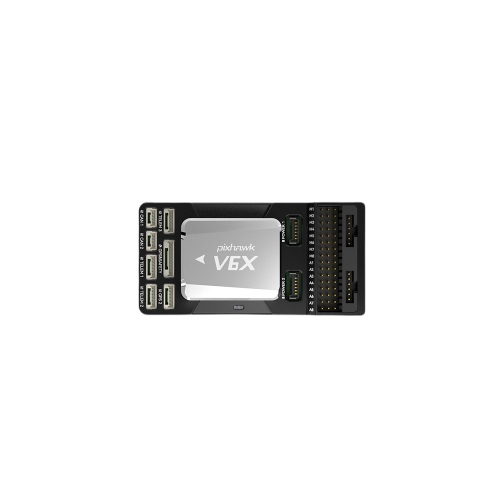
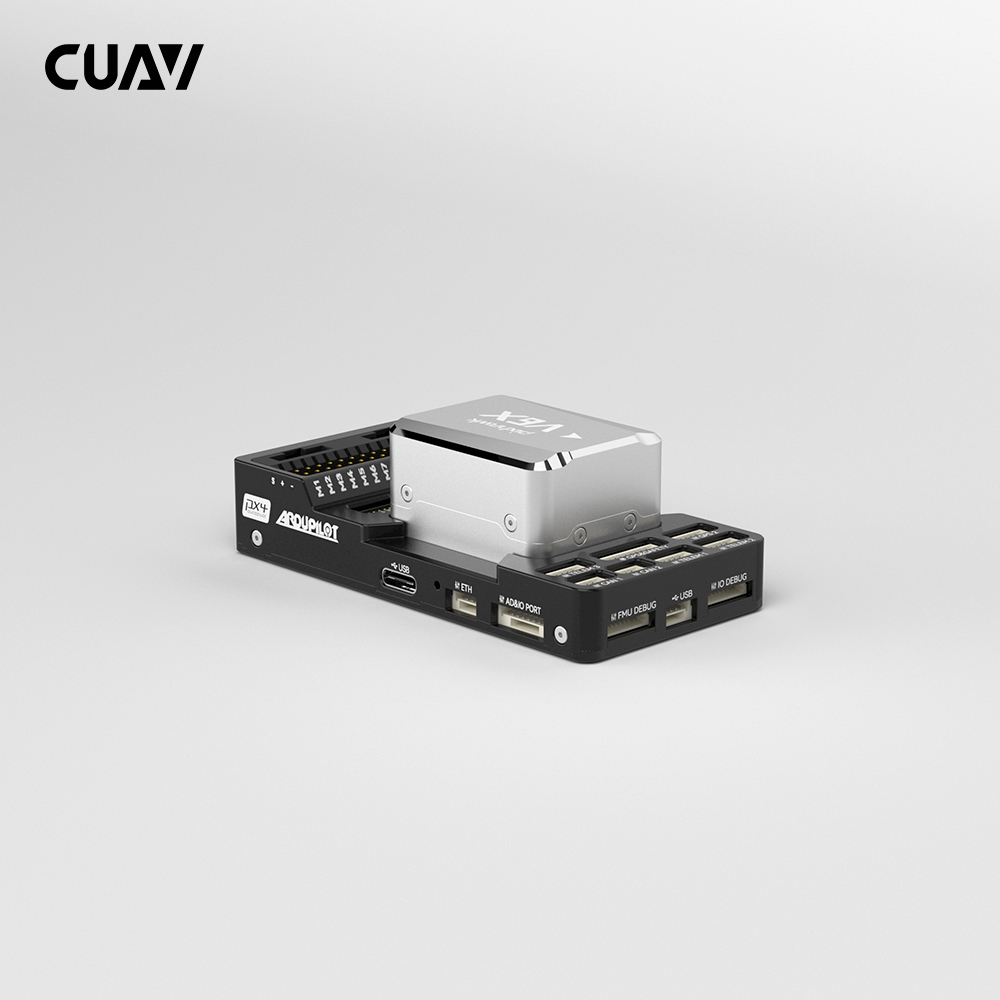
The CUAV V6X is a professional-grade Pixhawk-standard flight controller built around an STM32H753 processor, featuring triple-redundant IMUs, dual barometers, and a car-grade RM3100 magnetometer for robust autonomy in complex UAV applications.

Features

  • STM32H753IIK6 dual-precision floating-point processor (480MHz) for high-performance flight control.
  • Triple-redundant IMU (ICM42688-P, ICM-20649, BMI088) and dual-redundant barometer design for maximum flight safety.
  • Integrated 100M Ethernet PHY for high-speed communication with mission computers, INS, and mapping payloads.
  • Car-grade RM3100 magnetometer with GPS heading support for reliable operation in magnetically noisy environments.
  • Full compatibility with PX4 and ArduPilot firmware for multi-rotor, fixed-wing, VTOL, and rover platforms.

Out of stock

Description

The CUAV V6X Flight Controller is engineered for demanding commercial and industrial UAV operations. Its core architecture leverages a powerful STM32H753 processor paired with an ARM Cortex-M3 co-processor, delivering the computational headroom required for advanced autonomy and data processing. The design prioritizes reliability through hardware redundancy, incorporating three independent IMU sensors and two barometers on isolated buses to enable seamless failover in the event of a sensor fault.

Beyond core flight stability, the V6X provides extensive connectivity for system expansion. The onboard Ethernet port facilitates high-bandwidth data links with companion computers and high-end surveying equipment. A modular design separates the core processing module from the baseboard, allowing for custom carrier board development to meet specific payload and interface requirements. The controller is built to operate reliably across a wide temperature range and supports a comprehensive suite of standard UAV peripherals.

Key Features

  • High-performance STM32H753IIK6 MCU with DSP & FPU, clocked at 480MHz with 2MB Flash and 1MB RAM.
  • Triple-redundant IMU suite (ICM42688-P, ICM-20649, BMI088) with factory temperature calibration.
  • Dual redundant ICP-20100 barometers for robust altitude hold and vertical position estimation.
  • Integrated RM3100 high-precision magnetometer, resistant to interference for reliable heading.
  • 100Mbps Ethernet interface for connecting mission computers, INS, or high-end mapping cameras.
  • Modular core design enables custom baseboard development for specialized applications.
  • Wide input voltage range (4.75V - 5.45V) and extended operating temperature (-20°C to 85°C).
  • Comprehensive I/O including 16 PWM ports, 3 TELEM ports, 2 CAN buses, and multiple serial interfaces.

Applications

  • High-end surveying and mapping drones requiring stable flight and Ethernet-connected payloads.
  • Industrial inspection UAVs operating in complex electromagnetic environments.
  • Autonomous VTOL (Vertical Take-Off and Landing) platforms for cargo delivery.
  • Heavy-lift cinematography drones needing reliable redundancy and precise control.
  • Research and development platforms for testing advanced autonomy algorithms.

Technical Specifications

ProcessorSTM32H753IIK6
Accelerometer/GyroscopeICM42688-P, ICM-20649, BMI088
CompassRM3100
Barometer2× ICP-20100
PWM I/O16
CAN Ports2
TELEM Ports3
Ethernet1 (100M)
GPS Ports2 (GPS1 with I2C & Safety Switch)
USB Ports2 (Type-C, GH interface)
Operating Voltage4.75 - 5.45 V
Servo Rail Voltage0 - 9.9 V
Operating Temperature-20 to 85 °C

Frequently Asked Questions

What firmware is compatible with the CUAV V6X Flight Controller?

The CUAV V6X is fully compatible with both PX4 and ArduPilot open-source flight stacks. It supports a wide range of vehicle types including multicopters (3-8 motors), fixed-wing aircraft, helicopters, VTOLs, and rovers. The necessary target for this board is pre-configured in both firmware ecosystems.

How does the triple-redundant IMU system enhance safety?

The controller houses three independent IMU sensors (ICM42688-P, ICM-20649, BMI088) on separate data buses. The flight software continuously monitors all three. If one IMU provides data outside expected parameters or fails, the system automatically and seamlessly switches to a healthy sensor without interrupting flight control, significantly improving reliability in critical applications.

What is the purpose of the integrated Ethernet port?

The 100Mbps Ethernet PHY enables high-speed communication between the flight controller and an external mission computer or companion board. This is essential for advanced applications like real-time data streaming to ground control, integrating fiber-optic inertial navigation systems (INS), or controlling high-bandwidth payloads such as surveying cameras.

Can I use a standard 5V BEC to power the V6X?

Yes, the V6X requires a clean 5V power supply within the range of 4.75V to 5.45V, typically provided via its main power input or a dedicated 5V rail. Ensure your BEC or power module can deliver sufficient current for the controller and any peripherals connected to its servo rail, which can accept up to 9.9V for servos.

Package Includes

  • 1 x Pixhawk V6X Autopilot
  • 1 x PW-Link Module
  • 1 x CAN PMU Lite Module
  • 1 x CAN/I2C Extension Board
  • 1 x TF Memory Card
  • 1 x Type-C Cable (100cm)
  • 1 x RSSI Cable (30cm)
  • 1 x DSM RC Cable (30cm)
  • 1 x SBUS RC Cable (30cm)
  • 1 x PPM RC/SBUS OUT Cable (30cm)
  • 1 x Ethernet Cable (40cm)
  • 1 x CAN Cable (30cm)
  • 1 x TELEM Cable (30cm)
  • 1 x UART4 Cable (30cm)
  • 1 x UART4->I2C Cable (30cm)
  • 1 x ADIO Cable (30cm)
  • 1 x Debug Cable (30cm)
  • 1 x SPI6 Cable (30cm)
  • 1 x GPS Cable (30cm)

Additional Information

Weight 0.424 kg
Dimensions 18 × 16 × 6 cm