SKU: SENS-1031
📋 GST Invoice Available

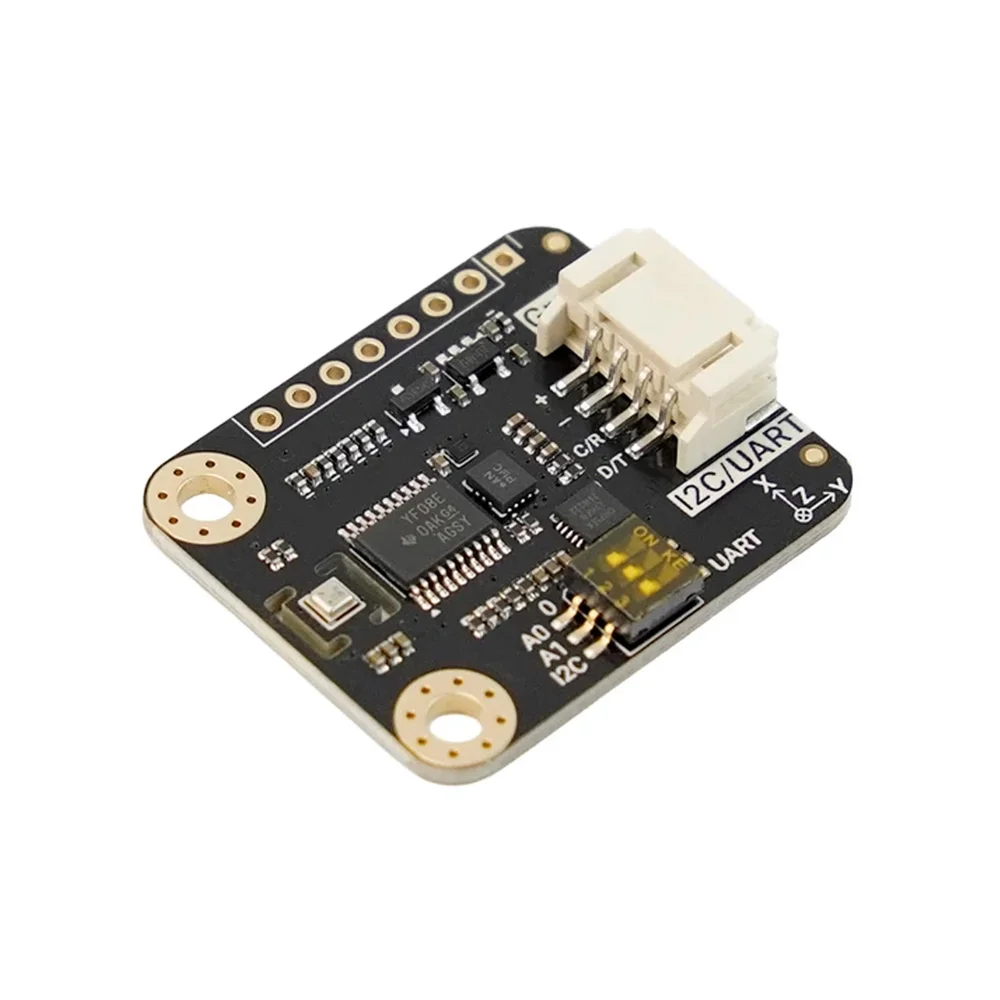
DFRobot Gravity BMI323+BMM350+BMP581 10DOF IMU Sensor Module - I2C/UART Plug & Play

₹3,539.00 (Inclusive of all taxes)
Out of Stock

The DFRobot Gravity 10DOF IMU Sensor integrates Bosch BMI323, BMM350, and BMP581 chips to provide high-precision acceleration, angular velocity, magnetic heading, pressure, and altitude data. Featuring I2C and UART interfaces, it offers plug-and-play compatibility with Arduino, Raspberry Pi, and ESP32 platforms for advanced motion sensing applications.

Features

  • 10DOF sensor fusion combining 6-axis IMU (BMI323), 3-axis magnetometer (BMM350), and barometric pressure sensor (BMP581).
  • Configurable accelerometer (±2g to ±16g) and gyroscope (±125 to ±2000°/s) ranges with up to 6400Hz output data rate.
  • Built-in Bosch hardware motion algorithms for step counting, tap, tilt, free-fall, and activity recognition.
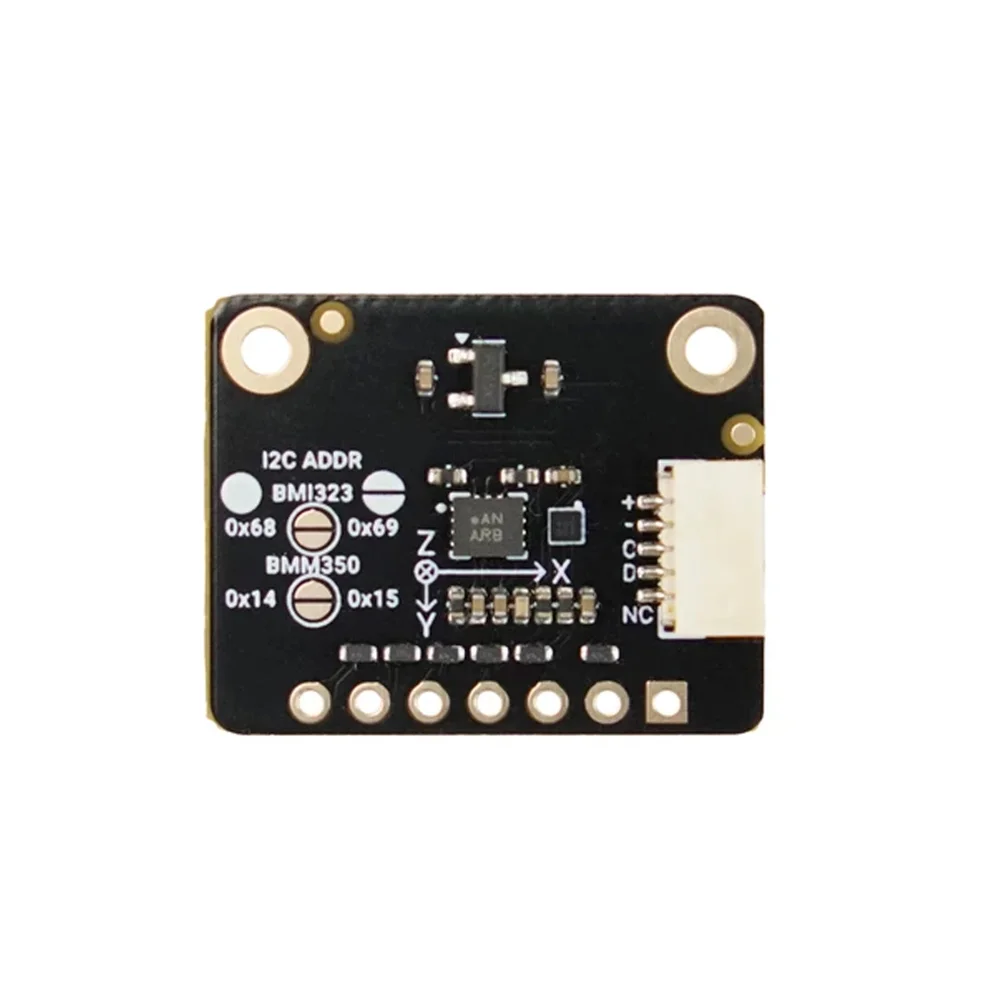
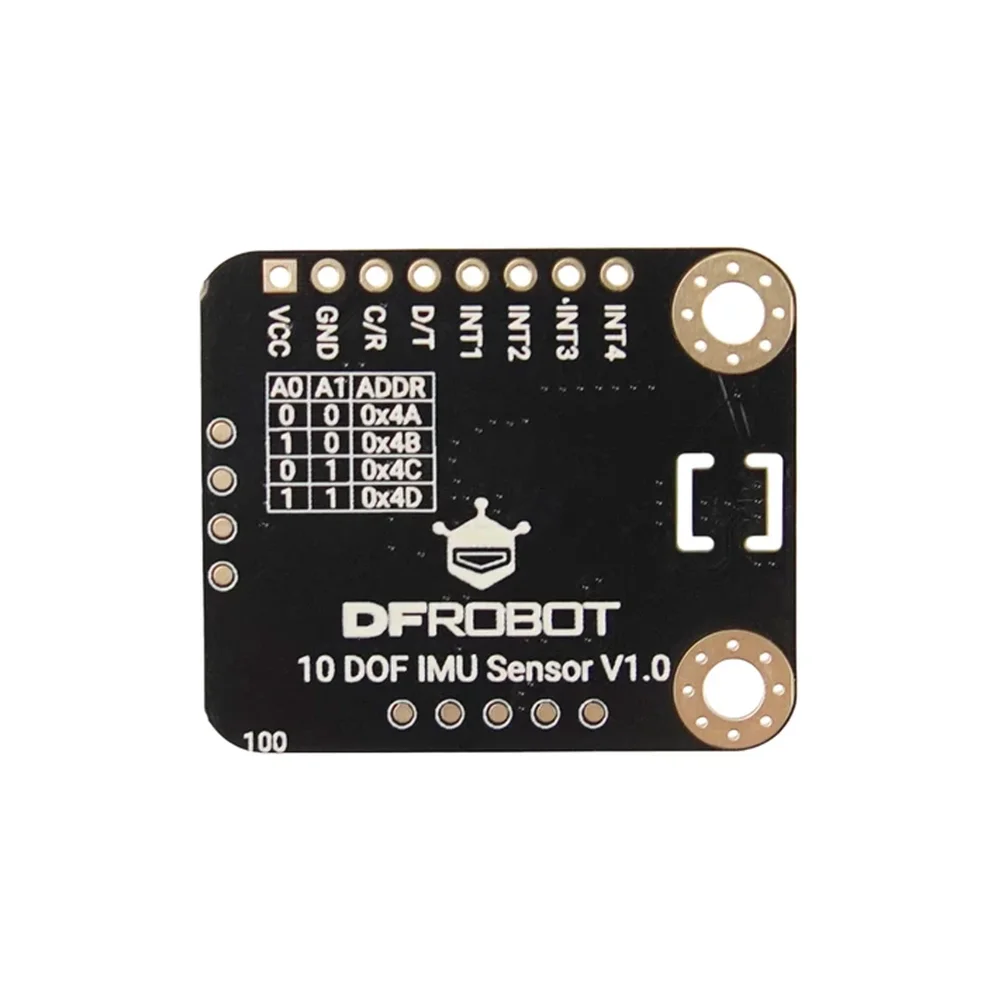
  • Dual I2C (default address 0x4A) and UART communication interfaces for flexible system integration.
  • Compact 32 x 27mm PCB with 3.3-5V operating voltage and integrated 2KB FIFO buffer for stable data streaming.

Out of stock

Description

This high-performance IMU module leverages Bosch’s latest MEMS sensor technology to deliver precise 10-degree-of-freedom motion and environmental data. The BMI323 6-axis IMU provides low-noise acceleration and angular rate measurements, while the BMM350 magnetometer delivers stable magnetic field data for heading calculation, even in dynamic environments. The BMP581 barometric sensor adds accurate pressure and altitude tracking, enabling full 3D orientation and navigation capabilities.

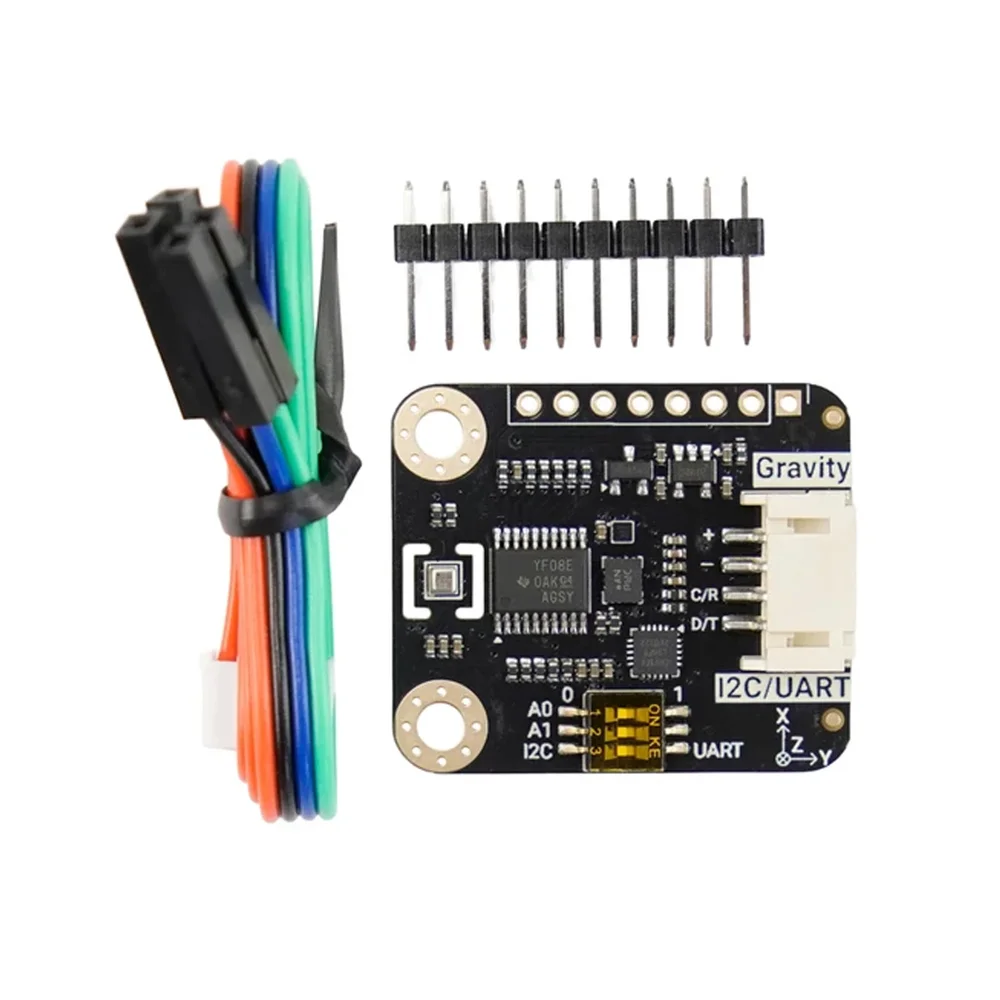
Designed for ease of integration, the module includes standard Gravity PH2.0 and 2.54mm pin headers, supporting both I2C and UART serial protocols. Its low-power architecture features multiple operational modes, programmable interrupt pins, and an internal FIFO buffer to minimize host processor overhead. This makes it ideal for real-time applications in robotics, drones, and wearable systems where precise motion tracking and power efficiency are critical.

Key Features

  • Bosch Sensor Cluster: Integrates BMI323 (accelerometer/gyroscope), BMM350 (magnetometer), and BMP581 (barometer) for comprehensive 10DOF data.
  • High-Resolution Sensing: 16-bit resolution for acceleration and gyroscope data; magnetometer resolution ~0.1µT; pressure resolution ~0.0156Pa.
  • Advanced Onboard Processing: Hardware-embedded algorithms for motion detection (step, tap, tilt, free-fall) reduce software complexity.
  • Flexible Communication: Selectable I2C addresses (0x4A-0x4D) and UART interface enable daisy-chaining and direct serial connection.
  • Optimized Power Management: Multiple power modes and configurable output data rates (ODR) from 0.78125Hz to 6400Hz balance performance and current draw (~3.59mA typical).
  • Robust Data Handling: Integrated 2KB FIFO buffer ensures no data loss during high-speed transmission or host MCU busy periods.
  • Developer-Friendly Design: Includes GUI software for real-time 3D attitude visualization and sensor data logging without coding.
  • Durable Construction: Compact FR4 PCB with 3mm mounting holes, suitable for integration into prototypes and final products.

Applications

  • Drone and UAV flight stabilization, heading control, and altitude hold systems.
  • Robotic platform localization, SLAM (Simultaneous Localization and Mapping), and inertial navigation.
  • Wearable electronics for advanced activity tracking, step counting, and gesture recognition.
  • Motion controller interfaces for VR/AR systems, gaming, and human-machine interaction.
  • Precision agriculture and surveying equipment requiring tilt-compensated electronic compass functionality.

Technical Specifications

Sensor Type10DOF IMU Sensor
IMU ChipBosch BMI323
MagnetometerBosch BMM350
Barometric SensorBosch BMP581
Operating VoltageDC 3.3–5V
Operating Current3.59mA
Communication InterfaceI²C / UART
Connector TypePH2.0-4P (Gravity), 2.54mm Pin Header
I²C Address (Default)0x4A
Programmable Interrupt Pins4
Accelerometer Resolution16-bit
Accelerometer Range±2g, ±4g, ±8g, ±16g
Accelerometer ODR0.78125Hz to 6400Hz
Gyroscope Resolution16-bit
Gyroscope Range±125, ±250, ±500, ±1000, ±2000°/s
Gyroscope ODR0.78125Hz to 6400Hz
Magnetometer Range±2000µT
Magnetometer Resolution~0.1µT
Magnetometer Max ODR400Hz
Pressure Range30kPa to 125kPa
Pressure Resolution~0.0156Pa
Pressure ODR0.125Hz to 240Hz
Temperature Range-40°C to +85°C
PCB Size32 × 27mm
Mounting Hole Spacing20mm
Mounting Hole Diameter3mm
Weight3g

Frequently Asked Questions

What is the default I2C address and can it be changed?

The default I2C address is 0x4A. The module supports three additional configurable addresses: 0x4B, 0x4C, and 0x4D, allowing multiple sensors to operate on the same I2C bus without address conflicts. Address selection is typically handled via hardware configuration or software commands during initialization.

How do I connect this sensor to an Arduino or Raspberry Pi?

For Arduino, use the provided Gravity 4P cable to connect the module's PH2.0 port to a Gravity-compatible shield or digital pin header. For direct connection or use with Raspberry Pi/ESP32, solder the included 10-pin header and wire the I2C pins (SDA, SCL), power (3.3V/5V, GND), and optional UART pins (TX, RX) as needed. The DFRobot library and examples simplify data reading.

Does the sensor require calibration for the magnetometer?

Yes, for accurate heading data, the magnetometer should undergo a hard-iron and soft-iron calibration procedure to compensate for local magnetic distortions. The included GUI software provides tools for this calibration. The accelerometer and gyroscope are factory-calibrated, but may benefit from sensor fusion algorithm tuning in your specific application.

What is the purpose of the built-in FIFO buffer?

The integrated 2KB FIFO buffer stores sensor data temporarily, allowing the host microcontroller to read data in bursts rather than requiring real-time polling. This is crucial for maintaining data integrity during high output data rates (up to 6400Hz) or when the host processor is busy with other tasks, preventing data loss.

Can this sensor measure absolute altitude?

Yes, the integrated BMP581 barometric pressure sensor provides highly accurate pressure readings, which can be converted to altitude relative to a known reference pressure (e.g., SEA level). It is suitable for detecting altitude changes in drones or wearable devices, but for absolute altitude, an initial reference pressure must be supplied to the calculation.

Package Includes

  • 1 x DFRobot Gravity: BMI323+BMM350+BMP581 10DOF IMU Sensor
  • 1 x Gravity 4P Sensor Cable
  • 1 x 2.54 mm Black Single Row Pin Header – 10-Pin

Additional Information

Weight 0.01 kg
Dimensions 8 × 8 × 3 cm