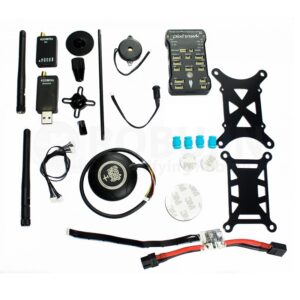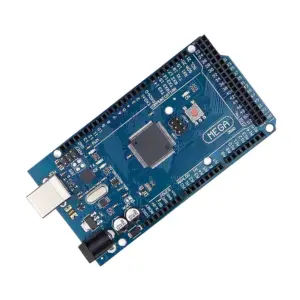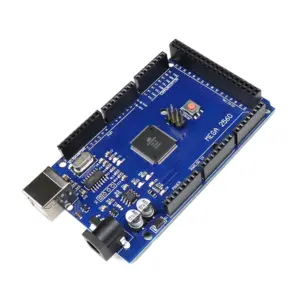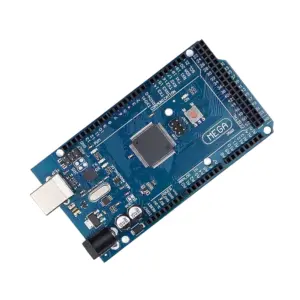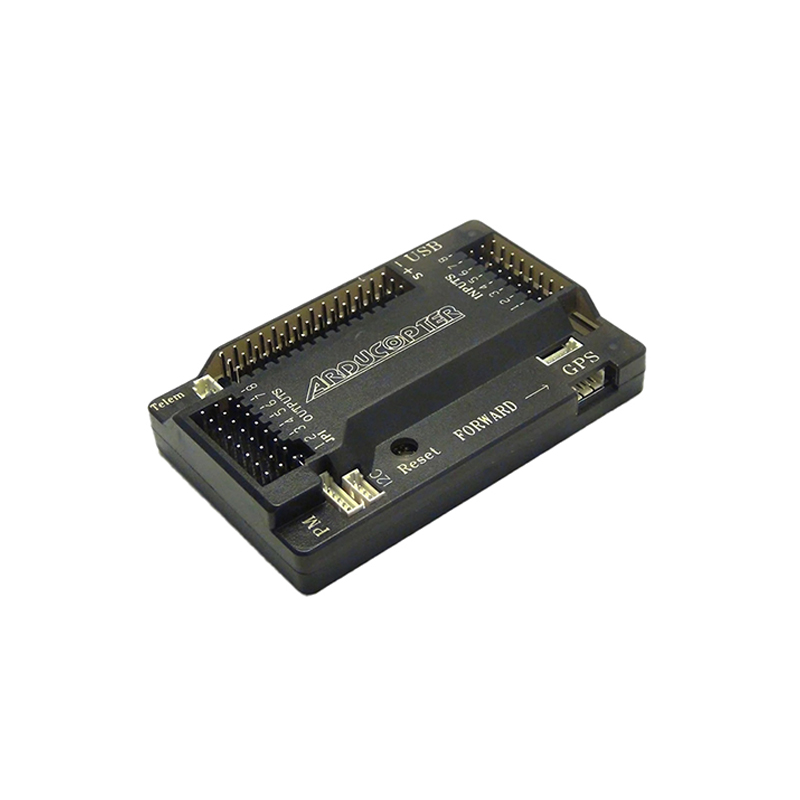
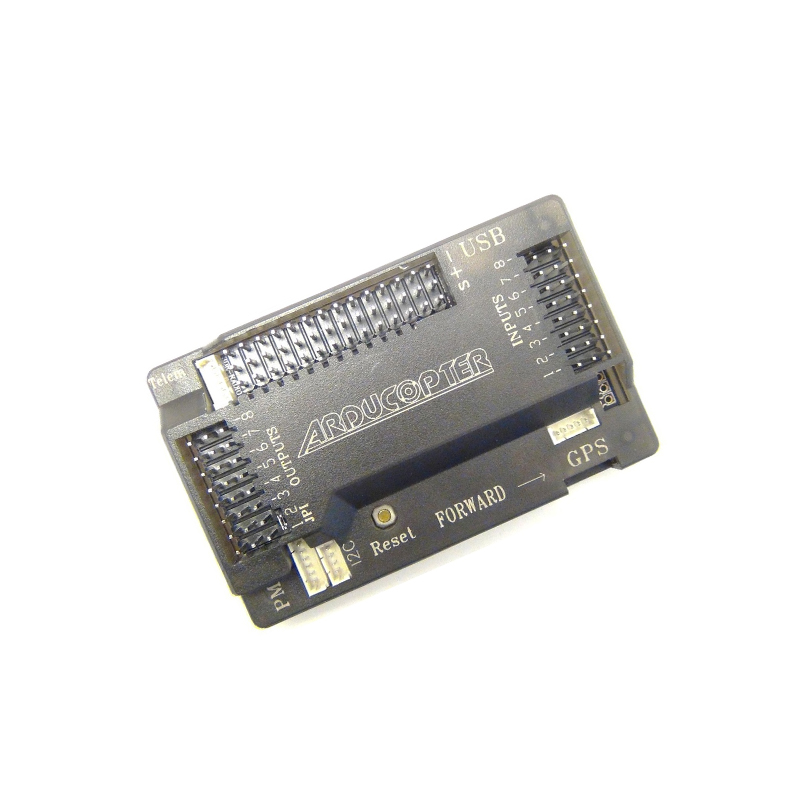
APM 2.8 Flight Controller without Compass
The APM 2.8 Flight Controller is an open-source autopilot system designed for multirotor, fixed-wing, and rover applications, compatible with the ArduPilot firmware and Mission Planner ground control software. This version is supplied without an integrated compass, requiring an external GPS/compass module for full navigation capability.
Features
- Open-source ArduPilot autopilot system for multirotors, rovers, and fixed-wing aircraft.
- Features the MPU-6000 6-DOF IMU and MS5611 barometric pressure sensor for stable flight.
- Onboard 4MB dataflash chip for automatic flight data logging and post-flight analysis.
- Arduino-compatible architecture based on the ATmega2560 and ATmega32U-2 microcontrollers.
- Requires an external GPS/compass module for full autonomous waypoint mission functionality.
Out of stock
The APM 2.8 Flight Controller represents a mature, community-supported autopilot platform, building upon the legacy of the APM 2.5 and 2.6. Its core processing is handled by an ATmega2560 microcontroller, paired with an ATmega32U-2 for USB communication, providing a robust and Arduino-compatible development environment. The sensor suite, including the MPU-6000 IMU and MS5611 barometer, delivers reliable attitude and altitude estimation for a variety of autonomous vehicles.
Designed for builders and developers, this controller excels in educational projects, custom drone builds, and autonomous vehicle research. Its lack of an integrated compass necessitates the addition of an external GPS/compass module, which is a standard practice for achieving full positional hold and autonomous navigation capabilities within the ArduPilot ecosystem. The included 4MB dataflash allows for detailed flight log recording, which is critical for tuning and diagnosing vehicle performance.
Additional Information
| Weight | 0.085 kg |
|---|---|
| Dimensions | 3 × 9 × 2 cm |