SKU: SENS-0130
📋 GST Invoice Available

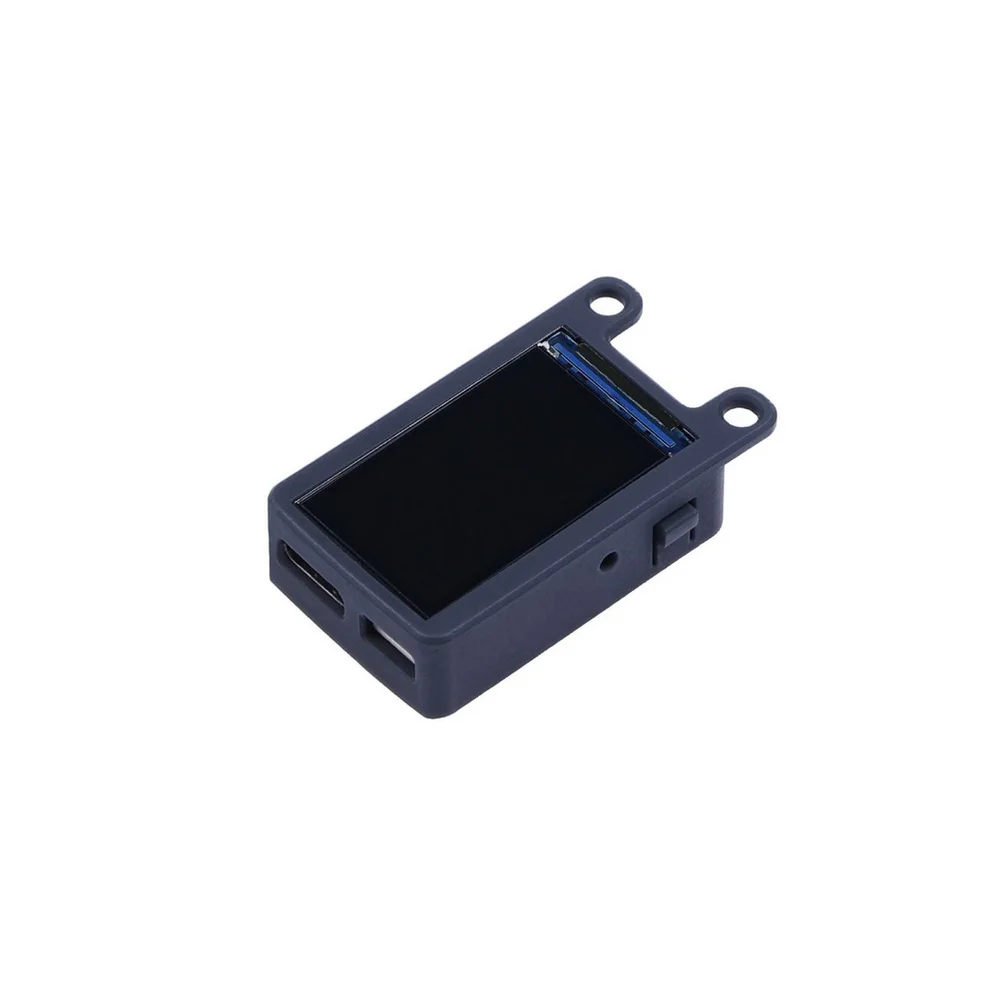
Sipeed MaixSense A010 with LCD - 3D ToF Depth Sensor Module w/ USB-C & UART

₹4,729.00 (Inclusive of all taxes)
Out of Stock

The Sipeed MaixSense A010 is a compact 3D Time-of-Flight (ToF) sensor module featuring an integrated 100×100 pixel array and an onboard BL702 RISC-V processor for real-time depth data processing. It outputs depth maps and RGB images at 30fps via USB-C (virtual COM) or UART interfaces, making it compatible with Raspberry Pi, K210, and other Linux-based development platforms for IoT and robotics applications.

Features

  • Integrated 100×100 pixel ToF sensor array with onboard RISC-V processor for real-time depth processing.
  • Outputs depth data and RGB image streams simultaneously at up to 30 frames per second.
  • Millimeter-level ranging accuracy across a 0.15 to 1.5-meter operational distance.
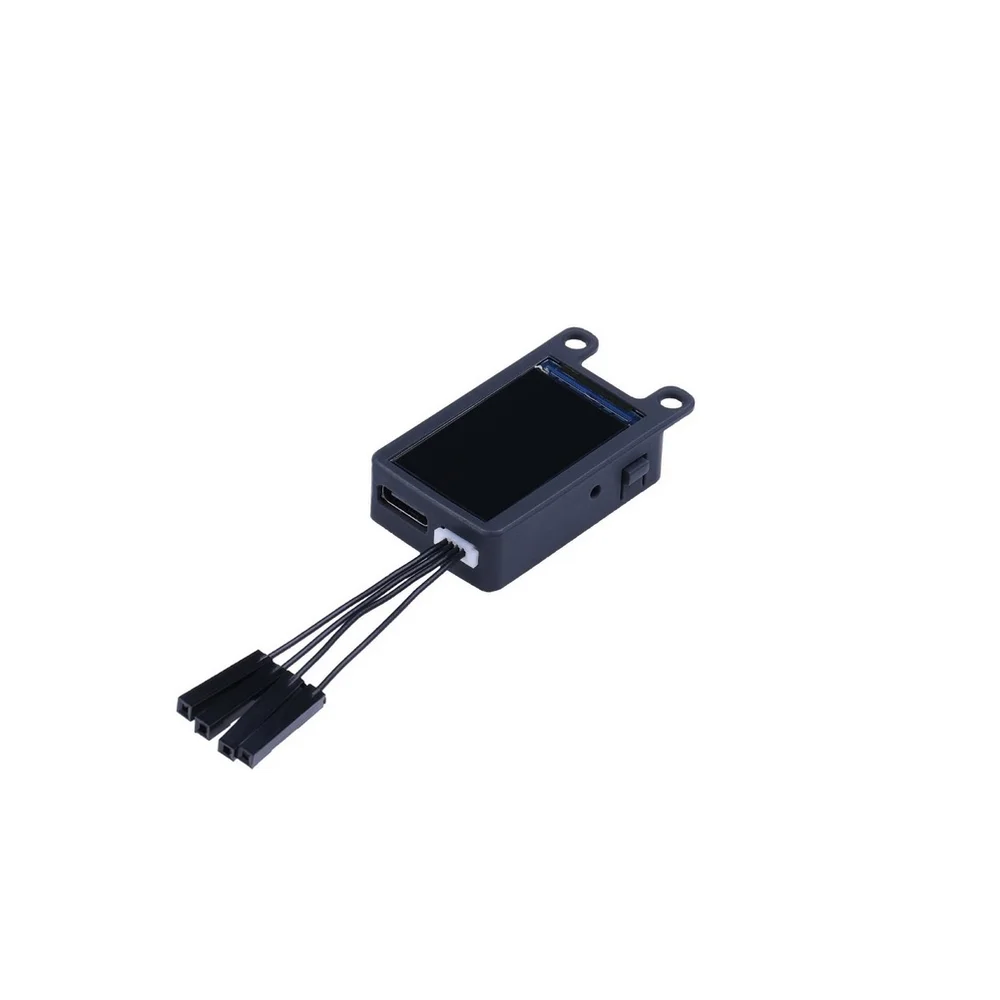
  • Dual communication interfaces: USB Type-C (virtual serial) and a 4-pin 1.0mm UART connector.
  • Pre-integrated algorithms for human positioning, posture monitoring, and SLAM navigation.

Out of stock

Description

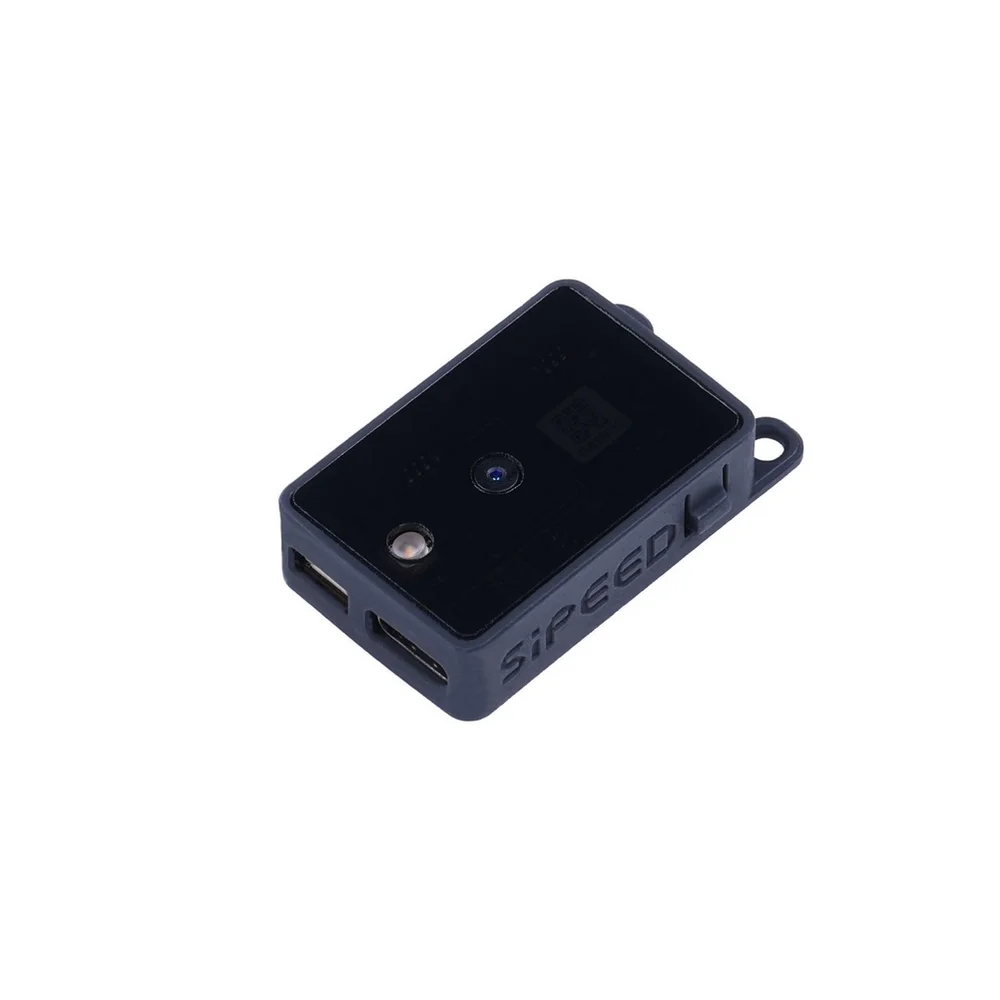
The Sipeed MaixSense A010 (MetaSense A010) is a fully integrated 3D Time-of-Flight solution that combines a ToF sensor array, signal processor, and application algorithms on a single board. It utilizes infrared light pulses to measure the time-of-flight to objects, calculating depth with millimeter-level precision. The module performs all depth processing onboard via its BL702 RISC-V CPU, outputting clean depth map and RGB video streams for direct integration into host systems.

Designed for flexible IoT and embedded development, the module communicates via a simple serial protocol over its USB-C or hardware UART interfaces. This allows seamless connection to microcontrollers like the Kendryte K210 or single-board computers like the Raspberry Pi. The integrated algorithms support advanced applications such as multi-person tracking, gesture recognition, and robotic navigation without requiring extensive external computational resources.

Key Features

  • Onboard BL702 32-bit RISC-V CPU with FPU, operating at up to 144MHz for real-time ToF data processing.
  • Combined 100x100 resolution ToF sensor and RGB imager for synchronized depth and color vision.
  • High-accuracy millimeter-level depth sensing across a 0.15m to 1.5m operational range.
  • Low-power architecture with support for lithium battery management, enabling portable and outdoor deployments.
  • Robust serial protocol interface (UART) for easy integration with K210, Raspberry Pi, and other Linux SBCs.
  • Durable hard-shell construction suitable for use in varied environmental conditions.
  • Pre-loaded with ROS1 and ROS2 driver packages for rapid development in robotic perception systems.
  • Outputs depth data and RGB image streams at a fluid 30 frames per second.

Applications

  • Simultaneous Localization and Mapping (SLAM) and navigation for autonomous robots and AGVs.
  • People counting, tailgate detection, and occupancy sensing in smart building systems.
  • Gesture recognition and human-machine interaction for VR/AR interfaces and smart appliances.
  • 3D modeling, object dimension measurement, and bin-picking in industrial automation.
  • Obstacle avoidance and environmental perception for service robots and laser TV autofocus.

Technical Specifications

ModelSipeed MaixSense A010 (MetaSense A010)
Core Sensor100x100 pixel ToF Array + RGB Imager
ProcessorBL702 32-bit RISC-V CPU @ 144MHz
Onboard Memory132KB RAM, 192KB ROM
Depth Range0.15 - 1.5 meters
Output Data RateDepth & RGB Image @ 30 fps
Communication InterfacesUSB 2.0 Type-C (Virtual COM), UART (4-pin 1.0mm connector)
Supply Voltage5V DC
Operating Current~0.5A
Operating Temperature-20°C to +50°C
Dimensions (L x W x H)40.70 mm x 23.25 mm x 10.50 mm
WeightApprox. 0.041 kg

Frequently Asked Questions

What are the primary communication interfaces on the MaixSense A010?

The module provides two main interfaces: a USB Type-C port that enumerates as a virtual serial (COM) port over USB 2.0, and a separate 4-pin 1.0mm pitch UART connector for direct hardware serial communication. Both interfaces use the same simple serial protocol to stream depth map and RGB image data, allowing connection to hosts like Raspberry Pi or microcontrollers like the K210.

What is the effective sensing range and accuracy of this ToF module?

The Sipeed MaixSense A010 has a specified depth sensing range from 0.15 meters (15 cm) to 1.5 meters. It achieves millimeter-level accuracy within this range, making it suitable for precise applications like gesture control, object sizing, and close-range obstacle detection. Performance can be influenced by ambient light and surface reflectivity.

Can this sensor be used outdoors or in bright environments?

While the module features a durable hard shell, its primary sensing technology is based on active infrared light. Performance in direct, bright sunlight may be degraded due to infrared interference. It is best suited for controlled indoor lighting or shaded outdoor environments. The operational temperature range is -20°C to +50°C.

How do I power the MaixSense A010 and what are its requirements?

The module is powered via its USB Type-C port, requiring a standard 5V DC supply capable of delivering approximately 0.5A. There is no separate power pin on the UART connector; all power and data for primary operation are supplied through the USB-C connection. The onboard circuitry includes power management supporting lithium battery operation.

Is the MaixSense A010 compatible with Robot Operating System (ROS)?

Yes, the Sipeed MaixSense A010 is supported by official ROS packages for both ROS1 and ROS2. These packages provide the necessary drivers and tools to quickly access depth data, point clouds, and depth images, facilitating rapid integration into robotic perception stacks for navigation, mapping, and human-robot interaction.

Package Includes

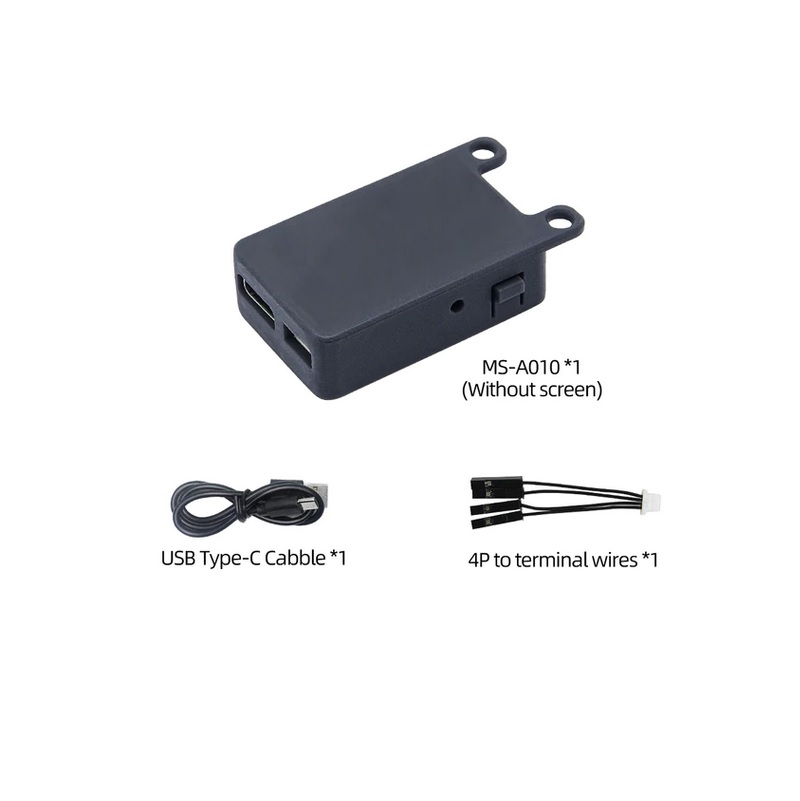
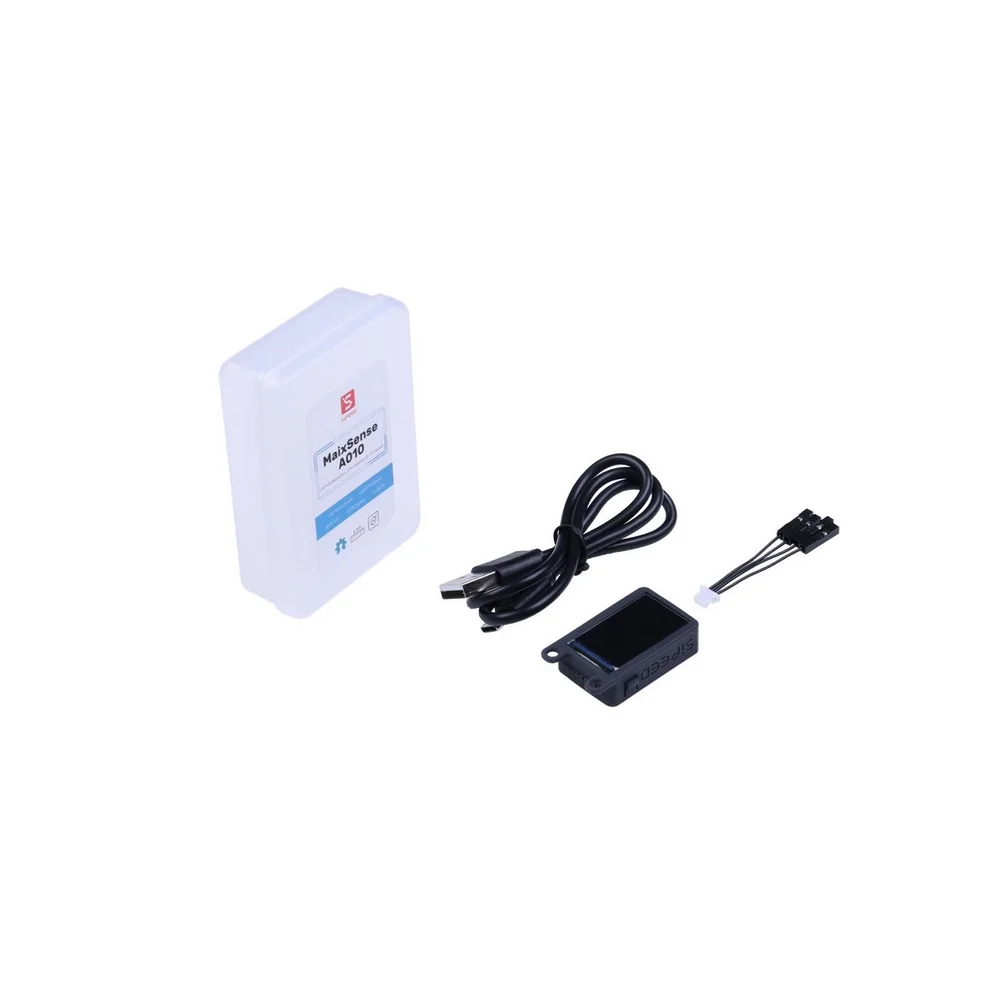
  • 1 x Sipeed MaixSense A010 Module with Integrated LCD

Additional Information

Weight 0.041 kg
Dimensions 4.07 × 2.325 × 1.05 cm