SKU: DRFC-2055
📋 GST Invoice Available

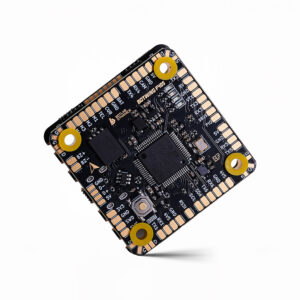
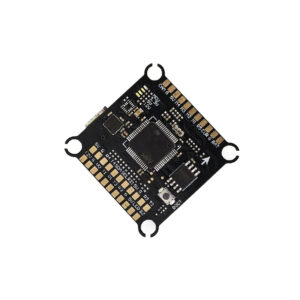
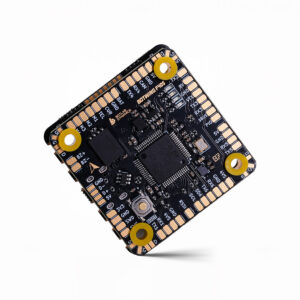
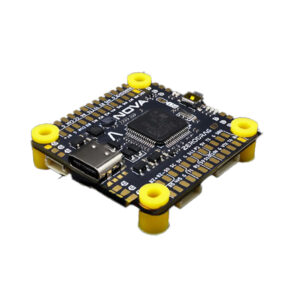
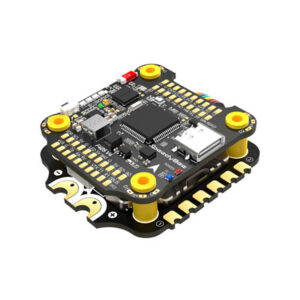
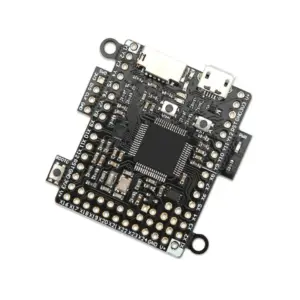
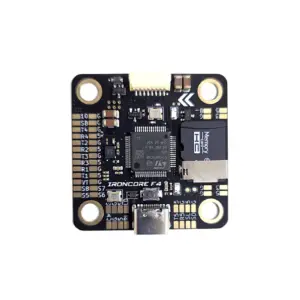
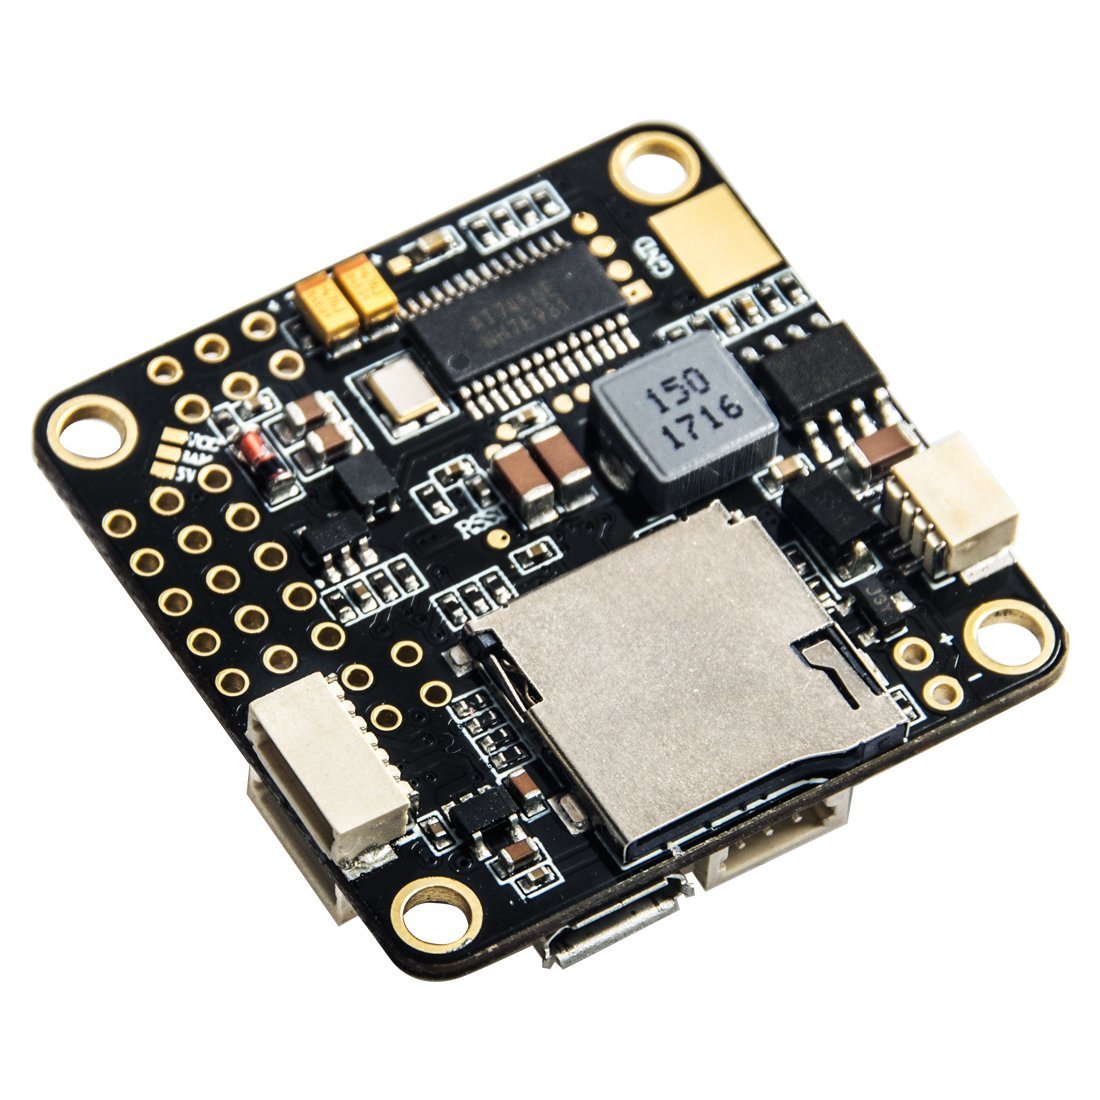
OMNIBUS F4 V2 PRO Flight Controller with SD Card Slot & BEC

₹3,169.00 (Inclusive of all taxes)
Out of Stock

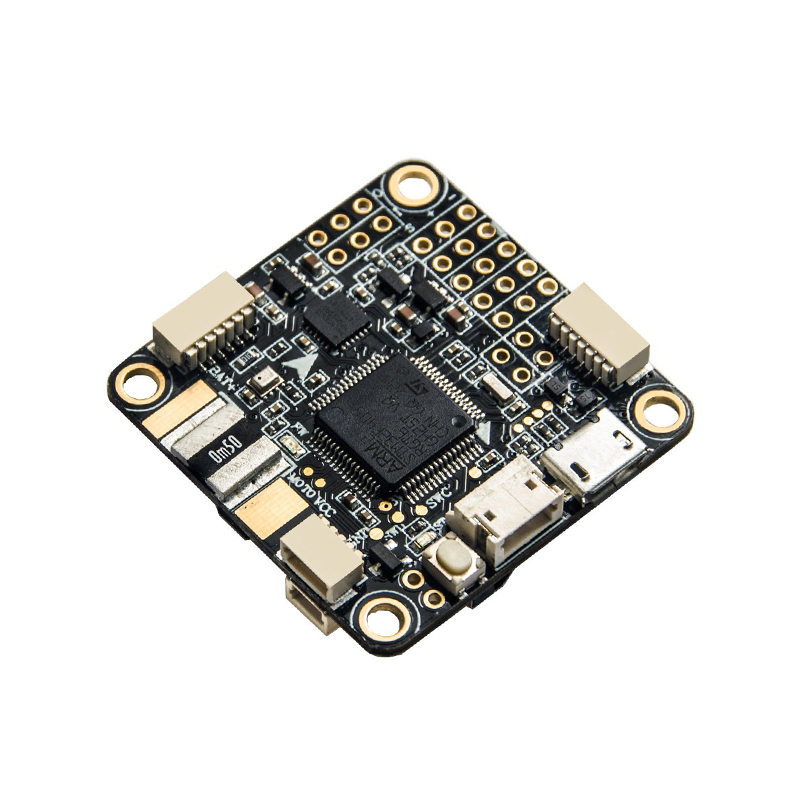
The OMNIBUS F4 V2 PRO is a feature-rich flight controller built around the STM32F405 MCU, offering Betaflight OSD, an integrated 5V/3A BEC, and an SPI MPU6000 gyro for precise FPV racing and freestyle drone control.

Features

  • STM32F405 processor for high-speed loop times and Betaflight compatibility.
  • Integrated Betaflight OSD configurable via remote controller for in-goggle tuning.
  • Onboard 5V/3A SBEC powers the board directly from 2S-4S LiPo batteries.
  • SPI-connected MPU6000 gyro/accelerometer and BMP280 barometer (user-enabled).
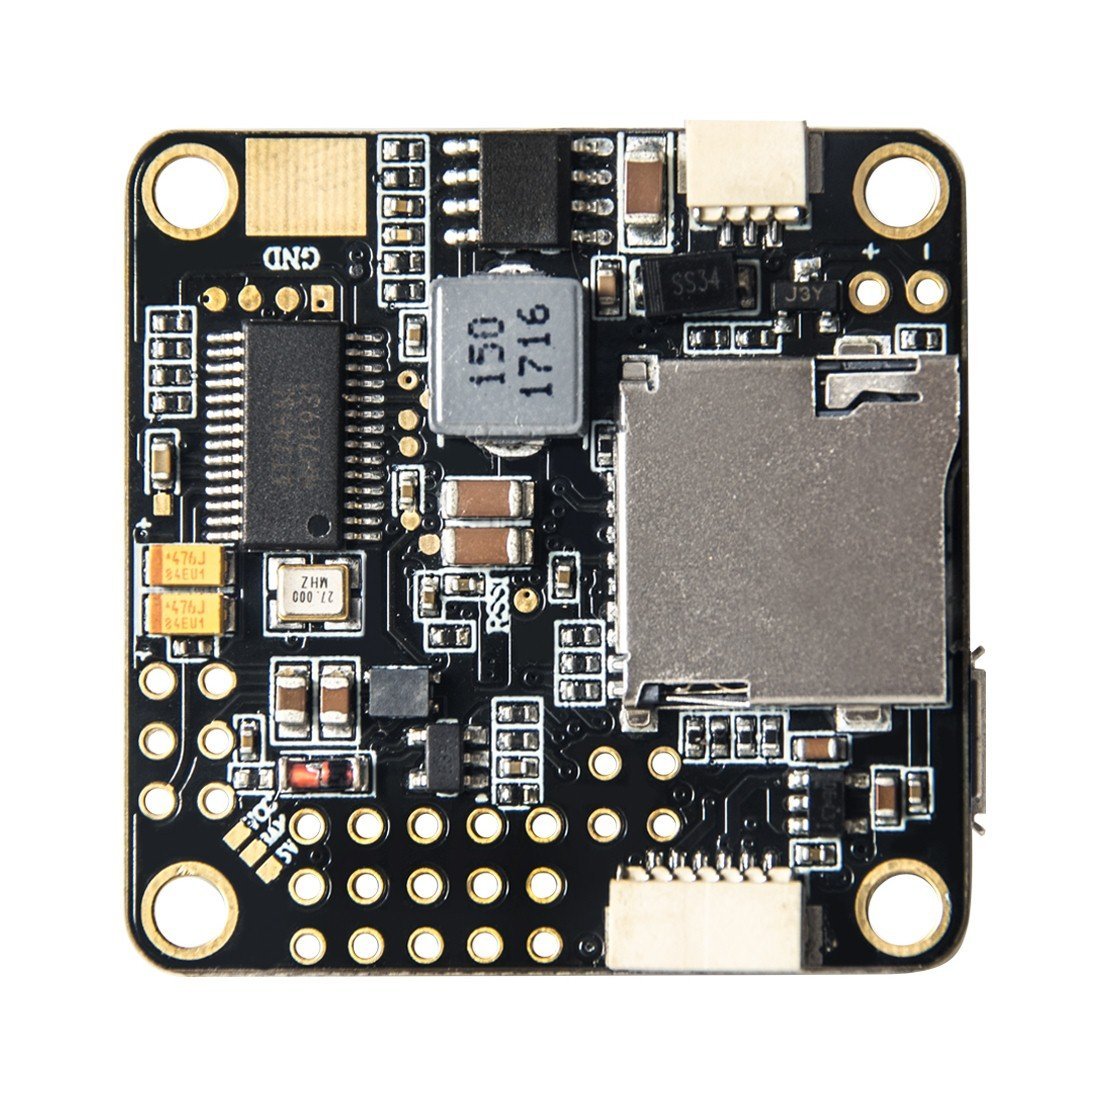
  • MicroSD card slot for blackbox flight data logging and analysis.

Out of stock

Description

The OMNIBUS F4 V2 PRO flight controller consolidates critical systems into a compact 37x37mm footprint, designed for performance-oriented FPV builds. Its STM32F405 MCU provides the processing headroom needed for advanced Betaflight firmware features and low-latency flight response. The integrated 5V/3A switching BEC simplifies wiring by eliminating the need for an external regulator, accepting direct input from 2S to 4S LiPo packs.

Flight data management is handled by the SPI-bus MPU6000 IMU for low-noise gyro readings and a BMP280 barometer for altitude hold functions. The controller features a built-in Betaflight OSD, allowing pilots to adjust PID settings and view telemetry directly through their FPV video feed. A microSD slot enables detailed blackbox logging, essential for diagnosing flight characteristics and tuning performance.

Key Features

  • High-performance STM32F405 microcontroller with ample flash memory for complex firmware.
  • Onboard 5V/3A switching BEC (SBEC) for clean power from 2S-4S LiPo inputs.
  • Integrated current sensor for real-time battery consumption monitoring via OSD.
  • SPI bus connection for the MPU6000 gyro/accelerometer, ensuring minimal latency.
  • User-configurable BMP280 barometer soldered onboard for altitude stabilization modes.
  • Direct Betaflight OSD control via SPI, supporting in-flight PID adjustments.
  • MicroSD card slot for high-rate blackbox data logging of gyro, PID, and motor outputs.
  • Onboard video filter providing clean 5V power to VTX and FPV camera systems.

Applications

  • 5-inch FPV racing drones requiring high-speed processing and blackbox analysis.
  • Freestyle quadcopters where integrated OSD for in-goggle tuning is beneficial.
  • Intermediate DIY builds seeking a compact FC with built-in BEC and current sensing.
  • Betaflight-based drones where SPI gyro performance and direct OSD control are prioritized.

Technical Specifications

Model NameOmnibus F4 V2 PRO
ProcessorSTM32-F405 RGT6
FirmwareBetaflight (e.g., 3.1.7_OMNIBUSF4SD)
Gyro/AccelerometerMPU6000 (SPI)
BarometerBMP280 (onboard, user-enabled)
Built-in SensorsCurrent Sensor, Voltage Sensor
Onboard OSDBetaflight OSD (SPI-controlled)
BEC Output5V / 3A
Input Voltage2S-4S LiPo (via BEC)
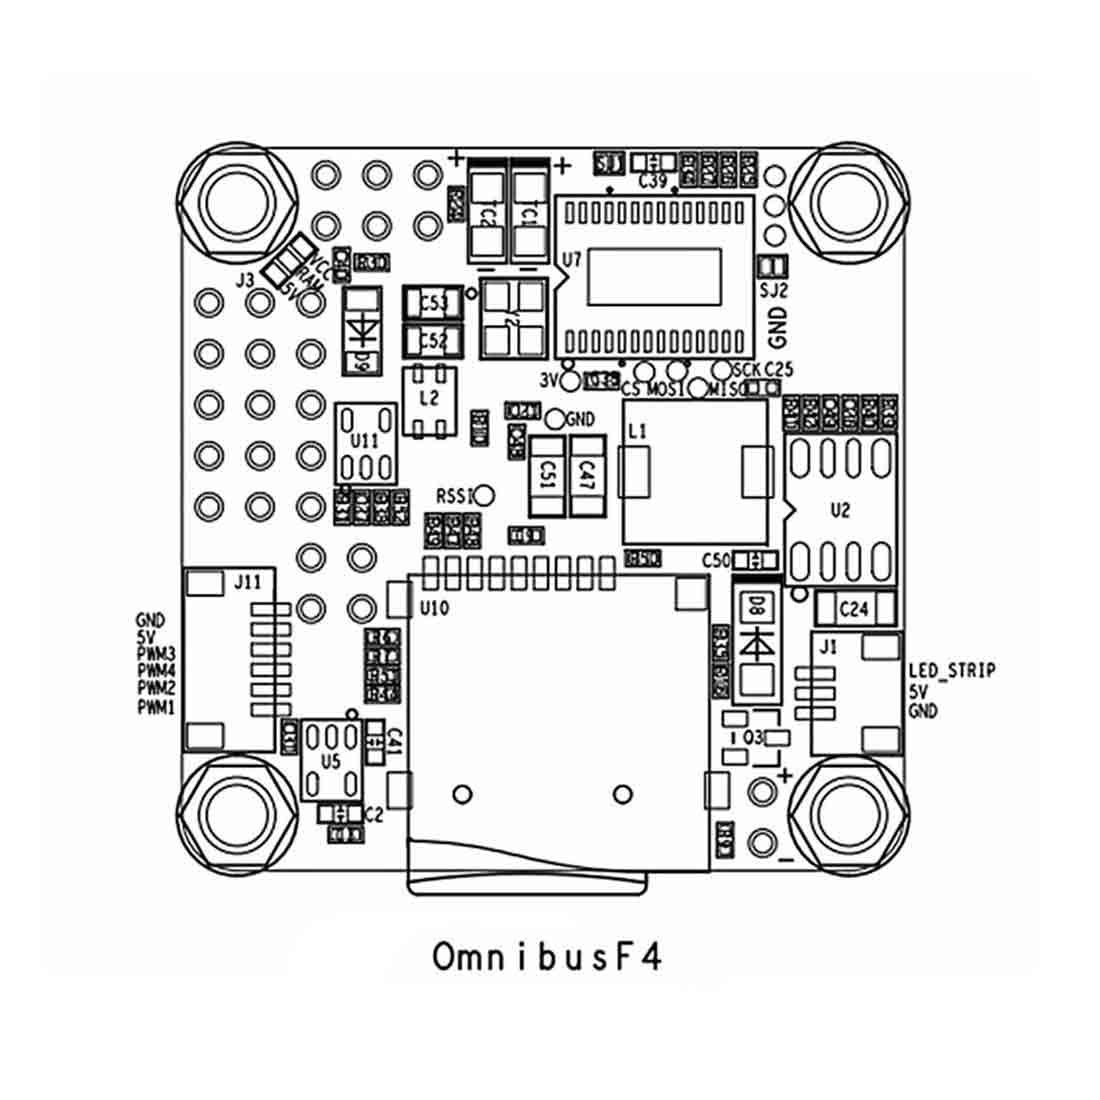
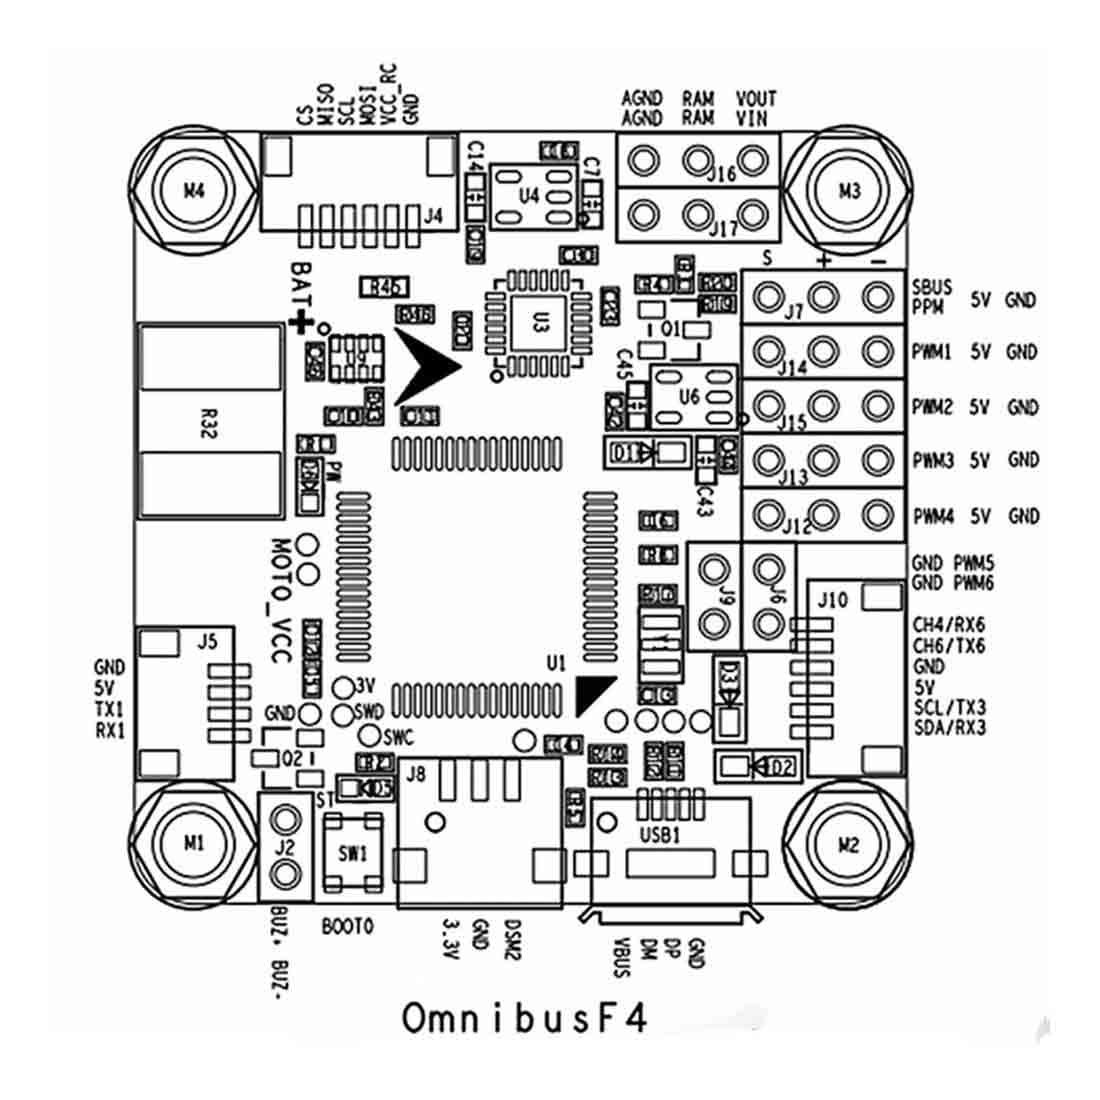
Receiver InputSBUS/PPM (via pinheaders)
Data LoggingMicroSD Card Slot
Dimensions (LxWxH)37 x 37 x 5 mm
Weight18 g

Frequently Asked Questions

What is the input voltage range for the OMNIBUS F4 V2 PRO?

The onboard 5V/3A BEC allows the flight controller to be powered directly from a 2S (7.4V), 3S (11.1V), or 4S (14.8V) LiPo battery pack. You connect your main battery leads to the designated VBAT input pads. The BEC regulates this down to a stable 5V for the FC and its peripherals.

How do I enable the barometer (BMP280) on this flight controller?

The BMP280 barometer is physically soldered onto the board but is disabled by default in the firmware. To enable it, you must connect to the FC via Betaflight Configurator, navigate to the Configuration tab, and activate the 'Barometer' feature. Ensure the correct sensor type (BMP280) is selected in the Betaflight settings for proper altitude hold functionality.

Can I use an ExpressLRS receiver with this flight controller?

Yes, ExpressLRS receivers with CRSF protocol output are fully compatible. You would connect the receiver's TX pin to a free UART RX pad on the FC (e.g., UART3). In Betaflight Configurator, set the corresponding serial port to 'Serial RX' and select 'CRSF' as the receiver protocol in the Receiver tab. Ensure the baud rate is set correctly, typically 420000 for ExpressLRS.

What is the function of the built-in current sensor?

The integrated current sensor measures the total current draw from your drone's battery in real-time. This data is processed by the flight controller and can be displayed via the On-Screen Display (OSD) in your FPV goggles. It provides crucial information for monitoring battery consumption during flight, helping to prevent over-discharge and calculate remaining flight time.

Package Includes

  • 1 x OMNIBUS F4 V2 PRO Flight Controller
  • 3 x Burg Connectors (JST-SH 1.0mm)

Additional Information

Weight 0.018 kg
Dimensions 3.7 × 3.7 × 0.5 cm